SINUMERIK 840D sl. Service - Configuring Commissioning. Manual (2011-2020) - page 91
Diagnostics
8.3 Diagnostic functions in SINUMERIK Operate
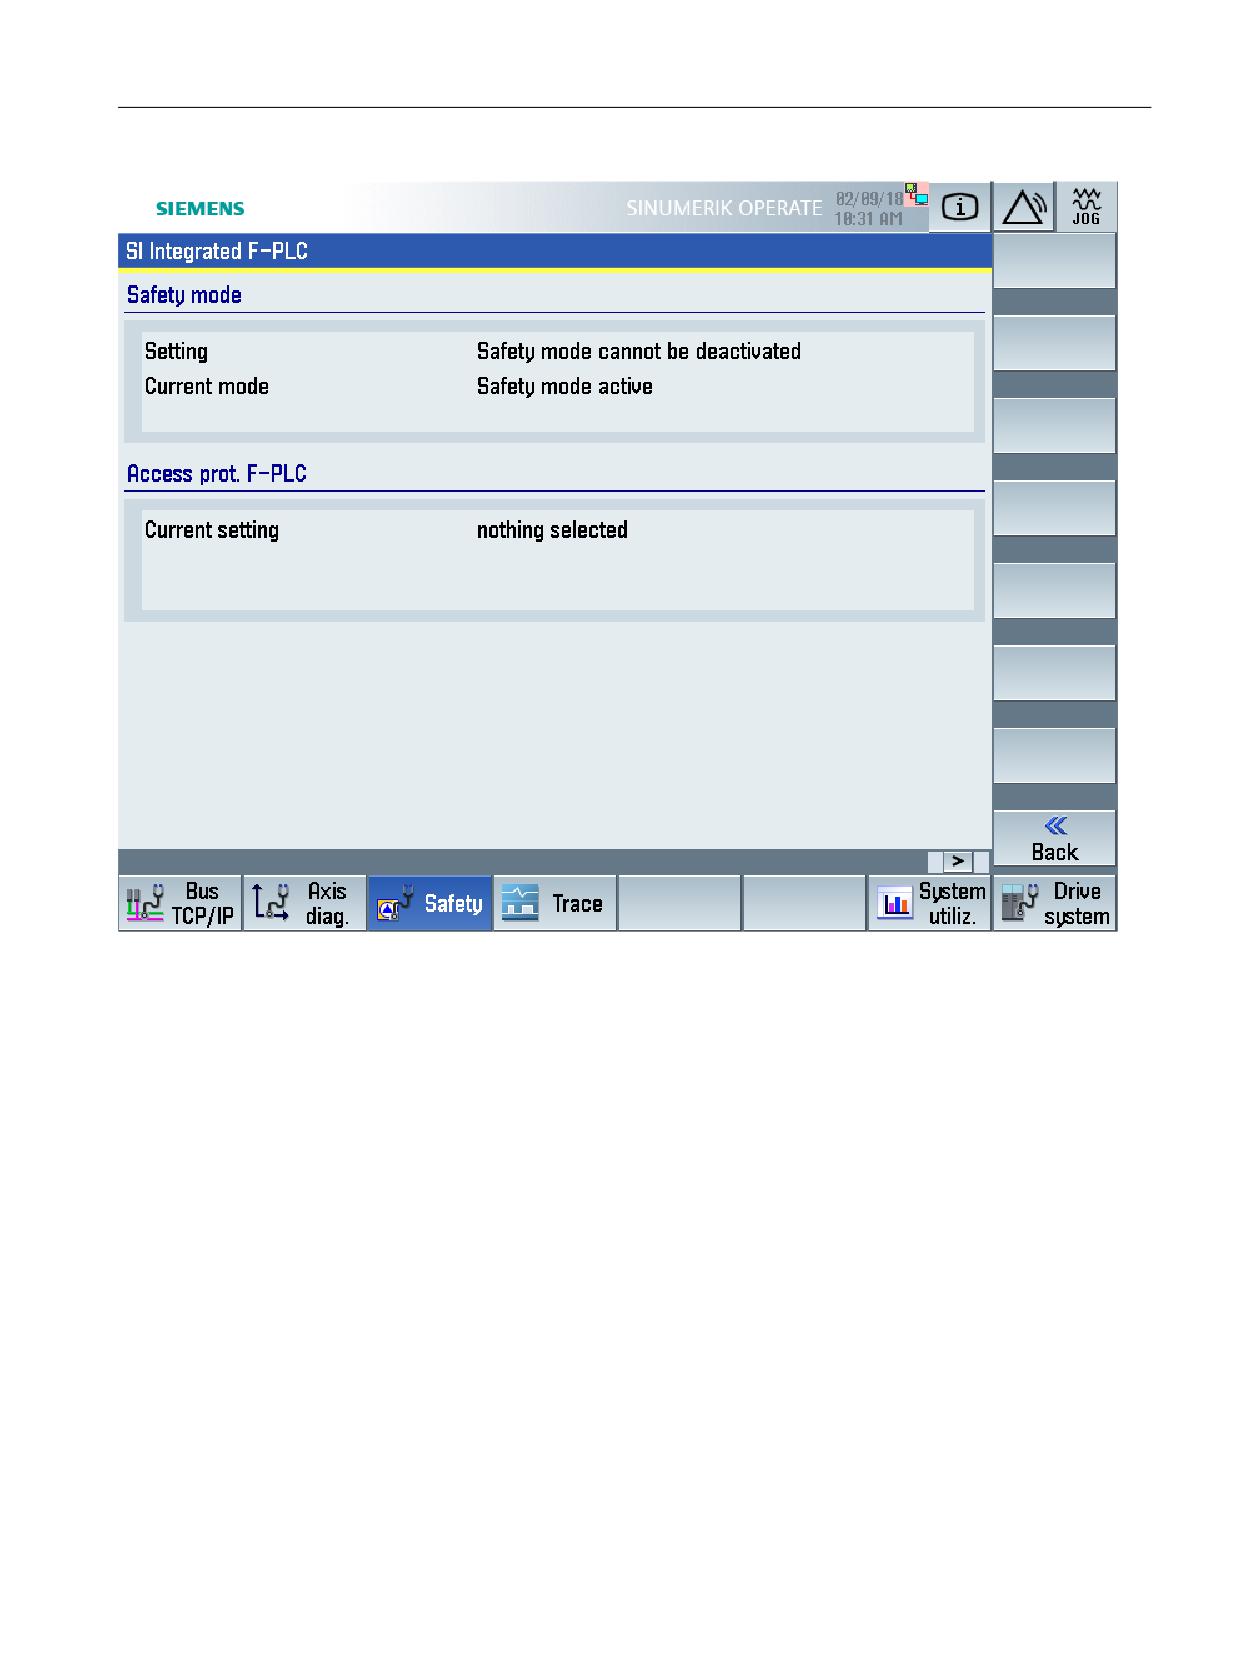
Figure 8-11
"SI Integrated F-PLC" diagnostic screen (screenshot as example)
8.3.10
SI I/O
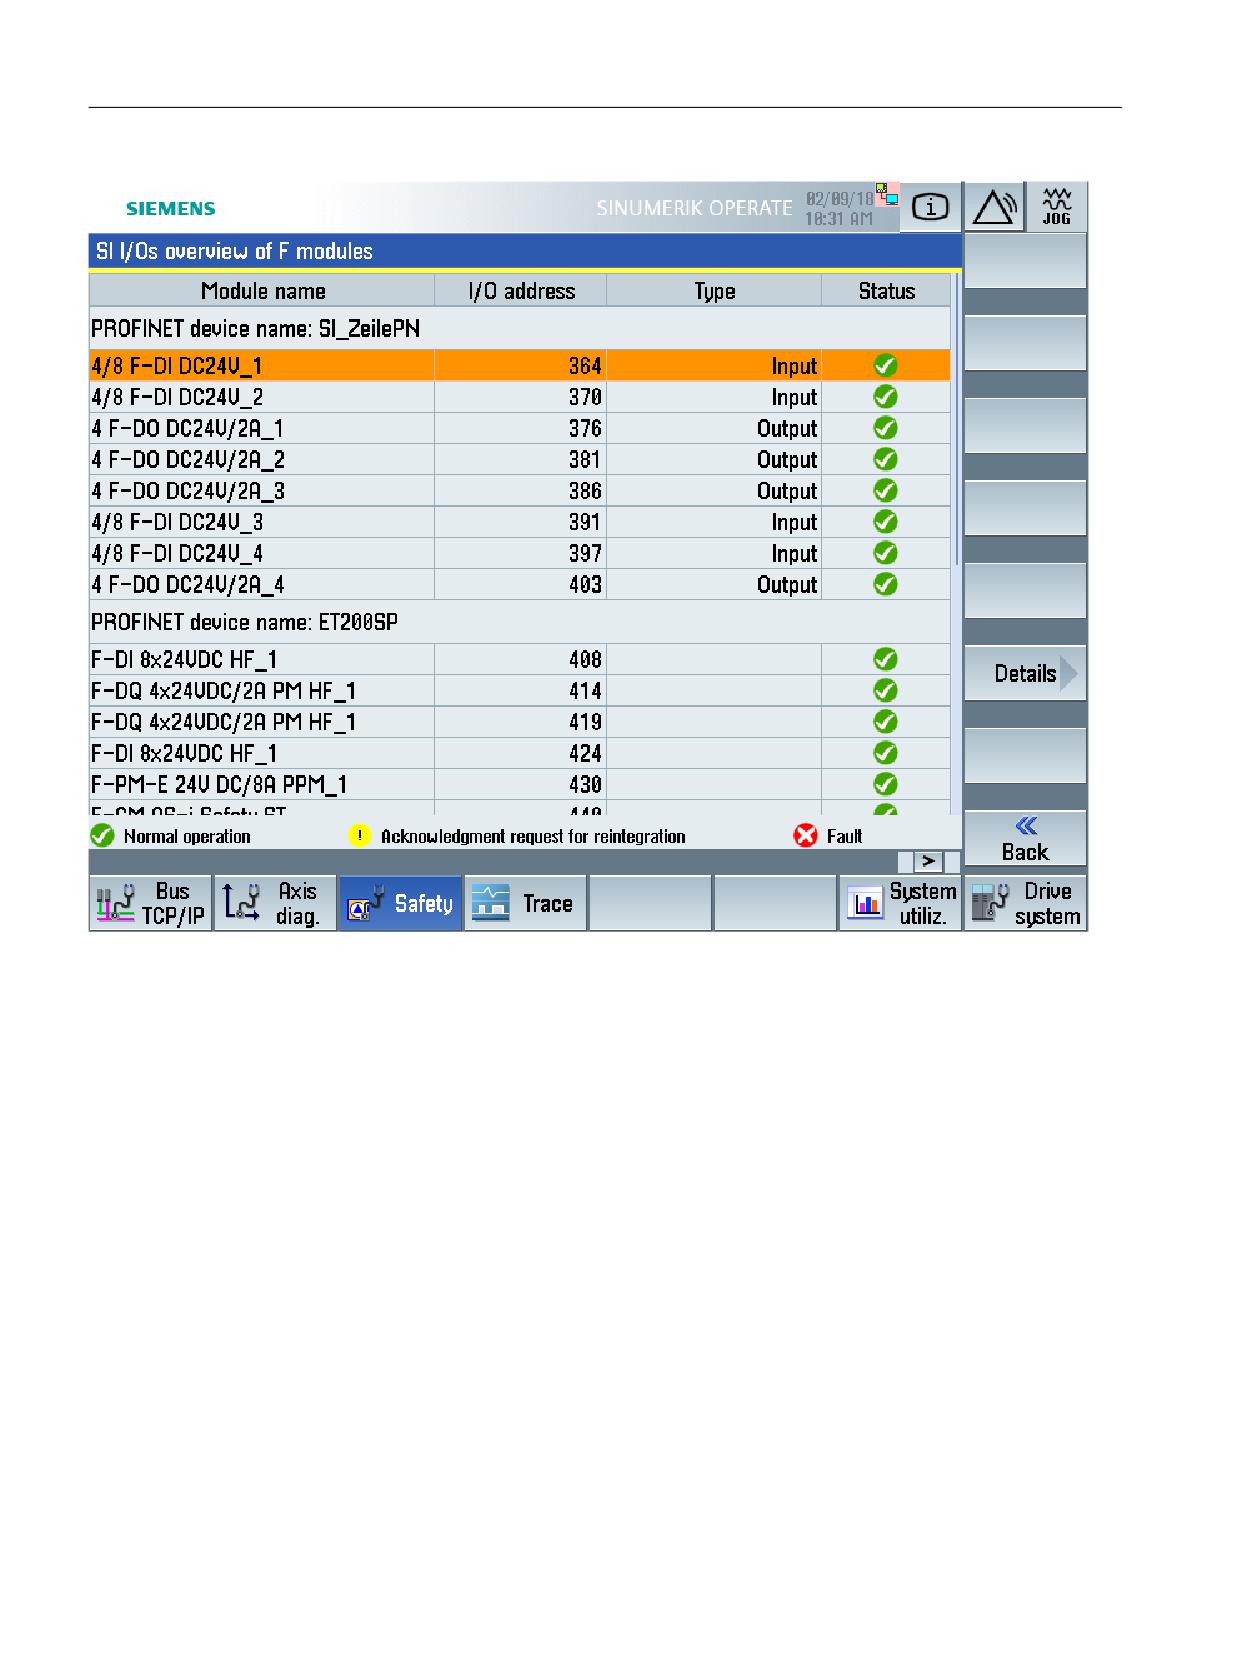
The configured F-I/O is displayed in the "SI I/O overview F-modules " diagnostic screen.
Call
MENU SELECT > Diagnostics > Menu forward key > Safety > SI I/O
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
311
Diagnostics
8.3 Diagnostic functions in SINUMERIK Operate
Figure 8-12
"SI I/O overview F-modules" diagnostics screen (sample screenshot).
With the "Details" softkey, you can display additional information about the selected module.
Safety Integrated plus
312
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Diagnostics
8.4 General information about displaying and evaluating diagnostic information
8.4
General information about displaying and evaluating diagnostic
information
In operating mode Safety Integrated plus, safety-relevant monitoring functions are executed in
the drive itself. Diagnostic information is communicated and evaluated as follows:
● The status and control information (SIC/SCC) (Page 205) of the drive is communicated
between the integrated subcomponents of the NCU:
- As a consequence, the motion control in the NC is also linked (Page 321) to the safety
functions integrated in the drive, therefore avoiding unnecessary follow-on responses in
the NC.
- Some SIC status information is also saved to NC variables (OPI) (Page 343).
● SINAMICS Safety Integrated messages and alarms can be displayed as follows:
- Safety messages of the drive are displayed in SINUMERIK Operate in the alarm lists.
Note
Information for those switching over from a different system: Evaluating alarms using the
NC
As Safety Integrated plus uses the safety functions integrated in the drive, the NC does
not suppress alarms, prioritize alarms or check alarm numbers of safety messages of the
drive (contrary to the Safety Integrated operating mode).
- The standard alarm of a drive can also include safety-relevant diagnostic information. In
order that these are displayed in SINUMERIK Operate, you must activate the alarm
buffer (Page 325).
- Display and acknowledgment (Page 327) of messages depend on the scope of the
Safety Integrated Functions (Page 25) used - and the use of the safety message buffer
(Page 324).
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
313
Diagnostics
8.5 Checksums
8.5
Checksums
Based on Safety Integrated checksums and signatures, you can compare the actual state of the
machine with the original state when delivered, which is documented in the acceptance report.
The checksums are displayed in SINUMERIK Operate in the Diagnostics area (Page 306).
● The individual F-blocks have signatures, and the safety program has an F-collective
signature. These checksums for the safety program are displayed in the TIA Portal as well
as in the safety printout.
● There are SINAMICS parameters with reference checksums (defined when commissioning)
- and actual checksums for CU, MM and motion monitoring functions, which are checked by
SINAMICS Safety Integrated when the system runs up. SINAMICS alarms 201650/230650
and/or 201680/230680 are output if the checksums differ.
See: SINAMICS checksums (Page 316)
● In SINUMERIK Operate, additional master checksums and global checksums are
displayed, which are calculated from the actual checksums listed above. The NCU does not
compare these higher-level checksums with reference checksums - and it does not save
them.
See: Calculating the global checksums/master checksums (Page 314)
The global checksums/master checksums are displayed in the diagnostics area of
SINUMERIK Operate, which means that it is easy to identify differences between the actual
and reference states.
See: SI checksums (Page 306)
8.5.1
Calculating the global checksums/master checksums
In addition to the checksums or signatures of the subcomponents SINAMICS Safety Integrated
and F-PLC, in SINUMERIK Operate global checksums and master checksums are displayed,
which are calculated from various actual checksums from the F-PLC and SINAMICS Safety
Integrated. The NCU does not compare these higher-level actual checksums with reference
checksums - and it does not save them.
By displaying these higher-level actual checksums, differences between the actual and
reference states can be easily and transparently identified.
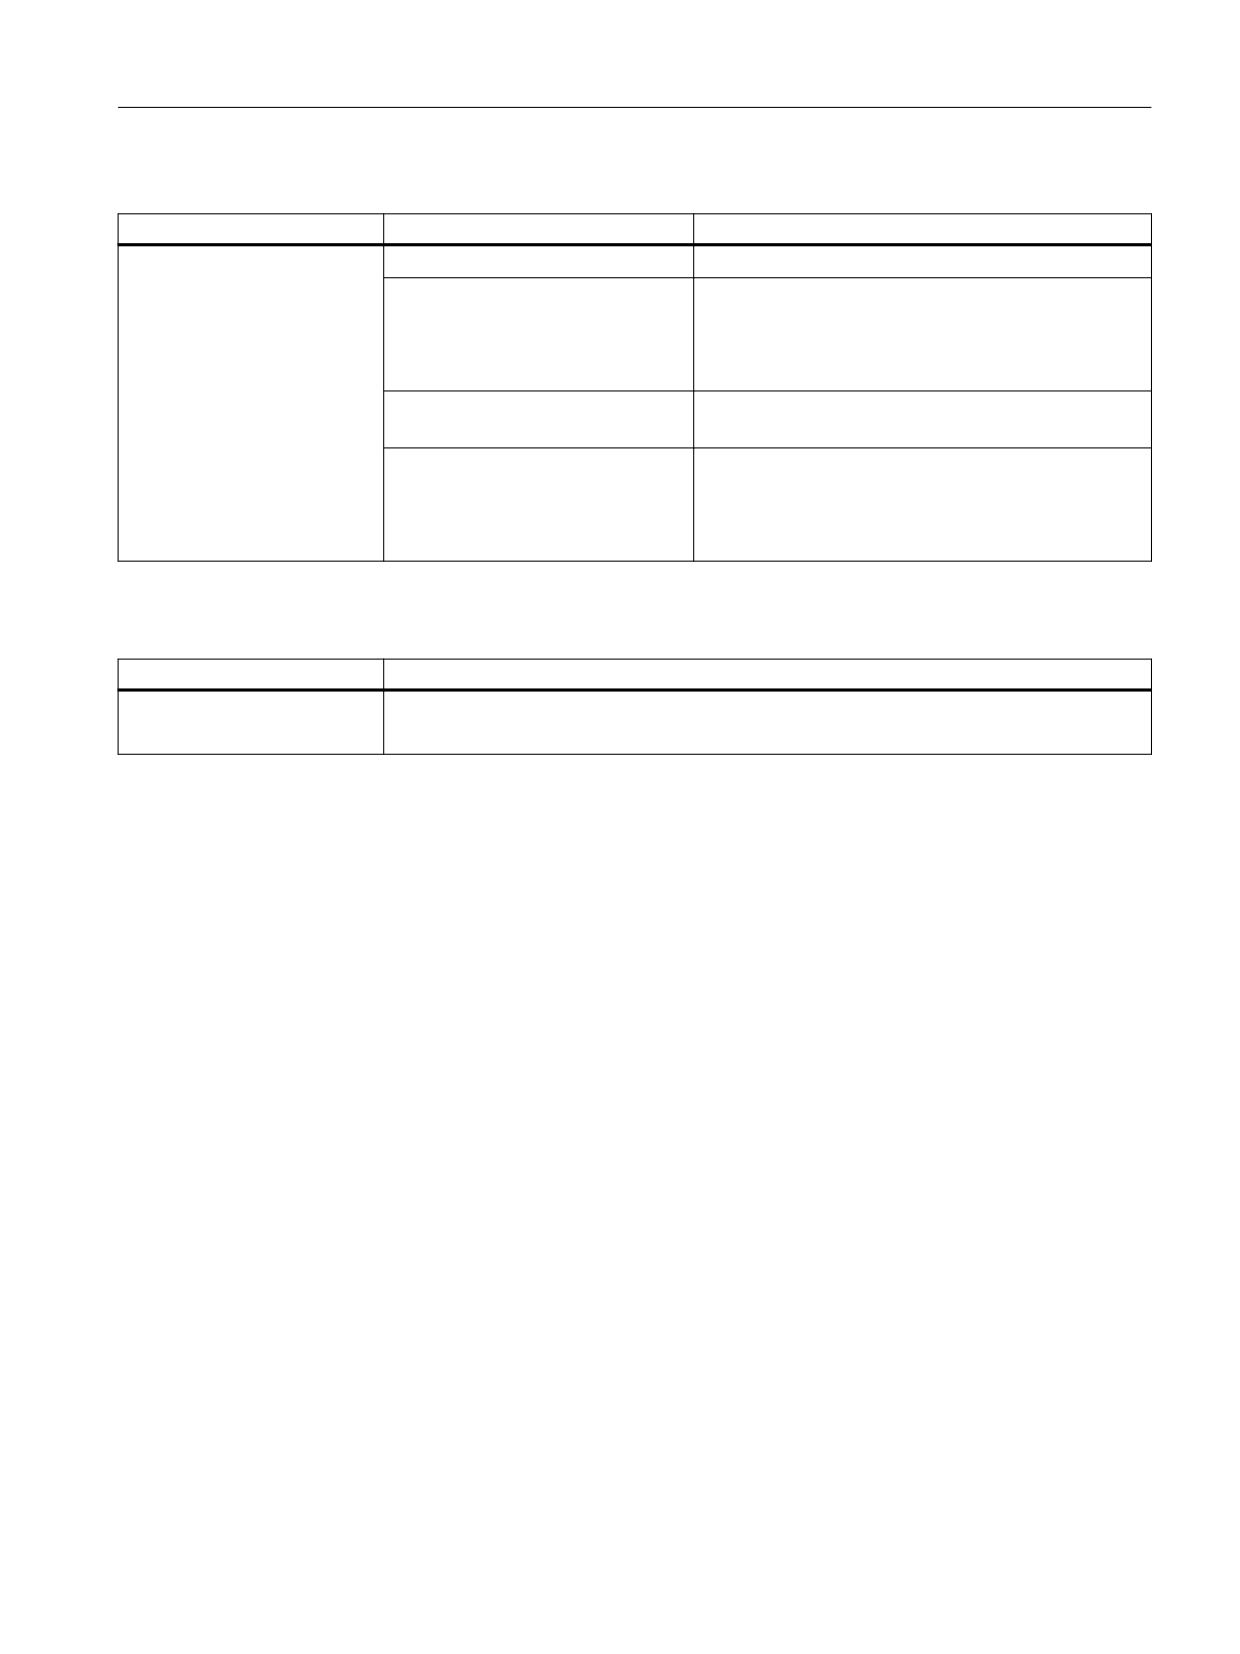
The global checksums/master checksums are calculated as follows:
● The global checksum is the sum of the associated master checksums (see table).
● The master checksums comprise the sums of the values/parameters with actual checksums
for the calculation (see table).
If SINAMICS parameters are involved for the values being used as basis, then when making
the calculation, the sum over the following drives is generated:
- Drives, which do not have an assigned NC axis, and where the safety functions are
enabled in p9601: p9601 SI enable functions integrated in the drive (Control Unit) / SI
enable fct CU ! = 0
Safety Integrated plus
314
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Diagnostics
8.5 Checksums
Table 8-6
Calculating the global checksum and the associated master checksums
Global checksum
Master checksum
Values/parameters used for the calculation
Global safety engineering
F-CPU master checksum
● Signature of the safety program
checksum
Extended Safety master checksum
● r9728[0] SI Motion actual checksum SI parame-
(sum of all master checksums)
ters / SI Mtn act CRC
● r9728[1] SI Motion actual checksum SI parame-
ters / SI Mtn act CRC
Extended Safety MM master check-
● r9398[0] SI Motion actual checksum SI parameters
sum
(Motor Modules) / SI Mtn act CRC MM
Drive-based master checksum
● r9798 SI actual checksum SI parameters (Control
Unit) / SI act_checksum CU
● r9898 SI actual checksum SI parameters (Motor
Module) / SI act_checksum MM
Table 8-7
Calculating the master checksum "safety-relevant hardware checksum"
Master checksum
Parameters used for the calculation
Safety-relevant hardware
● r9728[2] SI Motion actual checksum SI parameters / SI Mtn act CRC
checksum
● r9398[1] SI Motion actual checksum SI parameters (Motor Modules) / SI Mtn act CRC MM
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
315
Diagnostics
8.5 Checksums
8.5.2
SINAMICS checksums
For each monitoring channel, the safety parameters include 2 parameters for the reference and
actual checksum.
During commissioning, the actual checksum must be transferred to the corresponding
parameter for the reference checksum. This can be done for all checksums of a drive object at
the same time using parameter p9701 - or using the corresponding SINUMERIK Operate
functionality.
● Basic Functions
● r9798
SI actual checksum SI parameters (Control Unit)
● p9799
SI reference checksum SI parameters (Control Unit)
● r9898
SI actual checksum SI parameters (Motor Module)
● p9899
SI reference checksum SI parameters (Motor Module)
● Extended Functions (contain also the following checksum parameters)
● r9398[0...1]
SI Motion actual checksum SI parameters (Motor Module)
● p9399[0...1]
SI Motion reference checksum SI parameters (Motor Module)
● r9728[0...2]
SI Motion actual checksum SI parameters
● p9729[0...2]
SI Motion reference checksum SI parameters
During each ramp-up procedure, the actual checksum is calculated via the Safety parameters
and then compared with the reference checksum.
If the actual and reference checksums are different, fault F01650/F30650 or F01680/F30680 is
output.
Safety Integrated plus
316
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Diagnostics
8.6 Stop responses
8.6
Stop responses
8.6.1
Overview
The stop responses that can be initiated depend on the scope of the Safety Integrated
Functions used:
● Stop responses that can be initiated for faults involving Safety Integrated Basic Functions
(Page 317)
● Stop responses that can be initiated for faults involving Safety Integrated Extended
Functions (Page 319)
Stop responses and safety functions can be dependent on a priority that has been assigned:
● No overall priority is assigned to individual safety functions.
● The various stop responses each have a certain priority (Page 322).
● For stop responses and Safety Integrated Extended Functions, there are
some dependencies regarding the priority (Page 322).
The motion control in the NC is linked (Page 321) to the safety functions integrated in the drive
and the associated stop responses, which means that no unnecessary follow-on responses are
initiated in the NC.
8.6.2
Basic Functions
When faults associated with Safety Integrated Basic Functions occur, the following stop
responses can be initiated:
Table 8-8
Stop responses for Safety Integrated Basic Functions
Stop response
Triggered ...
Action
Effect
STOP A cannot
For all Safety faults with pulse
Trigger safe pulse suppression
The motor coasts to a standstill or is
be acknowl-
suppression that cannot be ac-
via the switch-off signal path for
braked by the holding brake.
edged
knowledged.
the relevant monitoring channel.
During operation with SBC:
STOP A
For all acknowledgeable Safety
Apply motor holding brake.
faults
As a follow-up reaction of STOP
F
STOP A corresponds to Stop Category 0 in accordance with EN 60204-1.
With STOP A, the motor is switched directly to zero torque via the "Safe Torque Off (STO)" function.
A motor at standstill cannot be started again accidentally.
A moving motor coasts to standstill. This can be prevented by using external braking mechanisms, e.g.
holding or operating brake.
When STOP A is present, "Safe Torque Off" (STO) is active.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
317
Diagnostics
8.6 Stop responses
Stop response
Triggered ...
Action
Effect
STOP F
If an error occurs in the cross-
Transition to STOP A.
Follow-up response STOP A
wise data comparison.
with adjustable delay (factory setting
without delay) if one of the safety
functions is selected
STOP F is permanently assigned to the crosswise data comparison (CDC). In this way, errors are detected
in the monitoring channels.
After STOP F, STOP A is triggered.
When STOP A is present, "Safe Torque Off" (STO) is active.
WARNING
Uncontrolled axis motion when a STOP A/F is initiated
With a vertical axis or pulling load, there is a risk of uncontrolled axis movements when STOP
A/F is triggered. If present in the hazardous area, this can result in death or severe injury.
● Use the "Safe Brake Control (SBC)" and a holding brake (not a safety-relevant brake!) with
sufficient holding force to prevent these movements.
Safety Integrated plus
318
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Diagnostics
8.6 Stop responses
8.6.3
Extended Functions
Faults involving Safety Integrated Extended Functions and violation of limits can trigger the
following stop responses:
Table 8-9
Stop responses for Safety Integrated Extended Functions
Stop response
Triggered ...
Response of the initiating axis
Response of other axes or NC re-
or DRV response
sponse
STOP A1)
● For all acknowledgeable
Immediate pulse suppression
All path axes: IPO rapid stop
(corresponds to
safety faults with pulse
All axes, with the exception of the
STO2))
suppression
path axes and the initiating axis:
Effect:
Braking along a ramp (acceleration
● Subsequent response of
Drive coasts down
limit)
STOP B
● Configurable subsequent
stop p9563 for SLS
● Configurable subsequent
stop p9566 for SDI
● Configurable subsequent
stop p9562 for SLP
STOP B1)
Examples:
Immediate input of speed set-
All path axes: IPO rapid stop
(corresponds to
point = 0 and start of timer tB .
● Standstill tolerance viola-
All axes, with the exception of the
SS13))
Once tB or nact < nshutdown has ex-
ted in p9530 (SOS)
path axes and the initiating axis:
pired, STOP A is triggered.
Braking along a ramp (acceleration
● Configurable subsequent
limit)
stop p9563 for SLS
Effect:
● Configurable subsequent
STOP B with subsequent
stop p9566 for SDI
STOP A.
● Configurable subsequent
The drive decelerates along
stop p9562 for SLP
the OFF3 ramp and then
● Subsequent response of
switches to STOP A.
STOP F
Note:
For "SS1 with external stop"
(SS1E), braking is not along
the OFF3 ramp (see
Section SS1 (Extended Func-
tions) with external stop
(Page 89))
STOP C1)
● Configurable subsequent
Immediate input of speed set-
All path axes: IPO rapid stop
(corresponds to
stop p9563 for SLS
point = 0 and start of timer tC.
All axes, with the exception of the
SS24))
● Configurable subsequent
Once tC has elapsed, SOS is
path axes and the initiating axis:
selected.
Braking along a ramp (acceleration
stop p9566 for SDI
limit)
● Configurable subsequent
stop p9562 for SLP
Effect:
The drive decelerates along
the OFF3 ramp; SOS is then
selected.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
319
Diagnostics
8.6 Stop responses
Stop response
Triggered ...
Response of the initiating axis
Response of other axes or NC re-
or DRV response
sponse
STOP D1)
● Configurable subsequent
Timer tD is started.
Braking along the path (interpolatory
stop p9563 for SLS
No drive-integrated response,
braking)
but an NC response (see right).
● Configurable subsequent
stop p9566 for SDI
Once tD has elapsed, SOS is
selected.
● Configurable subsequent
An automatic response is only
stop p9562 for SLP
triggered if the standstill toler-
ance window is violated in
SOS.
STOP E1)
● Configurable subsequent
SOS triggered after the expiry
Fast retraction (ESR), which allows
stop p9563 for SLS
of p9554
the controlled axes to be retracted
● Configurable subsequent
stop p9566 for SDI
Effect:
● Configurable subsequent
Controlling the drive-integra-
stop p9562 for SLP
ted ESR functionality
STOP F1)
If an error occurs in the cross-
Timer tF1 (Basic Functions) or
NC start/traversing interlock
wise data comparison.
tF2 (Extended Functions)
Follow-up response STOP B
No drive response
or STOP A
Effect:
If a safety function (SOS, SLS)
has been selected or if SSM
with hysteresis has been ena-
bled, transition to STOP A after
tF1 (Basic Functions) has
elapsed or STOP B after tF2
(Extended Functions) has
elapsed.
1)
See also the following note "delayed pulse cancellation when the bus fails".
2)
The behavior of the drive after STOP A is triggered corresponds (apart from the safety messages ) to the behavior after STO
is triggered. Note that the parameterization of STO applies equally for STOP A.
3)
The behavior of the drive after STOP B is triggered corresponds (apart from the safety messages ) to the behavior after SS1
is triggered. Monitoring with the aid of SAM or SBR, for example, works in exactly the same way. Note that the
parameterization of SS1 applies equally for STOP B.
4)
The behavior of the drive after STOP C is triggered corresponds (apart from the safety messages ) to the behavior after SS2
is triggered. Monitoring with the aid of SAM, for example, works in exactly the same way. Note that the parameterization of
SS2 applies equally for STOP C.
Safety Integrated plus
320
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Diagnostics
8.6 Stop responses
Note
Delayed pulse cancellation when the bus fails
For SLS and SDI, the stop responses are also available with delayed pulse cancellation when
the bus fails (in order that the drive does not immediately respond with pulse cancellation when
a communication error occurs):
● If p9580 ≠ 0 and SLS is active, in the event of communication failure, the parameterized ESR
reaction is only realized if, as SLS response, a STOP with delayed pulse cancellation when
the bus fails has been parameterized (p9563[0...3] ≥ 10).
● If p9580 ≠ 0 and SDI is active, in the event of communication failure, the parameterized ESR
reaction is only realized if, as SDI response, a STOP with delayed pulse cancellation when
the bus fails has been parameterized (p9566[0...3] ≥ 10).
● If p9580 ≠ 0 and SLP is active, in the event of communication failure, the parameterized ESR
reaction is only realized if, as SLP response, a STOP with delayed pulse cancellation when
the bus fails has been parameterized (p9566[0...3] ≥ 10).
The delay time (p9580) must not exceed 800 ms.
Note
Delay time between STOP F and STOP B
A delay time between STOP F and STOP B should only be set if an additional response is
initiated during this time when the "Internal Event" (r9722.7) message signal is evaluated.
Further, when using the delay time, a monitoring function should always be selected (e.g. SLS
with a high limit speed) or the hysteresis of SSM should be configured.
When hysteresis is activated for SSM, then this should be considered to be an activated
monitoring function.
On delays at the transition of the stop responses
● tB: p9556
● tC: p9552
● tD: p9553
● tF1: p9658
● tF2: p9555
● nshutdown: p9560
8.6.4
Connection and effects in the NC
The motion control in the NC is linked to the safety functions in the drive via the SIC status
signals. This avoids that subsequent responses are initiated in the NC as a result of safety stops
in the drive.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
321
Diagnostics
8.6 Stop responses
Example: The motion control in the NC responds to the drive STOP response by no longer
issuing additional setpoints for the path, for example. As a consequence, alarms to be
acknowledged are avoided, such as "Contour monitoring" or "Positioning monitoring".
The corresponding status bits from S_ZSW1 (or S_ZSW1B) are used to emulate the safety stop
responses in the NC.
See also
Safety Info Channel and Safety Control Channel (SIC/SCC) (Page 205)
8.6.5
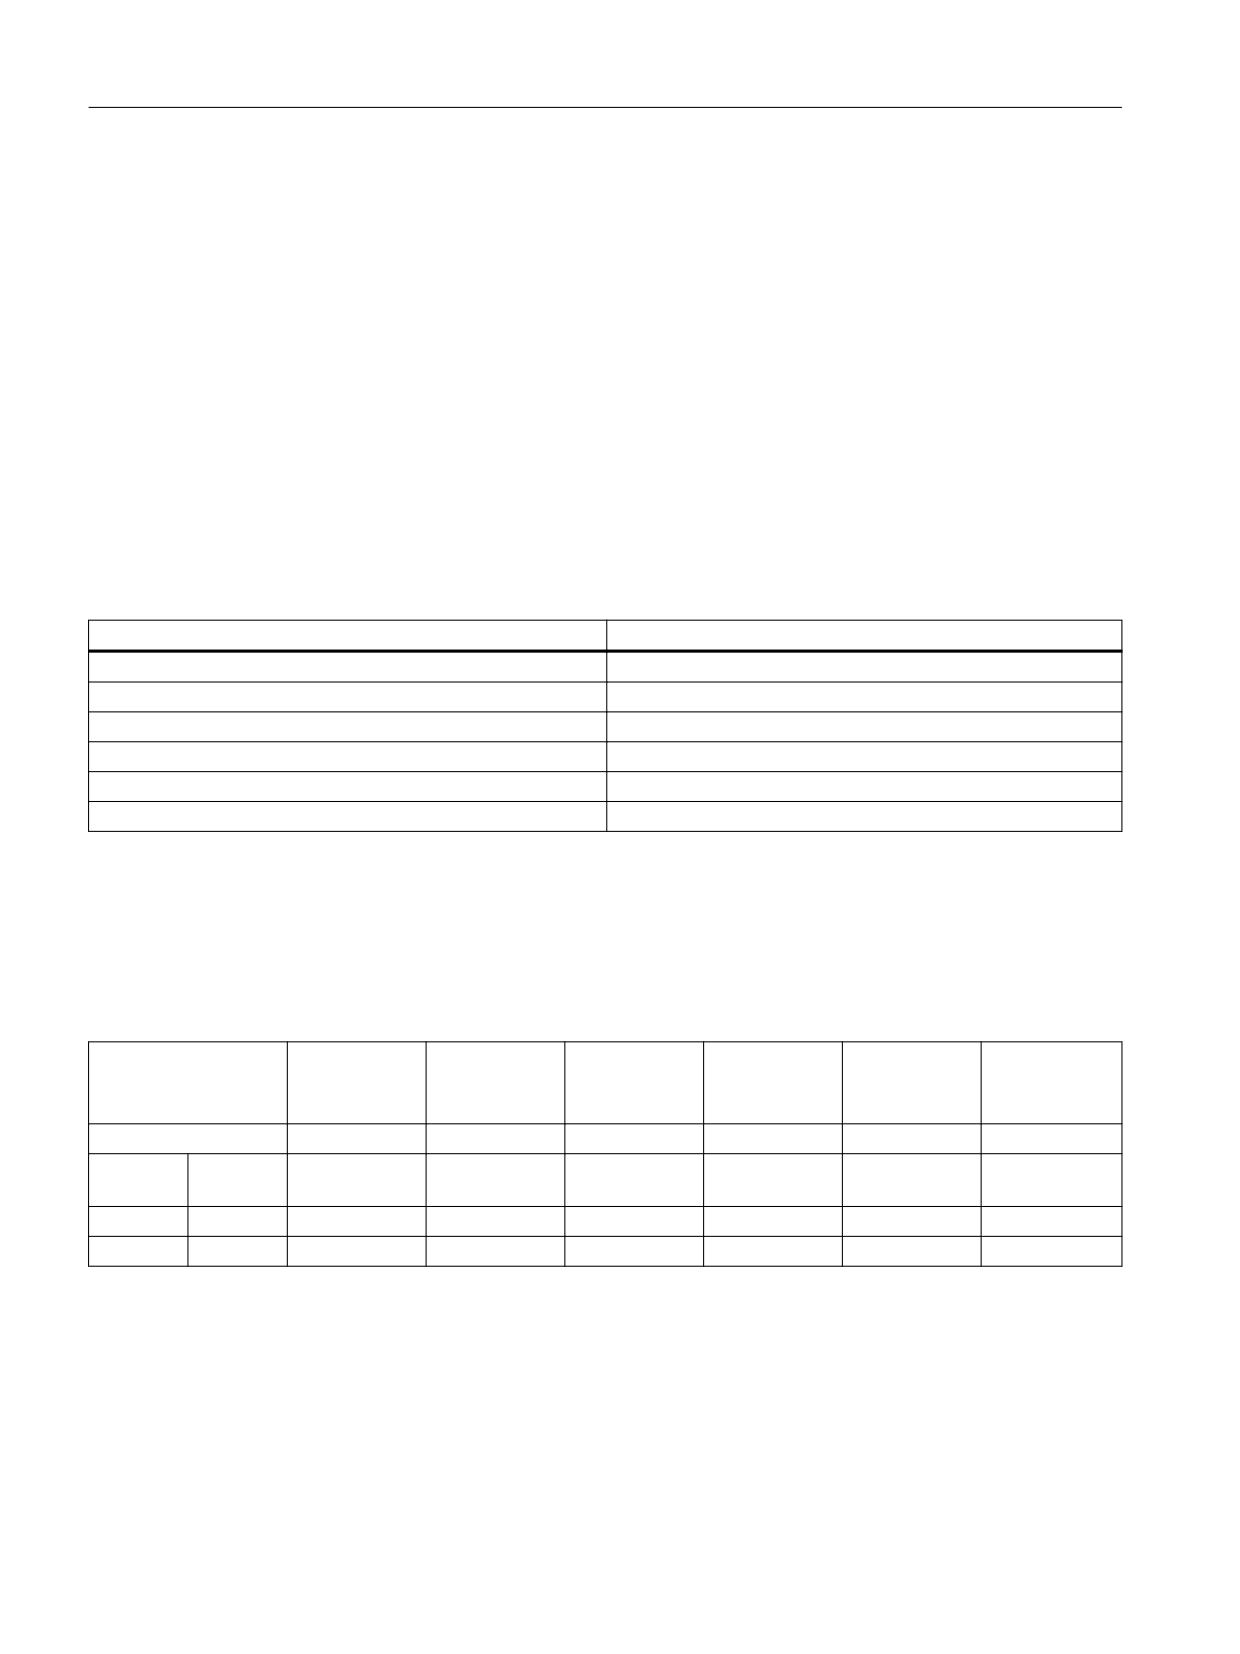
Priorities
Table 8-10
Priorities of the stop responses
Priority classes
Stop response
Highest priority
STOP A
STOP B
STOP C
STOP D
STOP E
Lowest priority
STOP F
Priorities between stop responses and Extended Functions
The following table lists which stop response or safety function is set if a STOP is initiated when
a safety function is active.
Table 8-11
Priorities between stop responses and Extended Functions
Highest
Lowest
priority
priority
Stop response/
Extended Function
STOP A
STOP B
STOP C
STOP D
STOP E
STOP F
Highest
STO
STOP A / STO
STO
STO
STO
STO
STO
priority
SS1
STOP A
STOP B / SS1
SS1
SS1
SS1
SS1
SS2
STOP A
STOP B
STOP C / SS2
SS2
SS2
SS2 / STOP B2)
Safety Integrated plus
322
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Diagnostics
8.6 Stop responses
SOS
STOP A1)
STOP B1)
SOS
SOS
STOP E/SOS
STOP B2)
Lowest
SLS
STOP A3)
STOP B3)
STOP C4)
STOP D4)
STOP E4)
STOP B2)
priority
1)
The SOS monitoring function remains active, although the fault response in the event of a fault can no longer be triggered
because it is already present.
2)
STOP B is the subsequent stop of STOP F, which is activated after a parameterizable time. STOP F alone does not have
any effect; the active safety function is still present.
3)
The SLS monitoring function remains active, although the fault response in the event of a fault can no longer be triggered
because it is already present.
4)
SLS remains active during the braking phase, after which the system switches to SOS.
Explanation of the table
No overall priority is assigned in the individual safety functions. SOS remains active, for
example, even if STO is requested.
● The safety functions that cause the drive to decelerate (SS1, SS2) are specified from top to
bottom in descending order of priority.
● The stop responses arranged here from left to right in descending order of priority (STOP A-
F).
If a field contains two entries, the stop responses and safety functions have the same priority.
● STOP A corresponds to selecting STO
● STOP B corresponds to selecting SS1
● STOP C corresponds to selecting SS2
● STOP D corresponds to selecting SOS
● STOP E corresponds to selecting SOS (for additional activation of the standard "Extended
stop and retract (ESR)" function)
● When the SS2 function is active, STOP F results in follow-up stop B. SS2 remains active.
Examples for illustrating the information in the table:
1. Safety function SS1 has just been selected. STOP A remains selected.
2. By selecting a STOP with a higher priority, STOPs that are present with a lower priority will
be replaced. This means that when SS1 is selected (≙ STOP B), any STOPs C-F that are
present will be replaced.
3. The SLS safety function is selected. This selection does not modify the function of STOP A-
D. A STOP F now triggers a STOP B because a safety function has been activated.
4. Stop response, STOP C is selected. If the STO or SS1 safety functions are active, this does
not have any effect. If SS2 is active, this brake ramp is retained. If SOS is active, SOS
remains effective, which is also the end status of STOP C. When SLS is selected, the drive
is decelerated with STOP C.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
323
Diagnostics
8.7 Using the fault buffer and safety message buffer
8.7
Using the fault buffer and safety message buffer
In addition to the standard fault buffer and the standard alarm buffer, SINAMICS Safety
Integrated has its own safety message buffer for safety-related messages for Safety Integrated
Extended Functions:
● Messages for Extended Functions are displayed in the safety message buffer.
● You must enable SIC/SCC for the appropriate axes in MD39750.
● For all messages in the safety message buffer, a specific reference is made in the HMI
to the fact that safety-relevant acknowledgment (Page 327) is required.
- In SINUMERIK Operate, in the "Safety Integrated diagnostics overview", reference
is made to active safety-relevant alarms (in addition to the standard alarm list).
- A safety delete symbol makes reference to active alarms that require a safety-rel-
evant acknowledgment.
● To acknowledge messages in the safety message buffer, safety-relevant acknowl-
edgment is required - and possibly also acknowledgment with PROFIdrive RESET
(Page 328).
● Messages for Basic Functions or for external drives without an NC axis assignment,
cannot be saved to the safety message buffer.
● When using external drives without NC axis assignment, then you must deactivate the
safety message buffer (Page 325).
● The response when saving safety-relevant messages relating to Basic Functions cor-
responds to the response for a deactivated safety message buffer (see below).
● If the safety message buffer is deactivated, then safety-relevant messages are saved in
the standard fault and/or alarm buffer.
● For safety-related messages in the fault and alarm buffer, in SINUMERIK Operate,
specific reference is not made to the safety-relevant acknowledgment required.
In SINUMERIK Operate, safety-relevant alarms are displayed in the standardalarm list
("MENU SELECT > Diagnostics > Alarms") - however, they require safety-relevant
acknowledgment.
● The messages require additional acknowledgment: For an entry in the fault buffer, in
addition alarm 25201 ("Drive fault") is output, and the drive message requires a safety-
relevant acknowledgment as well as also an acknowledgment via PROFIdrive
(Page 329).
Safety Integrated plus
324
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Diagnostics
8.8 Configuring the message buffer and alarm buffer
8.8
Configuring the message buffer and alarm buffer
8.8.1
Configuring the standard alarm buffer
The standard alarm buffer is automatically activated when you configure the safety mode.
This alarm buffer is required for safety-related standard warnings (Axxxx).
The display of safety-related standard warnings cannot be activated independently of the
display of other standard warnings.
The activation is entered in the following machine data:
● MD13150 $MN_SINAMICS_ALARM_MASK
- "bit 2: output faults of the drive controls"
- "bit 10: output alarms of the drive controls"
Alarms/warnings have to be evaluated.
Optionally, you can set additional bits in order to output faults or alarms of other DO groups.
8.8.2
Configuring the safety alarm buffer
The safety message buffer is activated in the factory setting, and is used for issuing safety-
relevant messages from Extended Functions.
In certain situations it can make sense to also deactivate the safety message buffer for
Extended Functions. This means that messages associated with Basic Functions and
Extended Functions can be saved in the fault and/or alarm buffer (e.g. if you are predominantly
using Basic Functions).
The setting to activate/deactivate the safety message buffer is a CU parameter (p3117). This
cannot be set for specific drives or axes - it is always applicable for all drives or axes of this CU.
The following drive parameter is relevant:
● p3117 Change safety message type / Ch SI mess type
Setting to re-parameterize all safety messages to faults and alarms.
Precondition
● Settings for drive parameters are protected with access level 2 (service).
Procedure
Proceed as follows to deactivate or activate the safety message buffer:
1. In SINUMERIK Operate, call the drive parameters using "MENU SELECT > Commissioning
> Machine data > Control Unit parameters".
2. Activate the CU commissioning state "Device configuration" with "p0009 = 1".
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
325
Diagnostics
8.8 Configuring the message buffer and alarm buffer
3. Set the required value in drive parameter p3117 Change safety message type / Ch SI mess
type:
- p3117 = 0: Safety messages of this CU are not reparameterized; this means that
messages associated with Extended Functions are entered in the safety message buffer.
- p3117 = 1: All safety messages of this CU are reparameterized, and entered in the
standard fault or alarm buffer.
4. Deactivate the CU commissioning state "Device configuration" with "p0009 = 0".
5. Confirm the setting with "Save/reset> Menu forward key> Reset (po)".
Safety Integrated plus
326
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Diagnostics
8.9 Acknowledgment
8.9
Acknowledgment
8.9.1
Overview
Most safety messages require safety-relevant acknowledgment.
Safety-relevant acknowledgment involves deleting safety-relevant messages of the drive-
integrated monitoring functions via safety-relevant communication. With the safety-related
acknowledgment, the fault case in the drive is marked as having been resolved (gone).
Safety-relevant acknowledgment is independent of the scope of the Safety Functions used
(Basic or Extended) - and is required in addition to actually removing the cause of the fault.
Depending on the drive type, different types of acknowledgment and/or safety-relevant
acknowledgment are possible:
Table 8-12
Permissible acknowledgment types for various drive types
Drive type
Permissible acknowledgment
Integrated drives
● Safety-relevant acknowledgment using PROFIsafe signal "IEACK"
(CU_I, CU_NX)
(Page 328)
● Acknowledgment by switching-off/switching-on (Page 329)
External NC drives
● Safety-relevant acknowledgment using PROFIsafe signal "IEACK"
(Page 328)
● Acknowledgment by deselecting STO or SS1 (Page 329)
● Acknowledgment by switching-off/switching-on (Page 329)
External SINAMICS drives
The safety message buffer is not supported and must be deactivated
without any assignment to an
(Page 325).
NC axis
The acknowledgment options correspond to those of external NC
drives (see above).
Depending on what has been configured, additional acknowledgments may be necessary:
● If you are using Basic Functions, or the safety message buffer is deactivated (p3117=1),
then you must additionally acknowledge (Page 329) all safety messages that are saved in
the standard fault buffer using a PROFIdrive RESET.
● In addition to a safety-relevant acknowledgment, various fault situations also require
an acknowledgment using a PROFIdrive RESET (Page 328).
WARNING
Unexpected restart for safety-related acknowledgment without MCP reset!
If a STOP response is acknowledged in a safety-related fashion by the machine operator, but
without PROFIdrive RESET acknowledgment, then the part program is not canceled and is
continued with the acknowledgment. When the machine restarts unexpectedly, this can put
people in dangerous situations or cause material damage.
● In the safety program logically combine safe acknowledgment (PROFIsafe IEACK) with a
RESET at the machine control panel (PROFIdrive RESET).
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
327
Diagnostics
8.9 Acknowledgment
8.9.2
Acknowledgment via PROFIsafe
You program a PROFIsafe acknowledgment in the safety program of the F-PLC by setting
signal "Internal Event ACK" separately for each drive object using the PROFIsafe telegram
(STW bit 7).
Faults in the drive objects (DOs) cannot be acknowledged by the F-PLC in the line-up, but must
instead be acknowledged separately for each individual drive object. A falling edge of the
"Internal Event ACK" signal resets the status "Internal Event" in the particular drive, and thus
acknowledges the fault.
8.9.3
Additional acknowledgment via PROFIdrive RESET
WARNING
Unexpected restart for safety-related acknowledgment without MCP reset!
If a STOP response is acknowledged in a safety-related fashion by the machine operator, but
without PROFIdrive RESET acknowledgment, then the part program is not canceled and is
continued with the acknowledgment. When the machine restarts unexpectedly, this can put
people in dangerous situations or cause material damage.
● In the safety program logically combine safe acknowledgment (PROFIsafe IEACK) with a
RESET at the machine control panel (PROFIdrive RESET).
In addition to a safety-relevant acknowledgment, various fault situations also require an
acknowledgment using a PROFIdrive RESET.
This applies to the following STOP responses or safety functions:
● Extended Safety Functions:
- All fault situations - or safety functions and STOP responses
● Basic Functions or inactive safety message buffer:
- Parameterizing SLS with STOP D or STOP E
If, in the case of a fault, the safety-relevant acknowledgment is realized without PROFIdrive
RESET, then although the part program remains in the stop state, the spindle continues to
operate.
A configuration such as this is not in conformance with standard IEC 61800-5-2. According to
the standard, a restart inhibit is mandatory for all STOP functions, and it is only permissible that
the spindle starts again after a RESET.
1. Therefore, in the safety program logically combine safe acknowledgment (PROFIsafe
IEACK) with a RESET at the machine control panel (PROFIdrive RESET).
2. This means that you should configure the machine control panel RESET (MCP reset or
channel/MODE GROUP RESET) so that when actuated, a PROFIdrive RESET as well as
a safety-relevant acknowledgment (e.g. PROFIsafe IEACK) are initiated.
Safety Integrated plus
328
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Diagnostics
8.9 Acknowledgment
8.9.4
Acknowledgment using POWER ON
Safety faults can also be acknowledged (as with all other faults) by switching the drive unit off
and then on again (POWER ON).
If this action has not eliminated the fault cause, the fault is displayed again immediately after
power-up.
8.9.5
Extended acknowledgment (deselecting STO/SS1)
For external drives, the extended alarm acknowledgment can be used as alternative to safety-
relevant acknowledgment. To do this, the extended alarm acknowledgment must be activated
in the safety configuration of the drive.
Extended alarm acknowledgment is not supported for integrated drives.
Basic procedure
If STO or SS1 is selected/deselected - and if p9507.0 is set = 1 - then the safety messages are
automatically withdrawn.
● Remove the cause of the fault.
● Deselect "Safe Torque Off" (STO) or "Safe Stop 1" (SS1).
● Acknowledge the fault.
If, in addition to the "Basic Functions via terminals", the "Extended Functions" are also enabled,
then acknowledgment is also possible by selecting/deselecting STO via PROFIsafe.
If the safety commissioning mode is exited when the safety functions are switched off (p0010 ≠
95 when p9601 = 0), then all safety faults can be acknowledged.
Once safety commissioning mode has been selected again (p0010 = 95), all the faults that were
previously present reappear.
8.9.6
Additional acknowledgment when the safety message buffer is inactive
If you are using Basic Functions, or the safety message buffer is deactivated (p3117=1), then
safety messages are saved in the standard fault buffer or in the standard alarm buffer. These
messages require a safety-relevant acknowledgment, even when the safety message buffer is
deactivated.
The safety messages in the standard fault buffer require, in addition to safety-relevant
acknowledgment, also acknowledgment using PROFIdrive signal "Acknowledge faults"
(PROFIdrive RESET). For NC axes, a PROFIdrive RESET corresponds to a machine control
panel RESET.
The required PROFIdrive RESET is displayed in SINUMERIK Operate with NC alarm 025201.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
329
Diagnostics
8.9 Acknowledgment
When the safety message buffer is deactivated, the following safety messages are saved in the
fault buffer, and therefore also additionally required a PROFIdrive RESET:
Table 8-13
Saving safety-relevant messages in the the fault buffer (when the safety message buffer is
deactivated)
Alarm number
Alarm text
201689
SI Motion: Axis re-configured
201700
SI Motion P1 (CU): STOP A initiated
201701
SI Motion P1 (CU): STOP B initiated
201708
SI Motion P1 (CU): STOP C initiated
201770
SI Motion P1 (CU): Discrepancy error of the failsafe digital inputs/outputs
When the safety message buffer is deactivated, all of the safety messages listed in the table are
saved in the standard alarm buffer.
Safety Integrated plus
330
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Acceptance test with SINUMERIK Operate
9
9.1
Purpose and requirements
An acceptance test has the objective to check that the parameterization and principle of
operation of the safety functions are correct, identify potential configuring errors and to
document the correctness of the configuration.
With the acceptance test, the limit values entered for all activated safety functions must be
exceeded (violated). This allows the correct execution of the function to be checked and
verified.
WARNING
Unwanted motion due to incorrect parameter changes
Changes to safety functions that have been accepted can result in faults and undesirable
motion - and in turn in death or severe injury.
● Perform a new acceptance test as soon as changes have been made to any of the safety
functions.
● Also create an appropriate acceptance report.
Responsibility for the acceptance test
This chapter provides recommendations for the content and scope of an acceptance test. The
machine manufacturer is responsible for carrying out and documenting an acceptance test.
It is not permissible to use the results of the acceptance test for other purposes!
The measured values obtained when executing the acceptance test (e.g. distance or time) and
the system response identified (e.g. initiation of a specific stop) are used to check the
plausibility of the configured safety functions. The values that are measured are typical and are
not worst-case values. They represent the behavior of the machine at the time of measurement.
These measurements cannot be used to derive real values (e.g. maximum distances for over-
travel distances).
Acceptance test in SINUMERIK Operate
A detailed description of the acceptance test in SINUMERIK Operate is provided in Function
Manual "SINUMERIK Operate Acceptance Test" (download (https://
support.industry.siemens.com/cs/ww/en/view/109761095)).
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
331
Acceptance test with SINUMERIK Operate
9.1 Purpose and requirements
Safety Integrated plus
332
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Component replacement (software/hardware)
10
10.1
Safety instructions
WARNING
Unsafe operating state after POWER ON
After a firmware update, the system generally requests a POWER ON. After a POWER ON,
an unsafe operating state can occur - and if persons are in the hazardous area, this can result
in death or severe injury.
● After each POWER ON, perform an acceptance test and create an acceptance report.
● Do not enter the danger zone of the motor until the acceptance test has been successfully
completed.
WARNING
Unwanted motion if components are replaced without a function test
After a component replacement, connections or functions can be defective so that death or
serious injury can result if a person enters the danger zone of the motors.
● Perform a POWER ON before resuming operation.
● After component replacement, always run a simplified function test.
You can find more detailed information in the chapters "AUTOHOTSPOT" and
"Acceptance test with SINUMERIK Operate (Page 331)".
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
333
Component replacement (software/hardware)
10.2 Software, F-CPU, F-I/O
10.2
Software, F-CPU, F-I/O
Replacement of software components
When replacing software components on your programming device or PC (e.g. with a new
version of STEP 7), you must adhere to the information regarding upward and downward
compatibility in the documentation and readme files for these products.
Replacement of hardware components
Hardware components for SIMATIC Safety (F-CPU, F-I/O, batteries, etc.) are replaced in the
same way as in standard automation systems.
Removing and inserting F-I/O during operation
It is possible to remove and insert F-I/O during operation, as with standard F-I/O. However, be
aware that replacing an F-I/O module during operation can cause a communication error in the
F-CPU.
You must acknowledge communication errors in your safety program at variables ACK_REI of
the F-I/O DB - or alternatively, using instruction "ACK_GL". Without an acknowledgment, the F-
I/O will remain passivated.
CPU firmware update
Check of the CPU operating system for F-approval: When using a new CPU operating system
(firmware update), you must check to see if the CPU operating system you are using is
approved for use in an F-system.
The minimum CPU operating system versions with guaranteed F-capability are specified in the
appendix of the Certificate. This information and any notes on the new CPU operating system
must be taken into account.
Firmware update for interface module
When using a new operating system for an interface module, e.g. IM 151-1 HIGH FEATURE
ET 200S (firmware update), you must observe the following:
If you have selected the "Activate firmware after update" option for the firmware update (see
Help on STEP 7, "Online & Diagnostics"), the IM will be automatically reset following a
successful download operation and will then run on the new operating system. Note that the
firmware update for interface modules during operation generates a communication error in the
F-CPU.
You must acknowledge communication errors in your safety program at variables ACK_REI of
the F-I/O DBs - or alternatively, using instruction "ACK_GL". Without an acknowledgment, the
F-I/O will remain passivated.
Safety Integrated plus
334
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Component replacement (software/hardware)
10.2 Software, F-CPU, F-I/O
Preventive maintenance (proof test)
The probability values for the certified F-system components guarantee a proof-test interval of
20 years for ordinary configurations.
Proof test for complex electronic components generally means replacement with unused
components.
PFD, PFH values
A complete list of the probability of failure values (PFD, PFH values) for F-CPUs is provided in
the Siemens web page Industry Online Support at the following address (https://
support.industry.siemens.com/cs/ww/en/view/109481784/80883060875):
There you can find a list for the following probability of failure values:
● PFD, PFH values for F-CPUs S7-300/400 - and the proof test intervals for components that
can be used in SIMATIC Safety
● PFD, PFH values for F-CPUs S7-1200/1500 for a usage time of 20 years and for a repair
time of 100 hours. Excerpt:
Operation in low demand mode
Operation in high demand or continuous mode
low demand mode
high demand/continuous mode
According to IEC 61508:2010:
According to IEC 61508:2010:
PFDavg = Average probability of a dangerous
PFH = Average frequency of a dangerous failure
failure on demand
[h-1]
< 2E-05
< 1E-09
● PFD, PFH values for safety-relevant communication. Excerpt:
Operation in low demand mode
Operation in high demand or continuous mode
low demand mode
high demand/continuous mode
According to IEC 61508:2010:
According to IEC 61508:2010:
PFDavg = Average probability of a dangerous
PFH = Average frequency of a dangerous failure
failure on demand
[h-1]
< 1E-05
< 1E-09*
* Note on S7-300/400 F-CPUs: The value is valid under the assumption that a maximum of 100 F-I/Os
are involved in a safety function. If more than 100 F-I/Os are used, you need to add 4E-12 for each F-
I/O for this safety function.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
335
Component replacement (software/hardware)
10.3 Motors, CU (SINAMICS Safety Integrated)
10.3
Motors, CU (SINAMICS Safety Integrated)
Overview
The faulty component was replaced according to safety regulations. The information relevant
from the perspective of Safety Integrated is provided in the following. For information about
component replacements, see "Example of component replacements" in the SINAMICS S120
Function Manual Drive Functions.
● Based on the NodeID and the saved CRC of the particular hardware component, the drive
identifies that a component has been replaced. You can take the responses of the drive and
the actions that have to be carried out from the following table:
Replaced
Control type
Drive re-
User action
Diagnostic
component
sponse
parameters
Fault acknowl-
Acknowledg-
Save3)
(fault)
edgment re-
ment is re-
quired1)
quired that the
component has
been replaced2)
Basic
Control Unit
All
F01641.0 = 1
Yes
No
Yes
r9776.2 = 1
Functions Motor Module
All
F01641.1 = 1
Yes
No
Yes
r9776.2 = 1
Power Module
All
F01641.2 = 1
Yes
No
Yes
r9776.2 = 1
Safety Integrated plus
336
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Component replacement (software/hardware)
10.3 Motors, CU (SINAMICS Safety Integrated)
Replaced
Control type
Drive re-
User action
Diagnostic
component
sponse
parameters
Fault acknowl-
Acknowledg-
Save3)
(fault)
edgment re-
ment is re-
quired1)
quired that the
component has
been replaced2)
Extended
Control Unit
All
F01641.0 = 1
Yes
No
Yes
r9776.2 = 1
Functions Motor Module
PROFIsafe,
F01641.1 = 1
Yes
No
Yes
r9776.2 = 1
OnBoard F-DI,
without selec-
tion
Power Module
All
F01641.2 = 1
Yes
No
Yes
r9776.2 = 1
Sensor
All
F01641.3 = 1
Yes
No
Yes
r9776.2 = 1
Module
(CPU 1)
Sensor
All
F01640.4 = 1
Yes
Yes
Yes
r9776.2 = 1
Module
r9776.3 = 1
(CPU 2)
Encoder4)
All
F01641.5 = 1
Yes
No
Yes
r9776.2 = 1
F01641.6 = 1
1)
The fault must be acknowledged each time a component is replaced using a standard acknowledgment (e.g. using a 0/1
signal at p2103). However, even without acknowledgment the drive can still be operated.
2)
The replacement of the components listed in the table must be acknowledged in order to ensure the new internal device
communications to be established. When replacing other components, acknowledgment is not required, as the new
communications to be established are automatically ensured.
To acknowledge a component replacement, perform the following sequence on all of the drive objects involved:
- Check whether the following preconditions are fulfilled:
- p0010 = 0
- It is not permissible for a firmware update to be active on the drive object.
- Set p9702 = 29 (= 1D hex)
3)
The modified data must be saved after a component has been replaced:
- It is not permissible for a firmware update to be active on the drive object.
- Copy from RAM to ROM by setting p0977 = 1.
If the data is not saved, the fault is output again after the next POWER ON.
4)
Only for encoders with serial number (e.g. EnDat)
Replacing motors for safety without encoder
When using safety functions without encoder, the motor pole pair number plays a decisive role.
If a motor is replaced, then the behavior depends on the pole pair number: If a motor with a
higher pole pair number is used (other than that configured), the mechanical speed is less than
that calculated by Safety Integrated. If a motor with a lower pole pair number is used (e.g. when
a motor is replaced), the mechanical speed is higher than that calculated by Safety Integrated.
● After a replacement such as this, perform a test by comparing the safe actual speed (r9714)
with the normal speed (r0063 or the output frequency), and if required, correct the
configured pole pair number.
See also
Acceptance test with SINUMERIK Operate (Page 331)
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
337
Component replacement (software/hardware)
10.4 Important parameters - notes regarding component replacement
10.4
Important parameters - notes regarding component replacement
Overview of important parameters (see SINAMICS S120/S150 List Manual)
● r9670
SI module identifier Control Unit
● r9671[0...n]
SI module identifier, Motor Module
● p9672
SI module identifier, Power Module
● p9673
SI module identifier, Sensor Module channel 1
● p9674
SI module identifier, Sensor Module channel 2
● p9675
SI module identification sensor channel 1
● p9676
SI module identification sensor channel 2
● p9702
Acknowledge SI component replacement
● r9776
SI diagnostics
● r9793[0...9]
SI diagnostics component replacement
Safety Integrated plus
338
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Component replacement (software/hardware)
10.5 Messages when components are replaced after Safety Integrated has been commissioned
10.5
Messages when components are replaced after Safety Integrated has
been commissioned
Safety-relevant components are assigned a CRC checksum, which can be used to identify if
the hardware was changed:
● Replacing certain drive components after Safety Integrated has been commissioned.
● Different checksums as a result of series commissioning with Safety Integrated functionality
The appropriate messages are displayed, depending on the components involved and the
control type:
Control type
Alarm
Extended Functions via PROFIsafe
F01650 SI P1 (CU): Acceptance test required
Fault value 2005
Indicates that the Control Unit has been replaced.
A01695 SI Motion: Sensor Module has been replaced
Indicates that the Sensor Module has been replaced.
C30711 SI Motion P2: Defect in a monitoring channel
Fault value 1031
Stop response STOP F
As a consequence of A01695, a defect is signaled in a mon-
itoring channel.
Basic procedure
WARNING
Unsafe states after a component has been replaced
Non-safe states are possible after a component has been replaced. If persons are in the
danger zone, accidents causing death or severe injury can occur.
● Before re-entering the hazardous area - and before resuming operation - perform a
simplified function test for the drive affected by the component replacement (see Chapter
"Acceptance test (Page 331)").
Use the following function in SINUMERIK Operate to acknowledge a CRC checksum that
differs for one of the reasons listed above:
● Commissioning > Safety Integrated > Overview > Confirm SI hardware
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
339
Component replacement (software/hardware)
10.5 Messages when components are replaced after Safety Integrated has been commissioned
Safety Integrated plus
340
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Data descriptions
11
11.1
Machine data
Overview
Table 11-1
Machine data with settings for the Safety Integrated plus mode
Number
Symbolic name
Purpose
MD13370
$MN_SAFE_MODE
Different safety operating modes
MD36933
$MA_SAFE_DES_VELO_LIMIT
Evaluation factors to define the setpoint limits
MD36964
$MA_SAFE_IPO_STOP_GROUP
Channel-wide IPO response distribution
MD36968.2
$MA_SAFE_BRAKETEST_CONTROL, bit 2
Positioning behavior after completion of SBT
MD37950
$MA_SAFE_INFO_ENABLE
SIC/SCC and PROFIsafe enable
MD37952
$MA_PROFISAFE_MODULE_NR
Number to select a logical basis address from
MD13372
MD37954
$MA_SAFE_INFO_MODULE_NR
Number to select a logical basis address from
MD13374
Table 11-2
Machine data with I/O addresses of safety-relevant telegrams
Number
Symbolic name
Purpose
MD13372
$MN_PS_DRIVE_LOGIC_ ADDR[0..30]
I/O start address of SIEMENS telegrams 903 and
902 (PROFIsafe) of the corresponding drive object
MD13374
$MN_SAFE_INFO_DRIVE_LOGIC_ ADDR[0..30]
I/O start address of SIEMENS telegrams 701 (SIC/
SCC) of the corresponding drive object
MD13376
$MN_SAFE_INFO_TELEGRAM_ TYPE[0..30]
Telegram type that is used for SIC/SCC communi-
cation. The default value (701) corresponds to the
default in the TIA Portal configuration
MD37950
$MA_SAFE_INFO_ENABLE
Activation / deactivation of safety-related telegrams
MD37952
$MA_PROFISAFE_MODULE_NR
Number to select a logical basis address from
MD13372 $MN_SAFE_PS_DRIVE_LOGIC_ADDR.
MD37954
$MA_SAFE_INFO_MODULE_NR
Number to select a logical basis address from
MD13374
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
341
Data descriptions
11.1 Machine data
Table 11-3
Machine data with safety-relevant settings for alarms/messages
Number
Symbolic name
Purpose
MD13140
$MN_PROFIBUS_ALARM_ACCESS
Alarm response of the PROFIBUS/PROFINET
drives during run-up
MD13150
$MN_SINAMICS_ALARM_MASK
Activation/deactivation of interference and alarm buf-
fer output of specific DO groups (for not NC-control-
led axes)
Additional information
● More detailed information on parameterizing, searching and filtering machine data in
SINUMERIK Operate can be found in documents SINUMERIK 840D sl Basic Software and
Operating Software, Commissioning Manual SINUMERIK Operate (IM9), Chapter Machine
and setting data.
● General information on all of the machine data is provided in the List Manual "SINUMERIK
840D sl, SINAMICS S120 Machine Data and Parameters" - or in the online help for
SINUMERIK Operate
Safety Integrated plus
342
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Data descriptions
11.2 NC tags
11.2
NC tags
11.2.1
Overview
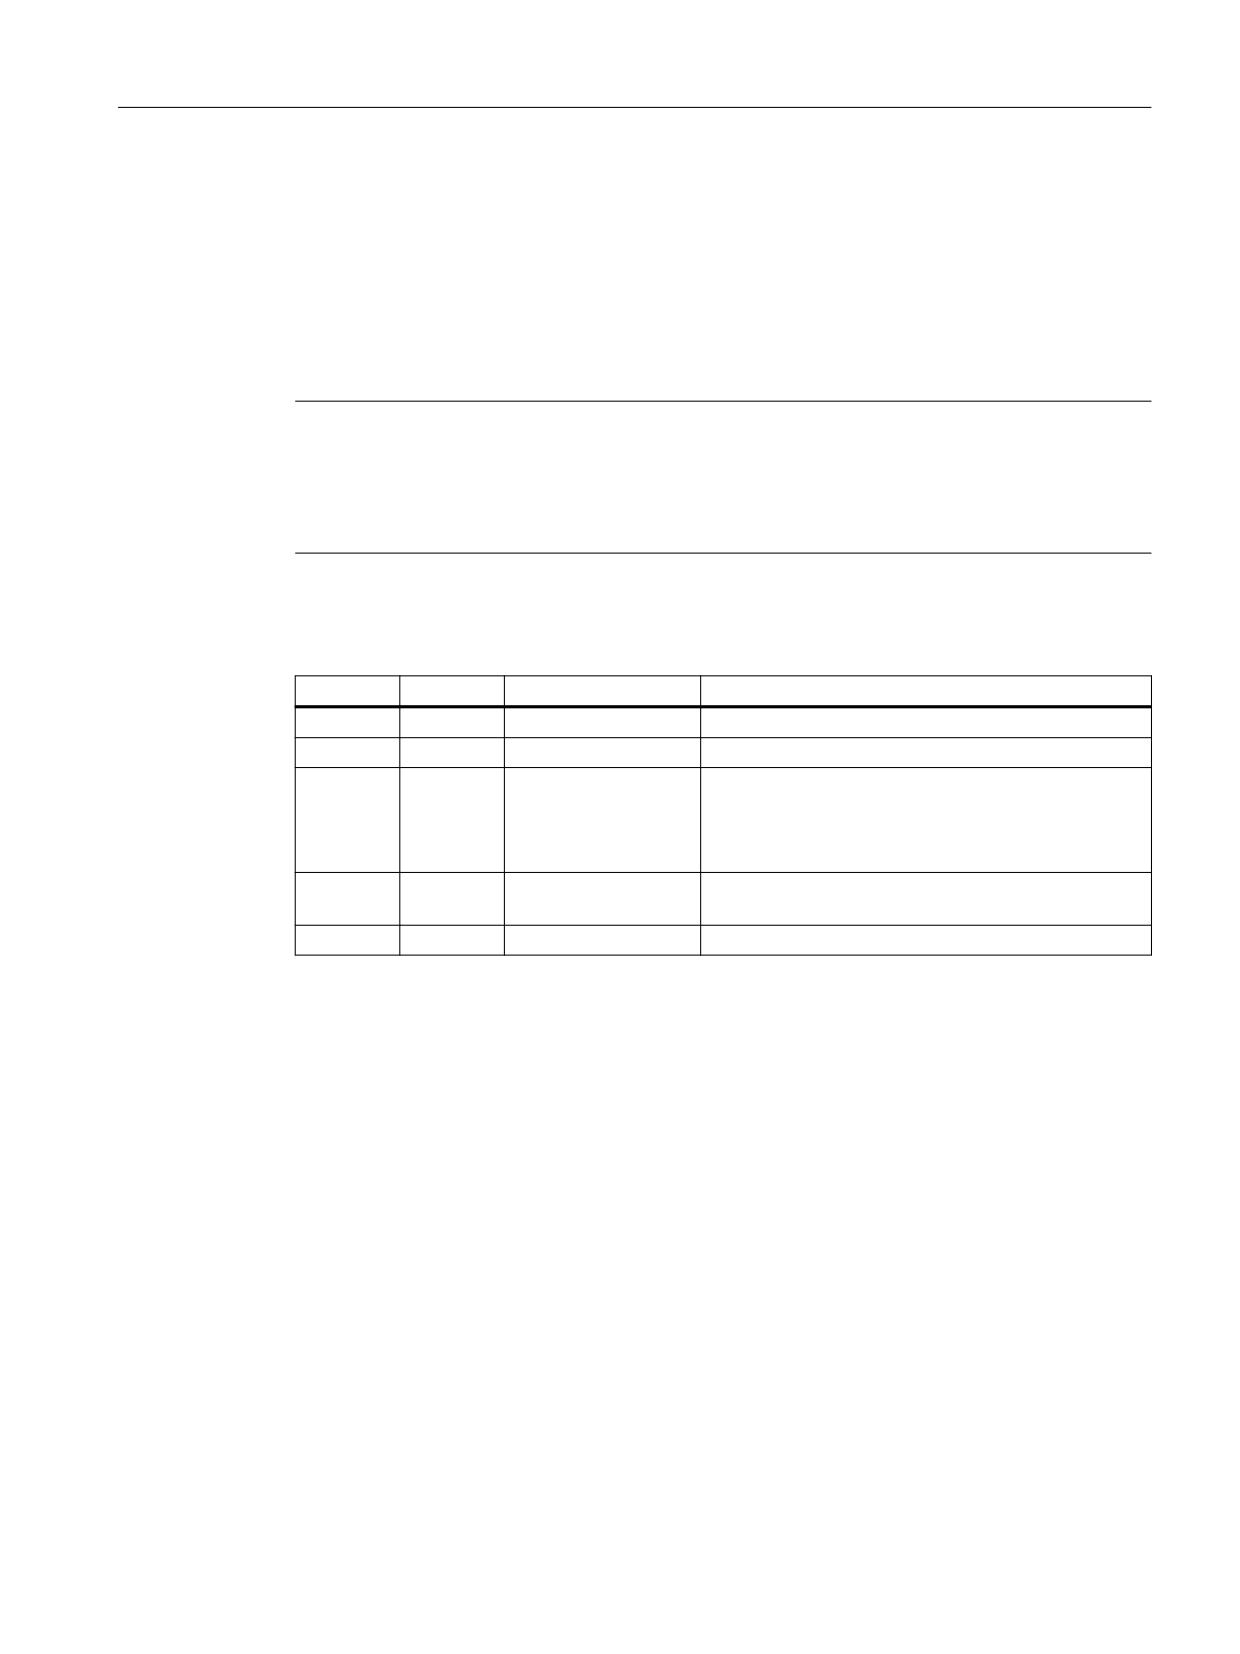
Safety-relevant NC variables (OPI) are available in the Safety Integrated plus operating mode;
to a large extent, these are mapped using SIC signals.
Note
Information for those switching over from a different system: Different use of NC variables (OPI)
Only variables "vaStopSi", "aStopesi" and "safeDesVeloLimit" are used in the two Safety
Integrated operating modes. All other safety-relevant NC variables are specific to an operating
mode - and are not supplied in the two operating modes.
Table 11-4
Safety-relevant NC variables available
Block
index
Name
Meaning
S
183
aStopesi
Actual Safety Integrated Stop E for any axis.
SEMA
214
vaStopSi
Safety Integrated stop.
SEMA
119
safeDesVeloLimit
Effective speed setpoint limit in the NC.
This is obtained from a speed setpoint limit in the
drive and a (possibly) active speed setpoint limit in the
NC.
SEMA
277
safeAxisType
Type of axis-specific safety monitoring functions
(safety axis operating mode).
S
358
safeMode
Configured Safety Integrated operating mode.
Further information
List Manual "SINUMERIK 840D sl, NC Variables and Interface Signals".
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
343
Data descriptions
11.3 System variables
11.3
System variables
11.3.1
Overview
Safety-relevant system variables are available in the Safety Integrated plus operating mode,
which are mapped using SIC signals (interface NC/PLC-DRIVE):
● $VA_STOPSI (Page 344)
● $A_STOPESI (Page 344)
Note
Information for those switching over from a different system: System variables available in the
Safety Integrated plus operating mode
Only variables "$VA_STOPSI" and "$A_STOPESI" listed here are used in both Safety
Integrated operating modes. All of the other system variables known from the Safety Integrated
operating mode are not supplied in the Safety Integrated plus operating mode.
11.3.2
$VA_STOPSI - actual STOP
System variable $VA_STOPSI
Axis-specific system variable that contains the present stop. For a value of 4, a STOP E is
active for this axis.
11.3.3
$A_STOPESI - actual STOP E
System variable $A_STOPESI
Global system variable that with a value not equal to 0 indicates that a STOP E is active for a
particular axis.
11.3.4
$VA_SAFE_TYPE - axial Safety Integrated operating mode
System variable $VA_SAFE_TYPE
Global system variable. It indicates whether Safety Integrated motion monitoring is active for
the active axis; if yes, whether it involves motion monitoring integrated in the NC or drive-based
motion monitoring.
Safety Integrated plus
344
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Data descriptions
11.4 Standard telegram start addresses
11.4
Standard telegram start addresses
11.4.1
PROFIsafe/PROFIdrive telegrams for Safety Integrated plus (F-PLC)
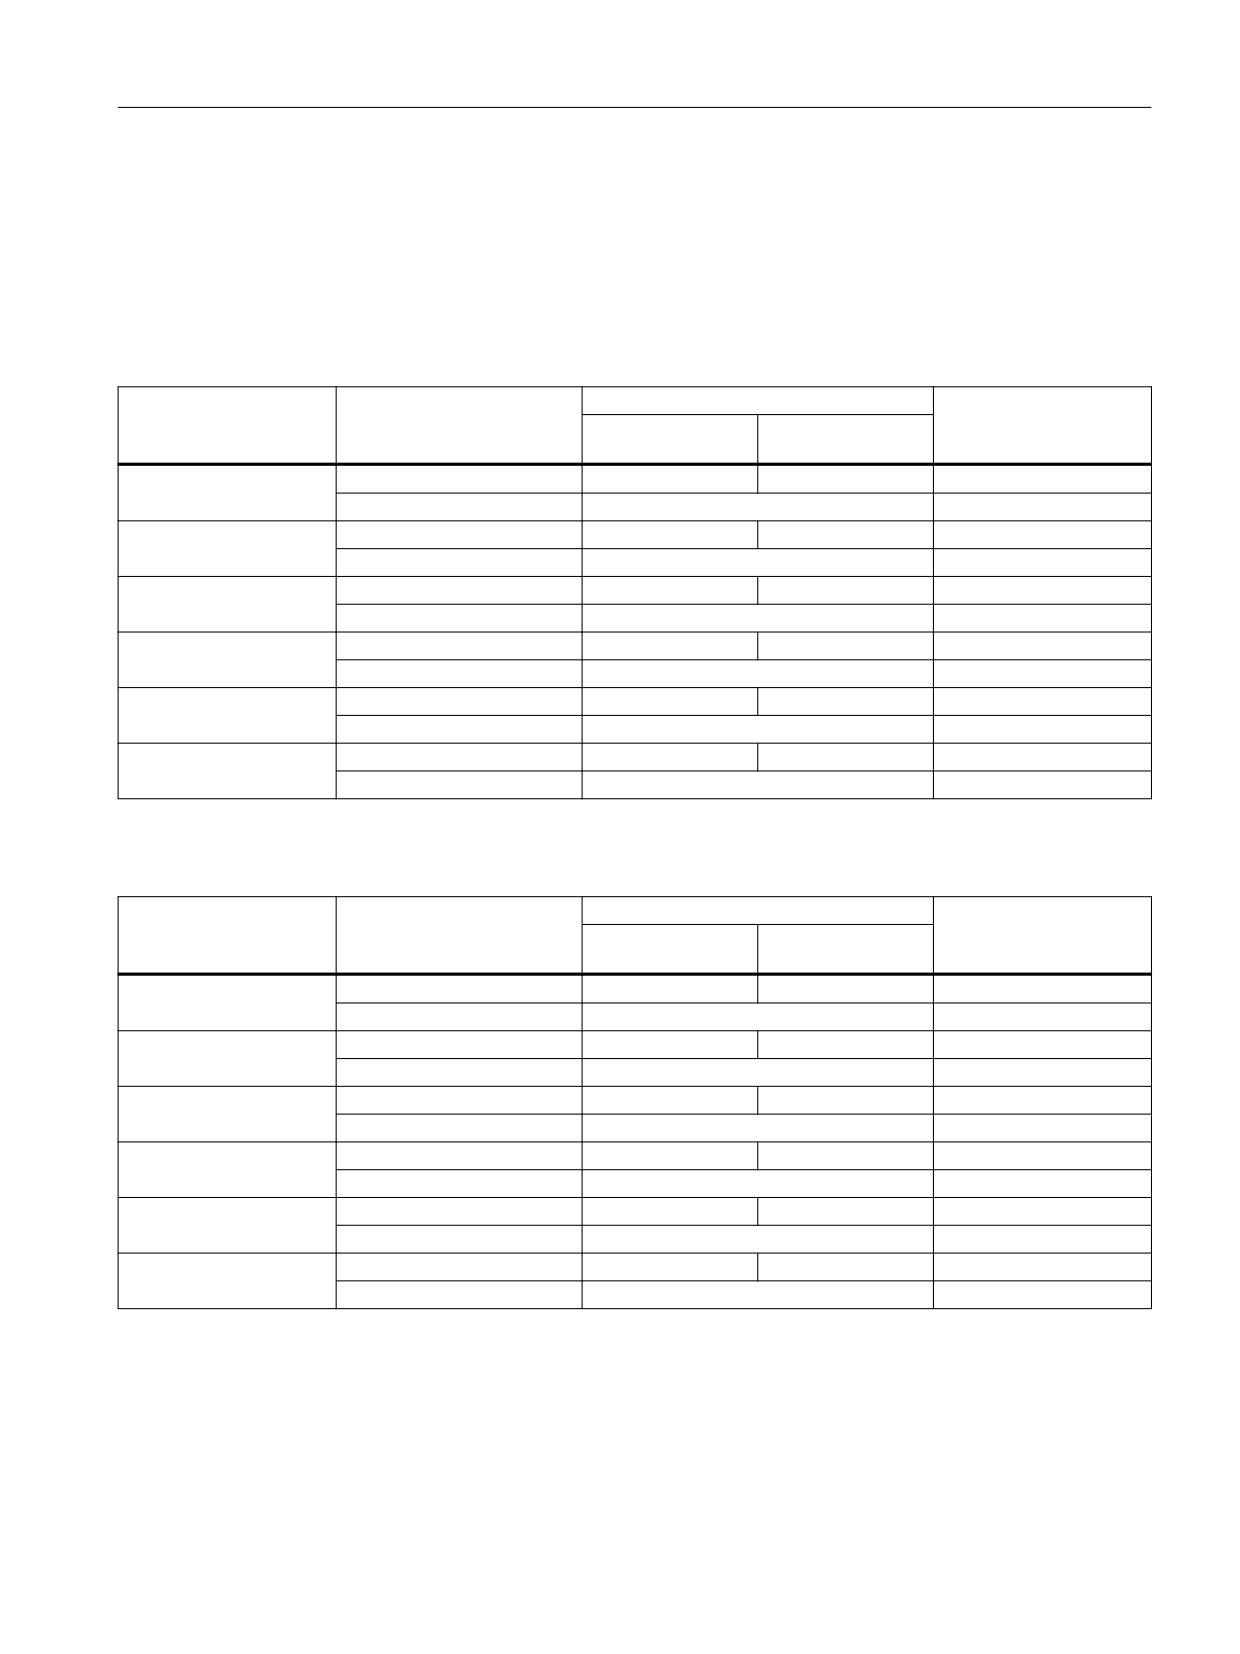
Table 11-5
SINAMICS Integrated: I/O addresses of PROFIsafe/PROFIdrive telegrams
Drive
Telegram type
I/O start address
Machine data
Standard addressing
Optimized address-
schematic
ing schematic
DriveAxis01
SIEMENS telegram 701
5800
15756
13374[0]
SIEMENS telegram 903
1008
13372[0]
DriveAxis02
SIEMENS telegram 701
5816
15676
13374[1]
SIEMENS telegram 903
992
13372[1]
DriveAxis03
SIEMENS telegram 701
5832
15596
13374[2]
SIEMENS telegram 903
976
13372[2]
DriveAxis04
SIEMENS telegram 701
5848
15516
13374[3]
SIEMENS telegram 903
960
13372[3]
DriveAxis05
SIEMENS telegram 701
5864
15436
13374[4]
SIEMENS telegram 903
944
13372[4]
DriveAxis06
SIEMENS telegram 701
5880
15356
13374[5]
SIEMENS telegram 903
928
13372[5]
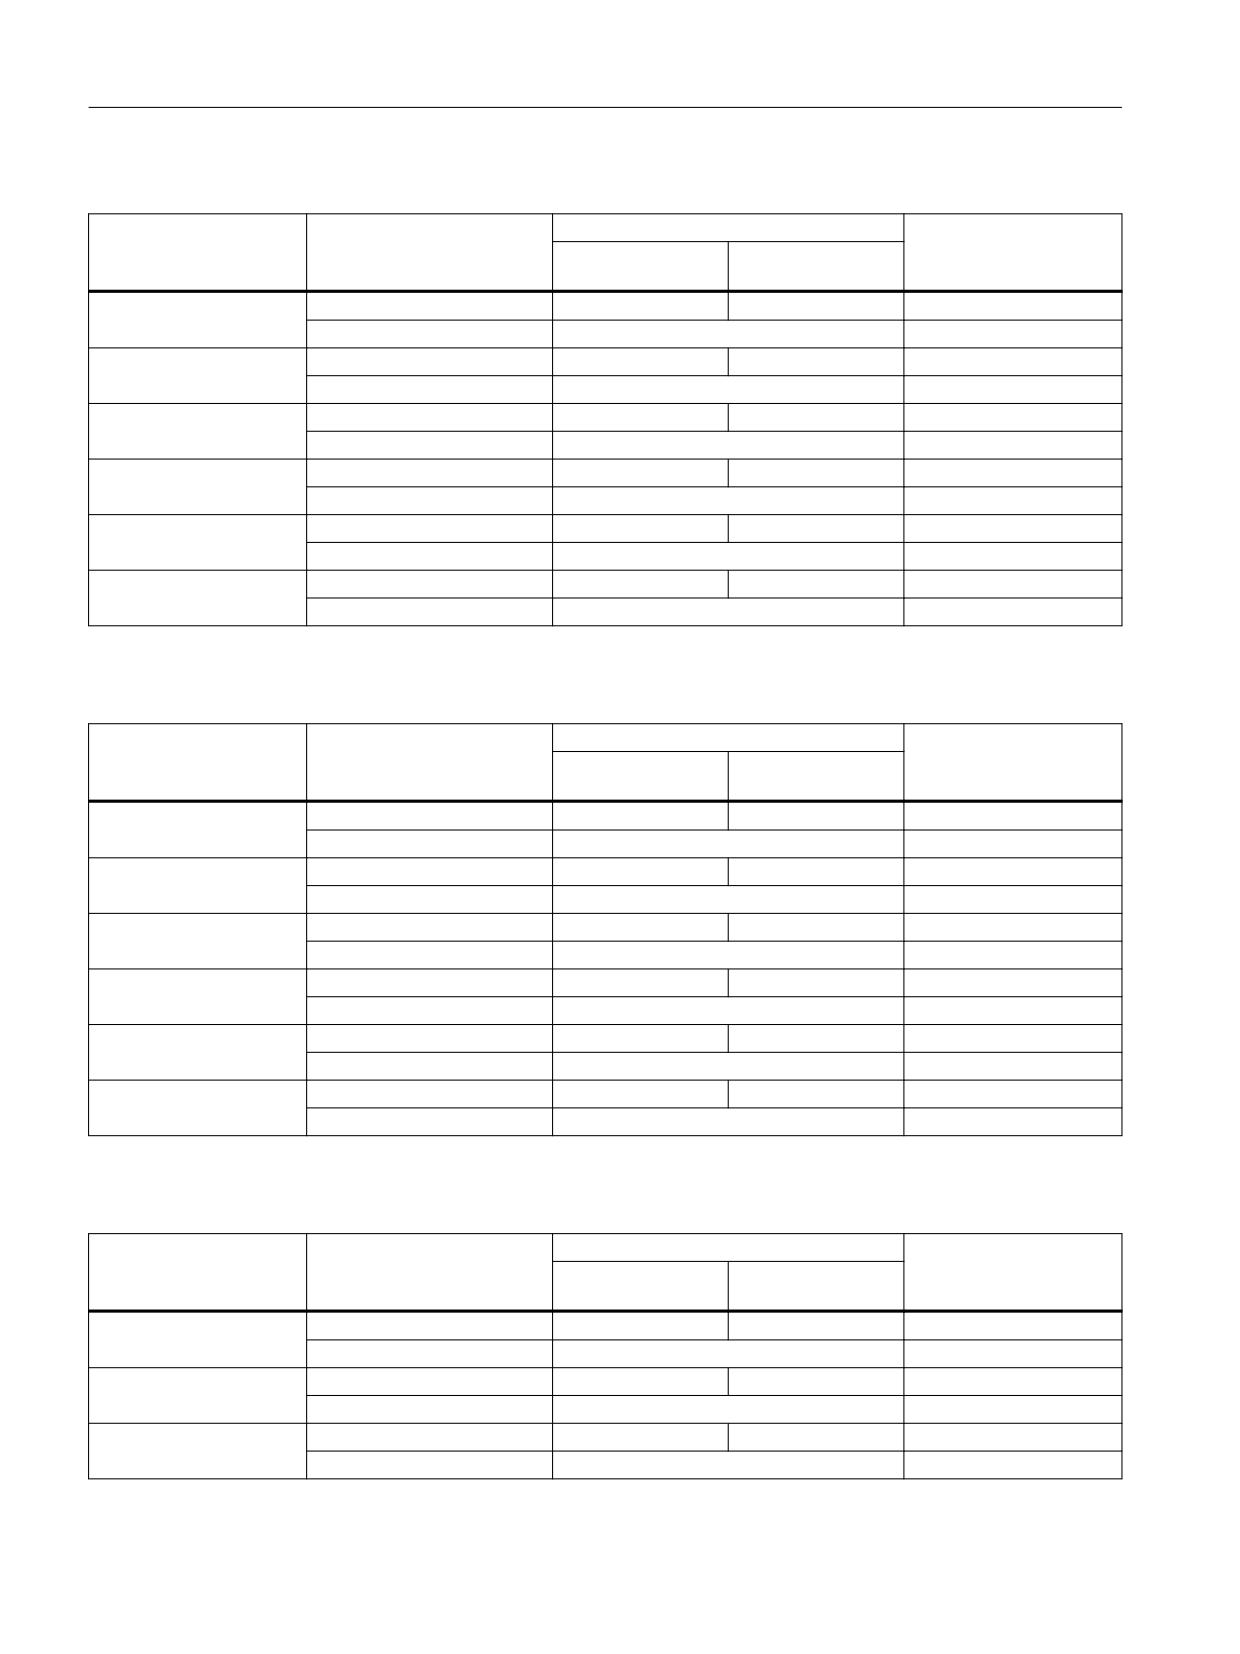
Table 11-6
NX on DRIVE-CLiQ socket X105; DP address 15: I/O addresses of PROFIsafe/PROFIdrive telegrams
Drive
Telegram type
I/O start address
Machine data
Standard addressing
Optimized address-
schematic
ing schematic
DriveAxis01
SIEMENS telegram 701
5896
15206
13374[6]
SIEMENS telegram 903
912
13372[6]
DriveAxis02
SIEMENS telegram 701
5912
15126
13374[7]
SIEMENS telegram 903
896
13372[7]
DriveAxis03
SIEMENS telegram 701
5928
15046
13374[8]
SIEMENS telegram 903
880
13372[8]
DriveAxis04
SIEMENS telegram 701
5944
14966
13374[9]
SIEMENS telegram 903
864
13372[9]
DriveAxis05
SIEMENS telegram 701
5960
14886
13374[10]
SIEMENS telegram 903
848
13372[10]
DriveAxis06
SIEMENS telegram 701
5976
14806
13374[11]
SIEMENS telegram 903
832
13372[11]
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
345
Data descriptions
11.4 Standard telegram start addresses
Table 11-7
NX on DRIVE-CLiQ socket X104; DP address 14: I/O addresses of PROFIsafe/PROFIdrive telegrams
Drive
Telegram type
I/O start address
Machine data
Standard addressing
Optimized address-
schematic
ing schematic
DriveAxis01
SIEMENS telegram 701
5992
14656
13374[12]
SIEMENS telegram 903
816
13372[12]
DriveAxis02
SIEMENS telegram 701
6008
14576
13374[13]
SIEMENS telegram 903
800
13372[13]
DriveAxis03
SIEMENS telegram 701
6024
14496
13374[14]
SIEMENS telegram 903
784
13372[14]
DriveAxis04
SIEMENS telegram 701
6040
14416
13374[15]
SIEMENS telegram 903
768
13372[15]
DriveAxis05
SIEMENS telegram 701
6056
14336
13374[16]
SIEMENS telegram 903
752
13372[16]
DriveAxis06
SIEMENS telegram 701
6072
14256
13374[17]
SIEMENS telegram 903
736
13372[17]
Table 11-8
NX on DRIVE-CLiQ socket X103; DP address 13: I/O addresses of PROFIsafe/PROFIdrive telegrams
Drive
Telegram type
I/O start address
Machine data
Standard addressing
Optimized address-
schematic
ing schematic
DriveAxis01
SIEMENS telegram 701
6088
14106
13374[18]
SIEMENS telegram 903
720
13372[18]
DriveAxis02
SIEMENS telegram 701
6104
14026
13374[19]
SIEMENS telegram 903
704
13372[19]
DriveAxis03
SIEMENS telegram 701
6120
13946
13374[20]
SIEMENS telegram 903
688
13372[20]
DriveAxis04
SIEMENS telegram 701
6136
13866
13374[21]
SIEMENS telegram 903
672
13372[21]
DriveAxis05
SIEMENS telegram 701
6152
13786
13374[22]
SIEMENS telegram 903
656
13372[22]
DriveAxis06
SIEMENS telegram 701
6168
13706
13374[23]
SIEMENS telegram 903
640
13372[23]
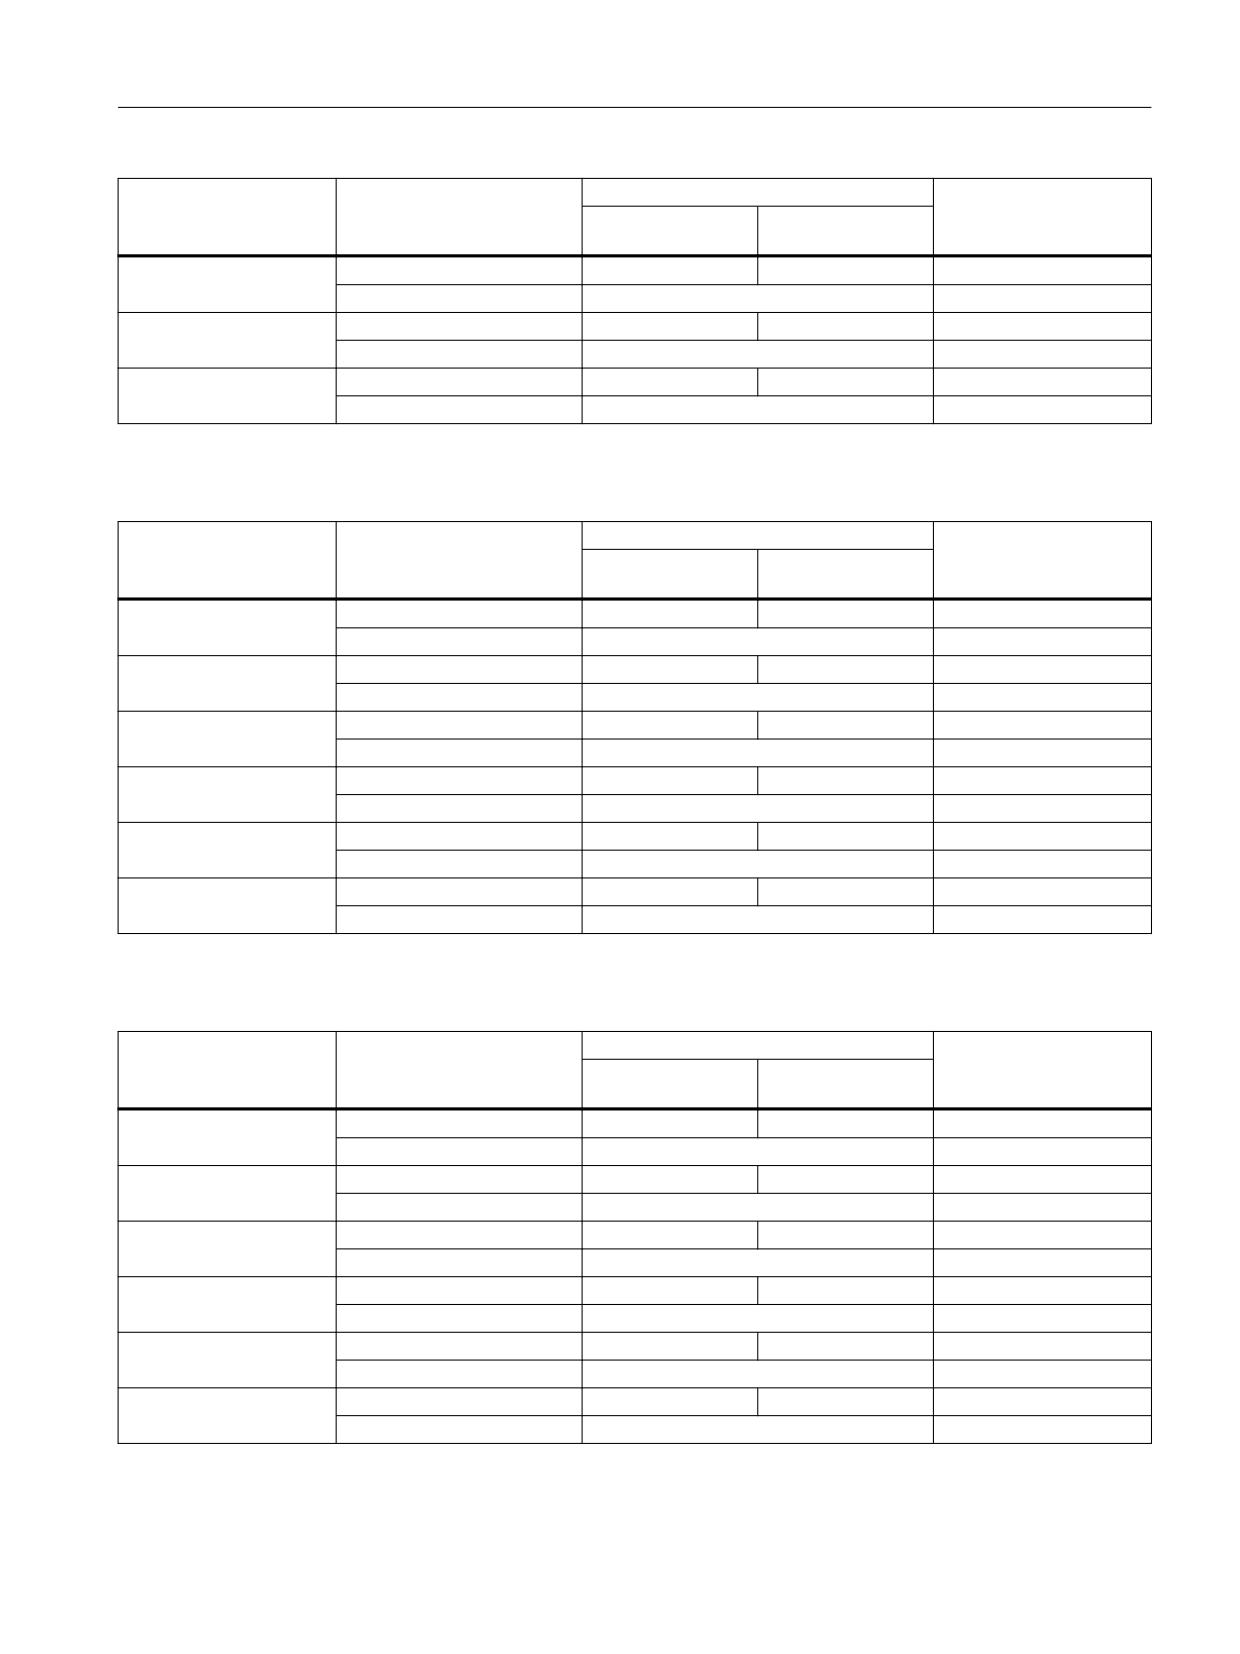
Table 11-9
NX on DRIVE-CLiQ socket X102; DP address 12: I/O addresses of PROFIsafe/PROFIdrive telegrams
Drive
Telegram type
I/O start address
Machine data
Standard addressing
Optimized address-
schematic
ing schematic
DriveAxis01
SIEMENS telegram 701
6184
13556
13374[24]
SIEMENS telegram 903
624
13372[24]
DriveAxis02
SIEMENS telegram 701
6200
13476
13374[25]
SIEMENS telegram 903
608
13372[25]
DriveAxis03
SIEMENS telegram 701
6216
13396
13374[26]
SIEMENS telegram 903
592
13372[26]
Safety Integrated plus
346
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Data descriptions
11.4 Standard telegram start addresses
Drive
Telegram type
I/O start address
Machine data
Standard addressing
Optimized address-
schematic
ing schematic
DriveAxis04
SIEMENS telegram 701
6232
13316
13374[27]
SIEMENS telegram 903
576
13372[27]
DriveAxis05
SIEMENS telegram 701
6248
13236
13374[28]
SIEMENS telegram 903
560
13372[28]
DriveAxis06
SIEMENS telegram 701
6264
13156
13374[29]
SIEMENS telegram 903
544
13372[29]
Table 11-10 NX on DRIVE-CLiQ socket X101; DP address 11: I/O addresses of PROFIsafe/PROFIdrive telegrams
Drive
Telegram type
I/O start address
Machine data
Standard addressing
Optimized address-
schematic
ing schematic
DriveAxis01
SIEMENS telegram 701
6280
13006
13374[30]
SIEMENS telegram 903
528
13372[30]
DriveAxis02
SIEMENS telegram 701
6296
12926
13374[31]
SIEMENS telegram 903
512
13372[31]
DriveAxis03
SIEMENS telegram 701
6312
12846
13374[32]
SIEMENS telegram 903
496
13372[32]
DriveAxis04
SIEMENS telegram 701
6328
12766
13374[33]
SIEMENS telegram 903
480
13372[33]
DriveAxis05
SIEMENS telegram 701
6344
12686
13374[34]
SIEMENS telegram 903
464
13372[34]
DriveAxis06
SIEMENS telegram 701
6360
12606
13374[35]
SIEMENS telegram 903
448
13372[35]
Table 11-11 NX on DRIVE-CLiQ socket X100; DP address 10: I/O addresses of PROFIsafe/PROFIdrive telegrams
Drive
Telegram type
I/O start address
Machine data
Standard addressing
Optimized address-
schematic
ing schematic
DriveAxis01
SIEMENS telegram 701
6376
12456
13374[36]
SIEMENS telegram 903
432
13372[36]
DriveAxis02
SIEMENS telegram 701
6392
12376
13374[37]
SIEMENS telegram 903
416
13372[37]
DriveAxis03
SIEMENS telegram 701
6408
12296
13374[38]
SIEMENS telegram 903
400
13372[38]
DriveAxis04
SIEMENS telegram 701
6424
12216
13374[39]
SIEMENS telegram 903
384
13372[39]
DriveAxis05
SIEMENS telegram 701
6440
12136
13374[40]
SIEMENS telegram 903
368
13372[40]
DriveAxis06
SIEMENS telegram 701
6456
12056
13374[41]
SIEMENS telegram 903
352
13372[41]
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
347
Data descriptions
11.5 Telegram structure and data
11.5
Telegram structure and data
11.5.1
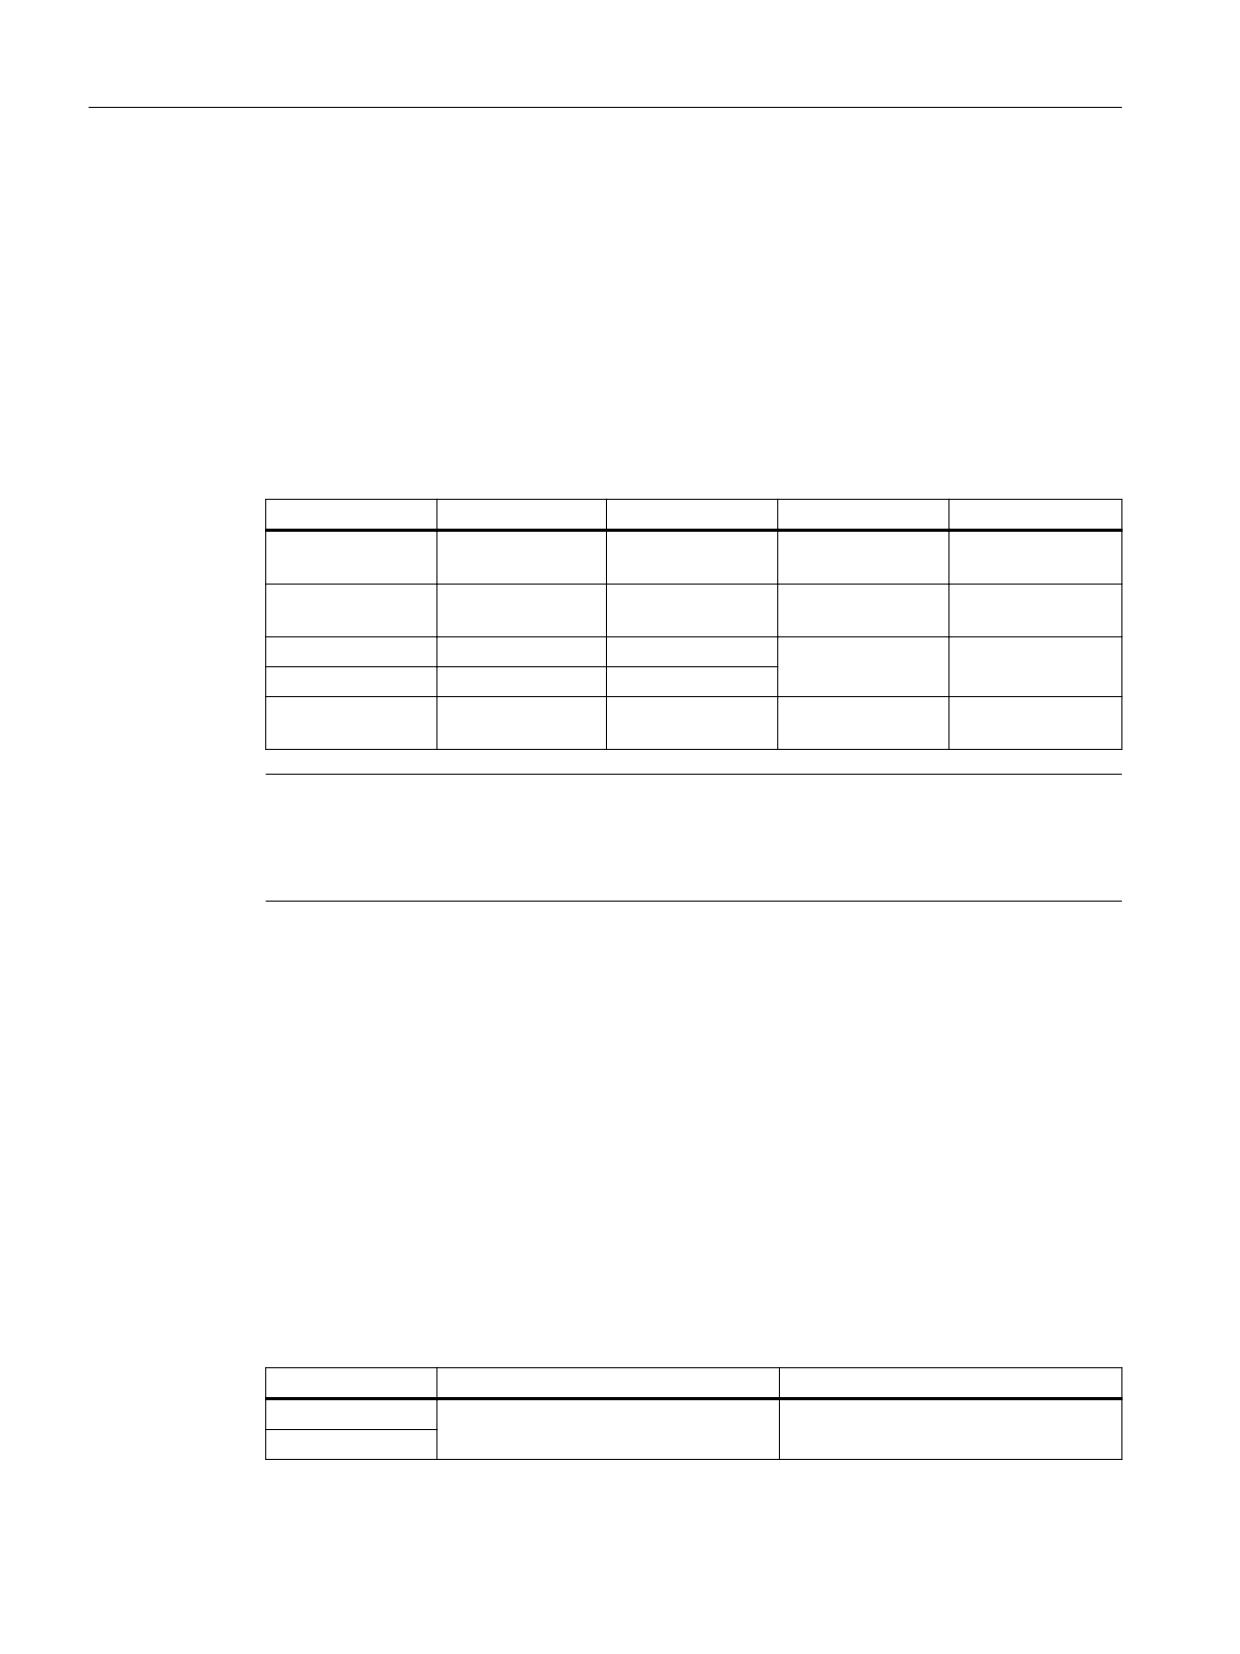
SIEMENS telegram 701
Telegram 701
The predefined PROFIdrive telegram 701 is available for the transfer of the SIC and the SCC:
Table 11-12 SIEMENS telegram 701 (telegram structure)
Receive data
Parameter
Send data
Parameter
PZD1
S_STW1B
p10250
S_ZSW1B
r9734
(Page 366)
(Page 366)
PZD2
S_STW3B
p10235
S_ZSW2B
r9743
(Page 368)
(Page 367)
PZD3
-
-
S_V_LIMIT_B
r9733[2]
(Page 369)
PZD4
-
-
PZD5
-
-
S_ZSW3B
r10234
(Page 368)
Note
Update of the send data
The send data S_ZSW1B, S_ZSW2B, S_ZSW3B and S_V_LIMIT_B is only updated if the
Safety Integrated Extended Functions are enabled.
Additional information
You can find further information on communication via PROFIdrive in the Manual "SINAMICS
S120 Drive Functions Function Manual", Chapter "Communication according to PROFIdrive".
11.5.2
SIEMENS telegram 903
Structure of telegram 903
Telegram 903 transmits the following user data: S_STW2, S_SLS_LIMIT_A, S_ZSW2,
S_ZSW_CAM1 and S_SLS_LIMIT_A_ACTIVE.
Telegram 903 is the default setting for internal NC drives.
Output data
Input data
PZD1
S_STW2 (Page 357)
S_ZSW2 (Page 359)
PZD2
Safety Integrated plus
348
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
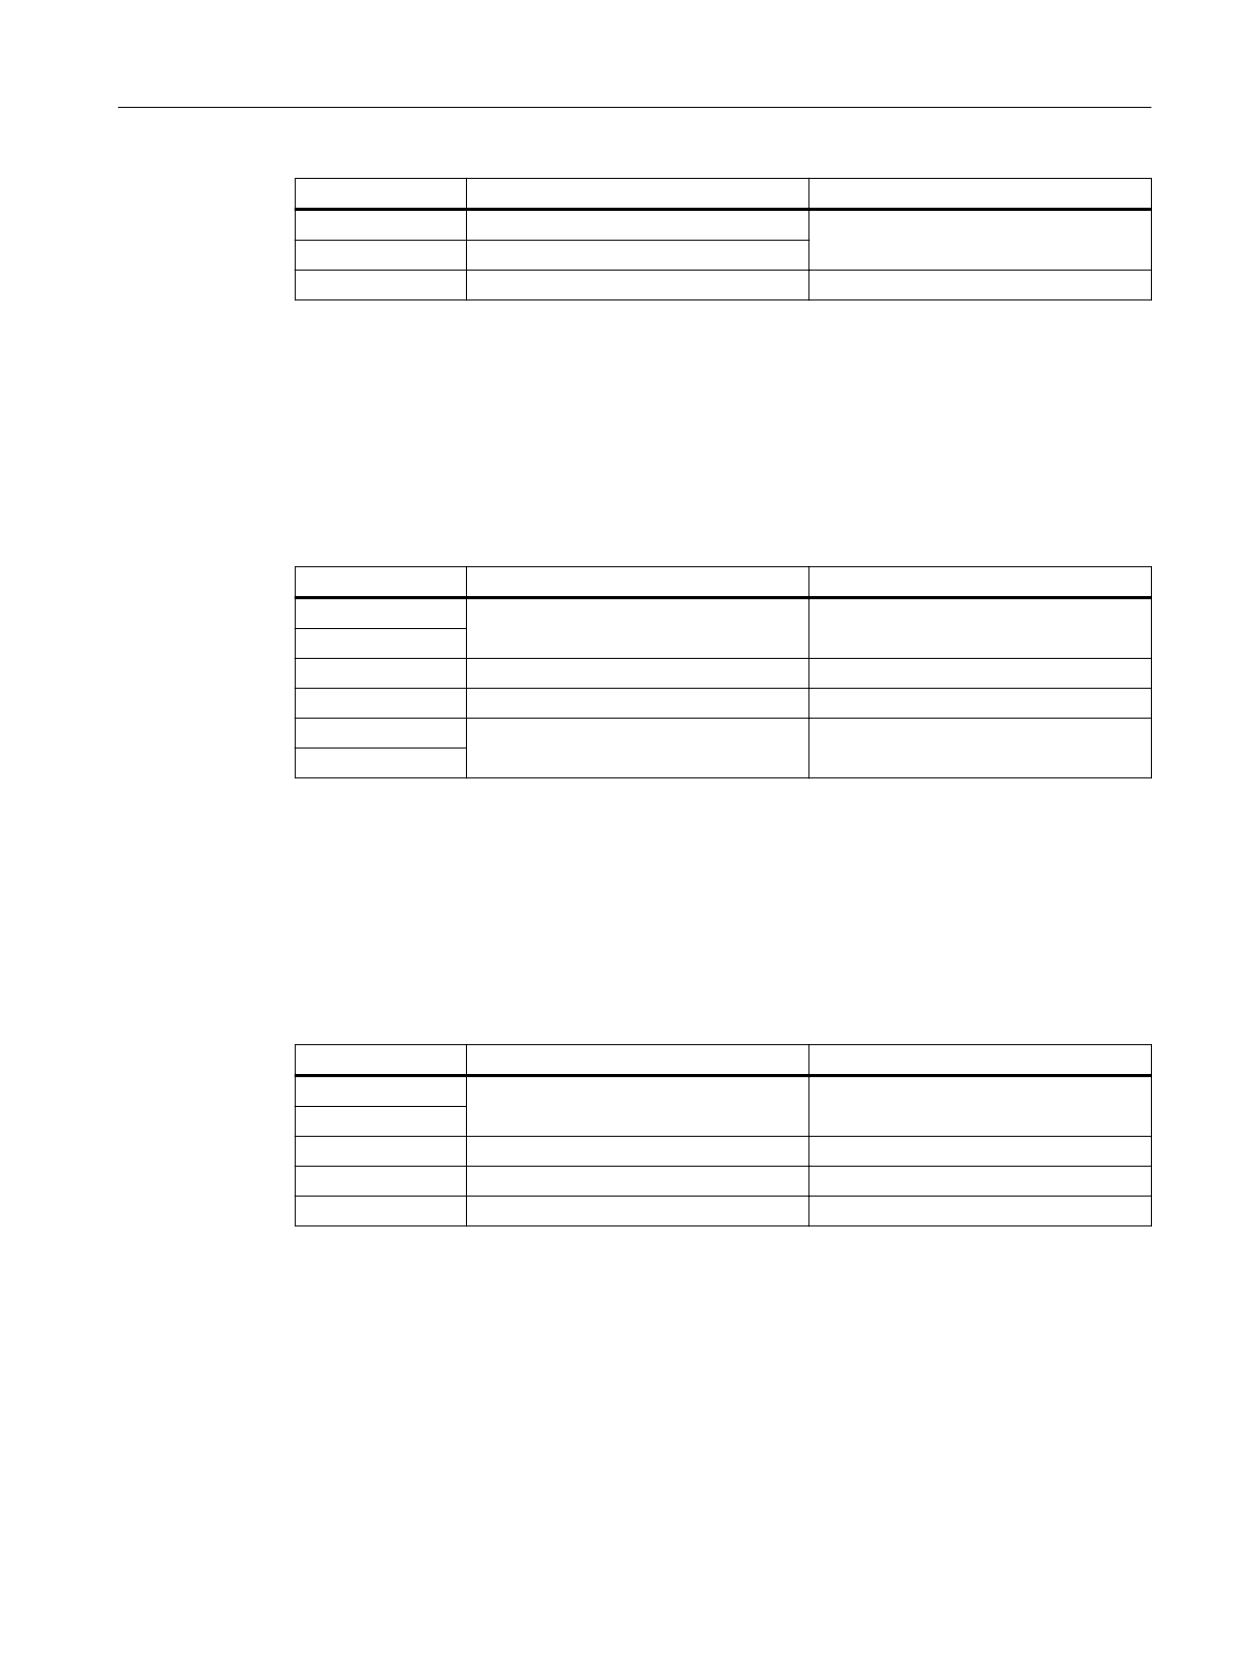
Data descriptions
11.5 Telegram structure and data
Output data
Input data
PZD3
S_SLS_LIMIT_A (Page 362)
S_ZSW_CAM1 (Page 364)
PZD4
-
PZD5
-
S_SLS_LIMIT_A_ACTIVE (Page 362)
11.5.3
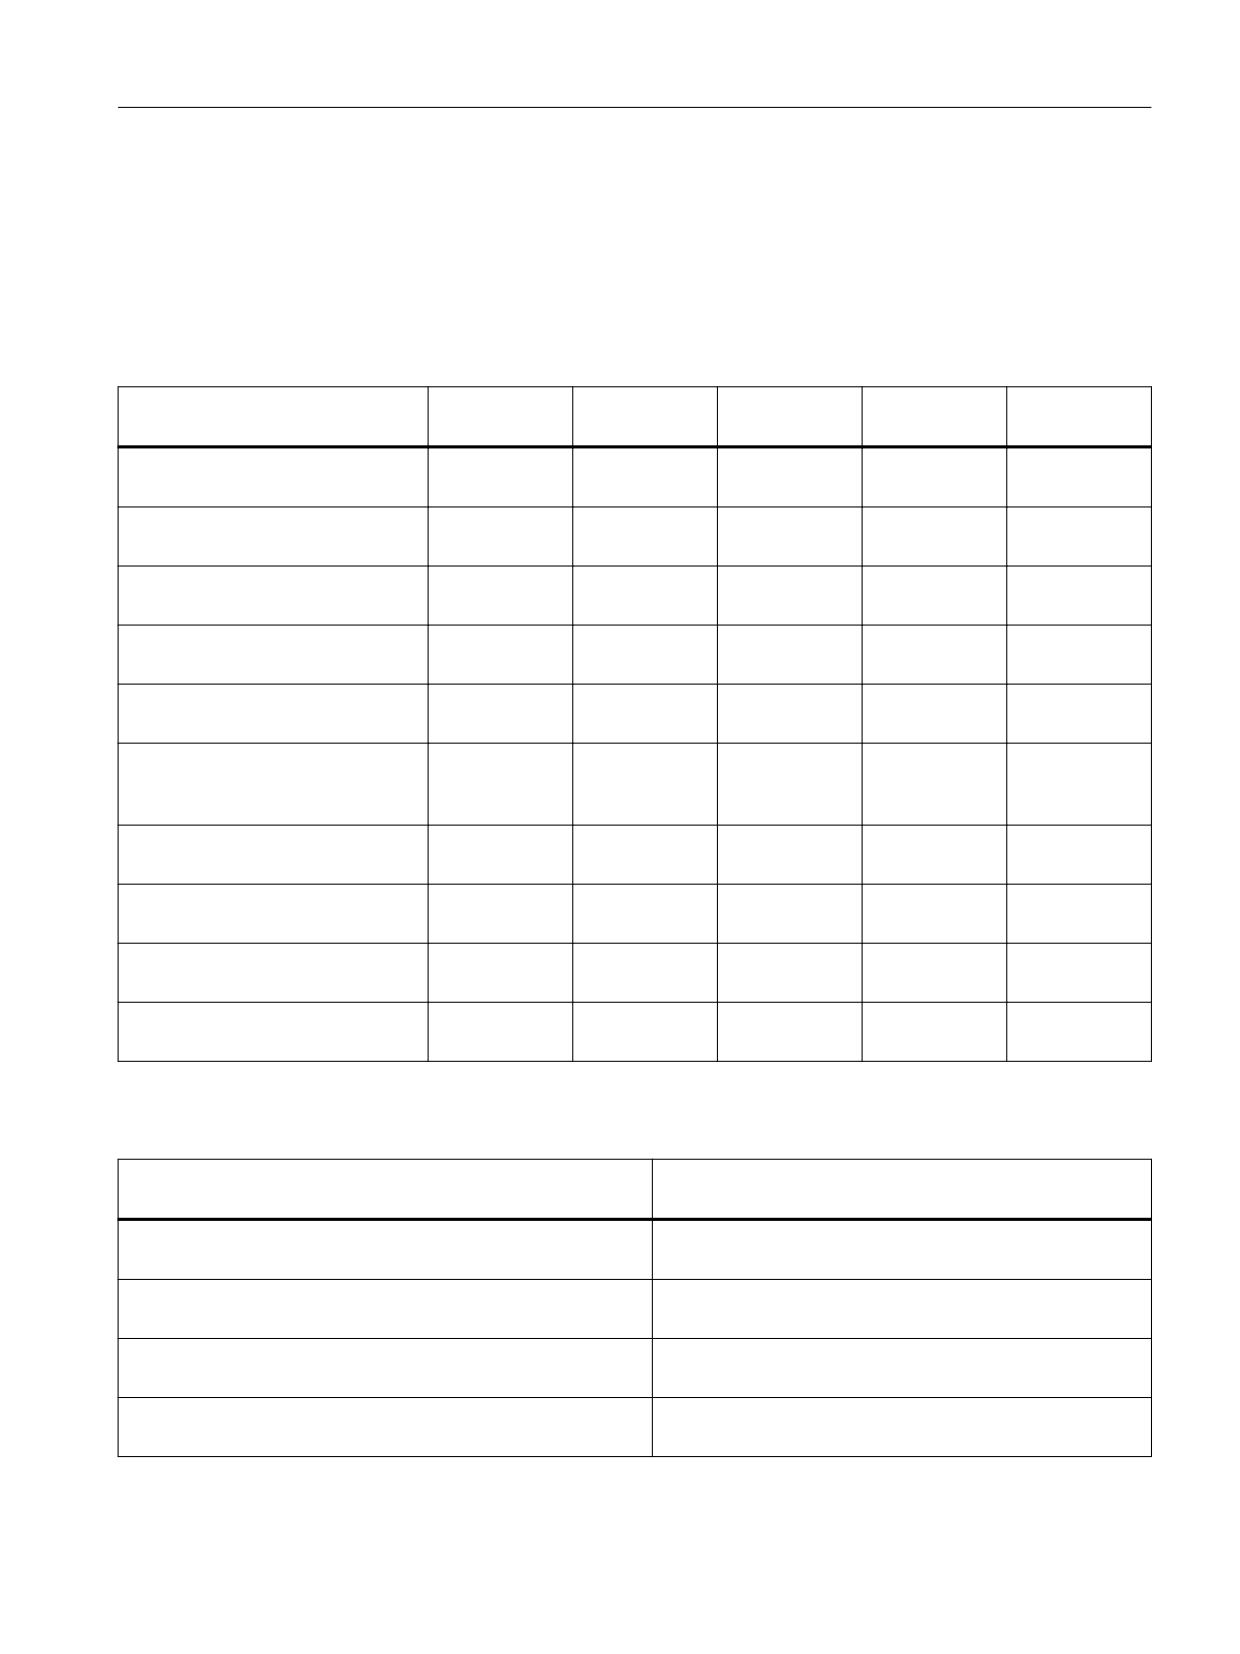
SIEMENS telegram 902
Telegram 902 transfers as user data S_STW2, the variable SLS limit (S_SLS_LIMIT_A), the
S_ZSW2, the active SLS value of level 1 (S_SLS_LIMIT_A_ACTIVE), a counter value
(S_CYCLE_COUNT) and the safe position value in 32-bit format (S_XIST32).
Table 11-13 SIEMENS telegram 902 (telegram structure)
Output data
Input data
PZD1
S_STW2 (Page 357)
S_ZSW2 (Page 359)
PZD2
PZD3
S_SLS_LIMIT_A (Page 362)
S_SLS_LIMIT_A_ACTIVE (Page 362)
PZD4
-
S_CYCLE_COUNT (Page 363)
PZD5
-
S_XIST32 (Page 363)
PZD6
11.5.4
SIEMENS telegram 901
Telegram 901 transfers the S_STW2, the variable SLS limit (S_SLS_LIMIT_A), the S_ZSW2,
the active SLS value of level 1 (S_SLS_LIMIT_A_ACTIVE), a counter value
(S_CYCLE_COUNT) and the safe position value in 16-bit format (S_XIST16) as user data.
Table 11-14 SIEMENS telegram 901 (telegram structure)
Output data
Input data
PZD1
S_STW2 (Page 357)
S_ZSW2 (Page 359)
PZD2
PZD3
S_SLS_LIMIT_A (Page 362)
S_SLS_LIMIT_A_ACTIVE (Page 362)
PZD4
-
S_CYCLE_COUNT (Page 363)
PZD5
-
S_XIST16 (Page 363)
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
349
Data descriptions
11.5 Telegram structure and data
11.5.5
PROFIsafe telegram 30
Telegram 30 transfers as user data safety control word 1 (S_STW1) and safety status word 1
(S_ZSW1).
Table 11-15 PROFIsafe telegram 30 (telegram structure)
Output data
Input data
PZD1
S_STW1 (Page 353)
S_ZSW1 (Page 355)
11.5.6
PROFIsafe telegram 31
Telegram 31 transfers safety control word 2 (S_STW2) and safety status word 2 (S_ZSW2) as
user data. It is structured as follows:
Table 11-16 PROFIsafe telegram 31 (telegram structure)
Output data
Input data
PZD1
S_STW2 (Page 357)
S_ZSW2 (Page 359)
PZD2
Safety Integrated plus
350
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Data descriptions
11.6 Process data
11.6
Process data
11.6.1
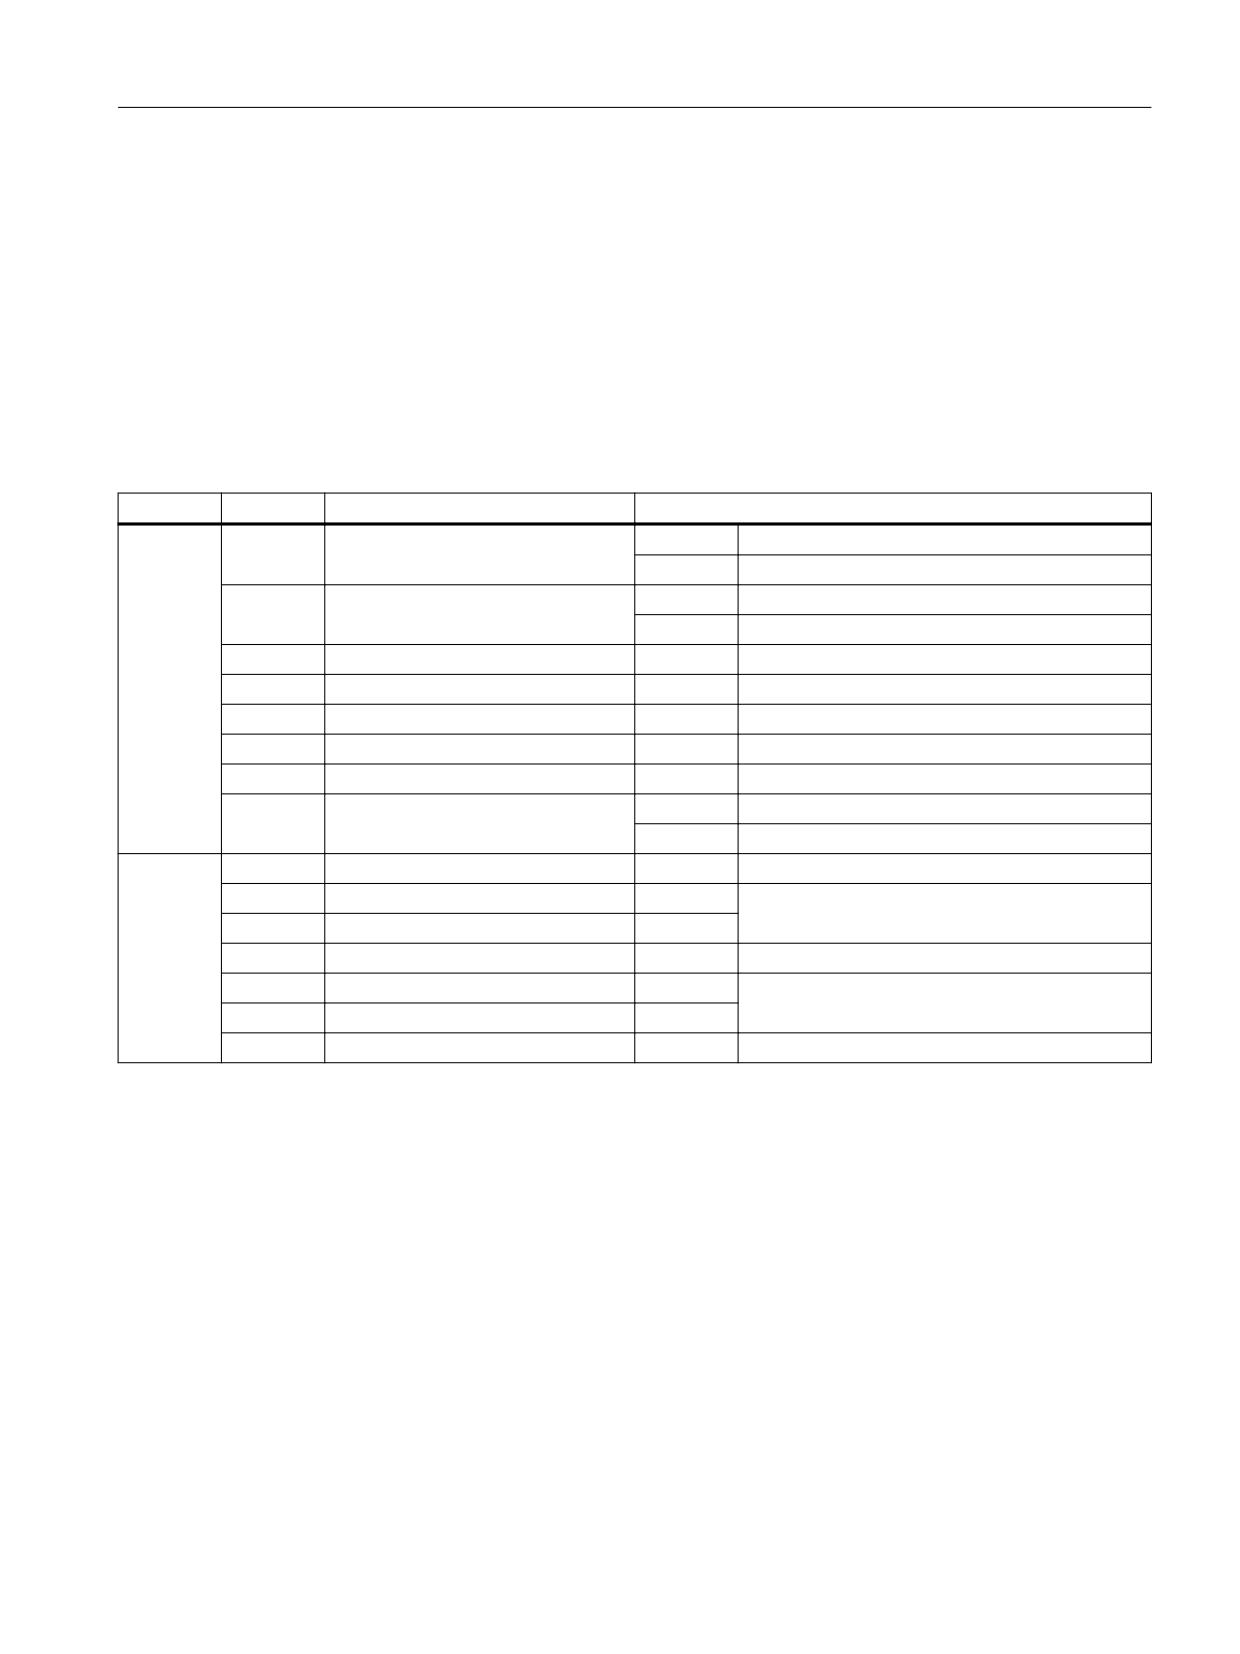
Overview: Process data in telegrams
Table 11-17 Process data from PROFIsafe telegrams
Telegram
903
902
901
31
30
Process data
Safety control word 1
-
-
-
-
PZD1
S_STW1 (Page 353)
Safety status word 1
-
-
-
-
PZD1
S_ZSW1 (Page 355)
Safety control word 2
PZD1…2
PZD1…2
PZD1…2
PZD1…2
-
S_STW2 (Page 357)
Safety status word 2
PZD1…2
PZD1…2
PZD1…2
PZD1…2
-
S_ZSW2 (Page 359)
SLS limit value input
PZD3
PZD3
PZD3
-
-
S_SLS_LIMIT_A (Page 362)
Active SLS limit value
PZD5
PZD3
PZD3
-
-
S_SLS_LIMIT_A_ACTIVE
(Page 362)
Counter for the safety cycle
-
PZD4
PZD4
-
-
S_CYCLE_COUNT (Page 363)
Actual position value (16 bits)
-
-
PZD5
-
-
S_XIST16 (Page 363)
Actual position value (32 bits)
-
PZD5…6
-
-
-
S_XIST32 (Page 363)
Safe Cam status word
PZD3…4
-
-
-
-
S_ZSW_CAM1 (Page 364)
Table 11-18 Process data from SIEMENS telegram 701 (SIC/SCC)
Telegram
701
Process data
Safety Control Channel control word 1
PZD1
S_STW1B (Page 366)
SI Motion Safety Info Channel status word
PZD1
S_ZSW1B (Page 366)
Safety Info Channel status word 2
PZD2
S_ZSW2B (Page 367)
Safety Control Channel control word 3
PZD2
S_STW3B (Page 368)
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
351
Data descriptions
11.6 Process data
Telegram
701
Process data
SLS setpoint speed limiting (32 bit)
PZD3…4
S_V_LIMIT_B (Page 369)
Safety Info Channel status word 3
PZD5
S_ZSW3B (Page 368)
See also
S_ZSW3B: Safety Info Channel status word 3 (Page 368)
11.6.2
PROFIsafe process data
Note
Supplementary information in function block diagrams
For the subsequent descriptions, a reference is generally made to a function block diagram.
You can find the specified function block diagram in the SINAMICS S120/S150 List Manual.
Safety Integrated plus
352
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Data descriptions
11.6 Process data
11.6.2.1
S_STW1: Safety control word 1
S_STW1 (Basic Functions)
Safety control word 1 (S_STW1)
S_STW1, output signals
see function chart [2806].
Table 11-19 Description of safety-control word1 (S_STW1)
Byte
Bit
Meaning
Remarks
0
0
STO
1
Deselect STO
0
Select STO
1
SS1
1
Deselect SS1
0
Select SS1
2
SS2
0
-1)
3
SOS
0
-1)
4
SLS
0
-1)
5
Reserved
-
-
6
SLP
0
-1)
7
Internal Event ACK
1/0
Acknowledgment
0
No acknowledgment
1
0
Reserved
-
-
1
Select SLS bit 0
0
-1)
2
Select SLS bit 1
0
3
Reserved
-
-
4
SDI positive
0
-1)
5
SDI negative
0
6, 7
Reserved
-
-
1)
Signals not relevant for Basic Functions: Should be set to "0".
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
353
Data descriptions
11.6 Process data
S_STW1 (Extended Functions)
Safety control word 1 (S_STW1)
S_STW1, output signals
see function chart [2842].
Table 11-20 Description of safety-control word1 (S_STW1)
Byte
Bit
Meaning
Remarks
0
0
STO
1
Deselect STO
0
Select STO
1
SS1
1
Deselect SS1
0
Select SS1
2
SS2
1
Deselect SS2
0
Select SS2
3
SOS
1
Deselect SOS
0
Select SOS
4
SLS
1
Deselect SLS
0
Select SLS
5
Reserved
-
-
6
SLP
1
Deselect SLP
0
Select SLP
7
Internal Event ACK
1/0
Acknowledgment
0
No acknowledgment
1
0
Reserved
-
-
1
Select SLS bit 0
-
Selection of the speed limit for SLS (2 bits)
2
Select SLS bit 1
-
3
Reserved
-
-
4
SDI positive
1
Deselect SDI positive
0
Select SDI positive
5
SDI negative
1
Deselect SDI negative
0
Select SDI negative
6, 7
Reserved
-
-
Safety Integrated plus
354
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Data descriptions
11.6 Process data
11.6.2.2
S_ZSW1: Safety status word 1
S_ZSW1 (Basic Functions)
Safety status word 1 (S_ZSW1)
S_ZSW1, input signals
see function diagram [2806].
Table 11-21 Description of safety status word 1 (S_ZSW1)
Byte
Bit
Meaning
Remarks
0
0
STO active
1
STO active
0
STO not active
1
SS1 active
1
SS1 active
0
SS1 not active
2
SS2 active
0
-1)
3
SOS active
0
-1)
4
SLS active
0
-1)
5
Reserved
-
-
6
SLP active
0
-1)
7
Internal Event
1
Internal event
0
No internal event
1
0
Reserved
-
-
1
Active SLS level bit 0
0
-1)
2
Active SLS level bit 1
0
3
SOS selected
0
-1)
4
SDI positive active
0
-1)
5
SDI negative active
0
-1)
6
Reserved
-
-
7
SSM (speed below limit value)
0
-1)
1)
Signals not relevant for Basic Functions: Must not be evaluated.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
355
Data descriptions
11.6 Process data
S_ZSW1 (Extended Functions)
Safety status word 1 (S_ZSW1)
S_ZSW1, input signals
see function diagram [2842].
Table 11-22 Description of safety status word 1 (S_ZSW1)
Byte
Bit
Meaning
Remarks
0
0
STO active
1
STO active
0
STO not active
1
SS1 active
1
SS1 active
0
SS1 not active
2
SS2 active
1
SS2 active
0
SS2 not active
3
SOS active
1
SOS active
0
SOS not active
4
SLS active
1
SLS active
0
SLS not active
5
Reserved
-
-
6
SLP active
1
SLP active
0
SLP not active
–
The status signal "SLP active" is not the same as
the diagnostic signal "SLP active" (r9722.6), but
is the AND logic operation of "SLP active"
(r9722.6) and "safely referenced" (r9722.23).
7
Internal Event
1
Internal event
0
No internal event
1
0
Reserved
-
-
1
Active SLS level bit 0
-
Display of the velocity limit for SLS (2 bits)
2
Active SLS level bit 1
-
3
SOS selected
1
SOS selected
0
SOS deselected
4
SDI positive active
1
SDI positive active
0
SDI positive not active
5
SDI negative active
1
SDI negative active
0
SDI negative not active
6
Reserved
-
-
7
SSM (speed)
1
SSM (speed below limit value)
0
SSM (speed higher than/equal to limit)
Safety Integrated plus
356
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Data descriptions
11.6 Process data
11.6.2.3
S_STW2: Safety control word 2
S_STW2 (Basic Functions)
Safety control word 2 (S_STW2)
S_STW2, output signals
see function diagram [2806].
Table 11-23 Description of safety-control word 2 (S_STW2)
Byte
Bit
Meaning
Remarks
0
0
STO
1
Deselect STO
0
Select STO
1
SS1
1
Deselect SS1
0
Select SS1
2
SS2
0
-1)
3
SOS
0
-1)
4
SLS
0
-1)
5
Reserved
-
-
6
SLP
0
-1)
7
Internal Event ACK
1/0
Acknowledgment
0
No acknowledgment
1
0
SLA active
0
-1)
1
Select SLS bit 0
0
-1)
2
Select SLS bit 1
0
3
Reserved
-
-
4
SDI positive
0
-1)
5
SDI negative
0
-1)
6
Reserved
-
-
7
SSM
0
-1)
2
0 ... 2
Reserved
-
-
3
Select SLP position range
0
-1)
4 ... 6
Reserved
-
-
7
SCA
0
-1)
3
0
Select gearbox stage, bit 0
0
-1)
1
Select gearbox stage, bit 1
0
-1)
2
Select gearbox stage, bit 2
0
-1)
3
Gearbox stage switchover
0
-1)
4
SS2E
0
-1)
5, 6, 7
Reserved
-
-
1)
Signals not relevant to Basic Functions should be set to "0".
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
357
Data descriptions
11.6 Process data
S_STW2 (Extended Functions)
Safety control word 2 (S_STW2)
S_STW2, output signals
see function diagram [2843].
Table 11-24 Description of safety-control word 2 (S_STW2)
Byte
Bit
Meaning
Remarks
0
0
STO
1
Deselect STO
0
Select STO
1
SS1
1
Deselect SS1
0
Select SS1
2
SS2
1
Deselect SS2
0
Select SS2
3
SOS
1
Deselect SOS
0
Select SOS
4
SLS
1
Deselect SLS
0
Select SLS
5
Reserved
-
-
6
SLP
1
Deselect SLP
0
Select SLP
7
Internal Event ACK
1/0
Acknowledgment
0
No acknowledgment
1
0
Reserved
-
-
1
Select SLS bit 0
-
Selection of the speed limit for SLS (2 bits)
2
Select SLS bit 1
-
3
Reserved
-
-
4
SDI positive
1
Deselect SDI positive
0
Select SDI positive
5
SDI negative
1
Deselect SDI negative
0
Select SDI negative
6, 7
Reserved
-
-
2
0 ... 2
Reserved
-
-
3
Select SLP position range
1
Select SLP area 2 (SLP2)
0
Select SLP area 1 (SLP1)
4 ... 7
Reserved
-
-
Safety Integrated plus
358
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Data descriptions
11.6 Process data
Byte
Bit
Meaning
Remarks
3
0
Select gearbox stage, bit 0
-
Select gearbox stage (3 bits)
1
Select gearbox stage, bit 1
-
2
Select gearbox stage, bit 2
-
3
Gearbox stage switchover
1
With increased position tolerance
0
Without increased position tolerance
4
SS2E
1
Deselect SSE
0
Select SSE
5 ... 7
Reserved
-
-
11.6.2.4
S_ZSW2: Safety status word 2
S_ZSW2 (Basic Functions)
Safety status word 2 (S_ZSW2)
S_ZSW2, input signals
see function diagram [2806].
Table 11-25 Description of safety status word 2 (S_ZSW2)
Byte
Bit
Meaning
Remarks
0
0
STO active
1
STO active
0
STO not active
1
SS1 active
1
SS1 active
0
SS1 not active
2
SS2 active
0
-1)
3
SOS active
0
-1)
4
SLS active
0
-1)
5
Reserved
-
-
6
SLP active
0
-1)
7
Internal Event
1
Internal event
0
No internal event
1
0
SLA active
0
-1)
1
Active SLS level, bit 0
0
-1)
2
Active SLS level, bit 1
0
3
Reserved
-
-
4
SDI positive active
0
-1)
5
SDI negative active
0
-1)
6
Reserved
-
-
7
SSM (speed)
0
-1)
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
359
Data descriptions
11.6 Process data
Byte
Bit
Meaning
Remarks
2
0 ... 2
Reserved
-
-
3
SLP active position range
0
-1)
4, 5
Reserved
-
-
6
Safe position valid
0
-1)
7
Safely referenced
0
-1)
3
0 ... 2
F-DI 0 ... 22)
0
-1)
3
Reserved
-
-
4
SS2E active
0
-1)
5
SOS selected
0
-1)
6
SLP upper limit maintained
0
-1)
7
SLP lower limit maintained
0
-1)
1)
Signals not relevant for Basic Functions: Must not be evaluated.
2)
Only valid for CU310-2.
S_ZSW2 (Extended Functions)
Safety status word 2 (S_ZSW2)
S_ZSW2, input signals
see function diagram [2843].
Table 11-26 Description of safety status word 2 (S_ZSW2)
Byte
Bit
Meaning
Remarks
0
0
STO active
1
STO active
0
STO not active
1
SS1 active
1
SS1 active
0
SS1 not active
2
SS2 active
1
SS2 active
0
SS2 not active
3
SOS active
1
SOS active
0
SOS not active
4
SLS active
1
SLS active
0
SLS not active
5
Reserved
-
-
6
SLP active1
1
SLP active
0
SLP not active
–
The status signal "SLP active" is not the same as
the diagnostic signal "SLP active" (r9722.6), but
is the AND logic operation of "SLP active"
(r9722.6) and "safely referenced" (r9722.23).
7
Internal Event
1
Internal event
0
No internal event
Safety Integrated plus
360
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Data descriptions
11.6 Process data
Byte
Bit
Meaning
Remarks
1
0
SLA active
1
SLA active
0
SLA not active
1
Active SLS level bit 0
-
Display of the speed limit for SLS (2 bits)
2
Active SLS level bit 1
-
3
Reserved
-
-
4
SDI positive active
1
SDI positive active
0
SDI positive not active
5
SDI negative active
1
SDI negative active
0
SDI negative not active
6
Reserved
-
-
7
SSM (speed)
1
SSM (speed below limit value)
0
SSM (speed higher than/equal to limit)
2
0 ... 2
Reserved
-
-
3
SLP active position range1)
1
SLP area 2 (SLP2) active
0
SLP area 1 (SLP1) active
-
The status signal "SLP active position range" al-
ways corresponds to the diagnostic signal "SLP
active position range" (r9722.19).
4, 5
Reserved
-
-
6
Safe position valid
1
Safe position valid
0
Safe position invalid
7
Safely referenced
1
Safe position is applicable as "safely referenced"
0
Safe position is not applicable as "safely refer-
enced"
1)
Signals not relevant for Extended Functions: Must not be evaluated.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
361
Data descriptions
11.6 Process data
Byte
Bit
Meaning
Remarks
3
0
F-DI 02)
1
F-DI 0 inactive
0
F-DI 0 active
1
F-DI 12)
1
F-DI 1 inactive
0
F-DI 1 active
2
F-DI 22)
1
F-DI 2 inactive
0
F-DI 2 active
3
Reserved
-
-
4
SS2E active
1
SS2E active
0
SS2E not active
5
SOS selected
1
SOS selected
0
SOS deselected
6
SLP high limit maintained1)
1
SLP: Upper limit maintained
0
SLP: Upper limit not maintained
–
The status signal "upper SLP limit maintained"
always corresponds to the diagnostic signal "up-
per SLP limit maintained" (r9722.30).
7
SLP low limit maintained1)
1
SLP: Lower limit maintained
0
SLP: Lower limit not maintained
-
The status signal "lower SLP limit maintained"
always corresponds to the diagnostic signal "low-
er SLP limit maintained" (r9722.31).
1)
Signals not relevant for Extended Functions: Must not be evaluated.
2)
Only valid for CU310-2.
11.6.2.5
S_SLS_LIMIT_A: SLS limit value input
S_SLS_LIMIT_A
● PZD3 in telegrams 901 and 902, output signals
● SLS limit value input
● Value range 1 ... 32767; 32767 ≙ 100% of the 1st SLS level
11.6.2.6
S_SLS_LIMIT_A_ACTIVE: Active SLS limit value
S_SLS_LIMIT_A_ACTIVE
● PZD3 in telegrams 901 and 902, input signals
● Active SLS limit value
● Value range 1 ... 32767; 32767 ≙ 100%
● Must only be evaluated if SLS 1 active and p9501.24 = 1.
Safety Integrated plus
362
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Data descriptions
11.6 Process data
11.6.2.7
S_CYCLE_COUNT: Counter for the safety cycle
S_CYCLE_COUNT
● PZD4 in telegrams 901 and 902, input signals
● Counter for the safety cycle
● Value range -32768 ... +32767
● May only be evaluated if the transfer of safe position values is active (p9501.25 = 1) and the
position value is valid (r9722.22 = r9722.23 = 1).
11.6.2.8
S_XIST16: Current actual position value (16 bits)
S_XIST16
● PZD5 in telegram 901, input signals
● Current actual position value (16 bits)
● Value range ±32767
● Scaling using p9574
Note
Scaling
It is not permissible that the position value transferred in S_XIST16 exceeds the value range
that can be represented. This is the reason that the safe position value of the drive (r9713[0])
can be allocated a scaling factor. The position value is divided by this factor before transfer.
As a consequence, a wider value range can be transferred with a reduced accuracy.
Example: For a position of -29.999 mm signaled in r9708[0] and r9708[1] and a scaling
factor of p9x74 = 1000, a numerical value of -29 is signaled to the controller.
● May only be evaluated if the transfer of safe position values is active (p9501.25 = 1) and the
position value is valid (r9722.22 = r9722.23 = 1).
11.6.2.9
S_XIST32: Current actual position value (32 bits)
S_XIST32
● PZD5 and PZD6 in telegram 902, input signals
● Current actual position value (32 bits)
● Value range ±737280000
● Unit: 1 μm (linear axis), 0.001 ° (rotary axis)
● May only be evaluated if the transfer of safe position values is active (p9501.25 = 1) and the
position value is valid (r9722.22 = r9722.23 = 1).
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
363
Data descriptions
11.6 Process data
11.6.2.10
S_ZSW_CAM1
S_ZSW_CAM1
S_ZSW_CAM1, Safe Cam
see function diagram [2844].
Table 11-27 Description of Safety status word Safe Cam (S_ZSW_CAM1)
Byte
Bit
Meaning
Remarks
0
0
Position at cam 1
1
Position is at cam 1
0
Position is not at cam 1
1
Position at cam 2
1
Position is at cam 2
0
Position is not at cam 2
2
Position at cam 3
1
Position is at cam 3
0
Position is not at cam 3
3
Position at cam 4
1
Position is at cam 4
0
Position is not at cam 4
4
Position at cam 5
1
Position is at cam 5
0
Position is not at cam 5
5
Position at cam 6
1
Position is at cam 6
0
Position is not at cam 6
6
Position at cam 7
1
Position is at cam 7
0
Position is not at cam 7
7
Position at cam 8
1
Position is at cam 8
0
Position is not at cam 8
1
0
Position at cam 9
1
Position is at cam 9
0
Position is not at cam 9
1
Position at cam 10
1
Position is at cam 10
0
Position is not at cam 10
2
Position at cam 11
1
Position is at cam 11
0
Position is not at cam 11
3
Position at cam 12
1
Position is at cam 12
0
Position is not at cam 12
4
Position at cam 13
1
Position is at cam 13
0
Position is not at cam 13
5
Position at cam 14
1
Position is at cam 14
0
Position is not at cam 14
6
Position at cam 15
1
Position is at cam 15
0
Position is not at cam 15
7
Position at cam 16
1
Position is at cam 16
0
Position is not at cam 16
Safety Integrated plus
364
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Data descriptions
11.6 Process data
Byte
Bit
Meaning
Remarks
2
0
Position at cam 17
1
Position is at cam 17
0
Position is not at cam 17
1
Position at cam 18
1
Position is at cam 18
0
Position is not at cam 18
2
Position at cam 19
1
Position is at cam 19
0
Position is not at cam 19
3
Position at cam 20
1
Position is at cam 20
0
Position is not at cam 20
4
Position at cam 21
1
Position is at cam 21
0
Position is not at cam 21
5
Position at cam 22
1
Position is at cam 22
0
Position is not at cam 22
6
Position at cam 23
1
Position is at cam 23
0
Position is not at cam 23
7
Position at cam 24
1
Position is at cam 24
0
Position is not at cam 24
3
0
Position at cam 25
1
Position is at cam 25
0
Position is not at cam 25
1
Position at cam 26
1
Position is at cam 26
0
Position is not at cam 26
2
Position at cam 27
1
Position is at cam 27
0
Position is not at cam 27
3
Position at cam 28
1
Position is at cam 28
0
Position is not at cam 28
4
Position at cam 29
1
Position is at cam 29
0
Position is not at cam 29
5
Position at cam 30
1
Position is at cam 30
0
Position is not at cam 30
6
Safe Cam active
1
Safe Cam is active
0
Safe Cam is not active
7
Validity of the values of Safe Cam
1
Values of Safe Cam apply
0
Values of Safe Cam do not apply
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
365
Data descriptions
11.6 Process data
11.6.3
SIC/SCC (PROFIdrive) process data
11.6.3.1
S_STW1B: Safety Control Channel control word 1
S_STW1B
Safety Control Channel control word 1
Table 11-28 Description of S_STW1B
Bit
Meaning
Remarks
Parameter
0...7
Reserved
-
-
-
8
Extended Functions test stop/forced
1
Extended Functions test stop/forced checking pro-
r10251.8
checking procedure
cedure selected
0
Extended Functions test stop/forced checking pro-
cedure deselected
9...15
Reserved
-
-
-
11.6.3.2
S_ZSW1B: SI Motion / Safety Info Channel status word
S_ZSW1B
SI Motion Safety Info Channel status word
Table 11-29 Description S_ZSW1B
Bit
Meaning
Remarks
Parameter
0
STO active
1
STO active
r9734.0
0
STO not active
1
SS1 active
1
SS1 active
r9734.1
0
SS1 not active
2
SS2 active
1
SS2 active
r9734.2
0
SS2 not active
3
SOS active
1
SOS active
r9734.3
0
SOS not active
4
SLS active
1
SLS active
r9734.4
0
SLS not active
5
SOS selected
1
SOS selected
r9734.5
0
SOS deselected
6
SLS selected
1
SLS selected
r9734.6
0
SLS deselected
7
Internal event
1
Internal event
r9734.7
0
No internal event
8
Reserved
-
-
-
Safety Integrated plus
366
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Data descriptions
11.6 Process data
Bit
Meaning
Remarks
Parameter
9
Active SLS level bit 0
-
Display of the velocity limit for SLS (2 bits)
r9734.9
10
Active SLS level bit 1
-
r9734.10
11
Reserved
-
-
-
12
SDI positive selected
1
SDI positive selected
r9734.12
0
SDI positive deselected
13
SDI negative selected
1
SDI negative selected
r9734.13
0
SDI negative deselected
14
ESR retract requested
1
ESR retract requested
r9734.14
0
ESR retract not requested
15
Safety message effective
1
Safety message effective
r9734.15
0
No Safety message effective
11.6.3.3
S_ZSW2B: Safety Info Channel status word 2
S_ZSW2B
Safety Info Channel status word 2
Table 11-30 Description of S_ZSW2B
Bit
Meaning
Remarks
Parameter
0...3
Reserved
-
-
-
4
SLP selected position range
1
SLP area 2 selected
r9743.4
0
SLP area 1 selected
5, 6
Reserved
-
-
-
7
SLP selected and user agreement
1
SLP selected and user agreement set
r9743.7
0
SLP selected or user agreement not set
8
SDI positive
1
SDI positive selected
r9743.8
0
SDI positive deselected
9
SDI negative
1
SDI negative selected
r9743.9
0
SDI negative deselected
10, 11
Reserved
-
-
-
12
Test stop active
1
Test stop active
r9743.12
0
Test stop not active
13
Test stop required
1
Test stop required
r0743.13
0
Test stop not required
14, 15
Reserved
-
-
-
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
367
Data descriptions
11.6 Process data
11.6.3.4
S_STW3B: Safety Control Channel control word 3
S_STW3B
Safety Control Channel control word 3
Table 11-31 Description of S_STW3B
Bit
Meaning
Remarks
Parameter
0
Select brake test
1
Brake test selected
r10231.0
0
Brake test deselected
1
Start brake test
1
Start brake test requested
r10231.1
0
Start brake test not requested
2
Brake selection
1
Test brake 2 selected
r10231.2
0
Test brake 1 selected
3
Select direction of rotation
1
Negative direction selected
r10231.3
0
Positive direction selected
4
Select test sequence
1
Test sequence 2 selected
r10231.4
0
Test sequence 1 selected
5
Status of external brake
1
External brake closed
r10231.5
0
External brake open
6...15
Reserved
-
-
-
11.6.3.5
S_ZSW3B: Safety Info Channel status word 3
S_ZSW3B
Safety Info Channel status word 3
Table 11-32 Description of S_ZSW3B
Bit
Meaning
Remarks
Parameter
0
Brake test
1
Brake test selected
r10234.0
0
Brake test deselected
1
Setpoint input, drive/external1)
1
Setpoint specification for the drive
r10234.1
0
Setpoint specification, external (controller)
2
Active brake
1
Test brake 2 active
r10234.2
0
Test brake 1 active
3
Brake test active
1
Test active
r10234.3
0
Test inactive
4
Brake test result
1
Test successful
r10234.4
0
Test error
5
Brake test completed
1
Test run
r10234.5
0
Test incomplete
Safety Integrated plus
368
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Data descriptions
11.6 Process data
Bit
Meaning
Remarks
Parameter
6
External brake request
1
Close brake
r10234.6
0
Open brake
7
Current load sign
1
Negative sign
r10234.7
0
Positive sign
8...13
Reserved
-
-
-
14
Acceptance test SLP (SE) selected
1
Acceptance test SLP (SE) selected
r10234.14
0
Acceptance test SLP (SE) deselected
15
Acceptance test mode selected
1
Acceptance test mode selected
r10234.15
0
Acceptance test mode deselected
1)
Setpoint input for the drive: The speed setpoint is entered by the function SBT.
External setpoint input (open-loop control): The "normal" speed setpoint is effective.
11.6.3.6
S_V_LIMIT_B: Safety Info Channel setpoint velocity limiting
S_V_LIMIT_B
SLS speed limit with a 32-bit resolution with sign bit.
Table 11-33 Description S_V_LIMIT_B
Parameter
Meaning
r9733[2]
SLS speed limit
p2000
Scaling of the SLS velocity limit
S_V_LIMIT_B = 4000 0000 hex ≐ speed in p2000
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
369
Data descriptions
11.7 Interface signals: Axis/spindle signals
11.7
Interface signals: Axis/spindle signals
As PLC user interface, certain axis-specific signals are mapped from the SIC/SCC (Page 205)
in the axis DB (Page 206):
● DB31 … DB61, Safety Info Channel (SIC)
● DB31 … DB61, Safety Control Channel (SCC)
This means, for example, that you can perform the brake test via the PLC user program.
Additional information
List Manual "SINUMERIK 840D sl, NC Variables and Interface Signals".
Safety Integrated plus
370
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
System features
12
12.1
Latest information
Important note for maintaining the operational safety of your system:
Note
Requirements for operational safety
Systems with safety-related characteristics are subject to special operational safety
requirements on the part of the operating company. The supplier is also obliged to comply with
special product monitoring measures. For this reason, we publish a special newsletter
containing information on product developments and features that are (or could be) relevant
when operating safety-related systems.
● You should subscribe to the corresponding newsletter in order to obtain the latest
information and to allow you to modify your equipment accordingly.
Subscribing to the Safety Newsletter
1. Go to the following Internet address in your browser:
2. Select the desired language for the Web page.
3. You have to register and log in if you want to subscribe to any newsletters. Please proceed
as follows if you have still not registered:
- Click on "Login / registration".
- Login with your access data. If you do not yet have a login and password, select "Yes, I
would like to register now".
You can subscribe to the individual newsletters in the following window.
4. Activate the "All Newsletters" tab.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
371
System features
12.1 Latest information
5. In the list, open the "Products and solutions" topic.
You will now be shown which newsletter is available for this particular subject area or topic.
You can subscribe to the appropriate newsletter by clicking on the "Subscribe" entry. If you
require more detailed information on the newsletters, then please use the supplementary
function on the website.
Figure 12-1
Ordering the newsletter
6. Subscribe to the "Safety Integrated Internal News" Newsletter.
Safety Integrated plus
372
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
System features
12.2 Response times
12.2
Response times
The Basic Functions are executed in the monitoring cycle (p9780). PROFIsafe telegrams are
evaluated in the PROFIsafe scan cycle, which corresponds to twice the monitoring clock cycle
(PROFIsafe scan cycle = 2 · r9780).
Note for understanding the tables
The drive system is the component that provides the safety functions. The designation "fault-
free drive system" means that the component that provides the safety functions does not have
a defect itself:
● Worst case for a fault-free drive system
For faults outside the drive system, such as e.g. faulty setpoint input from a control system,
limit value violations as a result of the behavior of the motor, closed-loop control, load, etc.,
the "Worst case for a fault-free drive system" response time is guaranteed.
● Worst case when a fault exists
For a single fault within the drive system, such as a defect in a switch-off signal path of the
power unit, a defect in an encoder actual value measurement, a defect in a microprocessor
(Control Unit or Motor Module) etc., the "Worst case when a fault exists" response time is
guaranteed.
12.2.1
Controlling Basic Functions via terminals on the Control Unit and Motor Module
The following table lists the response times from the control via terminals until the response
actually occurs.
Table 12-1
Response times for control via terminals on the Control Unit and the Motor Module.
Function
Worst case for
Drive system has no fault
A fault is present
STO
2 · r9780 + t_E1)
3 · r9780 + t_E1)
SBC
4 · r9780 + t_E1)
8 · r9780 + t_E1)
SS1/SS1E (time-controlled)
Selection until STO is initiated
2 · r9780 + p9652 + t_E1)
3 · r9780 + p9652 + t_E1)
SS1/SS1E (time-controlled)
Selection until SBC is initiated
4 · r9780 + p9652 + t_E1)
8 · r9780 + p9652 + t_E1)
SS1 (time-controlled)
Selection until braking is initiated
3 · r9780 + 2 ms + t_E1)
4 · r9780 + 2 ms + t_E1)
1)
The following applies for t_E (debounce time of the digital input being used):
p9651 = 0
t_E = 2 · p0799 (default = 4 ms)
p9651 ≠ 0
t_E = p9651 + p0799 + 1 ms
The minimum time for t_E is t_E_min = 2 ms.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
373
System features
12.2 Response times
12.2.2
Controlling the Basic Functions via PROFIsafe
The following table lists the response times1) from receiving the PROFIsafe Telegram in the
drive up to initiating the particular response.
Table 12-2
Response times when controlling via PROFIsafe
Function
Worst case for
Drive system has no fault
A fault is present
STO
5 · r9780 + t_E2)
5 · r9780 + t_E2)
SBC
6 · r9780 + t_E2)
10 · r9780 + t_E2)
SS1/SS1E (time-controlled)
Selection until STO is initiated
5 · r9780 + p9652 + t_K2)
5 · r9780 + p9652 + t_K2)
SS1/SS1E (time-controlled)
Selection until SBC is initiated
6 · r9780 + p9652 + t_K2)
10 · r9780 + p9652 + t_K2)
SS1 (time-controlled)
Selection until braking is initiated
5 · r9780 + 2 ms + t_K2)
5 · r9780 + 2 ms + t_K2)
1)
The specified response times involve internal SINAMICS response times. Program run times in the F-host and the
transmission time via PROFIBUS or PROFINET are not taken into account. When calculating the response times between
the F-CPU and the converter, you must take into account that faults in the communication can result in a safety function only
being selected after the PROFIsafe monitoring time (F_WD_Time) has expired. The PROFIsafe monitoring time
(F_WD_Time) must also be included in the calculation when an error occurs.
2)
t_K is the time for internal communication within the SINAMICS module; t_K can be determined as follows:
t_K = To (for To, see parameter r2064[4])
12.2.3
Controlling the Extended Functions via PROFIsafe
The following table lists the response times1) 2) from receiving the PROFIsafe Telegram in the
drive up to initiating the particular response.
Table 12-3
Response times when controlling via PROFIsafe
Function
Worst case for
Drive system has no fault
A fault is present
STO
5 · p95008) + r9780 + t_K6)
5 · p95008) + 2 · r9780 + t_K6)
SBC
5 · p95008) + 2 · r9780 + t_K6)
5 · p95008) + 6 · r9780 + t_K6)
SS1 (time controlled), SS1E, SS2E: Time from select-
ing up to starting the safe timer
SS1 (acceleration controlled), SS2: Time from select-
ing up to initiating braking
5 · p95008) + 2 ms + t_K6)
5 · p95008) + 2 ms + t_K6)
SOS: Time from selecting up to starting standstill mon-
itoring
SBR or SAM (limit value violation until STO active)
2 · p9500 + r9780
2.5 · p9500 + r9780 + t_ACT5)
SOS standstill tolerance window violated
1.5 · p9500 + 2 ms
3 · p9500 + 2 ms + t_ACT5)
SLS speed limit violated 3)
2 · p9500 + 2 ms
3.5 · p9500 + 2 ms + t_ACT5)
SSM4)
4 · p9500
4.5 · p9500 + t_ACT5)
SDI (limit value violation until braking is initiated)
1.5 · p9500 + 2 ms
3 · p9500 + 2 ms + t_ACT5)
Safety Integrated plus
374
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
System features
12.2 Response times
Function
Worst case for
Drive system has no fault
A fault is present
SLA 9): Selection or deselection
5 · p95008) + t_K
5 · p95008) + t_K
3 · p9500 + 2 ms
4 · p9500 + 2 ms + t_act
SLA: Limit value violation
SLP (limit value violation until a response is initiated)
1.5 · p9500 + 2 ms
3 · p9500 + 2 ms + t_ACT5)
SCA: Time between violation of a cam start or end po-
sition and output of the feedback message in
3.5 · p9500
4 · p9500 + t_ACT5)
S_ZSW_CAM1
SP7) with isochronous PROFIsafe telegram
3 · p9500
3 · p9500 + t_ACT5)
1)
The specified response times are valid for Extended Functions with and without selection.
2)
The specified response times involve internal SINAMICS response times. Program run times in the F-host and the
transmission time via PROFIBUS or PROFINET are not taken into account. When calculating the response times between
the F-CPU and the converter, you must take into account that faults in the communication can result in a safety function only
being selected after the PROFIsafe monitoring time (F_WD_Time) has expired. The PROFIsafe monitoring time
(F_WD_Time) must also be included in the calculation when an error occurs.
3)
SLS: Specification of the response time required to initiate a braking response in the drive - or for the output of the "SOS
selected" message to the motion control system.
4)
SSM: The data corresponds to the times between the limit value being undershot up to sending the information via
PROFIsafe.
5)
t_ACT:
For p9511 ≠ 0
t_ACT = p9511
For p9511 = 0
t_ACT = PROFIBUS cycle
6)
t_K is the time for internal communication within the SINAMICS module; t_K can be determined as follows:
t_K = To (for To, see parameter r2064[4])
7)
SP: The data corresponds to the times between acquisition of the safe position and transfer of the safe position via
PROFIsafe.
8)
For the best possible execution (relating to time) on the F-CPU this component is reduced from 5 · p9500 to 3 · p9500.
9)
In SINUMERIK Operate, the settings for SLA can only be made via the parameter list.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
375
System features
12.2 Response times
Safety Integrated plus
376
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Switchover from Safety Integrated (system-integrated)
13
13.1
Overview
If you previously worked with SINUMERIK Safety Integrated (SPL), the information provided in
this chapter can make it easier for you to switch over to Safety Integrated plus:
● Comparison of the safety functions (Page 378)
● Additional differences when commissioning (Page 383)
● Procedure when switching over between systems (Page 393)
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
377
Switchover from Safety Integrated (system-integrated)
13.2 Comparison of the safety functions
13.2
Comparison of the safety functions
13.2.1
Overview
The safety functions of SINUMERIK Safety Integrated - integrated in the system - use, in some
instances, their own function names. The names of the safety functions of Safety Integrated
plus, integrated in the system, correspond to the SINAMICS safety functions, and are therefore
orientated to DIN EN 60204-1.
These names are compared in this chapter.
For Safety Integrated plus, the drive-integrated safety functions available with Safety
Integrated (STO, SBC, SS1), belong to the Basic Functions - and are available with the same
function names. These are not listed here.
Table 13-1
Comparison of the system-integrated safety functions (Safety Integrated) and Extended Functions integrated in
the drive (Safety Integrated plus)
Safety Integrated
Safety Integrated plus
Additional information
External STOP A
Stop A/SH
Safe Torque Off
STO
(Safe Torque Off)
Safe Stop 1
SS1
(Safe stop in accordance with
stop Category 1)
Ext. STOP C
STOP C
Safe Stop 2
SS2
(Safe stop in accordance with
stop Category 2)
Ext. STOP D
STOP D
Safe Stop 2e
SS2e
Ext. STOP E
STOP E
--*
--*
*Available as stop response when
SLS/SLP is exceeded (Page 379)
Safe operating stop
SBH
Safe Operating Stop
SOS
(Safe operating stop)
Safely-Limited Speed
SG
Safely Limited Speed
SLS
(Safely-Limited Speed)
SG override
Override
SLS override
Enters the correction factor in the
for SG
safety program via PROFIsafe
(32 SG levels can be selected
(Page 380)
via SPL)
Safe Acceleration Monitoring
SBR
Safe Acceleration Monitor
SAM
(Safe Acceleration Monitoring)
--
--
Safe Brake Ramp
SBR
(Safe brake ramp monitoring)
Safety-relevant output signal
n<nx
Safe Speed Monitor
SSM
n<nx
(Safe Speed Monitor)
--
--
Safe Direction
SDI
(Safe motion direction)
Safe end positions
SE
Safely-Limited Position
SLP
(Safely-Limited Position)
Safety Integrated plus
378
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3