SINUMERIK 840D sl. Service - Configuring Commissioning. Manual (2011-2020) - page 88
Safety functions integrated in the drive
5.4 SBC (Basic/Extended)
● p9602
SI enable safe brake control (Control Unit)
● p9621
BI: SI Safe Brake Adapter signal source (Control Unit)
● p9622[0...1]
SI SBA relay wait times (Control Unit)
● r9771.14
SI common functions (Control Unit): SBC supported for parallel connec-
tion
● r9780
SI monitoring cycle (Control Unit)
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
103
Safety functions integrated in the drive
5.5 SS2
5.5
SS2
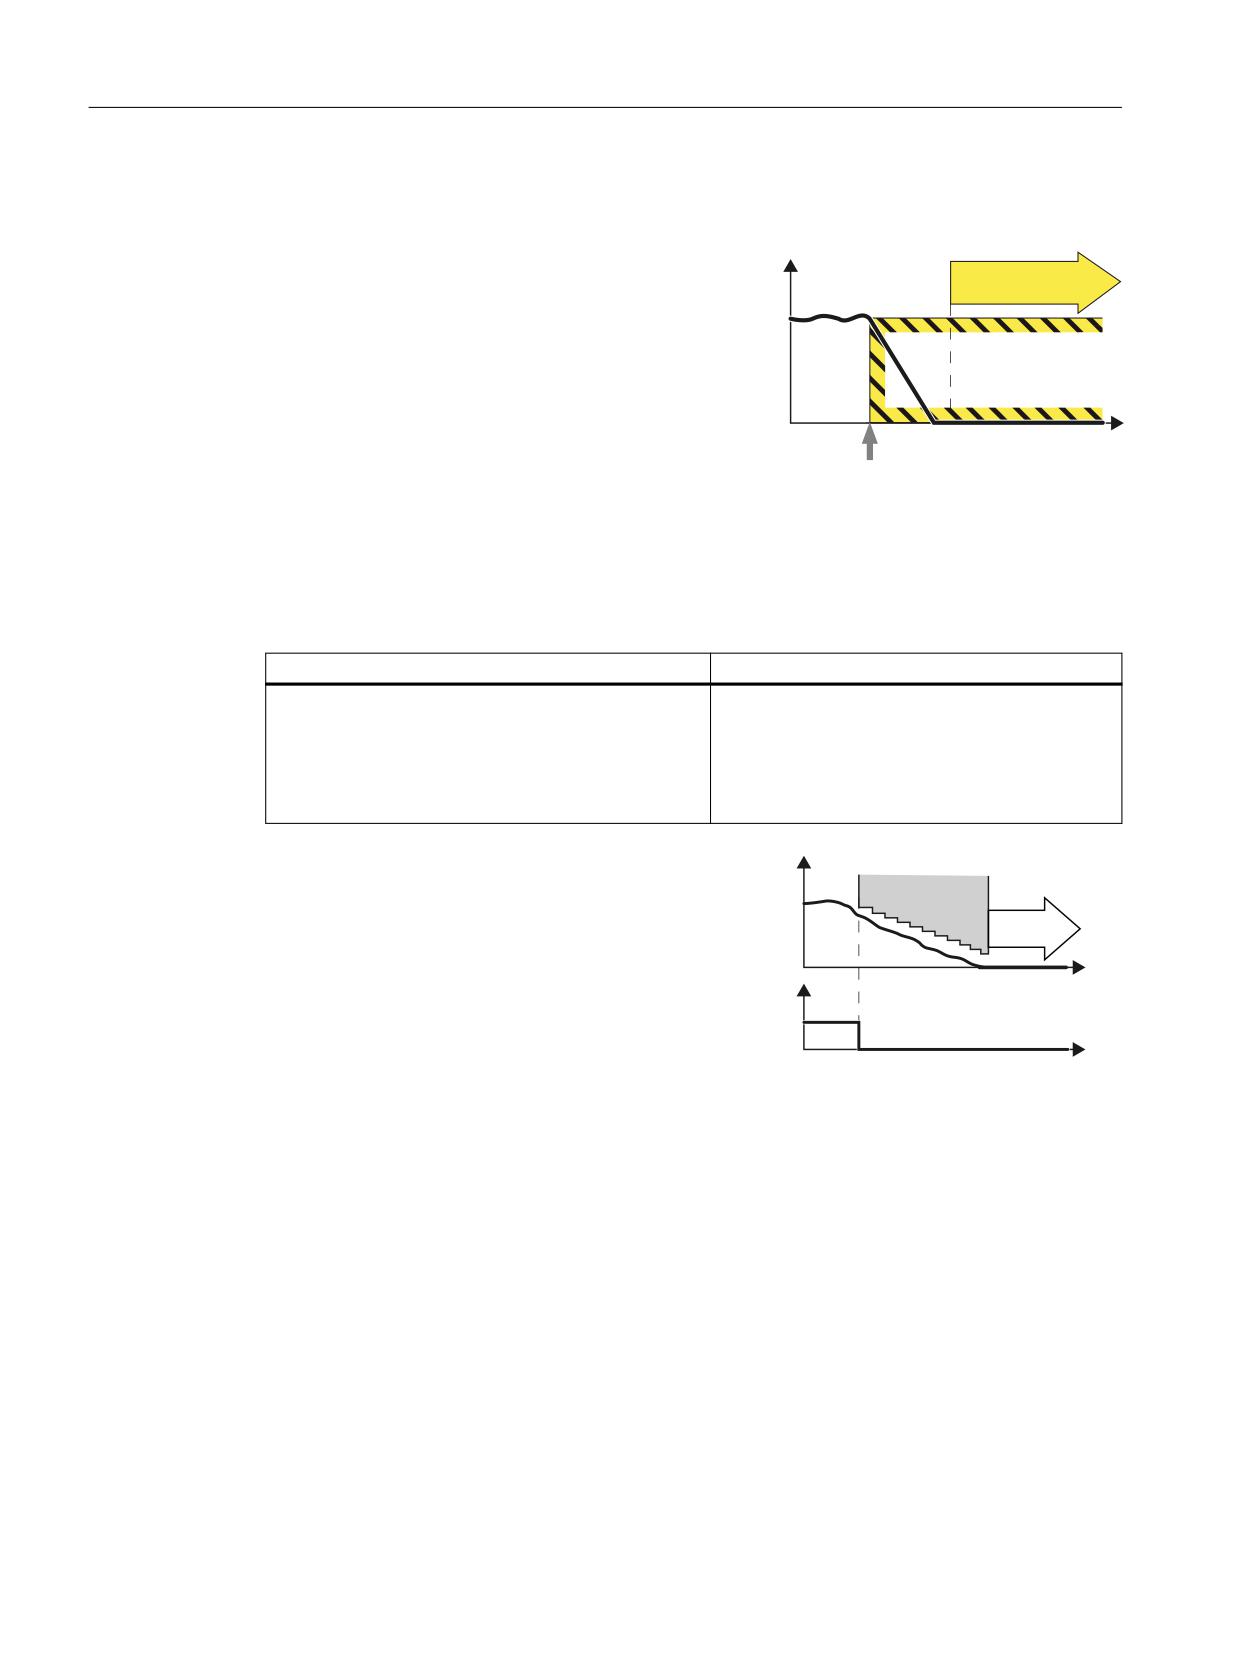
Definition according to EN 61800-5-2:
Y
SOS
The SS2 function brings the motor to a standstill with
subsequent safe monitoring of the standstill position.
When SS2-r is selected, the drive brakes the motor
along a braking ramp. The following variants are pos-
sible:
● SS1-a with acceleration monitoring (SAM)
W
● SS1-r with braking ramp monitoring (SBR)
● Manually set delay time until SOS is activated.
Select SS2
This function corresponds to stop category 2 to
EN 60204-1.
Example of how the function can be used
Example
Solution
A protective door must only be opened if a motor is in
● Select SS2 in the converter via a terminal or
the safe standstill state.
via PROFIsafe .
● After braking, the converter goes into the
SOS state. Only then may the protective
door be released.
The safety function SS2 monitors the
6SHHG
load speed and initiates the SOS function
0RQLWRULQJ
if the SS2 delay time has expired.
626
With SS2, braking is monitored on the
OFF3 ramp. A faulty acceleration is de-
W
66
GHVHOHFWLRQ
tected and the drive then shuts down with
352),VDIH
STO.
FRQWURO ZRUG
W
If you are operating the motor with closed-loop torque control, the converter switches to the
closed-loop speed control mode when SS2 is selected.
Safety Integrated plus
104
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.5 SS2
How does SS2 function in detail?
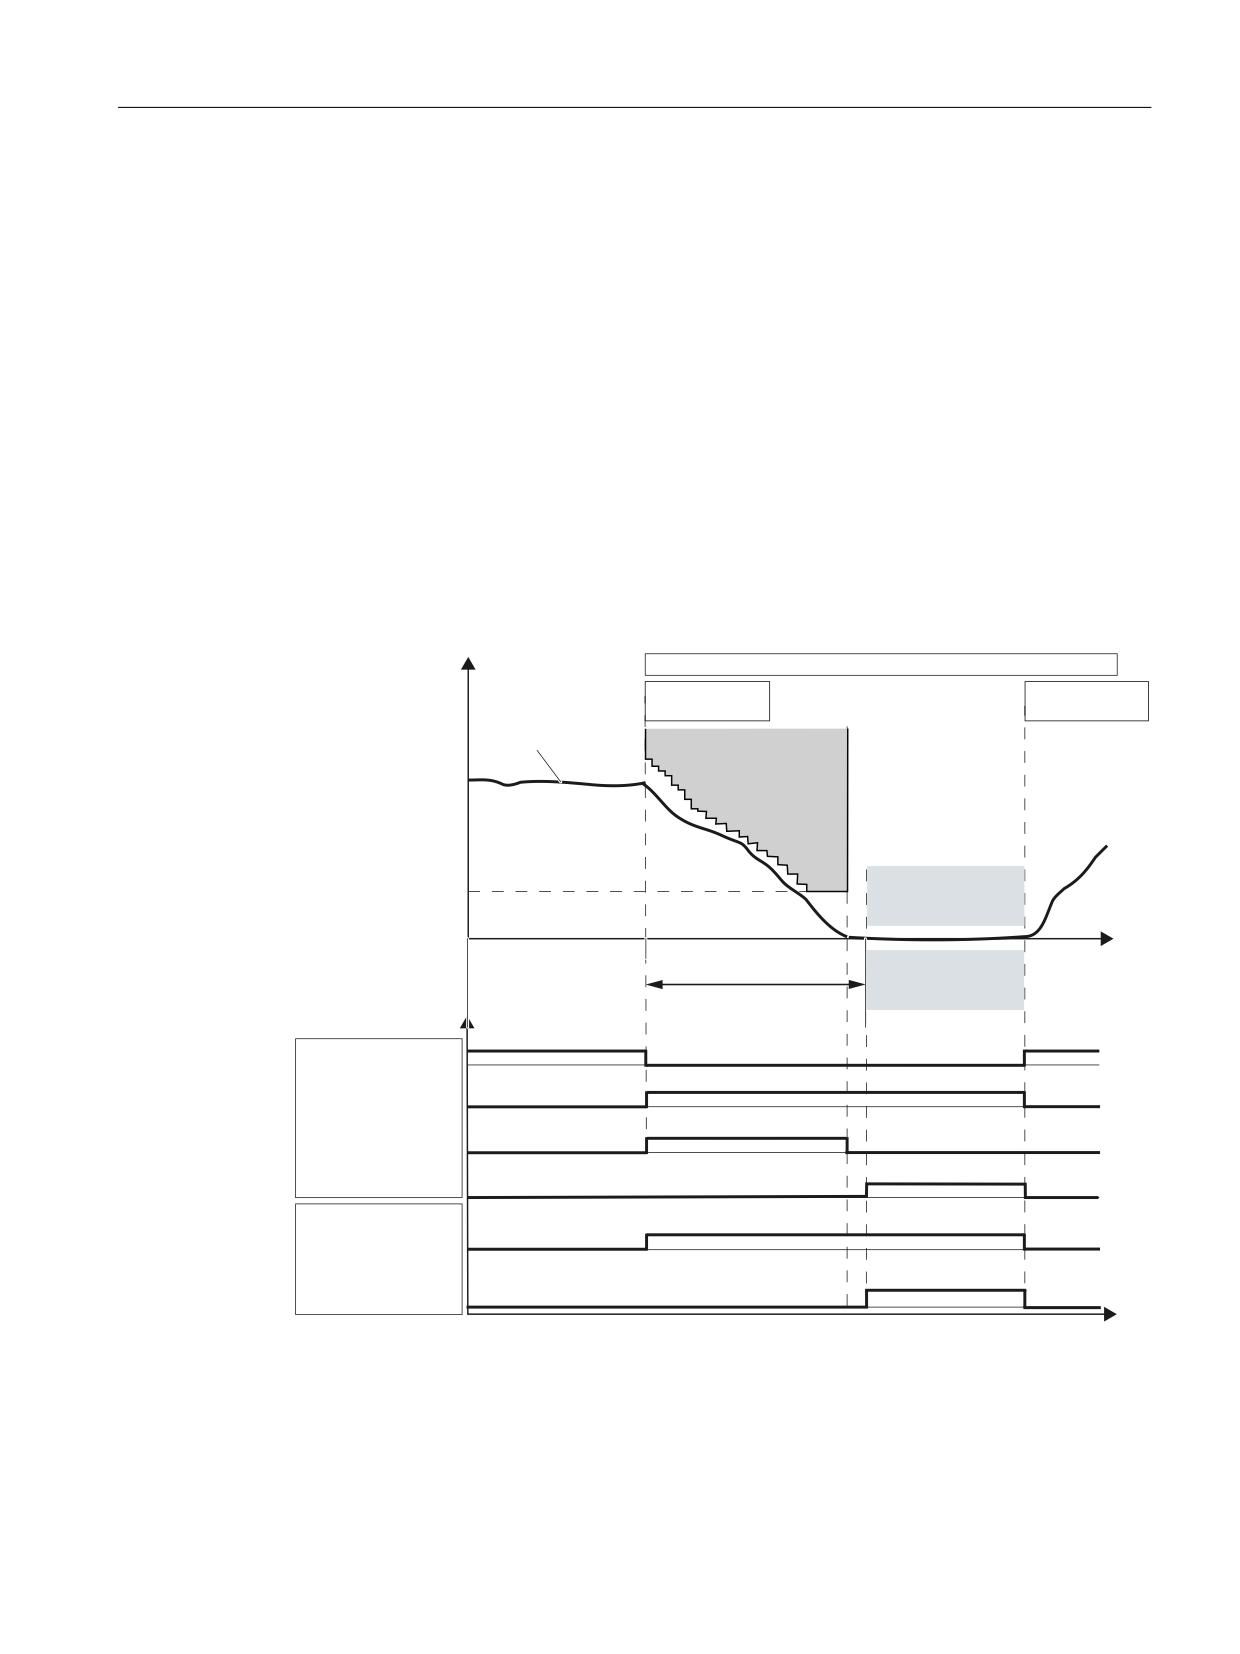
The failsafe logic (e.g. F-PLC) selects the SS2 safety function via a failsafe input or via the
PROFIsafe safe communication.
● If, when selecting SS2, the motor is already at a standstill, after a delay time, the converter
activates the Safe Operating Stop function (SOS).
● If the drive is not at standstill when SS2 is selected, it is braked along the OFF3 ramp.
Braking is monitored with one of the following functions, depending on the setting in p9506:
- Safe Acceleration Monitor (SAM)
A faulty acceleration is therefore detected.
- Safe Brake Ramp (SBR)
In this way, a violation of the braking ramp is detected.
After a delay time, the converter activates the Safe Operating Stop function (SOS). This
function monitors the safe standstill of the drive.
Braking behavior
/RDG VSHHG
2SHUDWRU DFWLRQV
6HOHFW 66
'HVHOHFW 66
$FWXDO YDOXH
6$0
6$0 VSHHG OLPLW
626
W
626
'HOD\ WLPH 66
'LDJQRVWLFV
'HVHOHFW 66
66
DFWLYH
6$0 6%5 DFWLYH
626 DFWLYH
352),VDIH
66
DFWLYH
6WDWXV ZRUGb ELWb
626 DFWLYH
6WDWXV ZRUGb ELWb
W
Figure 5-6
Braking behavior and diagnostics (example for SS2 with SAM)
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
105
Safety functions integrated in the drive
5.5 SS2
Note
SS2 with external stop (SS2E)
If you use SS2E, neither of the two monitoring functions (SBR, SAM) is active. The drive is
decelerated by interpolation (SIC/SCC is required for this). SOS becomes active after the delay
time expires.
5.5.1
Details and parameterization
Note
SS2 only with encoder
The "Safe Stop 2" (SS2) safety function can only be used with an encoder.
The "Safe Stop 2" (SS2) function is used to brake the motor safely along the OFF3 deceleration
ramp (p1135) with subsequent transition to the SOS state (see "Safe Operating Stop") after the
delay time expires (p9552). The delay time set must allow the drive to brake to a standstill from
every speed of the operating process within this time. The standstill tolerance (p9530) may not
be violated after this time.
After braking, the drives remain in speed control mode with the speed setpoint n = 0. The full
torque is available.
When braking, one of the following functions is active:
● For p9506 = 0, the following applies:
Braking is monitored with the "Safe Acceleration Monitor" function (see Chapter "SAM
(Page 137)").
● For p9506 = 2, the following applies:
Here, also for SS1, the monitoring function "Safe Brake Ramp" is active (see Chapter "SBR
(Page 139)").
The selection and monitoring of the acceleration (SAM) are realized through two channels -
however, braking along the OFF3 ramp, only through one channel.
● Effect on "Setpoint speed limit effective" (r9733[0...2]):
If SS2 (≙ STOP C), a setpoint of 0 is specified in r9733[0...2].
Safety Integrated plus
106
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.5 SS2
Responses
● Speed limit violated (SAM):
- STOP A
- Safety message C01706
● Standstill tolerance violated in p9530 (SOS):
- STOP B with subsequent STOP A
- Safety message C01707
● System fault:
- STOP F with subsequent STOP A
- Safety message C01711
Function diagrams (see SINAMICS S120/S150 List Manual)
●
2814
SI Basic Functions - SBC (Safe Brake Control), SBA (Safe Brake Adapt-
er)
Overview of important parameters (see SINAMICS S120/S150 List Manual)
● p1135[0...n]
OFF3 ramp-down time
● p9501
SI Motion enable safety functions (Control Unit)
● p9530
SI Motion standstill tolerance (Control Unit)
● p9548
SI Motion SAM actual speed tolerance (Control Unit)
● p9552
SI Motion transition time STOP C to SOS (SBH) (Control Unit)1)
● r9722.0...15
CO/BO: SI Motion drive-integrated status signals
1) STOP C corresponds to SS2.
5.5.1.1
SS2 with external stop (SS2E)
WARNING
Unexpected axis motion when the SS2E function is activated
When the SS2E function is active, during the safety delay time, until SOS is reached, axis
motion that is not monitored can occur. This can result in death or severe injury.
● During this time, prevent persons from entering the hazardous area around the axis, e.g.
by providing protective doors or other suitable protective equipment.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
107
Safety functions integrated in the drive
5.5 SS2
66 ( GHVHOHFWLRQ
W
6SHHG
S
W
66 ( DFWLYH
W
626 DFWLYH
W
6$0 6%5 DFWLYH
W
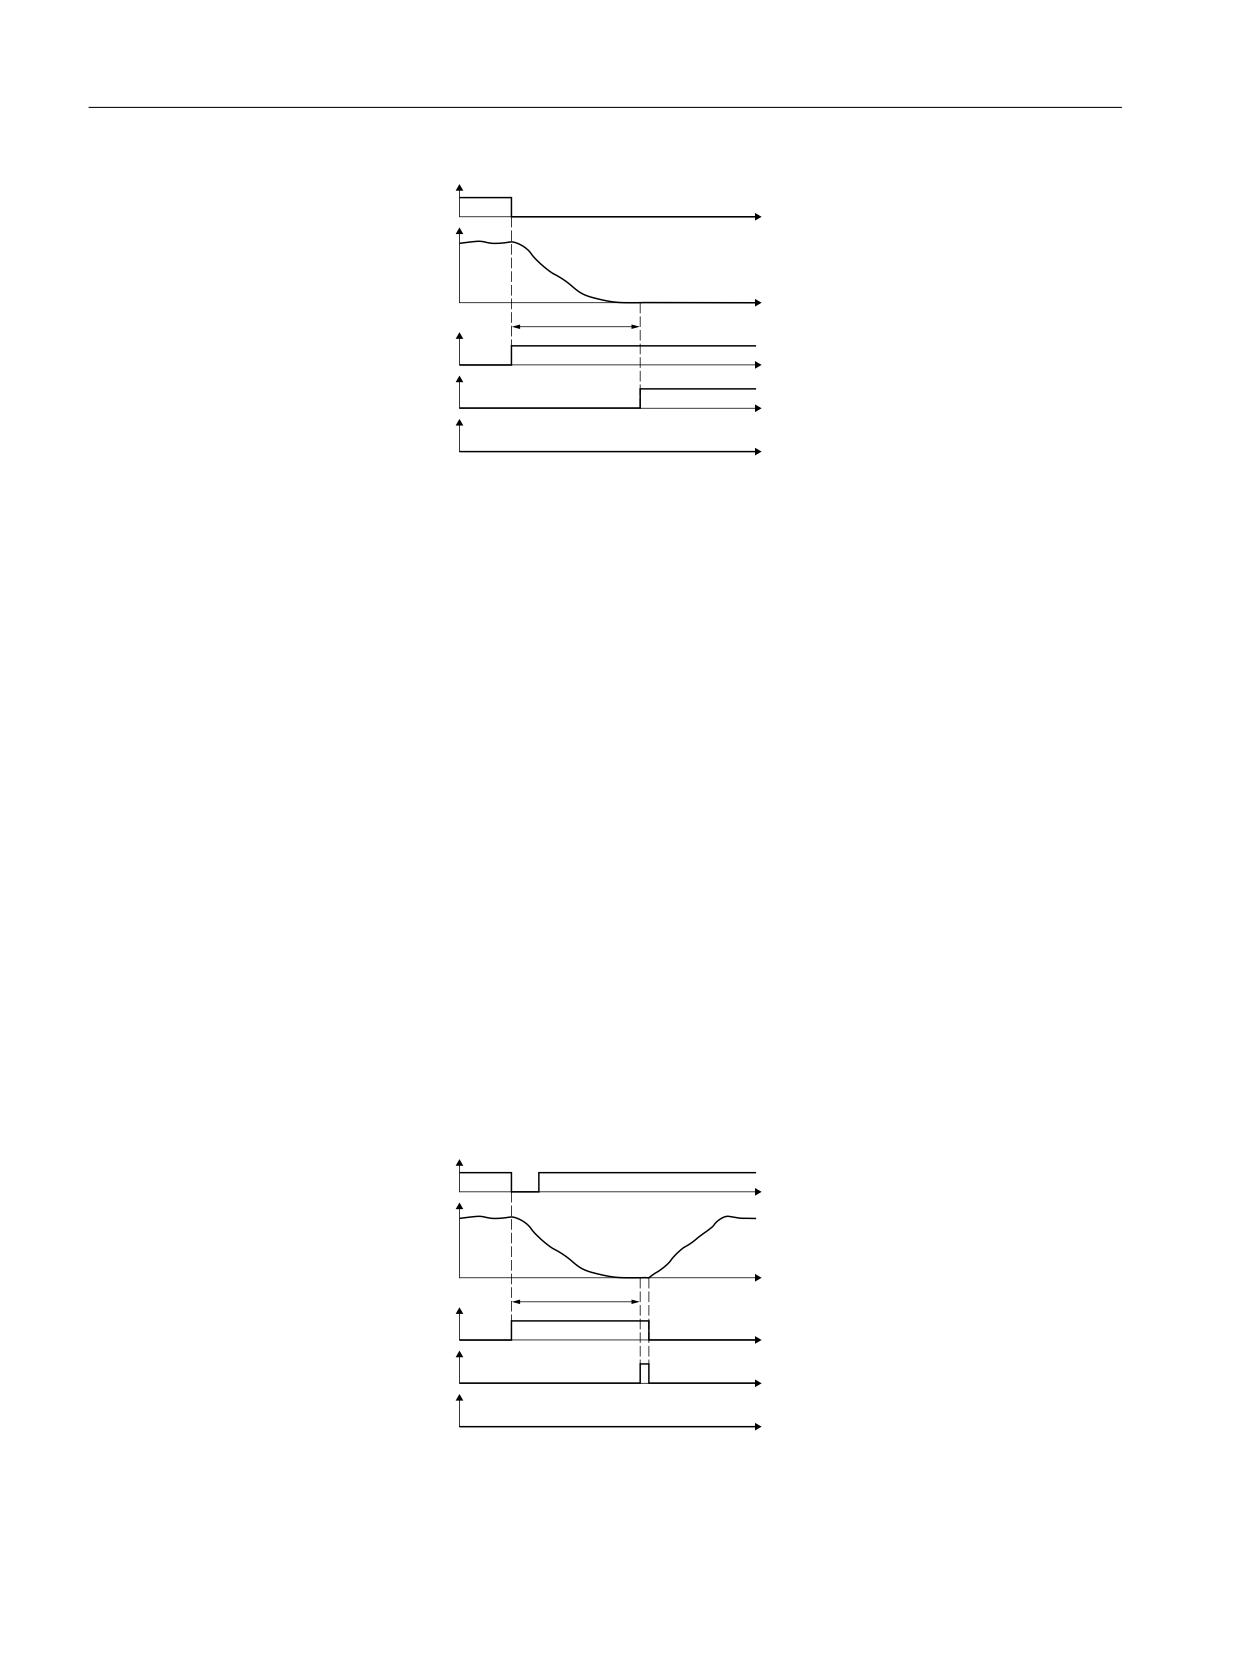
Figure 5-7
Selecting function SS2E
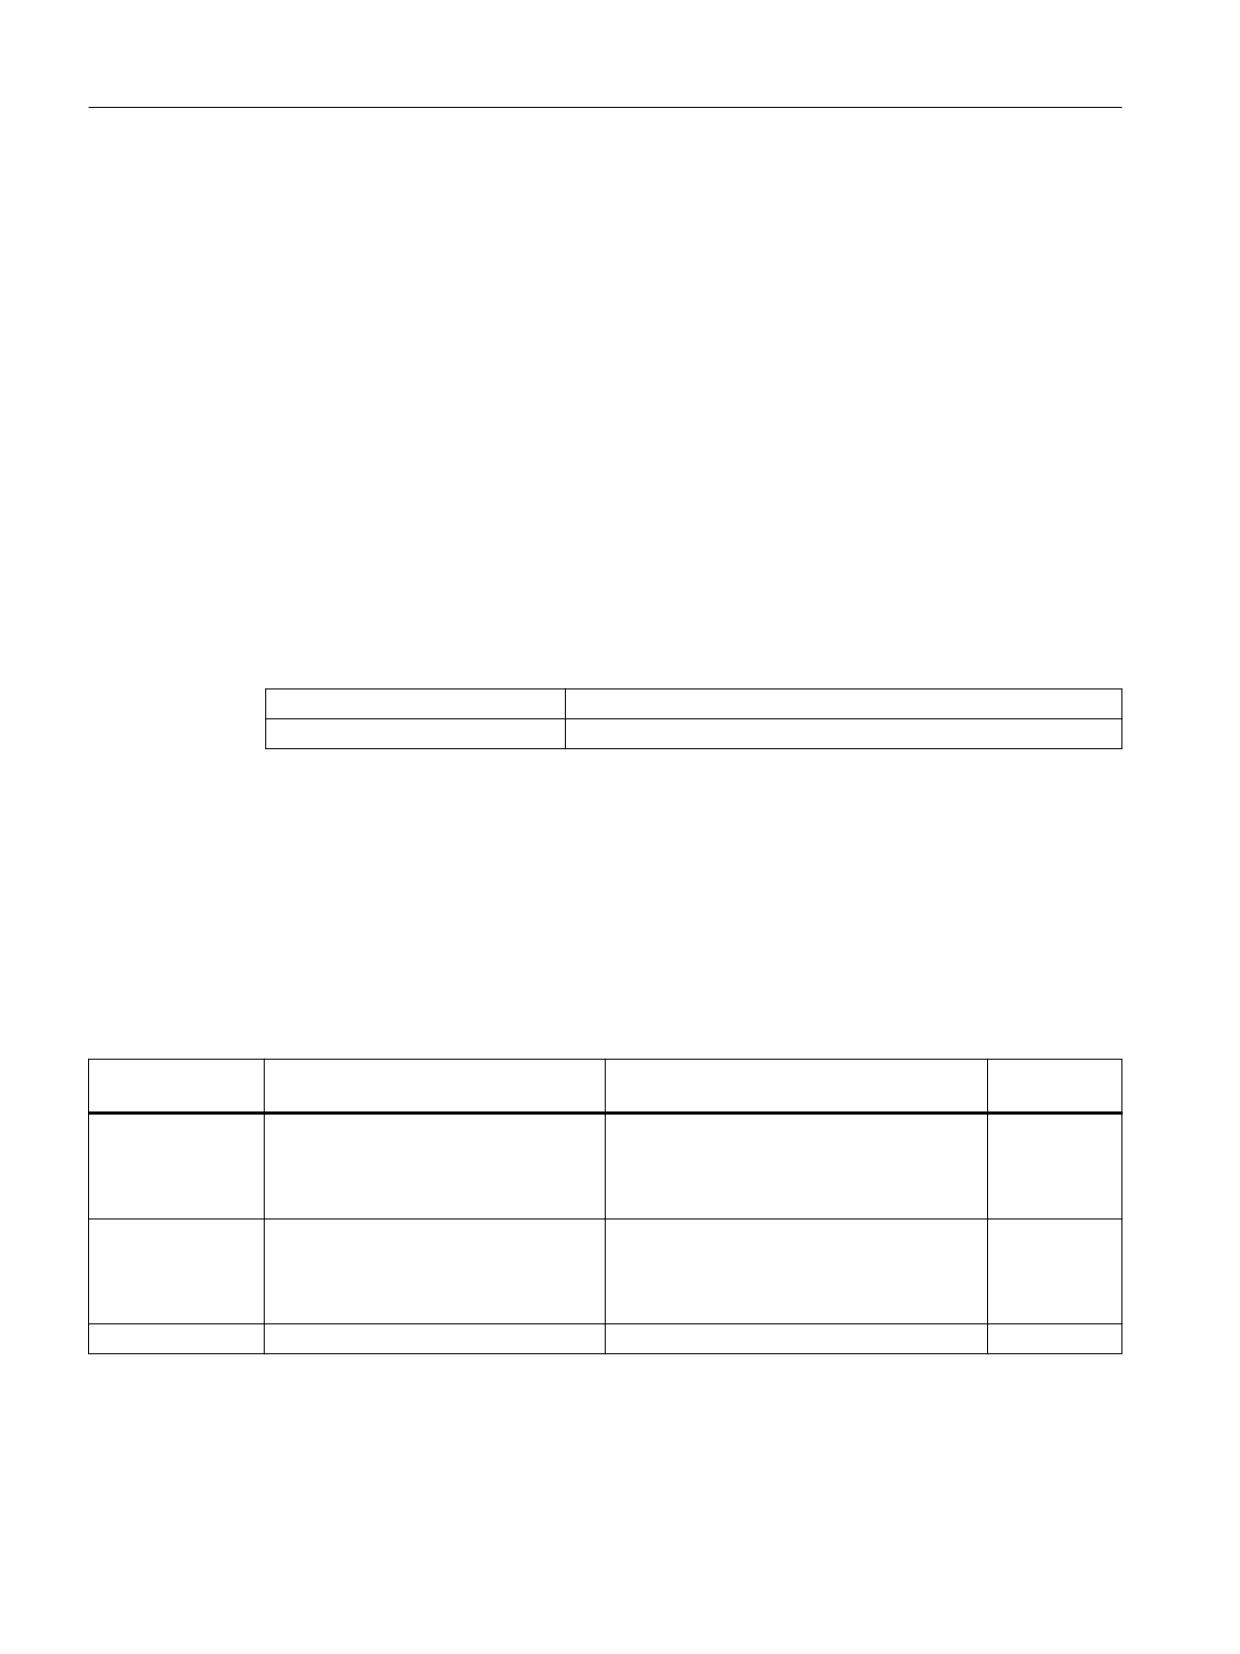
With external stop, "Safe Stop 2" functions in principle exactly the same way as described in the
previous sections. Note, however, the following differences:
Differences between "Safe Stop 2 with OFF3" and "SS2 with external stop (SS2E)"
● When SS2 is selected with external stop, the drive does not automatically brake the motor,
but instead, follows the specified speed setpoint.
● During delay time p9553, the brake ramp (SBR) and the acceleration (SAM) are not
monitored and there is no standstill detection.
● SOS becomes active after the delay time p9553 expires.
P9553 must be set in such a way that the axes are braked to a standstill with the set
dynamics.
● In order to activate "Safe Stop 2 with external stop", set p9501.18 = 1.
● The PROFIsafe control word S_STW2.28 selects the SS2E function. PROFIsafe
S_STW2.28 is contained in telegrams 31, 901, 902 and 903.
● The PROFIsafe status word S_ZSW2.28 indicates whether the SS2E function is active. The
PROFIsafe status word S_ZSW2.28 is contained in telegrams 31, 901, 902 and 903. The
associated diagnostics parameter is r9722.28.
In the "Safety Info Channel", status word S_ZSW3B.11 indicates whether function SS2E is
active. The associated diagnostics parameter is r10234.11.
Diagnostic parameters p9722.28 and p10234.11 are also set during an internal STOP D.
Deselecting function SS2E while SS2E is active
66 ( GHVHOHFWLRQ
W
6SHHG
W
S
66 ( DFWLYH
W
626 DFWLYH
W
6$0 6%5 DFWLYH
W
Figure 5-8
Deselecting function SS2E while SS2E is active
Safety Integrated plus
108
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.5 SS2
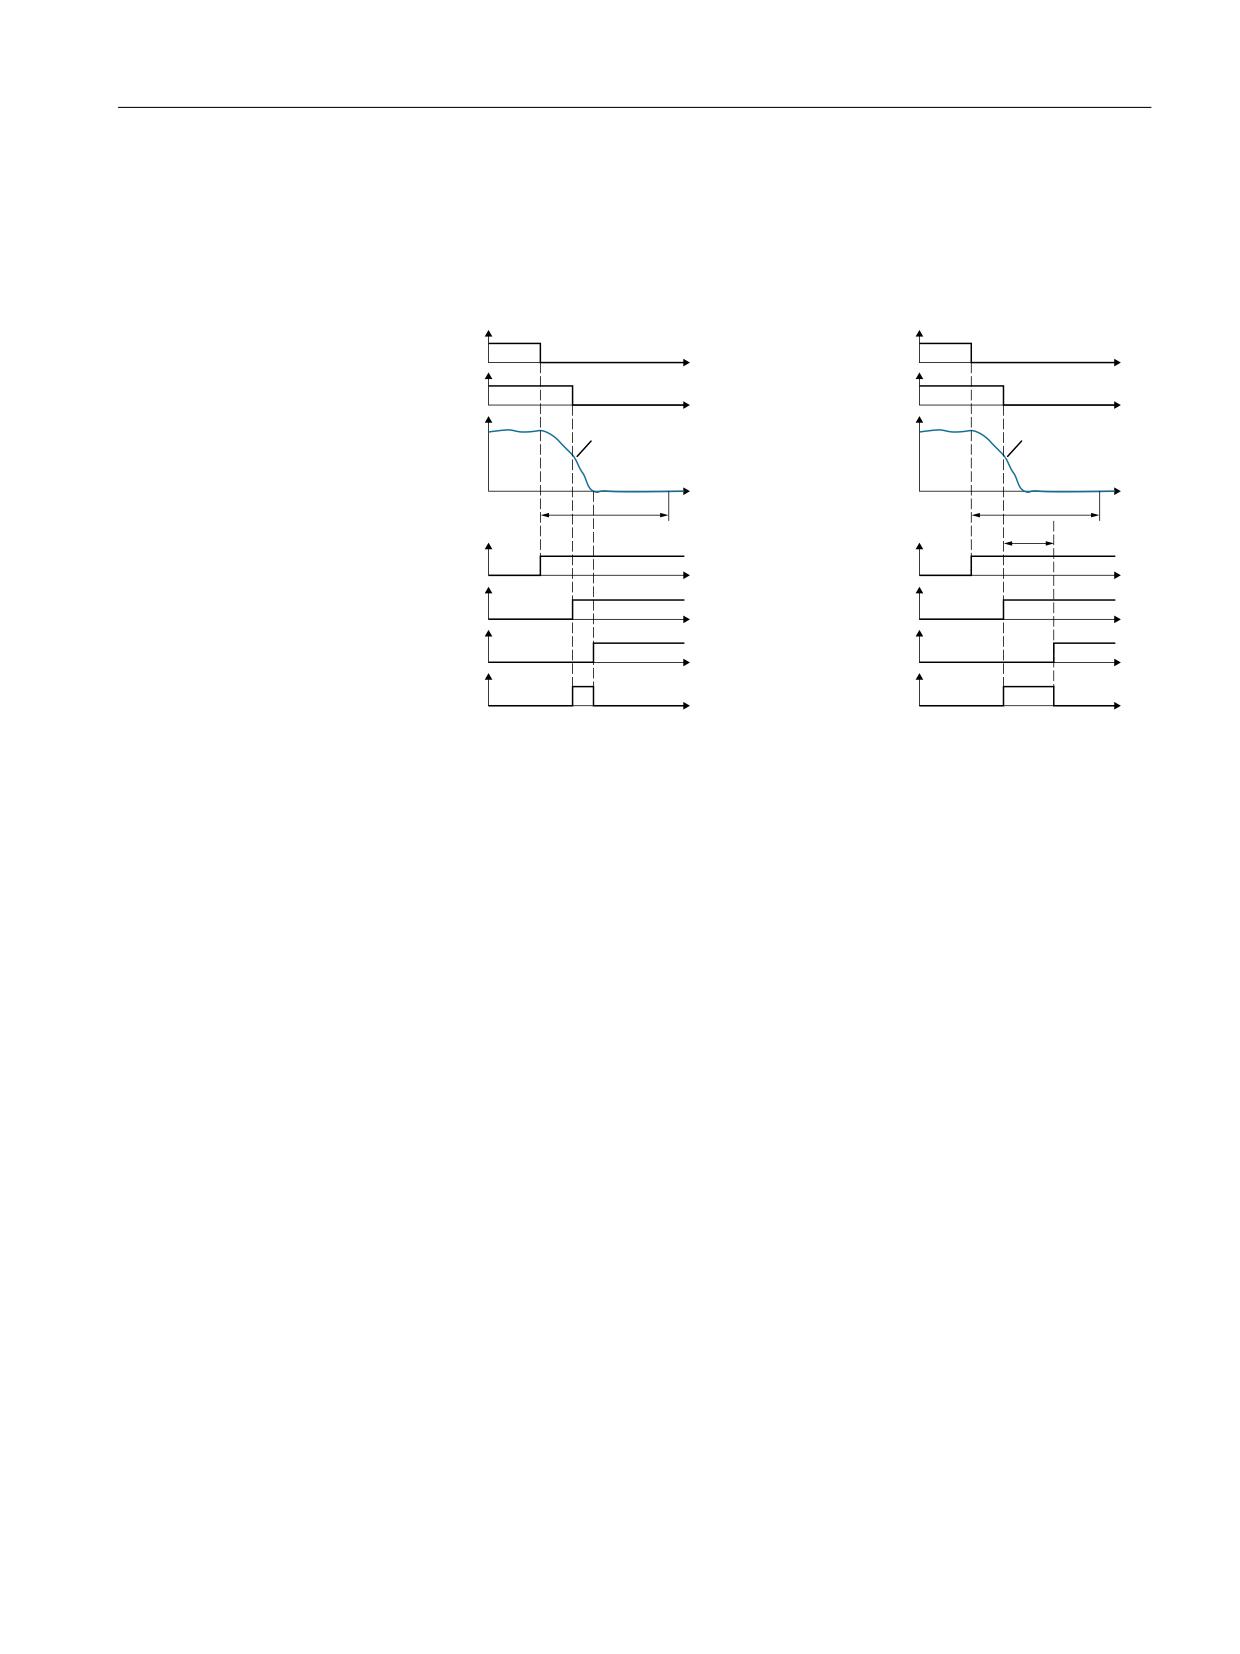
After the function has been selected, the delay time starts to expire - even if the function is
deselected during this time. In this case, after the delay time has expired, the SOS function is
briefly active. Afterwards, the drive may accelerate the motor back to the speed setpoint.
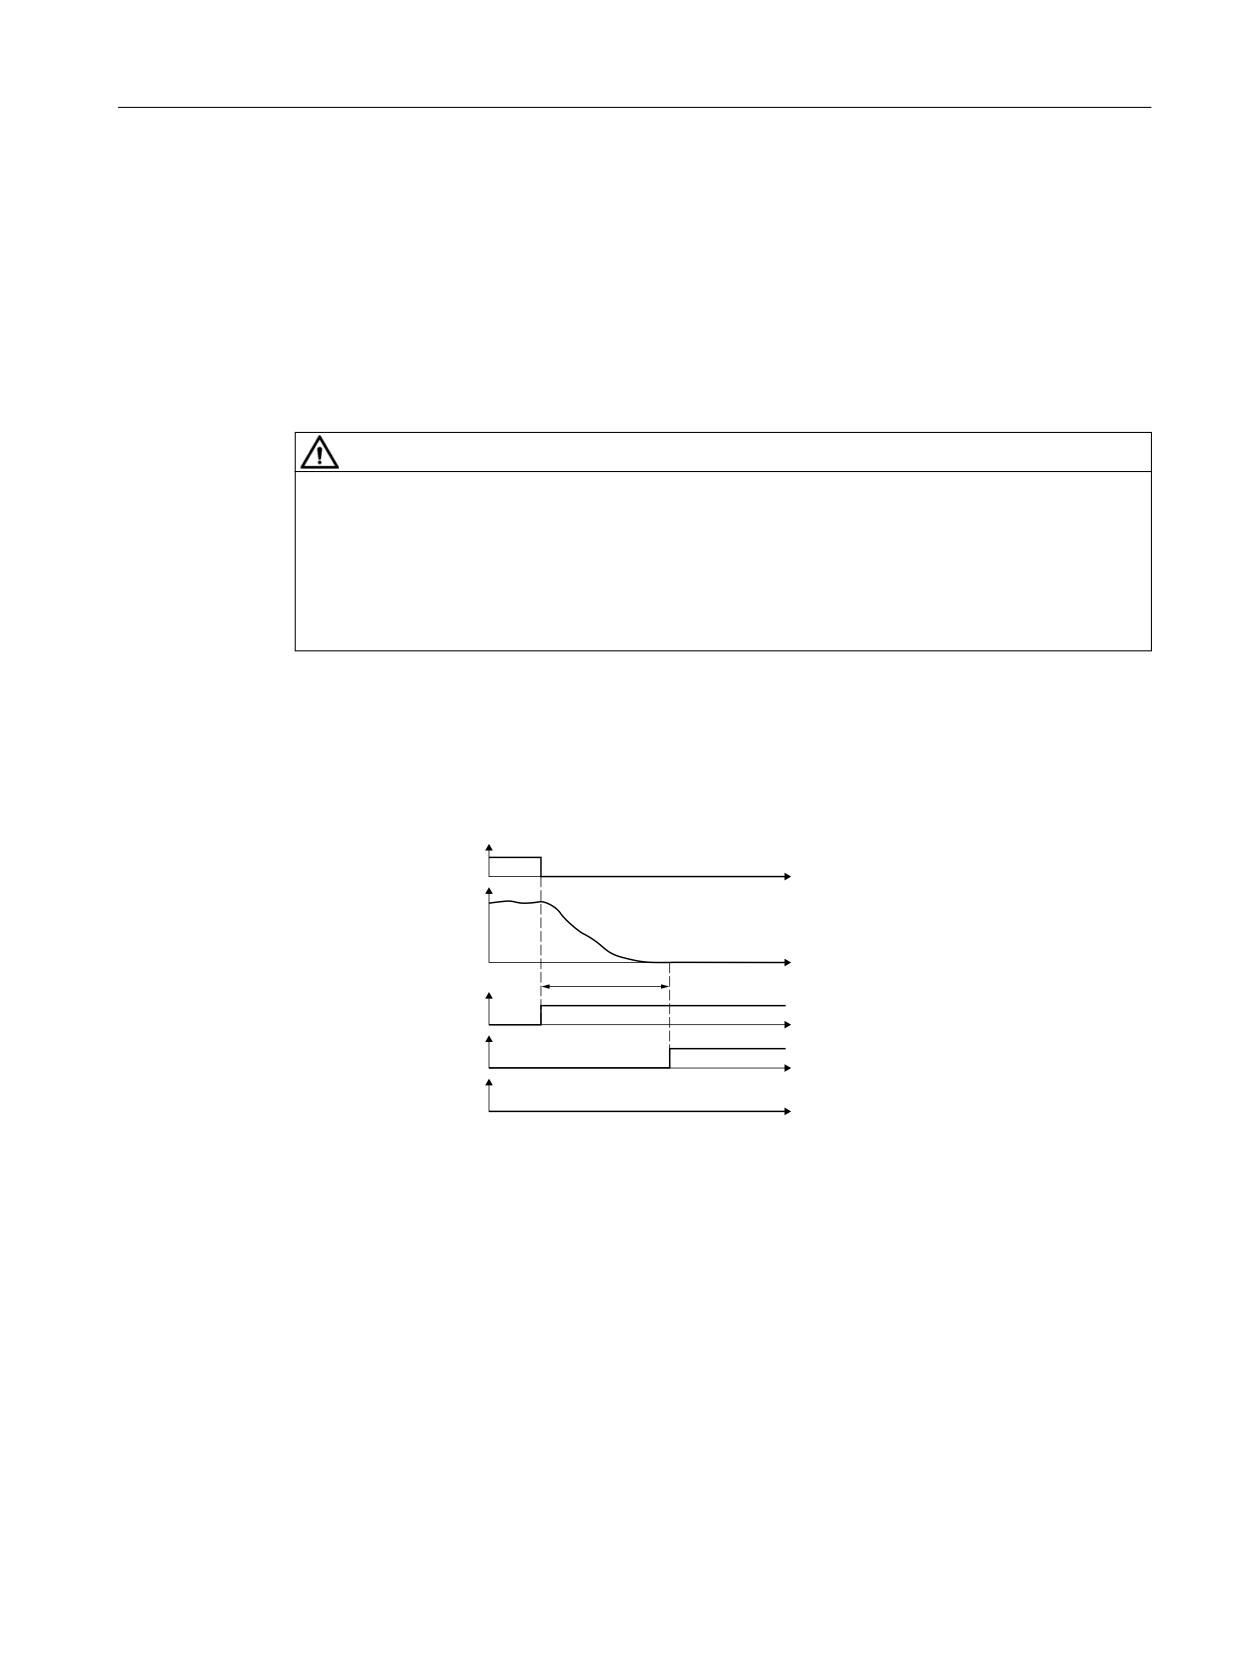
Interruption of the active SS2E function by functions SS1 and SS2
'HVHOHFW 66 (
'HVHOHFW 66 (
W
W
'HVHOHFW 66
'HVHOHFW 66
W
W
6SHHG
6SHHG
2)) UDPS
2)) UDPS
W
W
S
S
S
66 ( DFWLYH
66 ( DFWLYH
W
W
66 DFWLYH
66
DFWLYH
W
W
672 DFWLYH
626 DFWLYH
W
W
6$0 6%5 DFWLYH
6$0 6%5 DFWLYH
W
W
Figure 5-9
Interruption of function SS2E by functions SS1 (shown at the left) and SS2 (shown at the
right)
When selecting SS1, the drive brakes the motor along the OFF3 ramp and monitors the speed
using the SAM function. Function STO becomes active when the motor is at a standstill.
When selecting SS2, the drive also brakes the motor along the OFF3 ramp and monitors the
speed using the SAM function. Function SOS becomes active after time p9552.
5.5.1.2
Dynamic response adaptation for SS2E
For axes, the acceleration characteristic is adapted dynamically so that the axes stop within the
time saved in p9553 "SI Motion transition time STOP D to SOS". Therefore, ensuring stopping
with low associated stress on the machine.
In order that the stop D time, parameterized in p9553, is used as basis to determine the braking
time and possibly issue an alarm, this must be enabled by setting bit 2 in MD37950
$MA_SAFE_INFO_ENABLE.
When powering up, for all axes with SIC/SCC connection - where the bit to take into account the
stop D/SS2E transition times in the braking response (MD37950.2
$MA_SAFE_INFO_ENABLE) is set, the control system checks whether the braking time set in
p9553 is sufficient for the active acceleration characteristic of the axis. When violated,
suppressible alarm 22001 "Channel %1 block %2 axis %3: braking time %6 [s] longer than the
stop D time. Reason: %5" is output.
If the acceleration/deceleration behavior is changed, the axes brake for STOP D with the
shortest transition time of all path axes. It is recommended that the transition times are set the
same in p9553 for all axes of an interpolation group.
For spindles, the actual acceleration characteristic is not adapted. The control checks whether
the braking time set in p9553 is sufficient for all spindle operating modes and configured gear
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
109
Safety functions integrated in the drive
5.5 SS2
stages. When violated, suppressible alarm 22002 "Channel %1 Spindle %2: Braking time %6
[s] longer than the stop D time gearbox stage %3. Reason: %5" is output.
If the spindle is in axis operation, then it behaves just like an axis.
For an active axis or spindle coupling (with the exception of the synchronous spindle coupling),
the coupling is no longer taken into consideration, if synchronous stopping of the coupled group
is no longer safely possible within the time parameterized in p9553. For a coupled group, this
is the reason why a STOP D must be set for all axes of the coupled group.
For the synchronous spindle coupling, when synchronous operation is reached, the coupling is
always maintained. The coupling group is always braked via the leading spindle. If the following
spindle requires a longer braking time than the leading spindle, then p9553 must be
appropriately increased for the leading spindle.
When a synchronous spindle is active, STOP D should also be initiated for the leading and
following spindle.
Endlessly rotating axes are braked at the acceleration limit.
The SOS function is automatically activated after the time set in p9553 expires.
When Alarm 22001/22002 is output, the following formulas are applied:
METRIC:
p9553 > MAX_AX_VELO * 1/60000 / MAX_AX_ACCEL
INCH/ROT/SPINDLE:
p9553 > MAX_AX_VELO * 1/60 / MAX_AX_ACCEL
For axes with jerk limitation, the minimum braking time is increased by the additional
component:
2 * MAX_AX_ACCEL / MAX_AX_JERK
The check is made for NEWCONF, RESET, unparking an axis and for programming ACC or
JERKLIM.
The MD names contained in the formulas must, corresponding to the alarm situation (the alarm
occurs when parameterizing or when programming), be replaced by other values when
required.
MD
Alternative MD
Gearbox stage-specific MD spindle
Program
command
MAX_AX_VELO
min(JOG_VELO, JOG_VELO_RAPID)
$MA_GEAR_STEP_MAX_VELO_LIMIT[0…
-
max]
$MA_GEAR_STEP_PC_MAX_VELO_LIM-
IT[0…max]
MAX_AX_ACCEL
MAX_AX_ACCEL
$MA_GEAR_STEP_SPEEDCTRL_AC-
ACC
CEL[0…max]
$MA_GEAR_STEP_POSCTRL_ACCEL[0…
max]
MAX_AX_JERK
JOG_AND_POS_MAX_JERK
JERKLIM
Comment regarding INCH-METRIC switchover:
The calculated value should be rounded off to one decimal place so that for an INCH-METRIC
switchover, internal rounding effects can be compensated and no undesirable alarms are
initiated.
Safety Integrated plus
110
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.5 SS2
With the parameterization of the STOP D braking time in p9553 via the HMI IBN screen forms
and subsequent update by means of the operator panel reset, alarm 22001 or 22002 is
triggered when the specified calculation rules are violated.
Alarms 22001/22002 can be suppressed via MD 11415 bit 13. The dynamic response is
adapted as described.
5.5.1.3
Safe Stop 2 Extended Stop and Retract (SS2ESR)
WARNING
Unexpected axis motion
When function SS2ESR is active, during the delay time (p9554) the speed follows the setpoint
issued from the higher-level control system. As a consequence, unexpected axis motion is
possible, which can lead to severe injury and death.
● Prevent persons from entering the danger zone of the machine or system during the delay
time (p9554), for example, by keeping protective devices closed and interlocked.
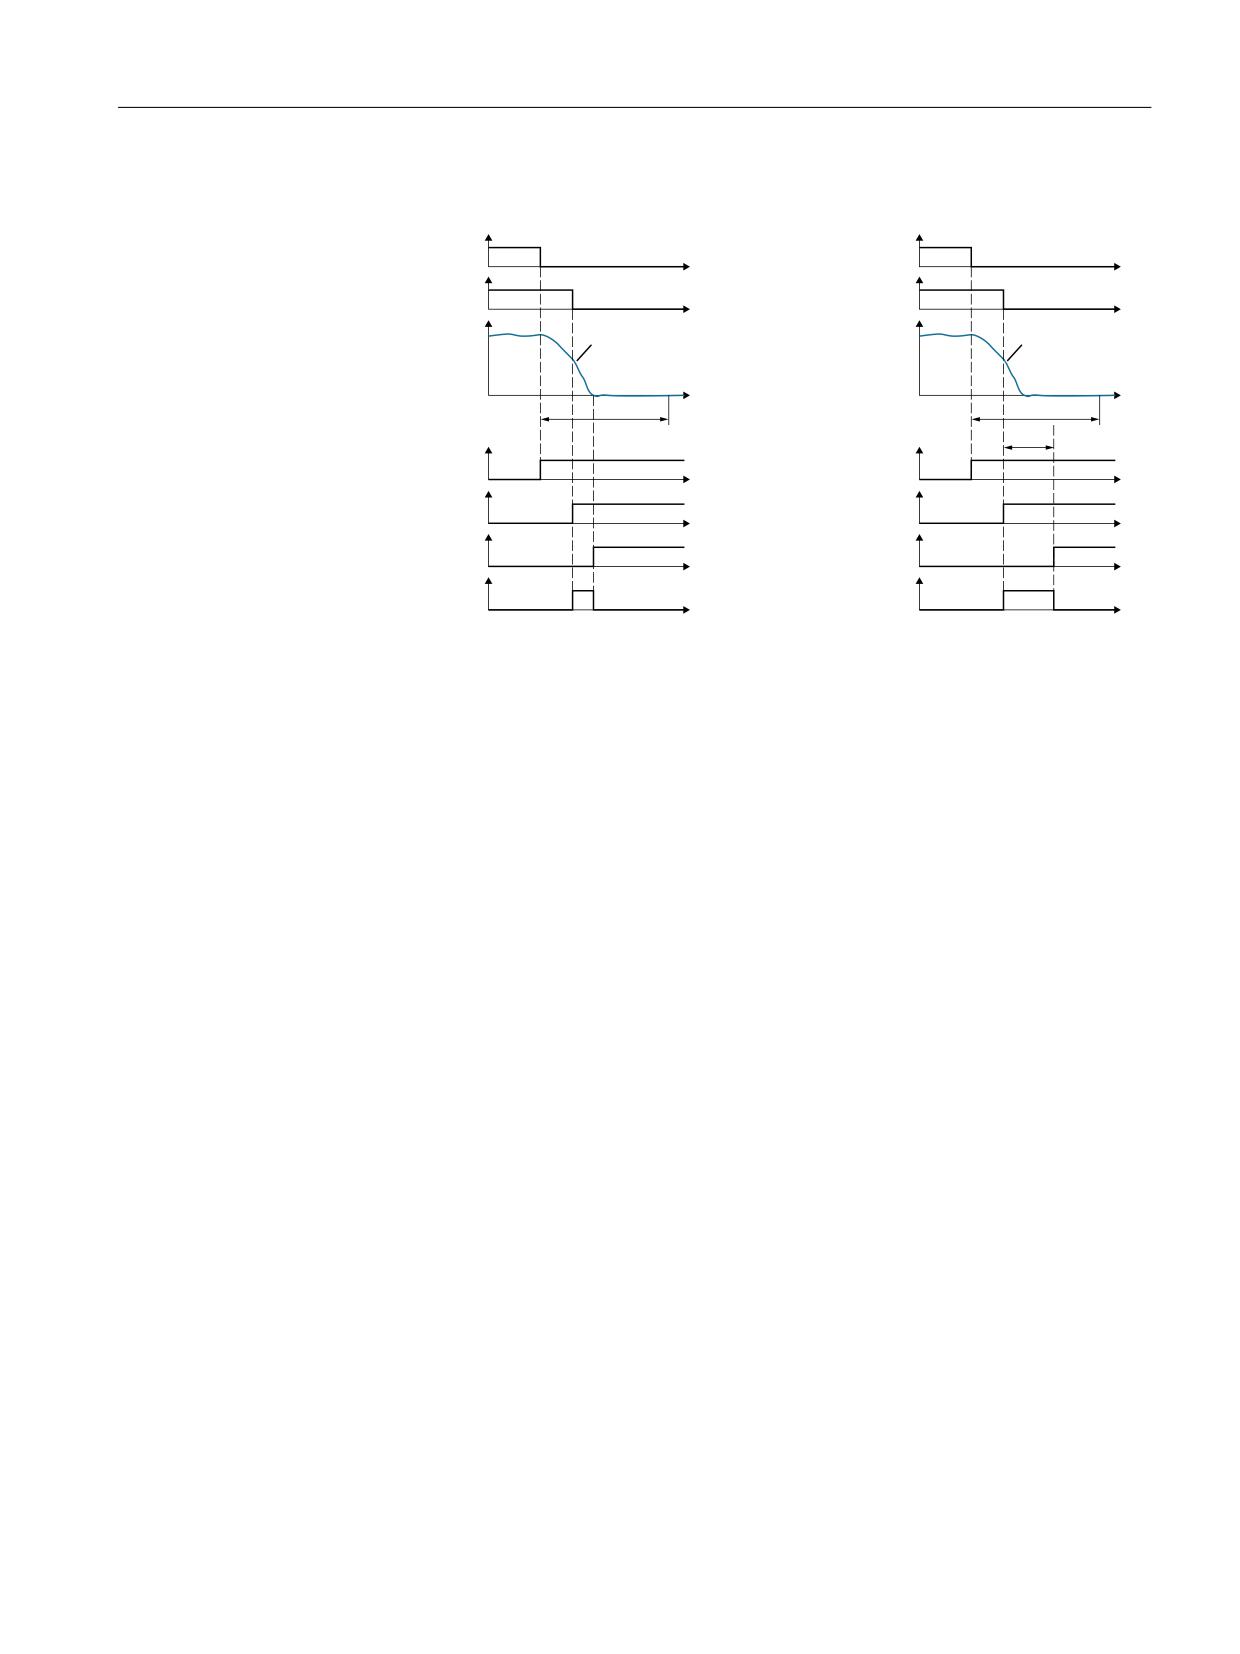
In principle, Safe Stop 2 Extended Stop and Retract (SS2ESR) functions in exactly the same
way as SS2 described in the previous sections. Note, however, the following differences:
Select SS2ESR
'HVHOHFW 66 (65
W
6SHHG
W
S
66 (65 DFWLYH
W
626 DFWLYH
W
6$0 6%5 DFWLYH
W
Figure 5-10
Selecting function SS2ESR
Differences between "Safe Stop 2 with OFF3" and SS2ESR
● If SS2ESR with external stop is selected, the drive does not brake the motor automatically,
but instead, follows the defined speed setpoint: This can also result in fast retraction motion.
● During the delay time p9554, the brake ramp (SBR) and the acceleration (SAM) are not
monitored, and there is no standstill detection.
● SOS becomes active after the delay time p9554 has expired. If function SS2ESR is active,
the higher-level control system must define the speed setpoint such that the motor is
stopped no later than after the delay time p9554 has expired.
● To enable SS2ESR, set p9501.4 = 1.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
111
Safety functions integrated in the drive
5.5 SS2
● PROFIsafe control word S_STW2.29 selects function SS2ESR. PROFIsafe S_STW2.29 is
contained in telegrams 31, 901, 902 and 903.
● PROFIsafe status word S_ZSW2.27 indicates whether function SS2ESR is active.
PROFIsafe status word S_ZSW2.27 is contained in telegrams 31, 901, 902 and 903. The
associated diagnostics parameter is r9722.27. In the "Safety Info Channel," status word
S_ZSW3B.12 indicates whether the SS2ESR function is active. The associated diagnostics
parameter is r10234.12.
● In addition, in the "Safety Info Channel", status word S_ZSW1B.14 = 1 is set. This bit
corresponds to diagnostic parameter r9734.14.
● You can use p0890[1] to interconnect to an ESR integrated in the drive.
● SS2ESR has no effect on the "Setpoint speed limit effective" (r9733[0...2]). If SS2ESR is
enabled in p9501.4, then a STOP E also has no effect on r9733[0...2].
Deselecting SS2ESR while SS2ESR is active
'HVHOHFW 66 (65
W
6SHHG
S
W
66 (65 DFWLYH
W
626 DFWLYH
W
6$0 6%5 DFWLYH
W
Figure 5-11
Deselecting SS2ESR while SS2ESR is active
After the function has been selected, the delay time starts to elapse - even if the function is
deselected during this time. In this case, after the delay time has expired, the SOS function is
briefly active. Afterwards, it is permissible that the drive accelerates the motor back to the speed
setpoint.
Safety Integrated plus
112
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.5 SS2
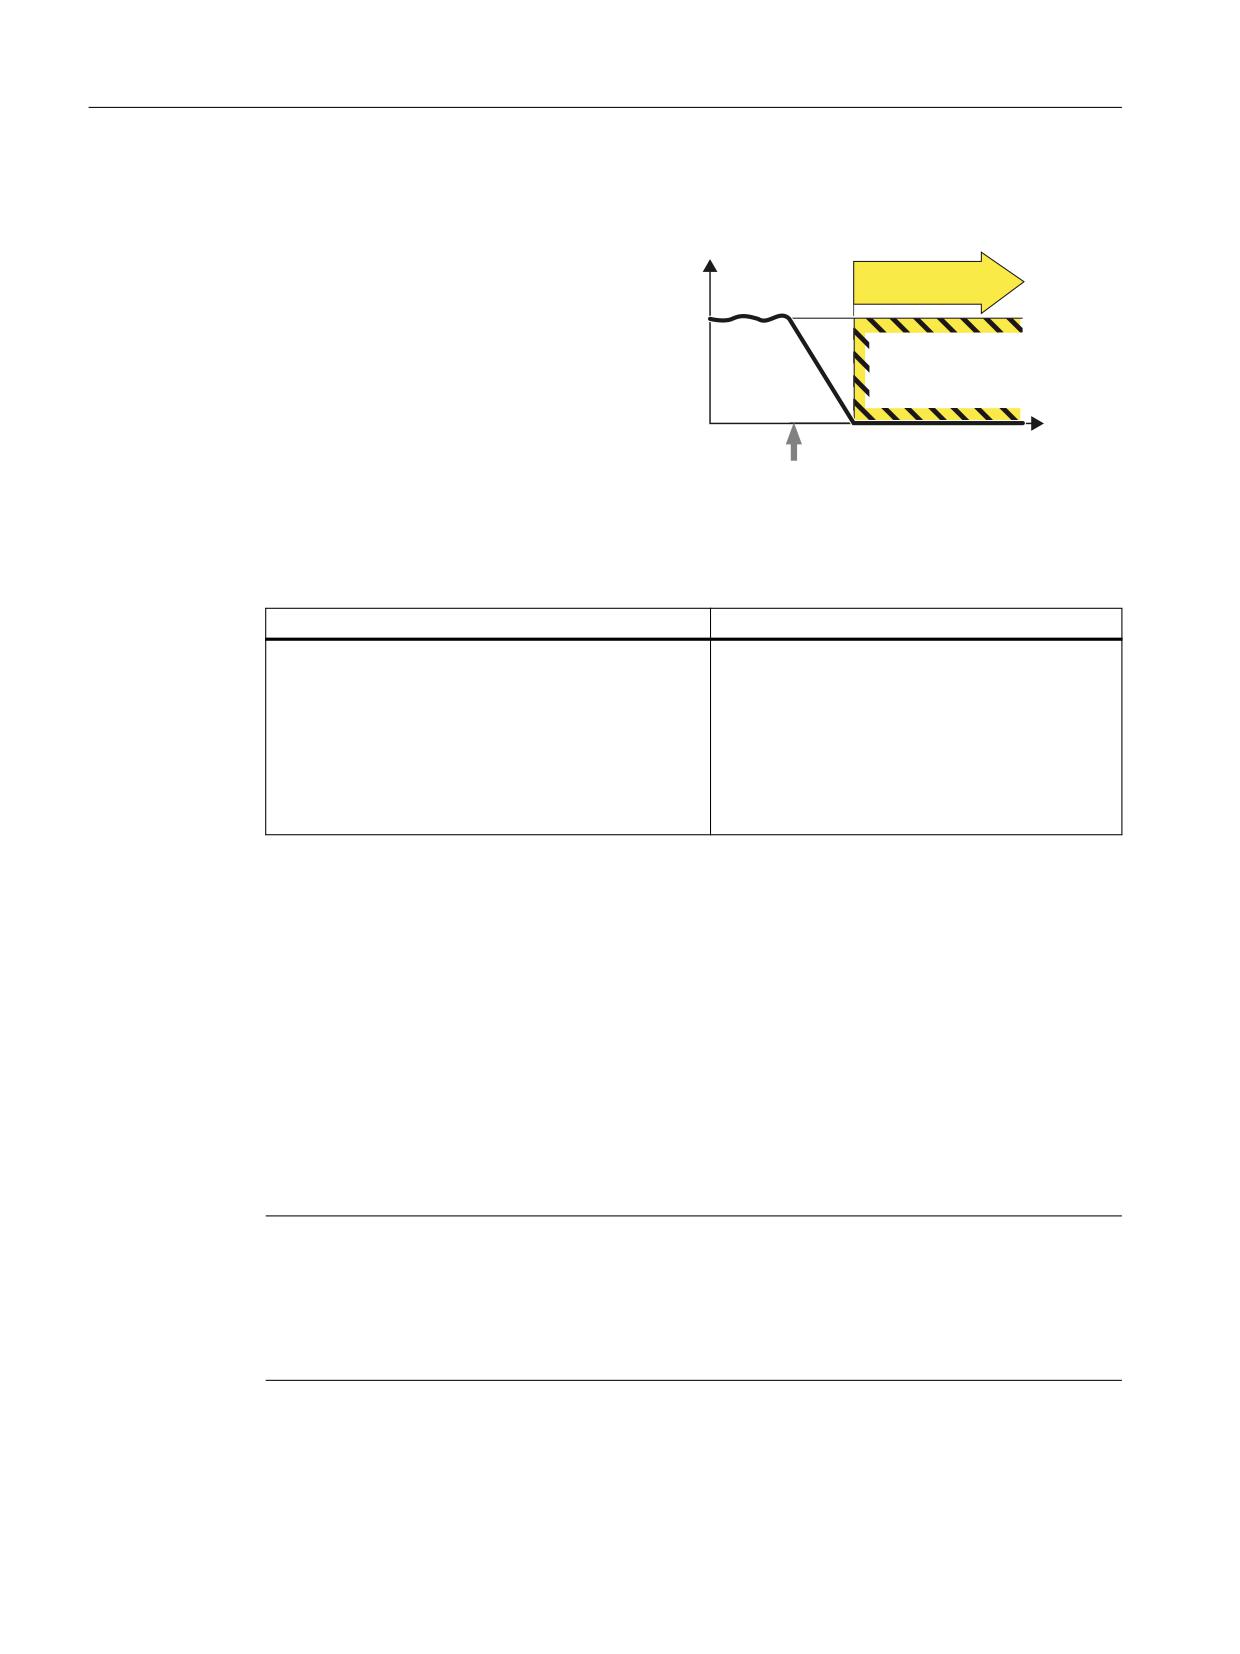
Interrupting active SS2ESR with SS1 and SS2
'HVHOHFW 66 (65
'HVHOHFW 66 (65
W
W
'HVHOHFW 66
'HVHOHFW 66
W
W
6SHHG
6SHHG
2)) UDPS
2)) UDPS
W
W
S
S
S
66 (65 DFWLYH
66 (65 DFWLYH
W
W
66 DFWLYH
66
DFWLYH
W
W
672 DFWLYH
626 DFWLYH
W
W
6$0 6%5 DFWLYH
6$0 6%5 DFWLYH
W
W
Figure 5-12
Interrupting function SS2ESR by functions SS1 (shown at the left) and SS2 (shown at the
right)
When selecting SS1, the drive brakes the motor along the OFF3 ramp and monitors the speed
using function SAM/SBR. Function STO becomes active when the motor is at a standstill.
When selecting SS2, the drive also brakes the motor along the OFF3 ramp and monitors the
speed using the SAM function. Function SOS becomes active after time p9552.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
113
Safety functions integrated in the drive
5.6 SOS
5.6
SOS
Definition according to EN 61800-5-2:
[
SOS
"This SOS function is used for safe monitor-
ing of the standstill position of a drive."
W
SOS selection
Example of how the function can be used
Example
Possible solution
A protective door must only be opened if a motor is in
● Select SOS
the safe standstill state.
● A higher-level controller brakes the axis (e.g.
position-controlled) down to standstill within
the configured time between the selection of
SOS and when it becomes active.
● Standstill is then safely monitored via the
SOS function.
5.6.1
Safe Operating Stop (SOS)
The protected machine areas can be entered without having to shut down the machine as long
as SOS is active.
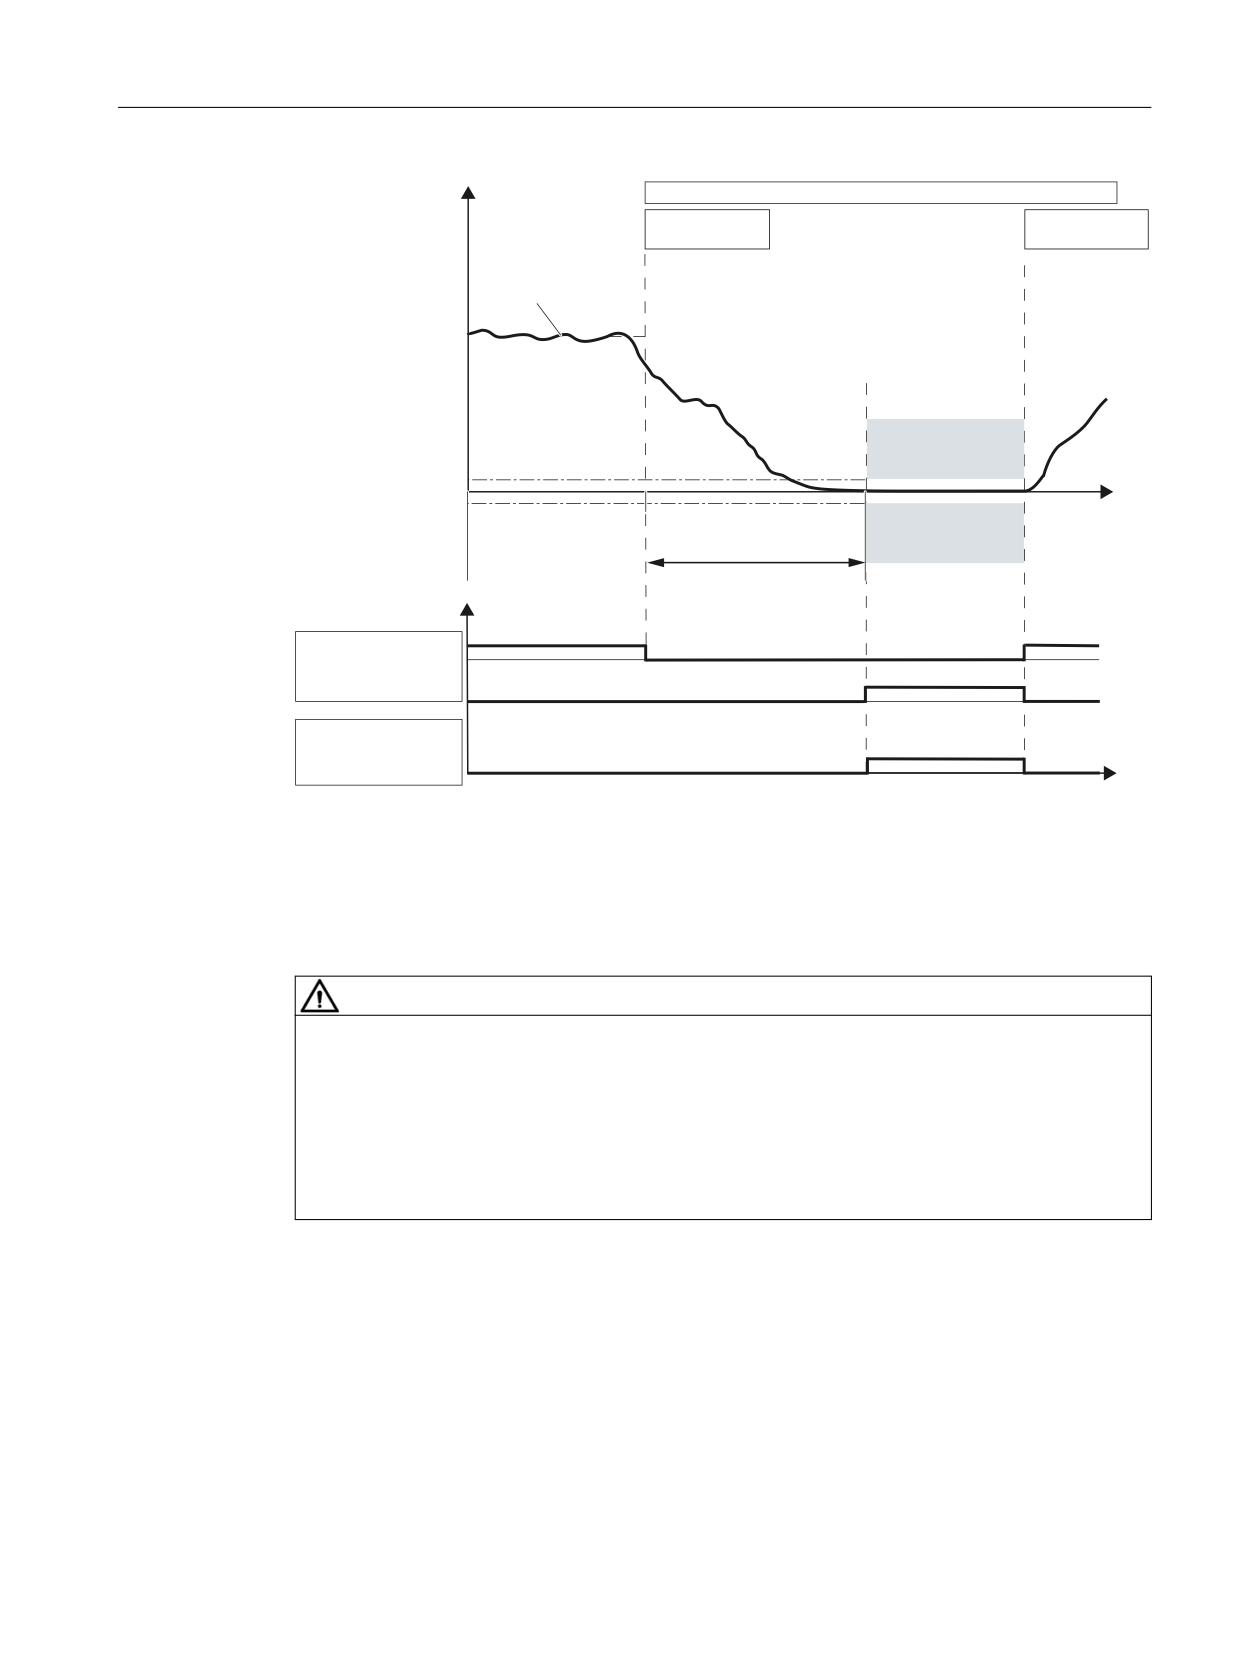
After SOS has been selected it becomes active after the parameterizable delay time has
expired. The drive must be braked to standstill within this delay time (e.g. by the controller).
Drive stopping is monitored using an SOS tolerance window. When this function is activated,
the current actual position is saved as a comparative position, until SOS is deselected again.
Any delay time is cleared after SOS is deselected and the drive can be immediately moved.
The drive is stopped with SS1 when the standstill tolerance window is violated.
Note
Contrary to SS1 and SS2, SOS does not automatically brake the drive
The control still enters the setpoint.
This means that in the user program of the control system, the system must respond to the
"SOS selected" bit so that the control system brings the drive to a standstill within the delay time.
Safety Integrated plus
114
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.6 SOS
2SHUDWRU DFWLRQV
;DFW
6HOHFW 626
'HVHOHFW 626
$FWXDO SRVLWLRQ
626
6WDQGVWLOO WROHUDQFH
W
626
'HOD\ WLPH 626
'LDJQRVWLFV
'HVHOHFW 626
626 DFWLYH
352),VDIH
626 DFWLYH
6WDWXV ZRUGb ELWb
W
Figure 5-13
Standstill tolerance
5.6.2
Details and parameterization
WARNING
Drive can be forced out of the SOS position by mechanical forces
A drive in position control can be forced out of the "Safe Operating Stop" (SOS, stop Category
2 according to 60204-1) position by mechanical forces that are greater than the maximum
torque of the drive. This unexpected drive motion then initiates a Category 1 stop function
according to EN 60204-1. The alarms for SS1 and STO must be carefully observed. This
unexpected drive motion can result in death and serious injury.
● To rule out any unexpected motion, use a brake with safe monitoring (see SBC (Page 97)).
This function serves for failsafe monitoring of the standstill position of a drive.
● Drive stopping is monitored using an SOS tolerance window (p9530).
● Effect on "Setpoint speed limit effective" (r9733[0...2]):
If SOS is selected, setpoint 0 is specified in r9733[0...2].
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
115
Safety functions integrated in the drive
5.6 SOS
Note
Size of the tolerance window
The size of the tolerance window should be slightly above the standard standstill monitoring
limit, otherwise the standard monitoring functions will no longer be effective.
Parameter r9731 indicates the safe position accuracy (load side) that can be achieved as a
maximum, based on the acquisition of the actual value for the safe motion monitoring functions.
STOP B is the stop response after the standstill tolerance window has been violated.
The SOS function comes into effect in the following cases:
● After SOS is selected and the delay time in p9551 has elapsed
The drive must be braked to standstill within this delay time (e.g. by the controller).
● As a consequence of SS2
● As a consequence of STOP C (corresponds to selection of SS2)
● As a consequence of STOP D (corresponds to selection of SOS)
● As a consequence of STOP E (corresponds to selecting SOS with additional activation of
the standard "Extended stop and retract (ESR)" function)
Responses
● Standstill tolerance violated in p9530
- STOP B with subsequent STOP A
- Safety message C01707
● System error
- STOP F
- Safety message C01711
5.6.2.1
Function diagrams and parameters
Function diagrams (see SINAMICS S120/S150 List Manual)
●
2819
SI Extended Functions - SS1, SS2, SOS, internal STOP B, C, D, F
Overview of important parameters (see SINAMICS S120/S150 List Manual)
● p9501
SI Motion enable safety functions (Control Unit)
● p9530
SI Motion standstill tolerance (Control Unit)
● p9551
SI Motion SLS(SG) switchover/SOS(SBH) delay time (CU)
● r9722.0...31
CO/BO: SI Motion drive-integrated status signals
● r9731
SI Motion safe positioning accuracy
Safety Integrated plus
116
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.7 SLS
5.7
SLS
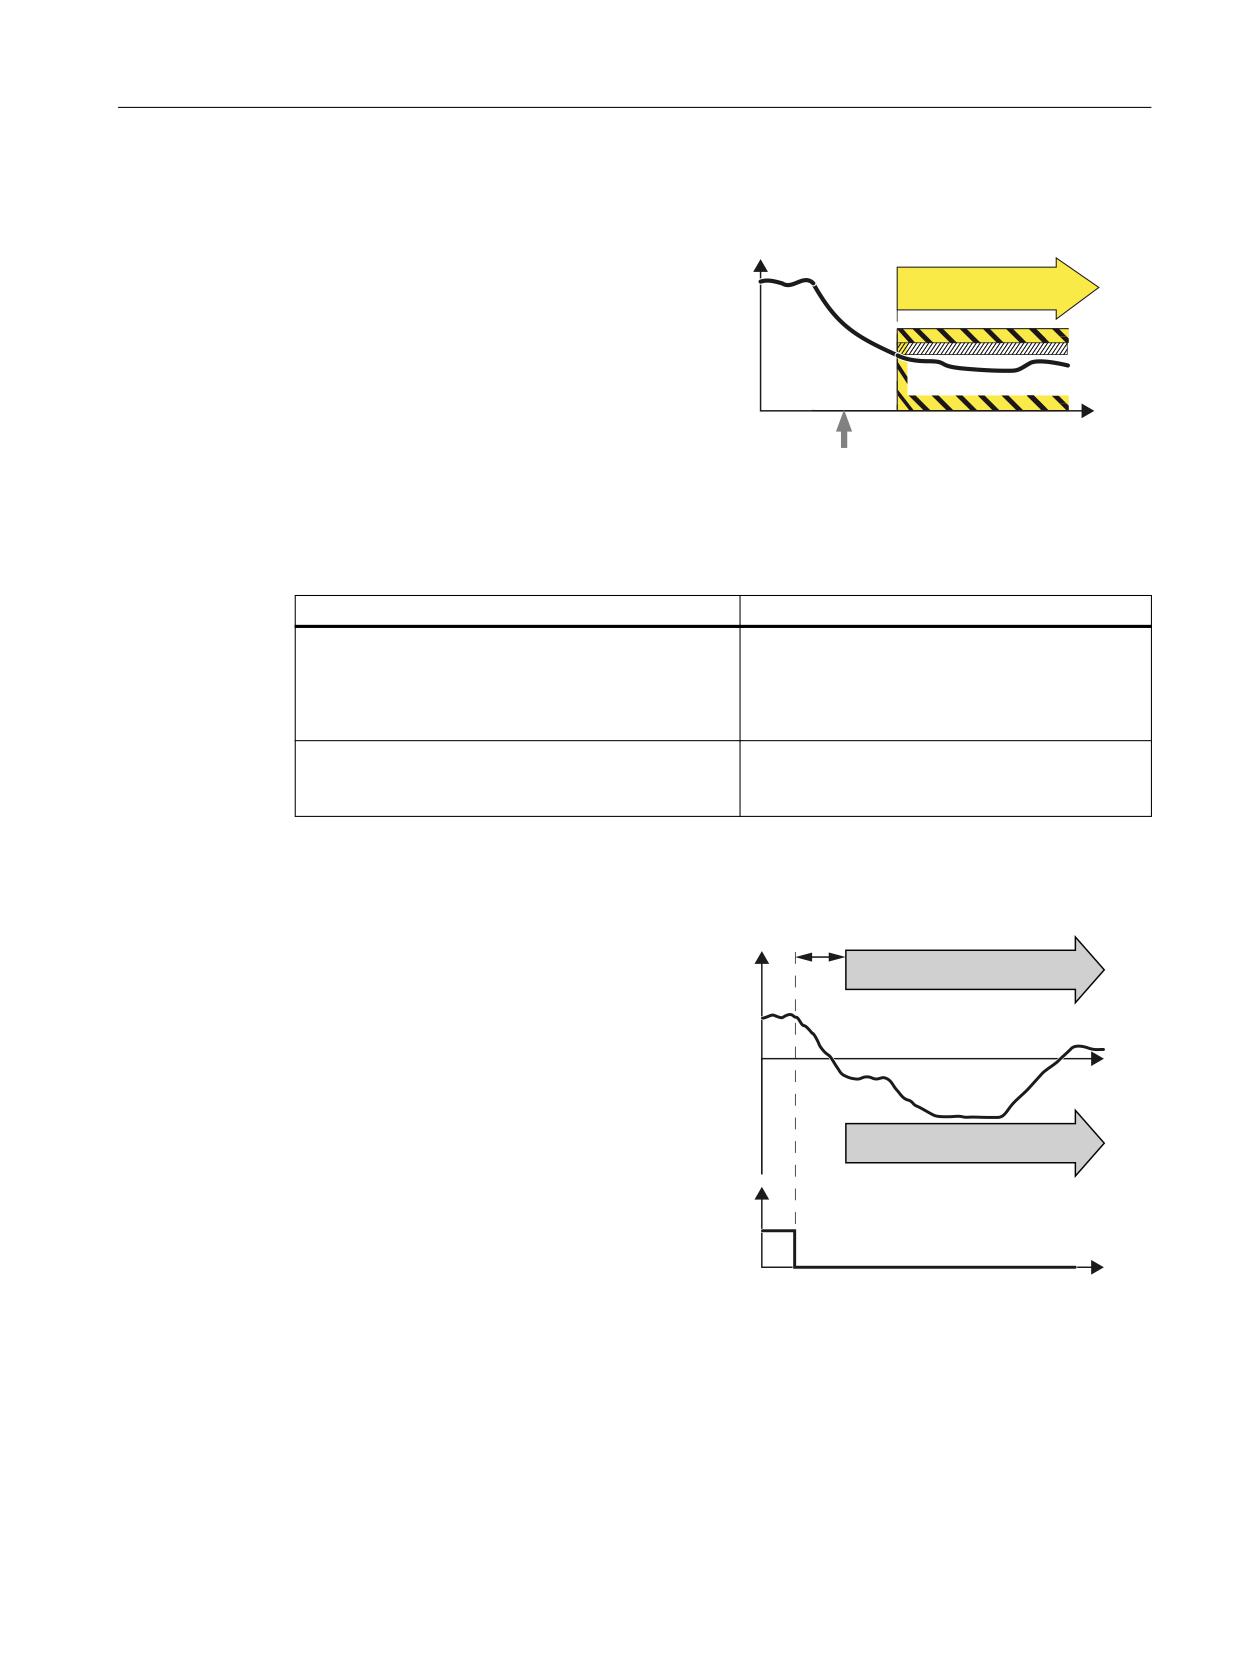
Definition according to EN 61800-5-2:
Y
"The SLS function prevents the motor from
SLS
exceeding the specified speed limit."
W
Select SLS
Examples of how the function can be used
Example
Possible solution
After opening a protective door, the machine opera-
● Select SLS in the converter via a fail-safe
tor must enter the machine and in the hazardous
input or PROFIsafe .
zone, operate a horizontal conveyor belt running at a
● The converter limits and monitors the veloci-
slow speed using an acknowledgment button.
ty of the horizontal conveyor.
A spindle drive, depending on the selection of the
● Select SLS and the corresponding SLSlevel
cutting tool, must not exceed a specific maximum
in the converter via PROFIsafe.
velocity.
How does SLS function in detail?
Overview
'HOD\ WLPH 6/6
6SHHG
1. The inverter recognizes the
6/6
selection of SLS via a failsafe
input or via the PROFIsafe
safe communication.
2. SLS allows a motor to reduce
W
its possibly inadmissibly high
speed within a defined time.
6/6
3. SLS monitors the absolute
value of the actual velocity.
6/6 GHVHOHFWLRQ
The SLS setpoint limit can be
transferred to the F-PLC,
352),VDIH
where the speed setpoint can
FRQWURO ZRUG
be limited.
W
In addition, you can configure
the setpoint limit provided by
SLS as maximum speed in
the ramp-function generator.
In this case, SLS limits the
speed setpoint.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
117
Safety functions integrated in the drive
5.7 SLS
Note
SLS without selection
As an alternative to controlling via terminals and/or PROFIsafe, there is also the option to
parameterize the SLS function without selection. In this case, the SLS function is permanently
active after POWER ON. You can find details about this in Section "Safely-Limited Speed
without selection (Page 128)".
Selecting SLS when the motor is switched on
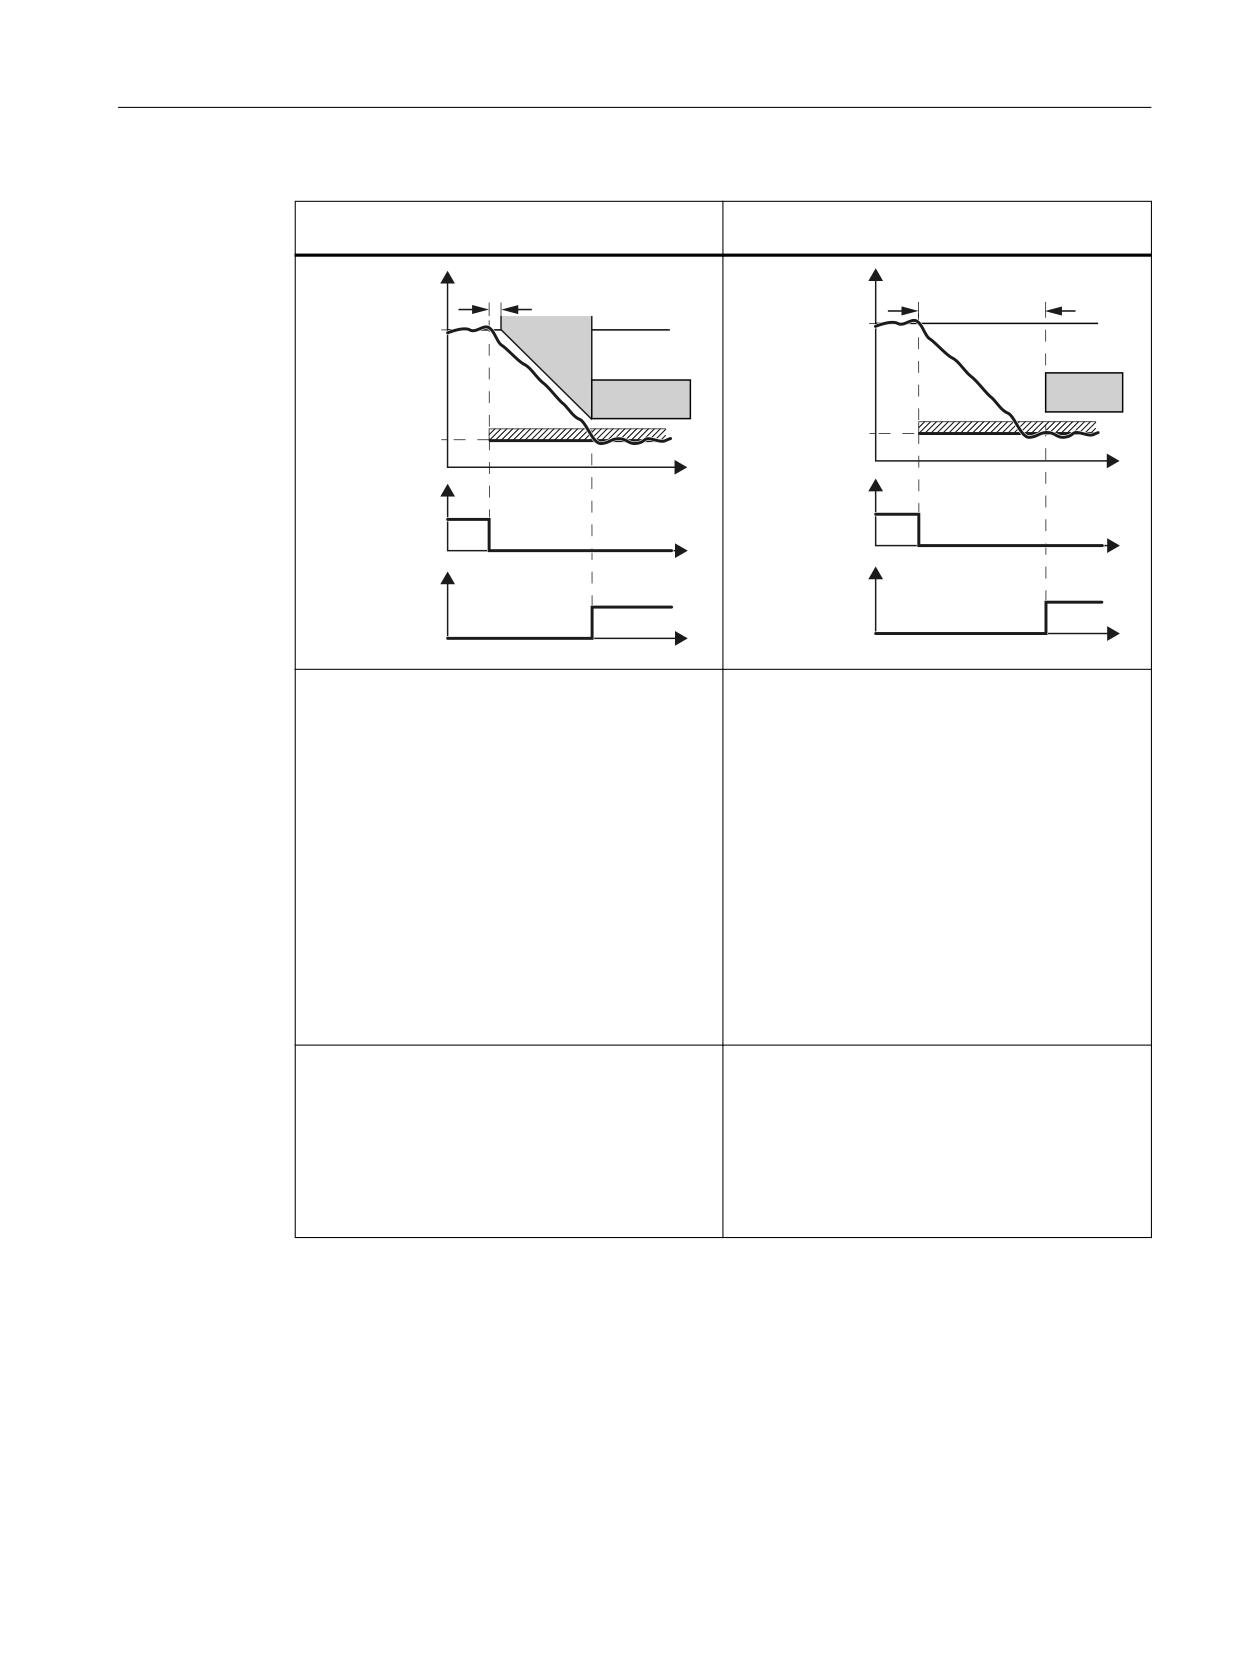
As soon as the converter detects the selection of SLS via a failsafe input or via PROFIsafe safe
communication, the following happens:
● To avoid a limit value being violated, the setpoint limit can be transferred to the F-PLC This
can then limit the velocity setpoint.
● If the speed setpoint limitation is interconnected to the ramp-function generator, the
converter limits the speed to a value below the SLS monitoring.
● For SLS without encoder, you can select whether the converter monitors motor braking
using the function SBR (Safe Brake Ramp) or SAM (Safe Acceleration Monitor) - or not. For
SLS with encoder, the SBR function cannot be selected.
Safety Integrated plus
118
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.7 SLS
With braking ramp monitoring1)
Without braking ramp monitoring
(only without encoder)
(with or without encoder)
9HORFLW\
'HOD\ WLPH IRU EUDNH
9HORFLW\
'HOD\ WLPH IRU 6/6
UDPS
VZLWFKRYHU
6HWSRLQW
6HWSRLQW
6%5
6/6
6/6
/LPLWDWLRQ
/LPLWDWLRQ
W
6/6 GHVHOHFWLRQ
W
6/6 GHVHOHFWLRQ
352),VDIH FRQWURO
352),VDIH FRQWURO
ZRUG
ZRUG
W
W
6/6 DFWLYH
6/6 DFWLYH
) '2 RU
) '2 RU
352),VDIH VWDWXV
352),VDIH VWDWXV
ZRUG
ZRUG
W
W
● After the adjustable "delay time for the braking
● The converter monitors the load velocity after
ramp", using the SBR (Safe Brake Ramp) func-
the "delay time for SLS switchover" has ex-
tion, the converter monitors whether the veloc-
pired.
ity decreases.
● The converter switches from SBR to SLS as
soon as one of the following two conditions is
fulfilled:
- The SBR monitoring ramp has reached the
value of the SLS monitoring.
This case is shown in the diagram above.
- After the actual velocity has reached the
value of the SLS monitoring threshold, the
system again waits for the "delay time for
braking ramp" until SLS becomes active.
Advantages:
Advantage:
● Already when braking, the converter detects as
● Commissioning is simplified, because instead
to whether the load velocity decreases too
of the subfunction SBR or SAM of the alterna-
slowly.
tive brake ramp monitoring, you only have to
set the delay time.
● The feedback signal "SLS active" generally
comes earlier than without acceleration moni-
toring.
1)
The automatic reduction of the speed only takes effect when the ramp-function generator is
interconnected to the speed setpoint limitation.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
119
Safety functions integrated in the drive
5.7 SLS
Selecting SLS at low velocities
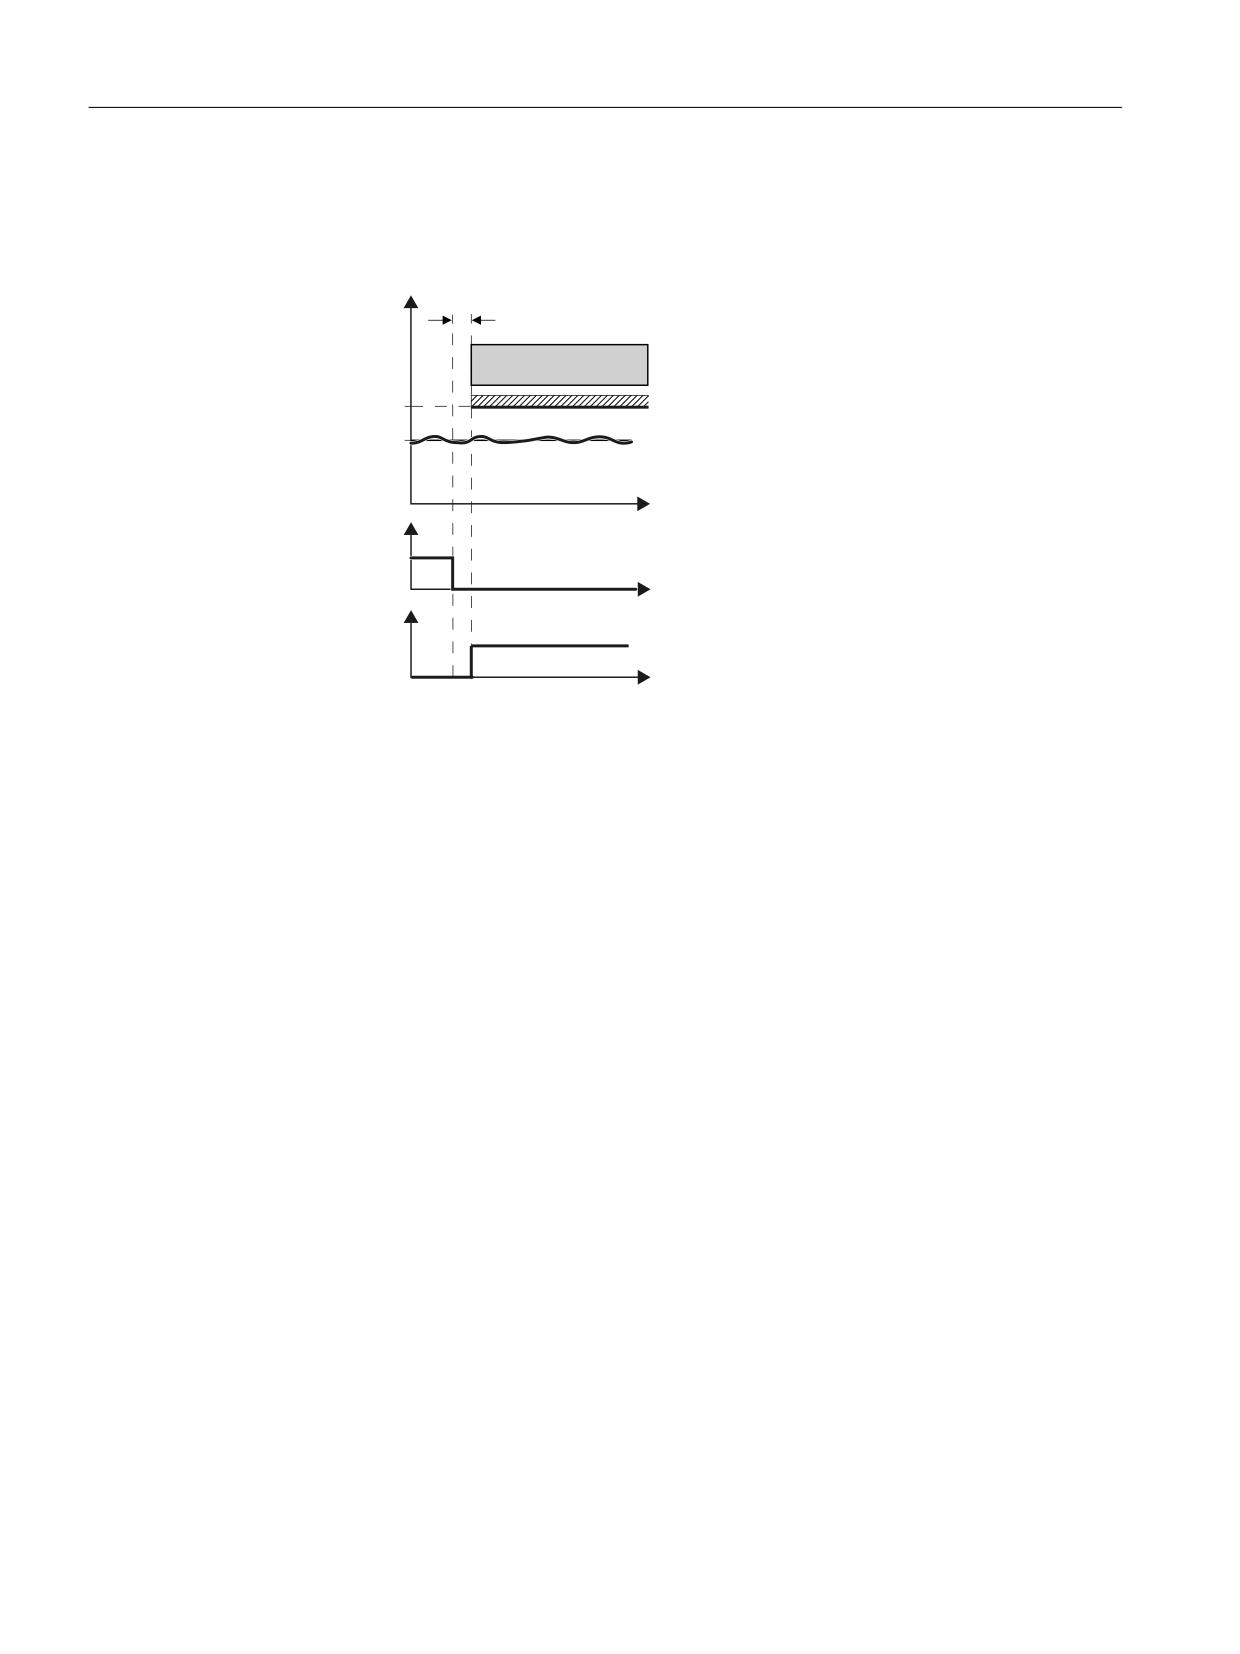
If the motor velocity when selecting SLS is less than the SLSlimit, then the drive responds as
follows:
9HORFLW\
'HOD\ WLPH 6/6
6/6
/LPLWDWLRQ
6HWSRLQW
W
6/6 GHVHOHFWLRQ
352),VDIH FRQWURO
ZRUG
W
6/6 DFWLYH
) '2 RU
352),VDIH VWDWXV
ZRUG
W
Figure 5-14
Selecting SLS at low velocities
Deselecting SLS
If the higher-level controller deselects SLS , then the converter deactivates limiting and
monitoring.
Switching over the monitoring limits
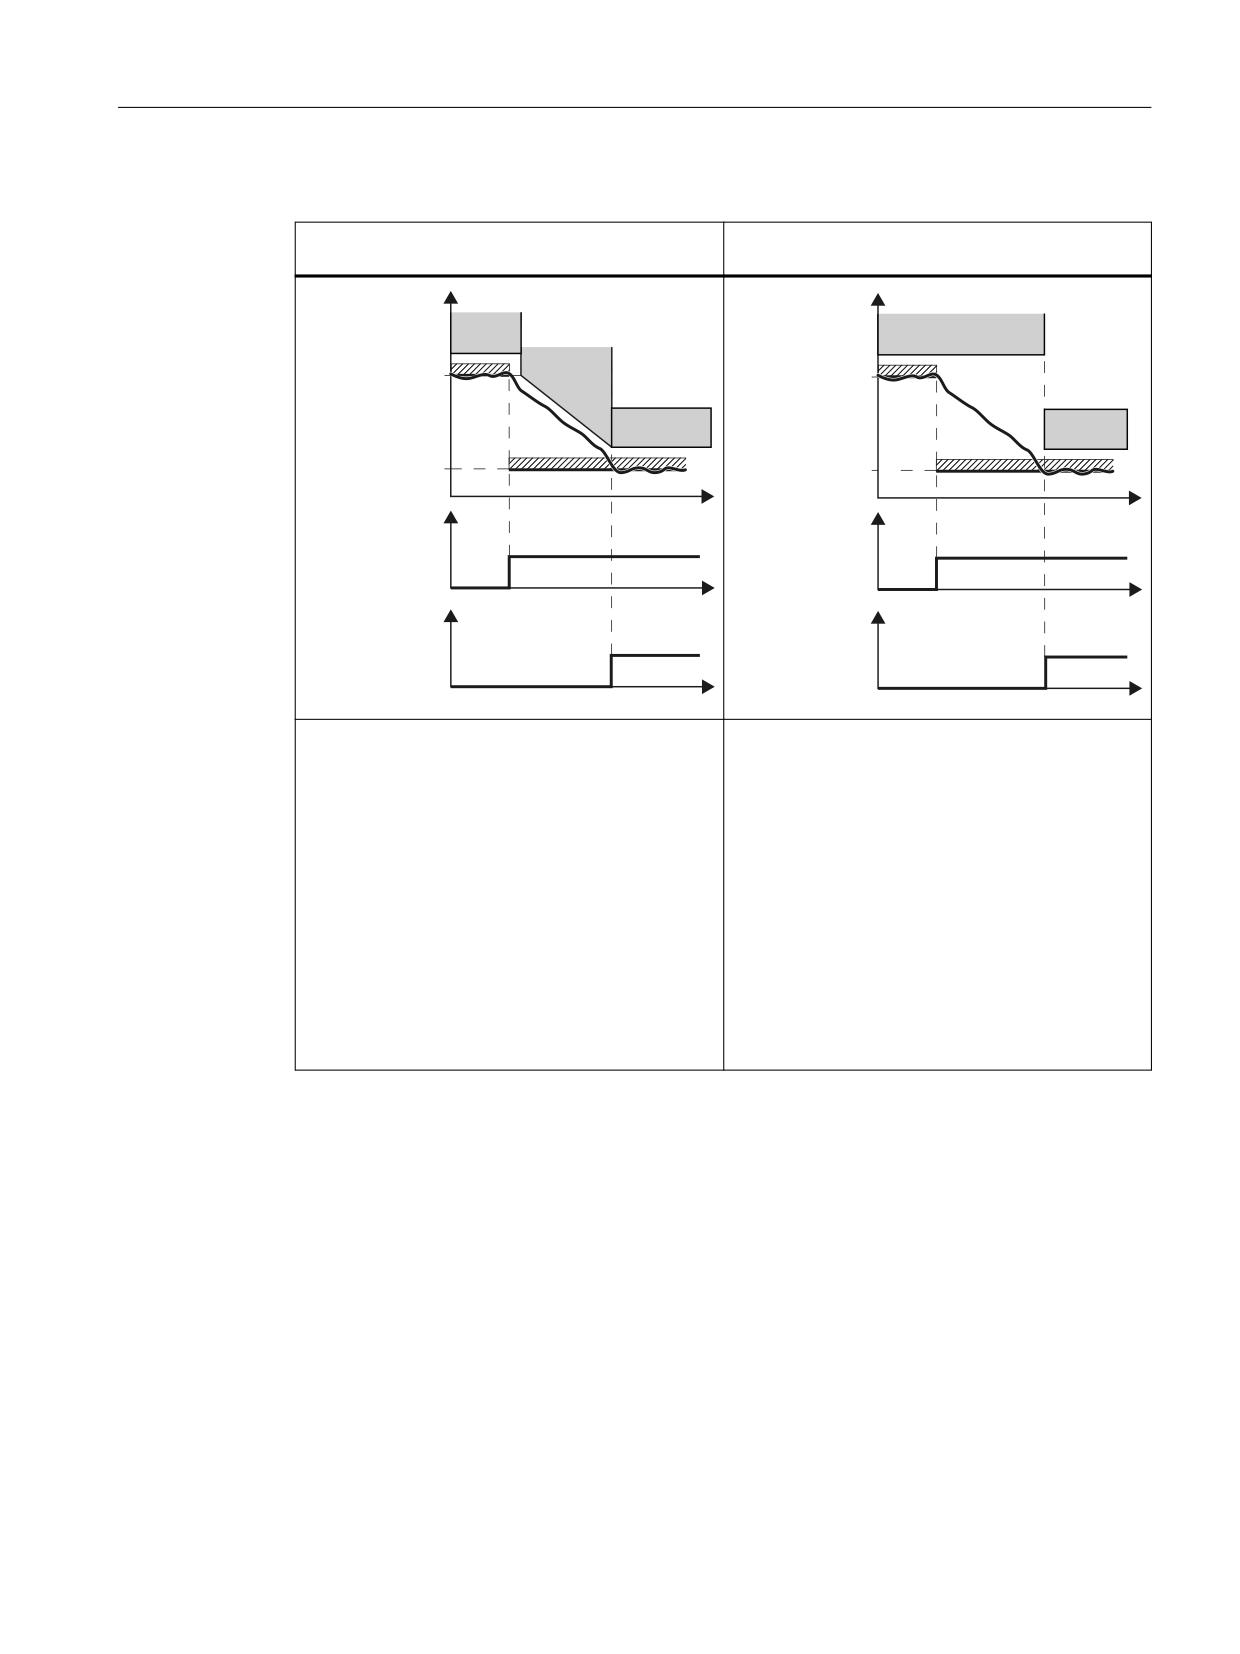
When SLS is active, you can switchover between 4 different speed levels. An exception is "SLS
without selection": In this case, there is only one limit.
Safety Integrated plus
120
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.7 SLS
Switching to a lower speed level
With braking ramp monitoring1)
Without braking ramp monitoring
(only without encoder)
(with or without encoder)
9HORFLW\
9HORFLW\
6/6
6/6
/LPLW OHYHO
6%5
/LPLW OHYHO
6/6
6/6
/LPLW OHYHO
/LPLW OHYHO
6HOHFW
W
6HOHFW
W
6/6 OHYHO
6/6 OHYHO
352),VDIH
/HYHO
352),VDIH
/HYHO
/HYHO
/HYHO
FRQWURO ZRUG
FRQWURO ZRUG
W
W
$FWLYH
$FWLYH
6/6 OHYHO
6/6 OHYHO
352),VDIH
352),VDIH
/HYHO
/HYHO
/HYHO
/HYHO
VWDWXV ZRUG
VWDWXV ZRUG
W
W
●
Once the "delay time for braking ramp" has
● The converter monitors the velocity with the
elapsed, the converter monitors the motor ve-
lower SLS level after the "delay time for SLS
locity using the function SBR (Safe Brake
changeover" has expired (this is the same de-
Ramp).
lay time that applies after selecting the function
SLS).
●
The converter switches over from SBR moni-
toring to level 2 of SLS monitoring as soon as
one of the following conditions is fulfilled:
- The SBR monitoring ramp has reached the
value of the SLS monitoring.
This case is shown in the diagram above.
- The load velocity has decreased down to
the value SLS monitoring and the "delay
time for braking ramp" has expired.
1)
The automatic reduction of the speed only takes effect when the ramp-function generator is
interconnected to the speed setpoint limitation.
Switching to a higher speed level
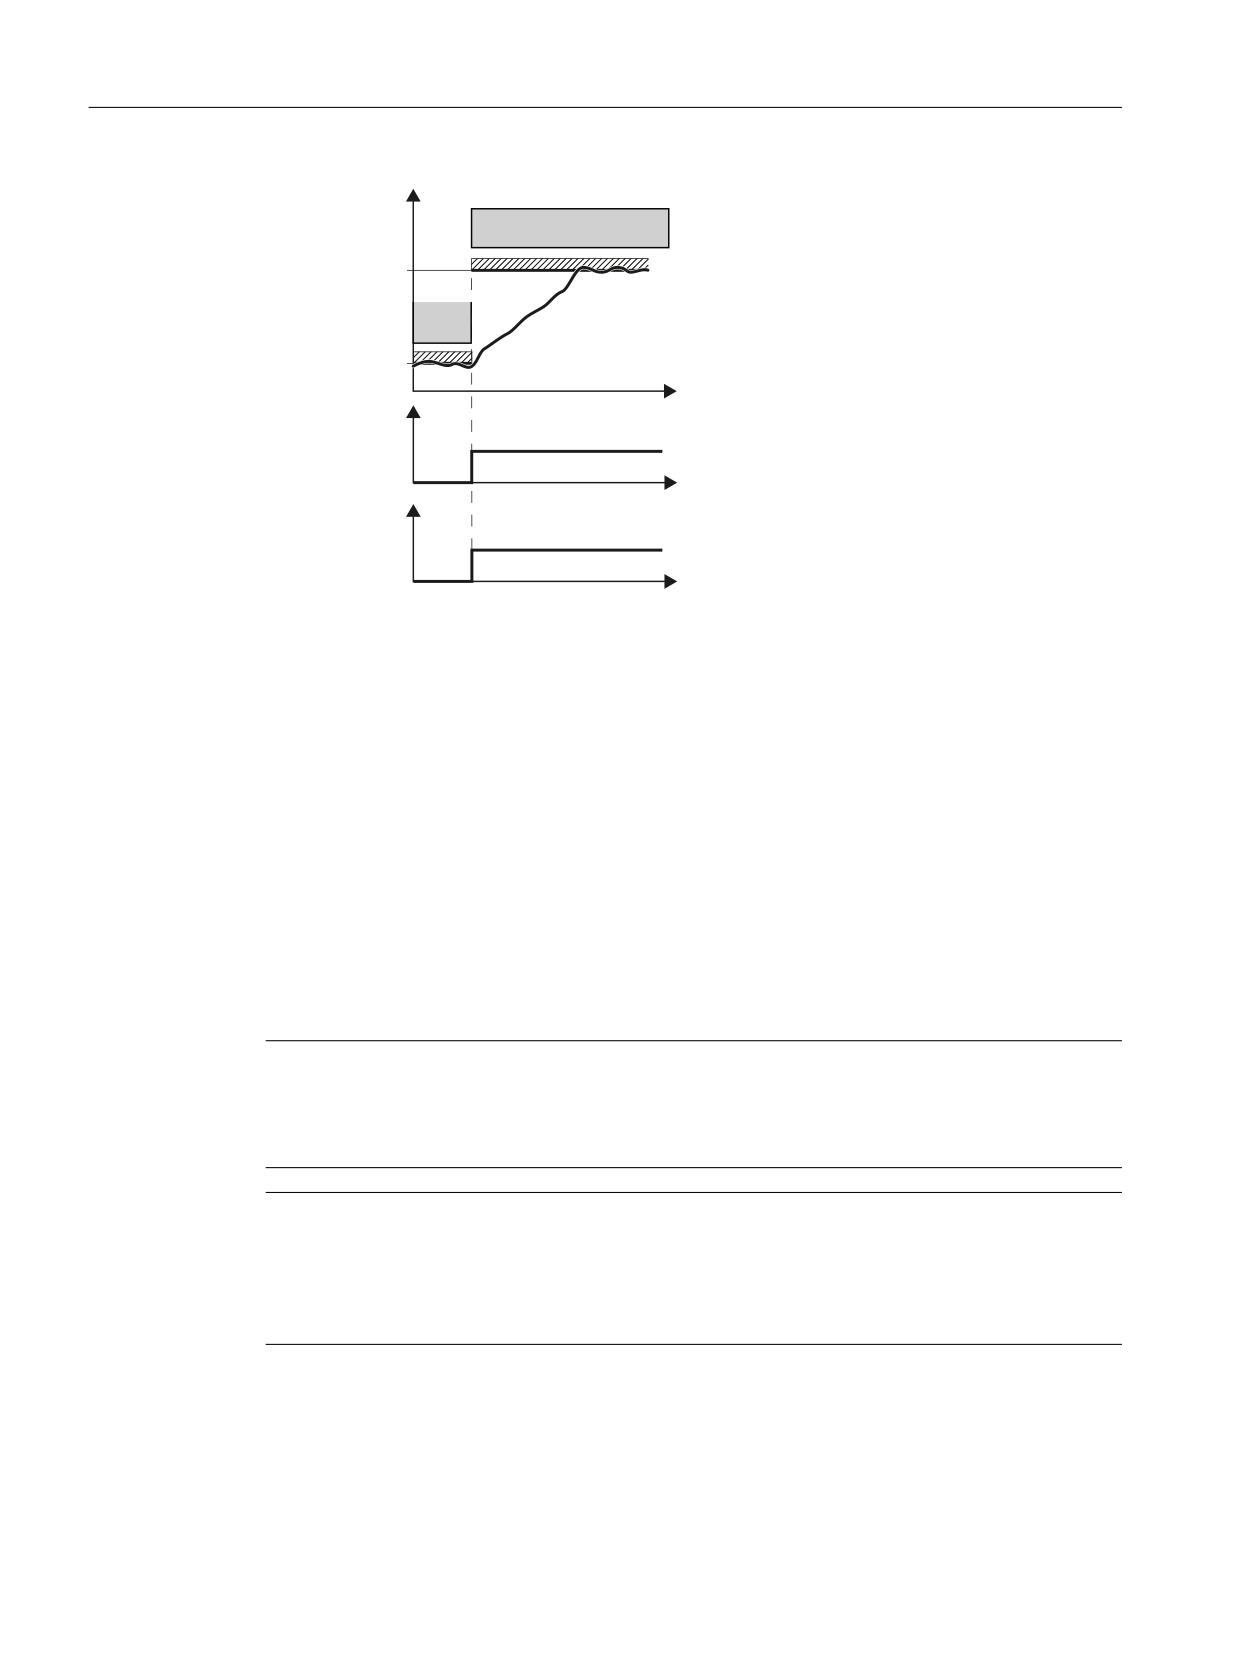
If you switch over from a lower to a higher speed level, the converter immediately monitors the
actual velocity against the higher velocity.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
121
Safety functions integrated in the drive
5.7 SLS
6SHHG
6/6
/LPLW OHYHO
6/6
/LPLW OHYHO
6/6 OHYHO
W
VHOHFWLRQ
352),VDIH
/HYHO
/HYHO
FRQWURO ZRUG
W
$FWLYH
6/6 OHYHO
352),VDIH
/HYHO
/HYHO
VWDWXV ZRUG
W
Figure 5-15
Switching to a higher speed level
5.7.1
Details and parameterization
The Safely Limited Speed (SLS) function is used to protect a drive against unintentionally high
speeds in both directions of rotation. This is achieved by monitoring the current drive speed up
to a speed limit.
Safely Limited Speed prevents a parameterized speed limit from being exceeded. Limits must
be specified based on results of the risk analysis. Up to four different SLS speed limits can be
parameterized using parameter p9531[0..3]; it is possible to switch between them even if the
SLS is activated.
An override can also be added to SLS limit value 1. In operation, this override can be varied
using a PROFIsafe telegram.
Note
Deviation of the displayed speed limit
The SLS speed limit displayed in r9714[2] can deviate slightly from the specified SLS speed
limit. The reason for this is the internal resolution (r9732) of the speed values.
Note
Response in the event of a communication error
If p9580 ≠ 0 and SLS is active, in the event of communication failure, the parameterized ESR
reaction is only realized if, as SLS response, a STOP with delayed pulse cancellation when the
bus fails has been parameterized (p9563[0...3] ≥ 10).
Safety Integrated plus
122
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.7 SLS
Note
Setpoint speed limit and SLS
● When parameterizing SLS, it also makes sense to configure the setpoint speed limiting. This
is done in a higher-level controller that evaluates the safety information channel, for
example, or by wiring r9733[0/1] to the speed limits of the ramp-function generator (p1051/
p1052).
● It does not make sense to use the positive and negative setpoint limiting for SLS in
conjunction with standard telegram 105 and others: With this combination, the velocity
setpoint of the standard telegram is only effective after the setpoint limiting.
5.7.1.1
Connection to motion control in the NC
The following status bits or values from the SIC/SCC send data are linked to the NC so that for
safety functions integrated in the drive, subsequent responses or alarms do not occur in the NC:
● SI Motion Safety Info Channel status word: S_ZSW1B (Page 366)
- Bit 4 SLS_ACTIVE (SLS active)
- Bit 6 SLS_SELECTED (SLS selected)
● Speed setpoint limit in 32-bit resolution with sign bit: S_V_LIMIT_B (Page 366)
If the SLS function is selected or is active, then the corresponding bits are set in S_ZSW1B. The
currently selected velocity limit value of the SLS function integrated in the drive is then entered
in S_V_LIMIT_B.
After rescaling, SV_LIMIT_B is multiplied with the value from MD36933
$MA_SAFE_DES_VELO_LIMIT[0...3], and is transferred to the motion control in the NC as
setpoint speed limit.
If a value of 0% or 100% is entered in MD36933, then the value from S_V_LIMIT_B is
transferred as speed setpoint limit.
When SOS or a STOP A to F is selected, then S_V_LIMIT_B contains a setpoint of 0. When the
"SLS" or "SOS" function is not selected in the drive, then the velocity/speed limit value in
S_V_LIMIT_B corresponds to the value for the maximum velocity/maximum speed (Vmax).
5.7.1.2
Safely Limited Speed (SLS)
Features
● When SLS is selected, the monitoring only takes effect after the configured delay time has
expired (p9551). Within this time, the actual speed must be below the (selected) limit. The
delay time is not effective when SLS is deselected.
● After switching to a lower limit value (p9531), the actual speed of the drive must have
dropped below the new limit within the delay time (p9551). The existing limit remains active
during the delay time. The lower limit value becomes active after the delay time expires. This
also applies to a reduction of the limit value via PROFIsafe.
● If the actual speed of the drive is higher than the new Safely-Limited Speed limit after the
delay time has elapsed, a message is generated with the parameterized stop response.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
123
Safety functions integrated in the drive
5.7 SLS
●
The stop response (STOP A, STOP B, STOP C, STOP D or STOP E) is parameterized with
p9563.
●
During changeover to a higher limit value, the delay time is not active and the high limit value
becomes immediately active. This also applies to increasing the limit value via PROFIsafe.
●
4 parameterizable limit values p9531[0...3]
●
The first limit value can be entered via the PROFIsafe telegrams 901 and 902 (for
p9501.24 = 1)
●
In parameter p9533 enter the weighting factor to determine the setpoint limit from the
selected actual speed limit in percent. The active limit value is evaluated using this factor,
and is provided as setpoint limit in r9733.
- r9733[0] = p9531[x] x p9533 (converted from the load to the motor side)
- r9733[1] = - p9531[x] x p9533 (converted from the load to the motor side)
[x] = selected SLS stage
Conversion factor from the motor to the load side:
- Motor type = rotary and axis type = linear: p9522/(p9521 × p9520)
- Otherwise: p9522/p9521
●
Limit value
- r9733[0] = p9531[x] x p9533; x = selected SLS limit value
- r9733[1] = - p9531[x] x p9533; x = selected SLS limit value
r9733 is used, for example, for transferring values to a higher-level controller, which can
then, for example, adjust traversing speeds to the SLS levels or at the setpoint channel
(p1051). r9733 is a part of the Safety Info Channel (SIC).
●
The currently monitored limit value is displayed in parameter r9714[2].
Changeover of SLS limit values
The changeover is executed binary-coded via 2 F-DIs or 2 PROFIsafe control bits. The speed
selection status can be checked using parameters r9720.9/r9720.10. Parameters r9722.9 and
r9722.10 indicate the actual speed limit, bit r9722.4 must carry a "1" signal.
Table 5-1
Changeover of speed limits:
F-DI for bit 1 (r9720.10)
F-DI for bit 0 (r9720.9)
Speed limit
SLS level
0
0
p9531[0]
1
0
1
p9531[1]
2
1
0
p9531[2]
3
1
1
p9531[3]
4
Safety Integrated plus
124
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.7 SLS
Excessively high speed during incorrect control of the Safely-Limited Speed limits via F-DI
For all control options except PROFIsafe, limit SLS1 is activated after 2 unacknowledged
discrepancy errors. This means that for the 2 F-DIs for selecting the velocity levels, the value
0 is the "safe state" (failsafe value).
● Therefore parametrize the SLS limits in ascending order, i.e. with limit SLS1 as the lowest
speed and limit SLS4 as the highest speed.
Responses
Speed limit value exceeded:
● Configured subsequent stop STOP A/B/C/D/E via p9563
● Safety message C01714
System fault:
● STOP F
● Safety messages C01711
Transferring the first limit value using SIEMENS telegram 902
You have the option of influencing the first SLS limit value via PROFIsafe:
● The transfer of the first SLS limit value via PROFIsafe is active if the speed level 1 in the
PROFIsafe telegram is selected and the bit "Enable transfer SLS (SG) limit via PROFIsafe"
(p9501.24) is set.
● S_SLS_LIMIT_A has the value range 1 ... 32767; the following applies:
-
32767 ≙ 100 % of the 1st SLS level
– The actually monitored limit value is calculated as follows:
SLS limit value = (S_SLS_LIMIT_A/32767) × p9531[0]
● Also in this case, speed levels 2, 3 and 4 can be parameterized and selected.
● In operation, the selected delay time cannot be changed. If you require various delay times
in your application, then you must realize this using a time-delayed transfer of the SLS limit
value using the F-PLC.
● If an incorrect SLS limit value is transferred, then the converter responds with the stop
response of speed level 1 parameterized in p9563.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
125
Safety functions integrated in the drive
5.7 SLS
5.7.1.3
Safely Limited Speed without encoder
Functions
2 different encoderless Safely-Limited Speed monitoring functions can be set with parameter
p9506:
● p9506 = 3: Safe monitoring of acceleration (SAM) / delay time
The function is identical to "Safely-Limited Speed with encoder" which was described in the
previous section.
● p9506 = 1: Safe brake ramp monitoring (SBR)
Note
Defaults
● When commissioning, also note the description provided in the SINAMICS Safety
Integrated Function Manual, Chapter "Default settings for commissioning Safety Integrated
Functions without encoder".
● Information about setting the SBR monitoring function can be found in Chapter "SBR
(Page 139)".
Monitoring the brake ramp
● If the speed setpoint limitation (r9733) was connected to the setpoint channel (p1051/
p1052) and then SLS was selected - or if you change over to a lower SLS level - the motor
is decelerated from the actual speed to below the value defined with r9733 along the OFF3
ramp. In this case, the drive may no longer follow the setpoint of the higher-level motion
controller.
● Parameter p9582 is used to set the delay time for the braking ramp monitoring.
● Monitoring of the brake ramp is activated once the delay time in p9582 has elapsed. If the
actual speed of the drive violates the brake ramp (SBR) during braking, safety message
C01706 is output and the drive is stopped with STOP A.
● The newly selected SLS limit value is also taken over as the new limit speed, if either
- The SBR ramp has reached the new SLS limit value, or
- The actual speed of the drive was below the new SLS limit value for at least the time set
in p9582.
● The "Safely-Limited Speed without encoder" function then monitors whether the actual
speed remains below the newly selected SLS limit value.
● The parameterized stop response (p9563[x]) is triggered if the SLS limit value is exceeded.
Safety Integrated plus
126
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.7 SLS
Configuring the limits
● The speed limits for Safely-Limited Speed without encoder are configured in exactly the
same way as described for Safely-Limited Speed with encoder.
● Only STOP A and STOP B may be configured as stop responses for "Safely-Limited Speed"
(SLS) without encoder.
Restart after OFF2/STO
If the drive has been switched off via STO, the following steps need to be carried out before a
restart can be performed:
1. Case
●
State after switching on
● SLS selected
● STO selected
● Pulse suppression active
●
Deselect STO
●
The drive enable must be issued within 5 seconds via a positive edge at OFF1, otherwise
STO is reactivated.
2. Case
●
Situation
● Traversing to standstill with SLS selected
● OFF1 is initiated, pulse cancellation becomes active (internal selection
STO)
●
Select STO
●
Deselect STO
STO activated internally via pulse suppression: This activation must be undone by se-
lection/deselection.
●
The drive enable must be issued within 5 seconds via a positive edge at OFF1, otherwise
STO is reactivated.
3. Case
●
Situation
● Traversing to standstill with SLS selected
● OFF1 is initiated, pulse cancellation becomes active (internal selection
STO)
●
Deselect SLS
STO activated internally via pulse suppression: This activation must be undone by se-
lecting/deselecting SLS.
●
Select SLS
The drive enable must be issued within 5 seconds via a positive edge at OFF1, otherwise
STO is reactivated.
4. Case
●
Situation
● All Safety Integrated functions are deselected.
●
After this the drive enable must be given by a positive edge at OFF1.
●
In this case, the motor is not started safely.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
127
Safety functions integrated in the drive
5.7 SLS
5.7.1.4
Safely-Limited Speed without selection
Differences between Safely-Limited Speed with and without selection
● As an alternative to controlling via terminals and/or PROFIsafe, there is also the option to
parameterize the SLS function without selection.
● The function "SLS without selection" is selected with p9512.4 = 1.
● For "SLS without selection", only one SLS limit value can be parameterized (p9531[0]).
● The stop response is parameterized with p9563[0].
● For Safely-Limited Speed without selection there is no delay time. The function is always
active (with encoder), or it becomes active when switching on (without encoder).
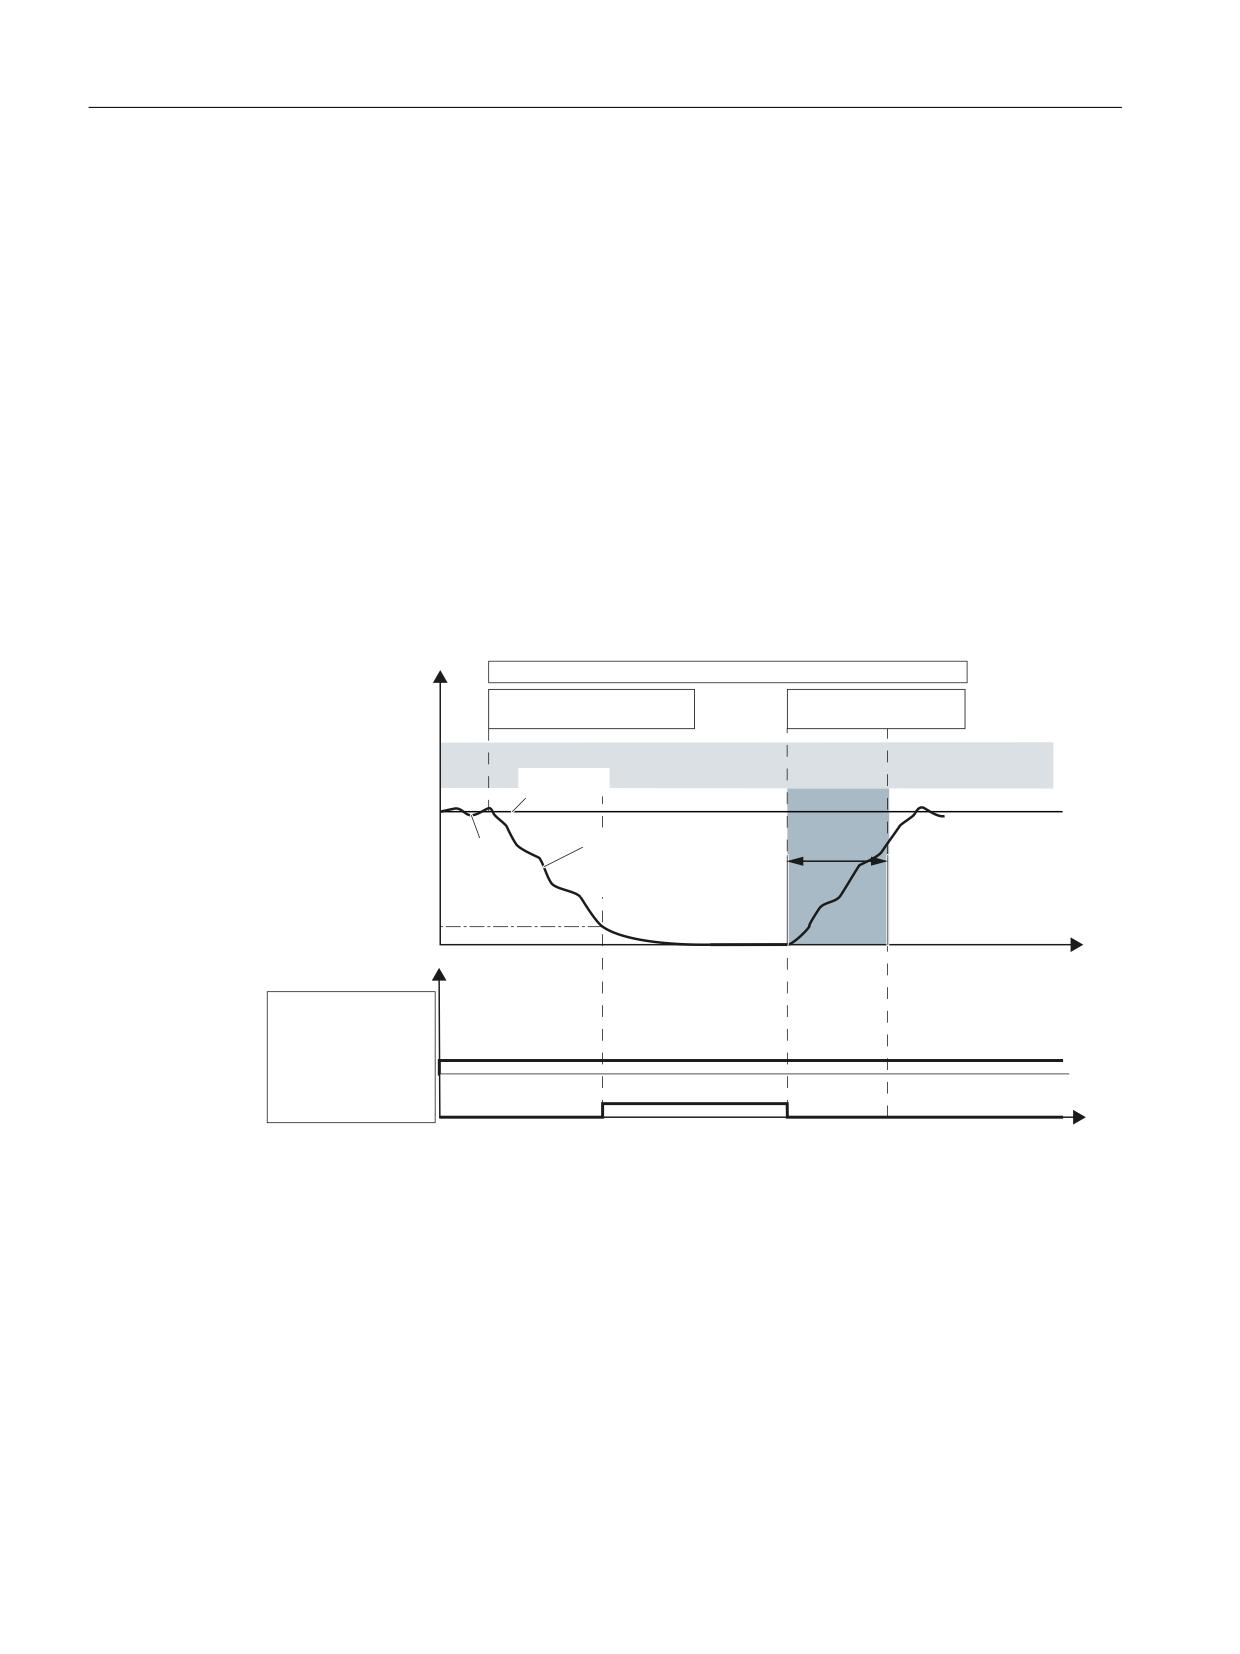
Switching the motor on and off (without encoder)
The time response and diagnostic options are as follows in this SLS version:
/RDG VSHHG
2SHUDWRU DFWLRQV
6ZLWFK RII WKH PRWRU
6ZLWFK RQ PRWRU
2)) 2)) FRPPDQG
21 FRPPDQG
6/6
6HWSRLQW
5DP
S GRZQ WLPH
$FWXDO
VHFRQGV
2))
YDOXH
S
6WDQGVWLOO PRQLWRULQJ
S
S
W
'LDJQRVWLFV
6/6 DFWLYH
U
6DIH SXOVH VXSSUHV
VLRQ DFWLYH
U
W
Figure 5-16
Time response of SLS without selection (example: Switching the motor on and off (without
encoder))
"SLS without selection" behaves as follows when switching off and switching on again:
● After switch-off, the motor behaves in accordance with the removed signal (OFF1, OFF2 or
OFF3).
● The "safe pulse cancellation" becomes active after the standstill limit is undershot. If a brake
has been parameterized, it is also closed.
● After the ON command, the converter cancels the "safe pulse cancellation" state and the
start procedure is initiated.
● If the minimum current has not been reached after 5 s, the converter returns into the "safe
pulse suppression" state and initiates alarm C01711.
Safety Integrated plus
128
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.7 SLS
5.7.1.5
Function diagrams and parameters
Function diagrams (see SINAMICS S120/S150 List Manual)
●
2820
SI Extended Functions - SLS (Safely-Limited Speed)
Overview of important parameters (see SINAMICS S120/S150 List Manual)
● p9501.0
SI Motion enable safety functions (Control Unit)
● p9512
Select SI Motion safety functions without selection (CU)
● p9531[0...3]
SI Motion SLS (SG) limits (Control Unit)
● p9551
SI Motion SLS(SG) switchover/SOS(SBH) delay time (CU)
● p9563[0...3]
SI Motion SLS (SG)-specific stop response (Control Unit)
● p9580
SI Motion STO delay bus failure (Control Unit)
● p9581
SI Motion braking ramp reference value (Control Unit)
● p9582
SI Motion braking ramp delay time (Control Unit)
● p9583
SI Motion braking ramp monitoring time (Control Unit)
● p9601
SI enable functions integrated in the drive (Control Unit)
● r9707[0...2]
CO: SI Motion diagnostics actual position value GX_XIST1
● r9714[0...2]
CO: SI motion diagnostics velocity
● r9720.0...27
CO/BO: SI Motion drive-integrated control signals
● r9721.0...15
CO/BO: SI Motion status signals (Control Unit)
● r9722.0...31
CO/BO: SI Motion drive-integrated status signals (Control Unit)
5.7.1.6
EPOS and safety-relevant setpoint velocity limiting
If safe speed monitoring (SLS) or the safe direction motion monitoring (SDI) is also to be used
at the same time as the EPOS positioning function, EPOS must be informed about the activated
monitoring limits. Otherwise these speed monitoring limits can be violated by the EPOS
setpoint input. By monitoring the limit value, if violated, the drive is stopped therefore exiting the
intended motion sequence. In this case, the relevant safety faults are output first, and then the
sequential faults created by EPOS.
Using parameter r9733, the safety functions offer EPOS setpoint limiting values, which when
taken into account, prevent the safety limit value being violated.
In order to prevent a safety limit violation by the EPOS setpoint specification, you must transfer
the setpoint limit value (r9733) as follows to the maximum speed setpoint of EPOS (p2594):
● r9733[0] = p2594[1]
● r9733[1] = p2594[2]
In this regard you must set the delay time for SLS/SOS (p9551), so that the relevant safety
monitoring function only becomes active after the maximum required time for the speed to be
reduced below the limit. This required braking time is determined by the current speed, the jerk
limit in p2574 and the maximum delay in p2573.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
129
Safety functions integrated in the drive
5.7 SLS
Overview of important parameters (see SINAMICS S120/S150 List Manual)
● p2573
EPOS maximum delay
● p2574
EPOS jerk limitation
● p2593
CI: EPOS LU/revolution LU/mm
● p2594[0...2]
CI: EPOS maximum speed, externally limited
● p9551
SI Motion SLS(SG) switchover/SOS(SBH) delay time (CU)
● r9733[0...2]
CO: SI Motion speed setpoint limit active
Safety Integrated plus
130
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.8 SSM
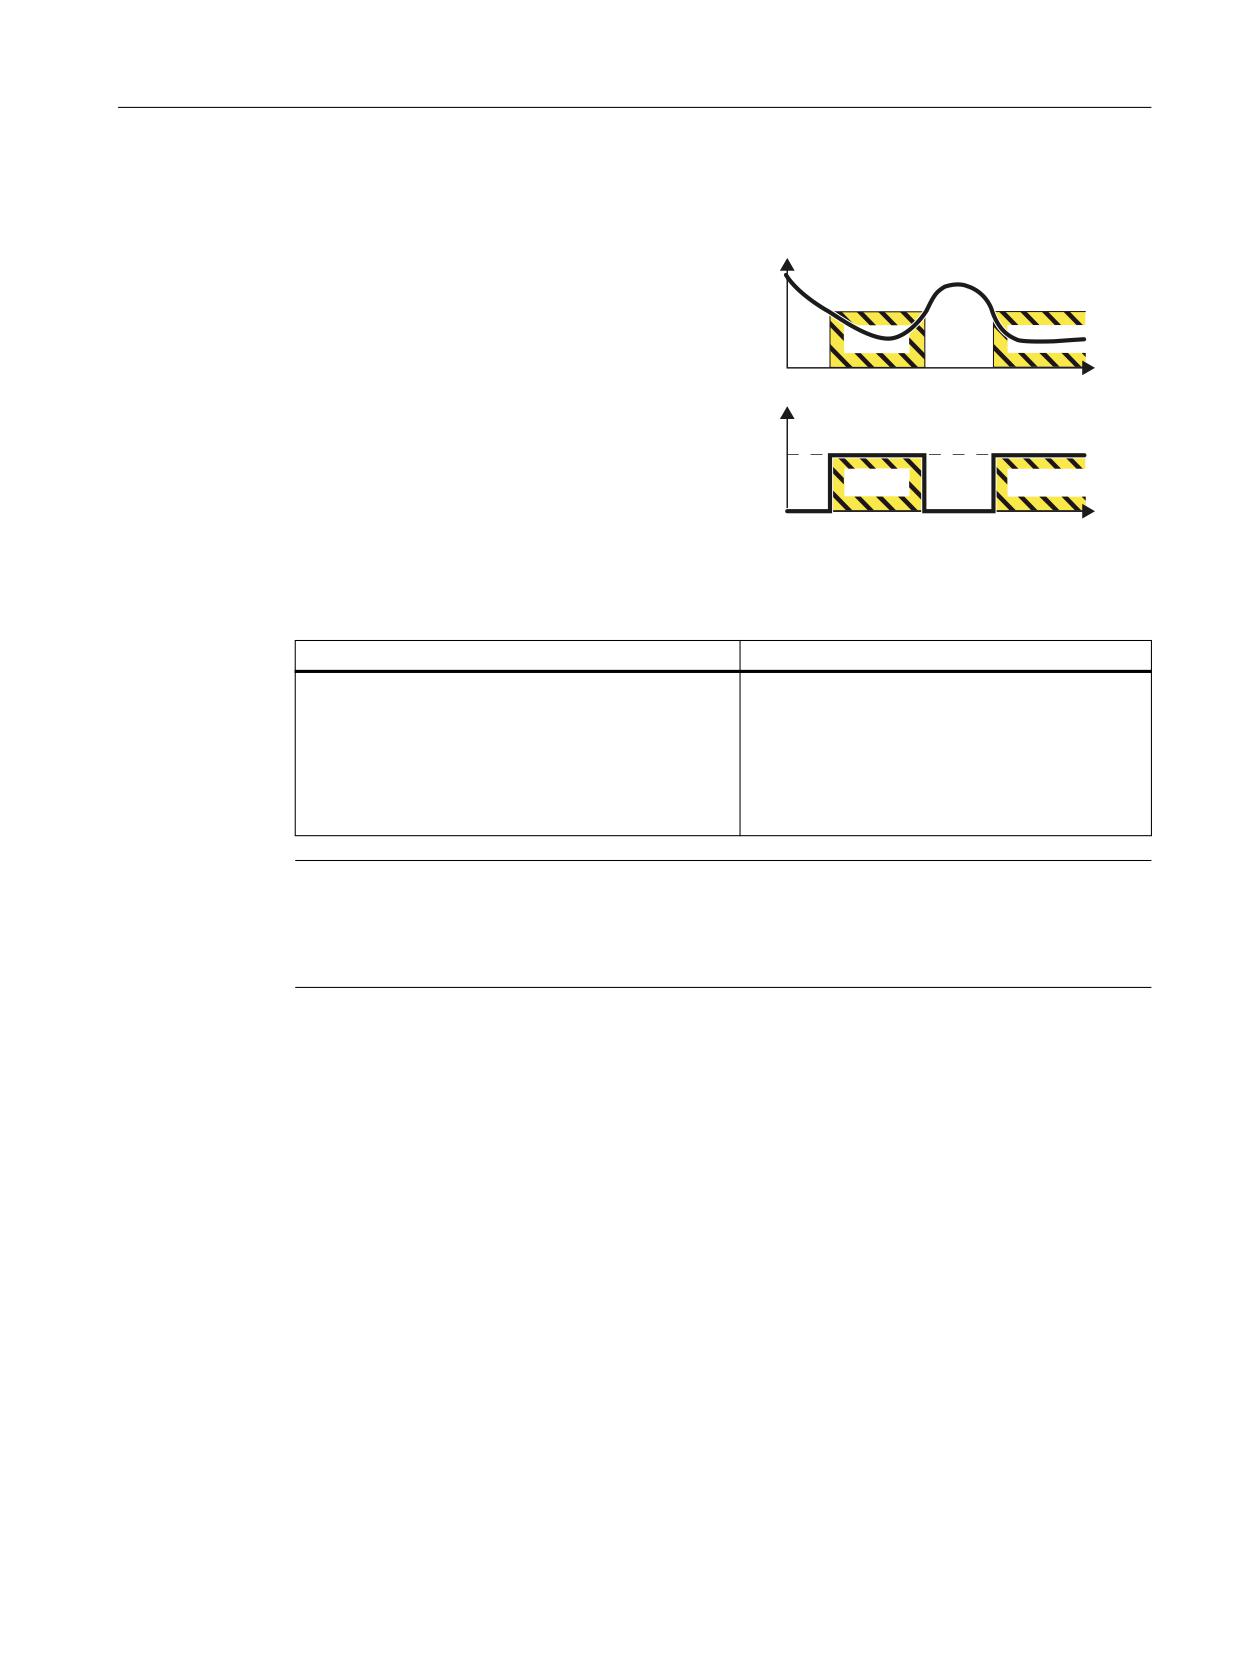
5.8
SSM
Definition according to EN 61800-5-2:
Y
"The SSM function supplies a safe out-
put signal to indicate whether the motor
speed is below a specified limit value."
W
660 RXWSXW VLJQDO
6SHHG
EHORZ WKH
OLPLW YDOXH
W
Example of how the function can be used
Example
Possible solution
A centrifuge may only be filled below a velocity de-
● SSM is active through the configuration of
fined by the user.
the Safety Integrated Extended Functions.
● The converter safely monitors the centrifuge
speed and enables the process to advance
to the next step using the "Status SSM" sta-
tus bit.
Note
SSM is a pure signaling function
Contrary to other safety functions integrated in the drive, a violation of the SSM limit does not
result in a drive-based stop response.
5.8.1
Details and parameterization
The "Safe Speed Monitor" (SSM) function provides a reliable method for detecting when a
speed limit has been fallen below in both directions of rotation, e.g. for zero speed detection. A
failsafe output signal is available for further processing.
Features
● Safety-relevant monitoring of the specified speed limit
● Parameterizable hysteresis
● Adjustable filter time (PT1 filter)
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
131
Safety functions integrated in the drive
5.8 SSM
● Safe output signal
● No stop response
Note
Unexpected response of STOP F for SSM
A STOP F is indicated by safety message 201711. STOP F only results in the subsequent
response STOP B / STOP A if one of the safety functions is active. If only the SSM function
without hysteresis (that is, p9501.16 = 0) is active, a STOP F cross-checking error does not
result in a STOP B / STOP A follow-up response.
● SSM is only considered to be an active monitoring function if "SSM with hysteresis" has
been activated.
How does SSMfunction in detail?
Requirements
The safety function SSM cannot be selected or deselected using external control signals. SSM
is active if, for the drive involved, the following settings have been made:
● Extended Functions are selected as safety function scope.
● The velocity limit for SSM is parameterized > 0.
Evaluating the speed
The converter compares the load speed with the speed limit and signals if the limit value is
undershot to the high-level control.
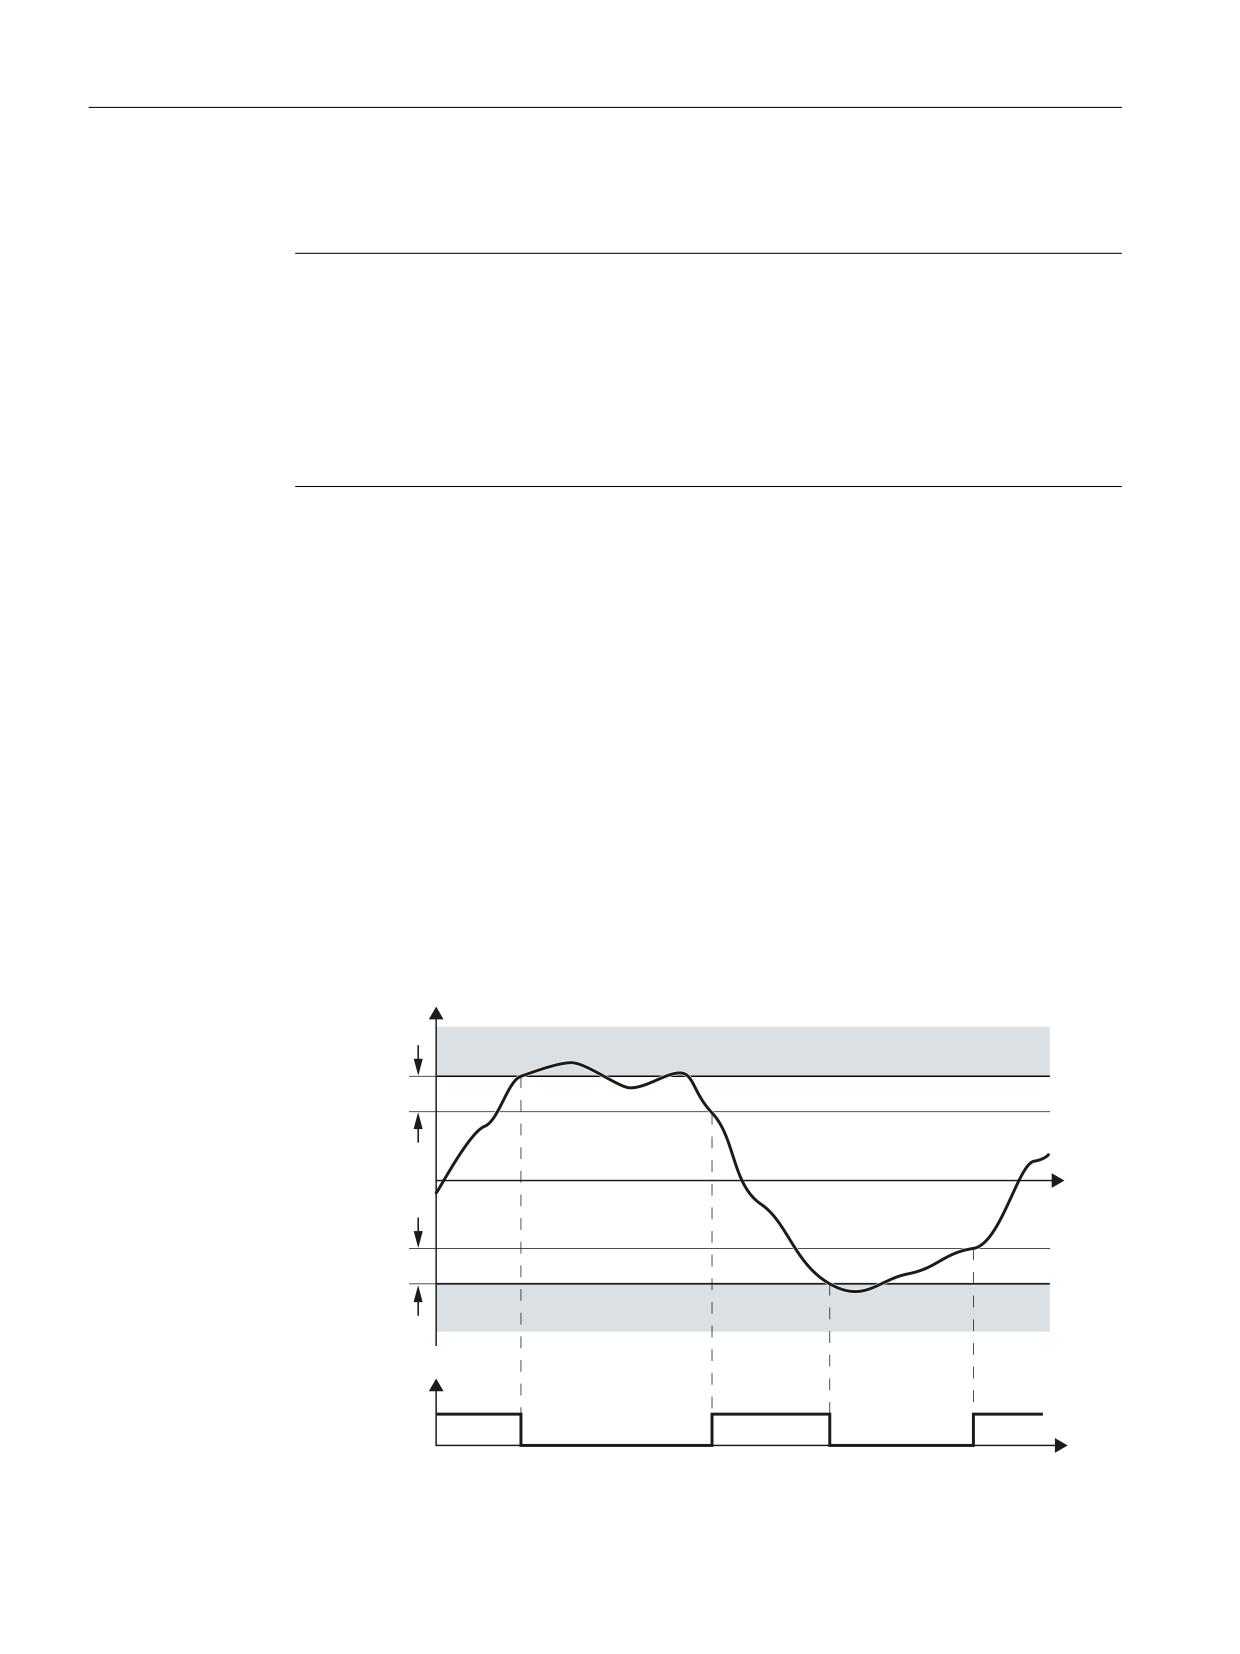
Parameterizable hysteresis
The parameterizable hysteresis ensures that the SSM output signal does not jump between the
values "0" and "1" in the limit range.
6SHHG
660
+\VWHUHVLV
W
+\VWHUHVLV
660
6SHHG EHORZ OLPLW
YDOXH
) '2 RU
352),VDIH VWDWXV ZRUG
W
Safety Integrated plus
132
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.8 SSM
Figure 5-17
Time response of the safety function SSM (Safe Speed Monitor)
5.8.1.1
Signal characteristic (with encoder)
Functional features of "Safe Speed Monitor" with encoder
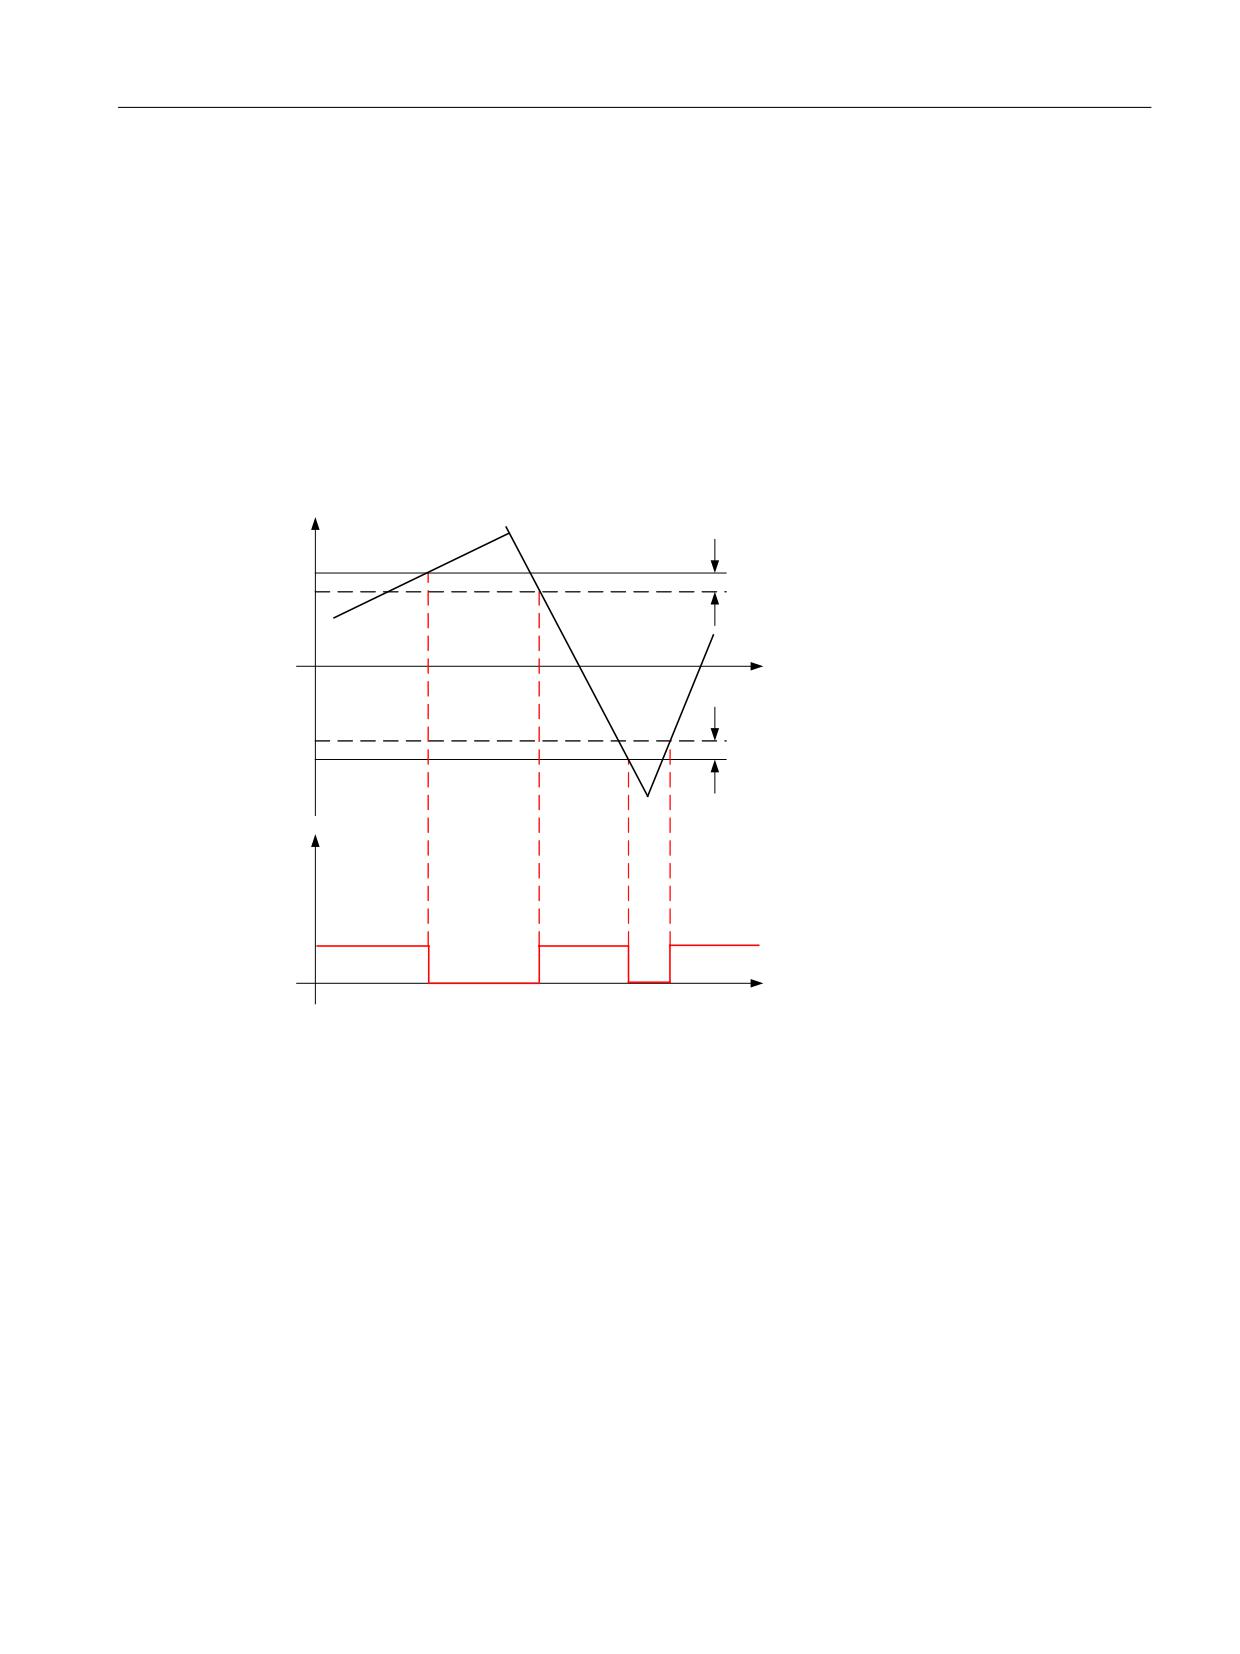
A hysteresis can be configured for the SSM function using (p9547). In this way, a more stable
signal characteristic of SSM can be achieved at velocities close to the velocity limit (p9546).
The following diagram shows the characteristic of the safe output signal SSM when the
hysteresis is active:
Q
Q[
S
+\VWHUHVLV S
W
+\VWHUHVLV S
Q[ S
660 RXWSXW VLJQDO
W
Figure 5-18
Safe output signal for SSM with hysteresis
5.8.1.2
Differences in operation without encoder
In operation, safety function SSM makes a distinction without encoder as a result of the
following features:
● Due to the less precise speed sensing, "Safe Speed Monitor without encoder" requires a
higher hysteresis (p9547) and, where applicable, a filter time (p9545) compared with the
function with encoder.
● For Safe Speed Monitor without encoder, after pulse suppression the drive is unable to
determine the current speed. For this operating state, the additional setting "Feedback
signal SSM for pulse inhibit" is available (see below)
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
133
Safety functions integrated in the drive
5.8 SSM
Note
Setting of the OFF1 or OFF3 ramp-down time
If the OFF1 or OFF3 ramp-down time is too short or the difference between the SSM limit speed
and the shutdown speed is too small, the "speed below limit value" signal may not change to
1, because no actual speed value could be determined below the SSM limit before pulse
suppression occurred. In this case, the OFF1 or OFF3 ramp-down time or the margin between
SSM speed limit and shutdown speed should be increased.
5.8.1.3
Signal characteristic (without encoder)
Procedure when the "Feedback signal SSM for pulse inhibit" setting is activated
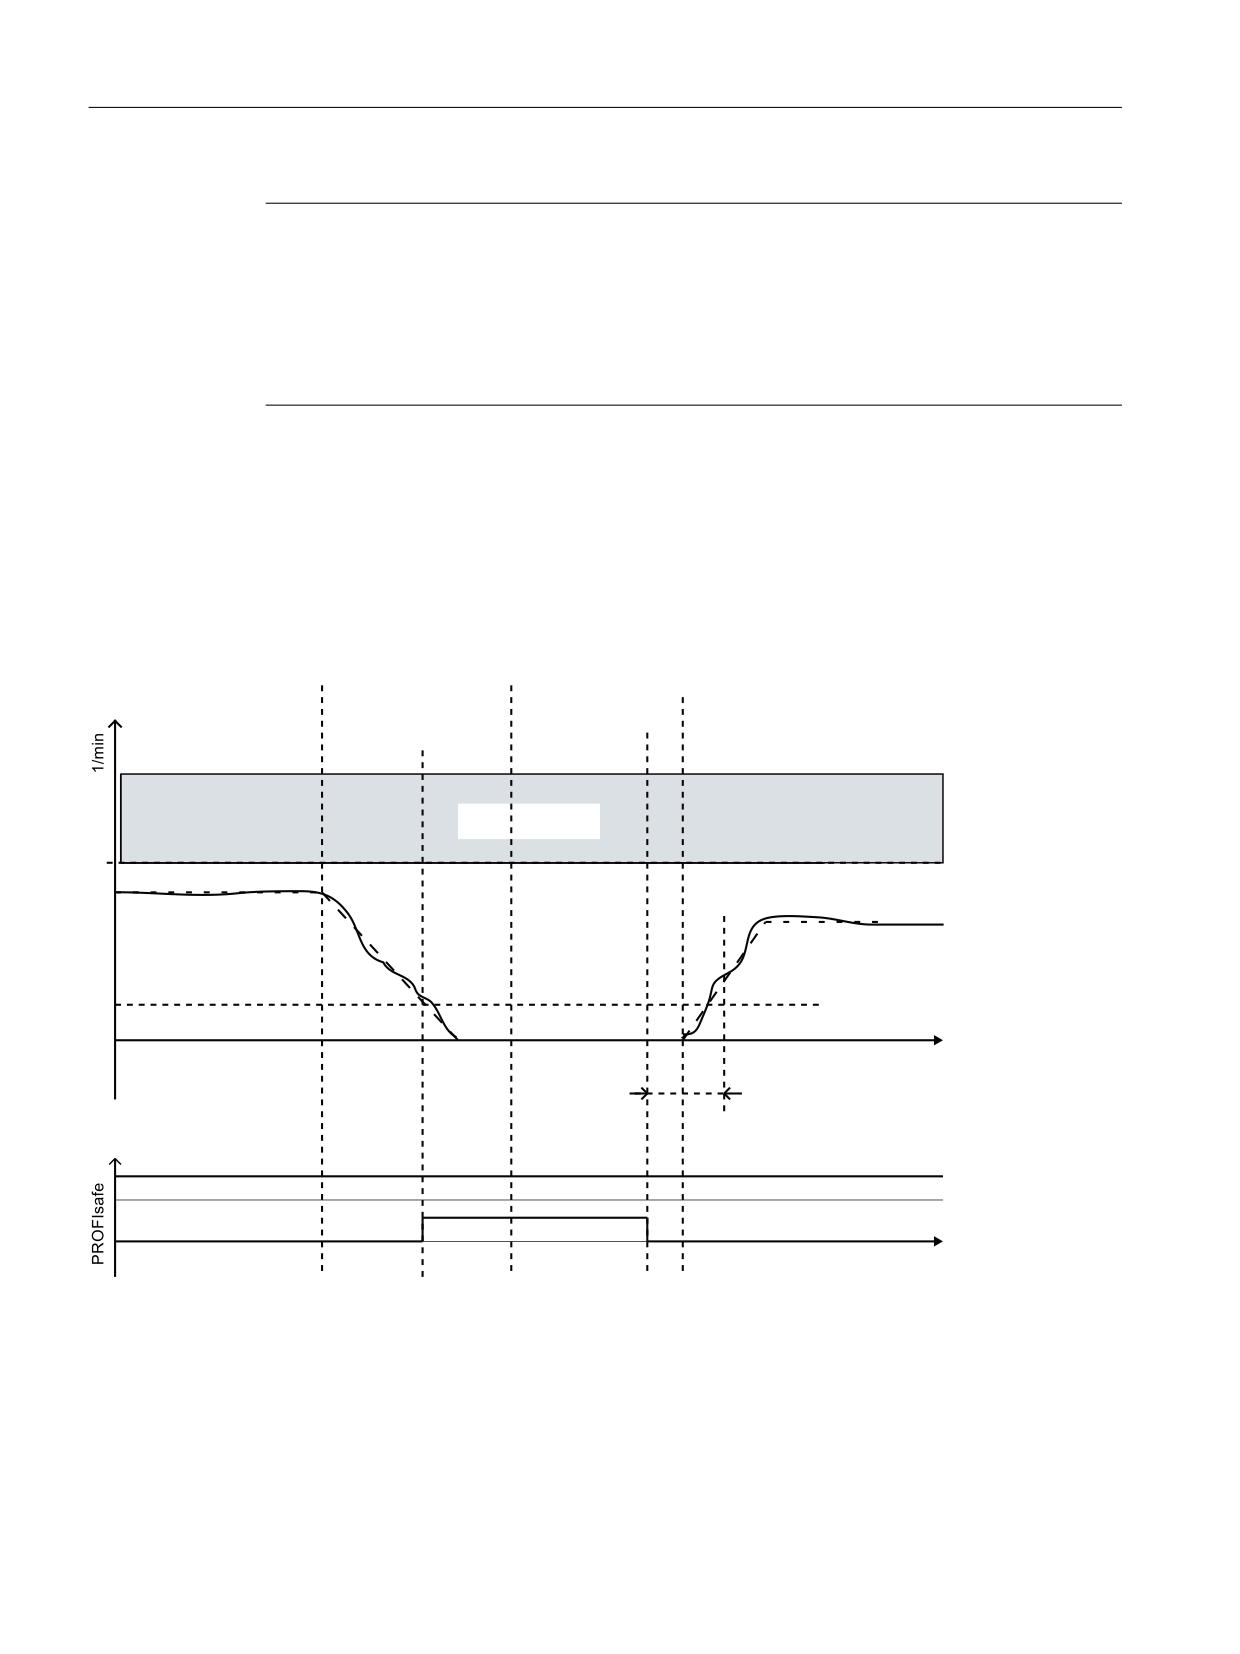
The following diagram shows the signal characteristic if the property "Feedback signal SSM for
pulse inhibit"is activated. (p9509.0 = 0)
3XOVHV
2))
6HOHFW 672
HQDEOHG
$XWRPDWLF
'HVHOHFW 672
6HOHFW 672
0R
QLWRULQJ
660 VSHHG
OLPLW
6SHHG
=HUR VSHHG GHWHFWLRQ
W
7LPHU V
660 IHHGEDFN VLJQDO
6DIH RXWSXW VLJQDO
3RZHU UHPRYHG 672
W
Figure 5-19
Flow chart: SSM without encoder with feedback signal SSM for pulse inhibit (p9509.0 = 0)
The speed remains below the speed limit throughout the entire monitoring period. This is the
reason that status signal "SSM (Speed below limit value)" goes to 1 (r9722.15 = 1). After the
command for pulse suppression, the motor speed drops. The internal STO is set when the
speed drops below the zero speed detection level.
In this case, the SSM status signal remains HIGH; it is frozen. The drive cannot accelerate
again, due to the internal STO selection.
Safety Integrated plus
134
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.8 SSM
To restart the motor safely, the STO must be selected manually and deselected once more.
After the STO has been deselected, a 5 second time window is opened. If the pulse enable
takes place within this time window, the motor starts. If the pulse enable does not take place
within this 5 second time window, the internal STO becomes active once more.
Procedure when the "Feedback signal SSM for pulse inhibit" setting is deactivated
When the property "Feedback signal SSM for pulse inhibit" is de-activated (p9509.0 = 1), then
SSM the monitoring is exited after the pulses have been canceled. Status signal "SSM (Speed
below limit value)" goes to 0 (r9722.15 = 0). The SSM monitoring is only reactivated after a new
pulse enable. In this case, STO must not be selected and deselected to start the drive.
Restart after pulse cancellation for p9509.0 = 0
If the drive pulses have been suppressed using OFF1/OFF2/STO, the following steps must be
carried out for a restart:
1. Case
● State after switching on
● SSM active
● STO selected
● Pulse suppression active
● Deselect STO
● The drive enable must be issued within 5 seconds via a positive edge at OFF1, otherwise
STO is reactivated.
2. Case
● Situation
● SSM active
● Motor turning
● OFF1 triggered, pulses are suppressed
● Select STO
● Deselect STO
STO activated internally via pulse suppression: This activation must be undone by se-
lecting/deselecting STO.
● The drive enable must be issued within 5 seconds via a positive edge at OFF1, otherwise
STO is reactivated.
5.8.1.4
Function diagrams and parameters
Function diagrams
●
2823
SI Extended Functions - SSM (Safe Speed Monitor)
●
2840
SI Extended Functions - SI Motion drive-integrated control signals/status
signals
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
135
Safety functions integrated in the drive
5.8 SSM
Overview of important parameters
Parameters
Parameter name or signal name
Designation in the function-specific
screen form
p9501
SI Motion enable safety functions (Control
-
Unit)
p9501.16
Enable SSM (n < nx) hysteresis and filtering
SSM with hysteresis
p9506
SI Motion function specification (Control Unit)
-
p9509
SI Motion behavior during pulse suppression
-
(Control Unit)
p9509.1
SSM during pulse cancellation and with no
Feedback signal SSM active for pulse
encoder
inhibit
p9545
SI Motion SSM (SGA n < nx) filter time (Con-
Filter time
trol Unit)
p9546
SI Motion SSM (SGA n < nx) speed limit (CU)
Speed limit
p9547
SI Motion SSM (SGA n < nx) speed hystere-
Hysteresis
sis n_x (CU)
r9722.0...14
CO/BO: SI Motion drive-integrated status
-
signals
r9722.15
SSM (speed below limit value)
Speed below SSM limit value
You can parameterize parameters that are marked in column "Designation in function-specific
screen form" using these.
Parameters not designated there are either part of the general NC and drive-specific settings
(Page 239) - or can only be configured using the expert list. The expert list can be reached in
the function-specific screen forms of the safety functions by pressing softkey "Parameter list".
Additional information
You can find a complete description of all SINAMICS parameters - as well as the associated
function diagrams - in the SINAMICS S120/S150 List Manual.
Safety Integrated plus
136
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.9 SAM
5.9
SAM
The "Safe Acceleration Monitor" (SAM) function is used to safety monitor braking along the
OFF3 ramp. The function is active for SS1, SS2 or STOP B and STOP C.
Features
As long as the speed is less, the converter continuously adds the adjustable tolerance p9548
to the actual speed so that the monitoring tracks the speed. If the speed is temporarily higher,
the monitoring remains at the last value. The converter reduces the monitoring threshold until
the "Shutdown speed" has been reached.
SAM recognizes if the drive accelerates beyond the tolerance defined in p9548 during the ramp-
down phase, and generates a STOP A. The monitoring function is activated for SS1 (or STOP
B) and SS2 (or STOP C) and is deactivated after the speed drops below the value set in p9568.
Note
Relationship between SSM and SAM
If 0 is entered for p9568, the speed limit of the SSM function (p9546) is also used as minimum
limit value for the SAM function (Safe Acceleration Monitoring). If the speed is below this limit,
SAM no longer triggers a response from the drive.
In this case, the effects of Safe Acceleration Monitoring are therefore significantly restricted if
a relatively high SSM velocity limit is set when using the SS1 and SS2 stop functions.
Note
No direct selection of SAM
SAM is part of the Safety Integrated Extended Functions SS1 and SS2 or STOP B and STOP
C. SAM cannot be individually selected.
Calculating the SAM tolerance of the actual speed
● The following applies when parameterizing the SAM tolerance:
- The maximum speed increase after SS1 or SS2 is triggered results from the effective
acceleration (a) and the duration of the acceleration phase.
- The duration of the acceleration phase is equivalent to one monitoring cycle (MC p9500)
(delay from detecting an SS1 / SS2 until nset = 0)
● Calculating the SAM tolerance:
Actual speed for SAM = acceleration × acceleration duration
The following setup rule is derived thereof:
- For linear axes:
SAM tolerance [mm/min] = a [m/s2] x MC [s] x 1000 [mm/m] x 60 [s/min]
- For rotary axes:
SAM tolerance [rpm] = a [rev/s2] x MC [s] x 60 [s/min]
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
137
Safety functions integrated in the drive
5.9 SAM
● Recommendation
The SAM tolerance value entered should be approx. 20% higher than the calculated value.
● You set the tolerance such that the "overshoot" is tolerated that necessarily occurs when
standstill is reached after braking along the OFF3 ramp. However, it cannot be calculated
as to just how high this is.
Note
First monitoring cycle
For SAM, in the first "SI Motion monitoring cycle" (p9500) a higher SAM tolerance is taken into
account in order to compensate for possible settling operations without resulting in an incorrect
initiation. The increase factor is calculated as follows:
SI Motion monitoring cycle (p9500) / SI Motion actual value acquisition cycle (p9511)
Example:
SI Motion monitoring cycle (p9500) = 12 ms
SI Motion actual value acquisition cycle (p9511) = 1 ms
SAM tolerance (p9548) = 300 rpm
Actual speed = 250
Rotary axis
In the first cycle after activation of the monitoring, the SAM limit value is therefore:
Actual speed + SAM tolerance · (12 ms/1 ms) =
250 rpm + 300 rpm · 12 =
approx. 3850 rpm
Responses
● Speed limit violated (SAM):
- STOP A
- Safety message C01706
● System fault:
- STOP F with subsequent STOP A
- Safety message C01711
Overview of important parameters (see SINAMICS S120/S150 List Manual)
● p9546
SI Motion SSM (SGA n < nx) speed limit (CU)
● p9548
SI Motion SAM actual speed tolerance (Control Unit)
● p9568
SI Motion SAM speed limit (Control Unit)
Safety Integrated plus
138
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.10 SBR
5.10
SBR
The Safe Brake Ramp (SBR) function provides a safe method for monitoring the brake ramp.
The Safe Brake Ramp function is used to monitor braking for functions "SS1 with/without
encoder," "SLS without encoder" - as well as for STOP B / STOP C (for Safety with encoder).
For SLS, the setpoint limiting of the Safety Integrated Functions (r9733) must be connected to
the ramp-function generator (p1051/p1052).
Features
The motor is immediately braked along the OFF3 ramp as soon as SS1, SS2, or SLS is
triggered. Monitoring of the brake ramp is activated once the delay time in p9582 has elapsed.
Monitoring ensures that the motor does not exceed the set brake ramp (SBR) when braking.
The safe monitoring of the brake ramp is deactivated
● For SS1:
- As soon as the speed drops below the shutdown speed (p9560).
Or:
- As soon as the SS2 delay time (p9552) has elapsed.
● For SLS:
- As soon as the set brake ramp has reached the new SLS level
Or:
- As soon as the actual speed drops below the newly selected SLS level and has remained
there for the time parameterized in p9582.
Additional specific functions (e.g. STO, new SLS speed limit, etc.) are activated at this point,
depending on the Safety Integrated Function used.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
139
Safety functions integrated in the drive
5.10 SBR
6HOHFW 6/6
6HOHFW 6/6 OLPLW
6HOHFW 6/6 OLPLW
6HOHFW 6/6
PP
8VHU DFWLRQ
8VHU DFWLRQ
8VHU DFWLRQ
8VHU DFWLRQ
VHW 6/6
VHW 6/6 OLPLW
VHW 6/6 OLPLW
VHW 6/6 OLPLW
GHVHOHFW 6/6
!
0RQLWRULQJ UDPS DFWLYH
(QYHORSH FXUYH
6/6 OLPLW YDOXH
!
0RQLWRULQJ UDPS DFWLYH
6/6 VHWSRLQW OLPLW
(QYHORSH FXUYH
6/6 OLPLW YDOXH
6/6 VHWSRLQW OLPLW
(QYHORSH FXUYH
6/6 OLPLW YDOXH
!
6/6 VHWSRLQW OLPLW
6
SHHG VHWSRLQW
$FWXDO VSHHG YDOXH
W
'LDJQRVWLFV
6/6 VHOHFWHG
6/6 DFWLYH
6%5 0RQLWRULQJ DFWLYH
352),VDIH
6/6 DFWLYH
6/6 OLPLW
6/6 OLPLW
W
! 6%5 GHOD\ WLPH
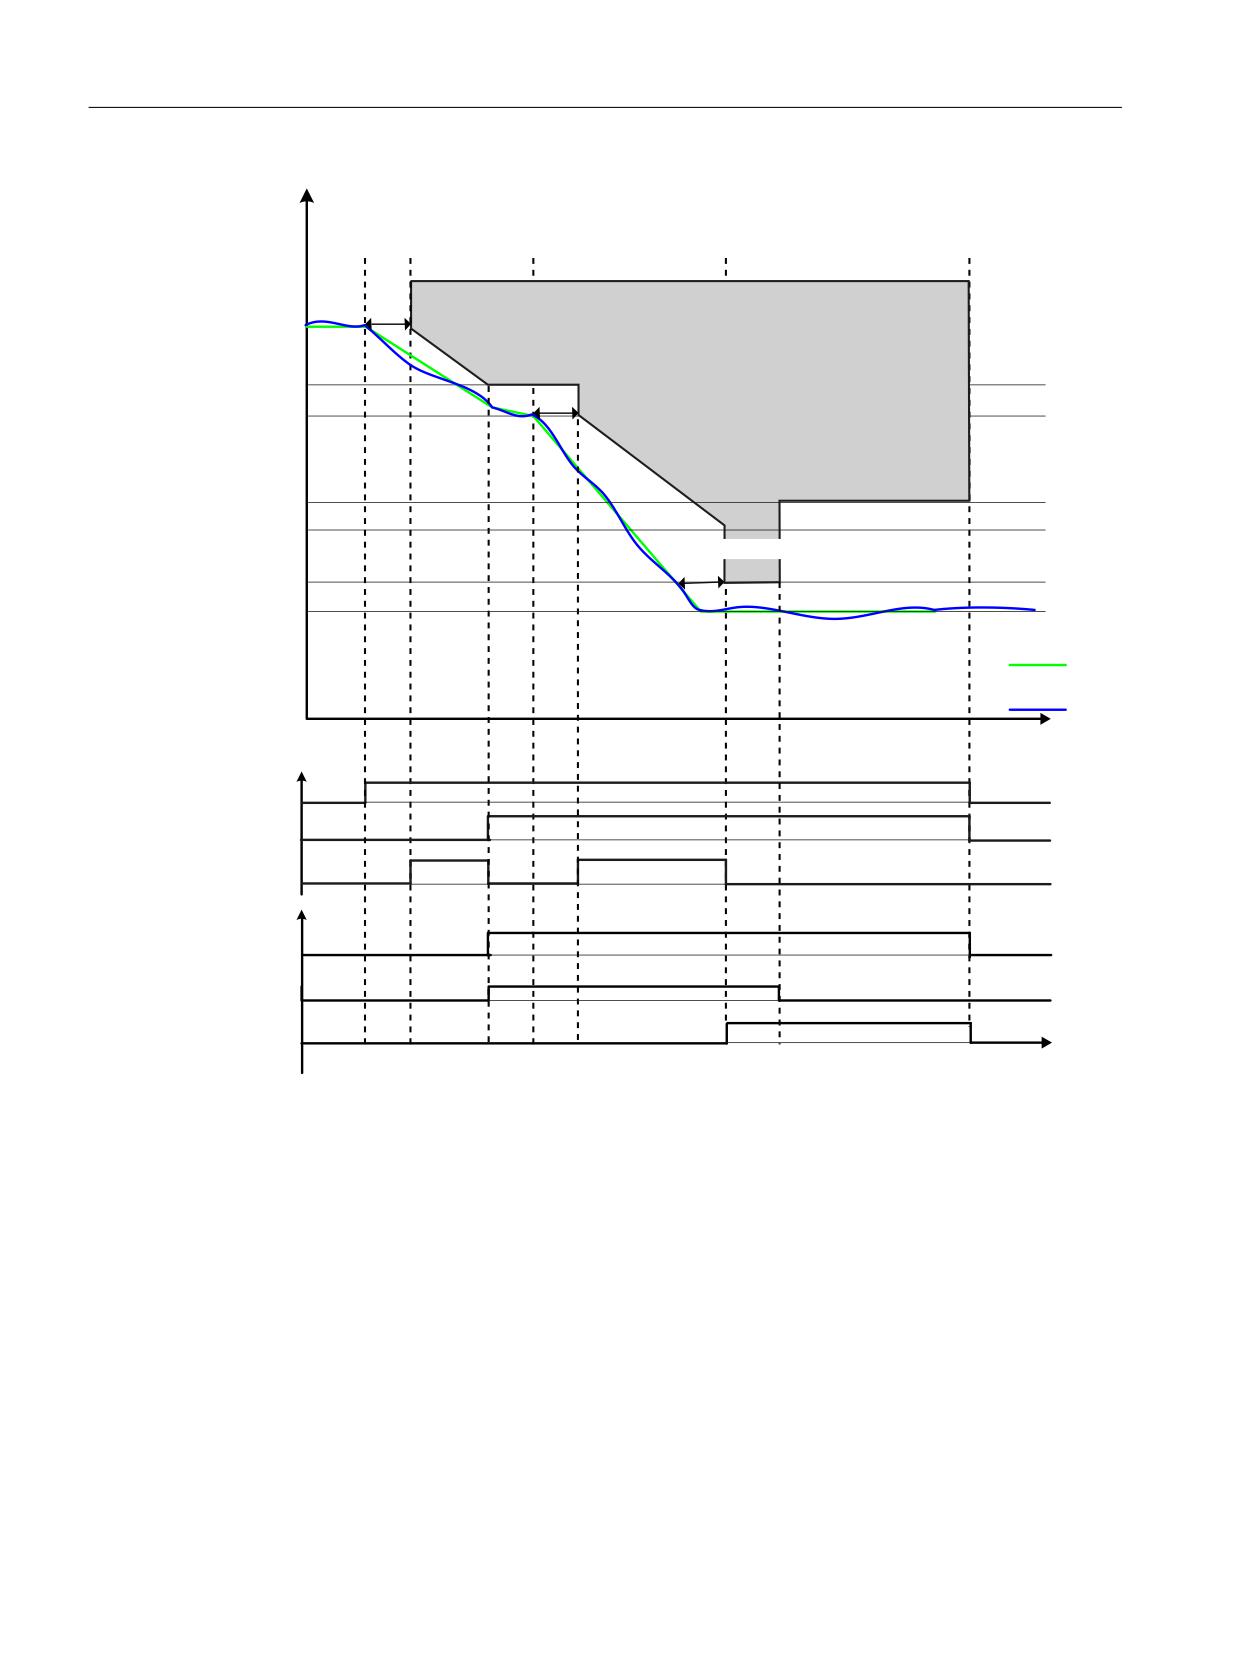
Figure 5-20
Safe Brake Ramp without encoder (for SLS)
Safety Integrated plus
140
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.10 SBR
Parameterization of the brake ramp
p9581 (SI Motion braking ramp reference value) and p9583 (SI Motion brake ramp monitoring
time) are used to set the gradient of the brake ramp. Parameter p9581 determine the reference
speed and parameter p9583 define the ramp-down time. Parameter p9582 is used to set the
time which passes after the triggering of SS1, selection of SLS or SLS level changeover and the
start of brake ramp monitoring.
Note
SBR and OFF3 curve
The SBR curve should be aligned to the OFF3 curve. In addition, you should check that under
every load condition, the drive can follow this OFF3 ramp.
Note
Limitation of the SBR delay time
The SBR delay time (p9582) is limited to a minimum value of 2 SI Motion monitoring cycles
(2 · p9500), i.e. even if a value less than 2 · p9500 is parameterized for the delay time (p9582),
SBR only takes effect 2 safety cycles after an active SS1.
If a value greater than 2 · p9500 is parameterized for the delay time (p9582), SBR takes effect
after active SS1 after the time p9582. Ensure that you round off the SBR delay time to an integer
multiple of the safety cycle (p9500).
Responses to brake ramp violations (SBR)
● Safety message C01706 (SI Motion: SAM/SBR limit exceeded)
● Drive is stopped with STOP A
● For an encoder fault in a 1-encoder system, the "Safe Acceleration Monitoring" function is
not active. A stop response, Category 0 or 1 (EN 60204-1), can be set with parameter
p9516.4.
Features
● Part of the "SS1 with/without encoder", "SS2 with encoder", "SLS without encoder" and
"STOP B/STOP C (for safety with encoder)" functions.
● Parameterizable safe brake ramp
5.10.1
Overview of important parameters
● p9560
SI Motion STO shutdown speed (Control Unit)
● p9581
SI Motion braking ramp reference value (Control Unit)
● p9582
SI Motion braking ramp delay time (Control Unit)
● p9583
SI Motion braking ramp monitoring time (Control Unit)
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
141
Safety functions integrated in the drive
5.11 SDI
5.11
SDI
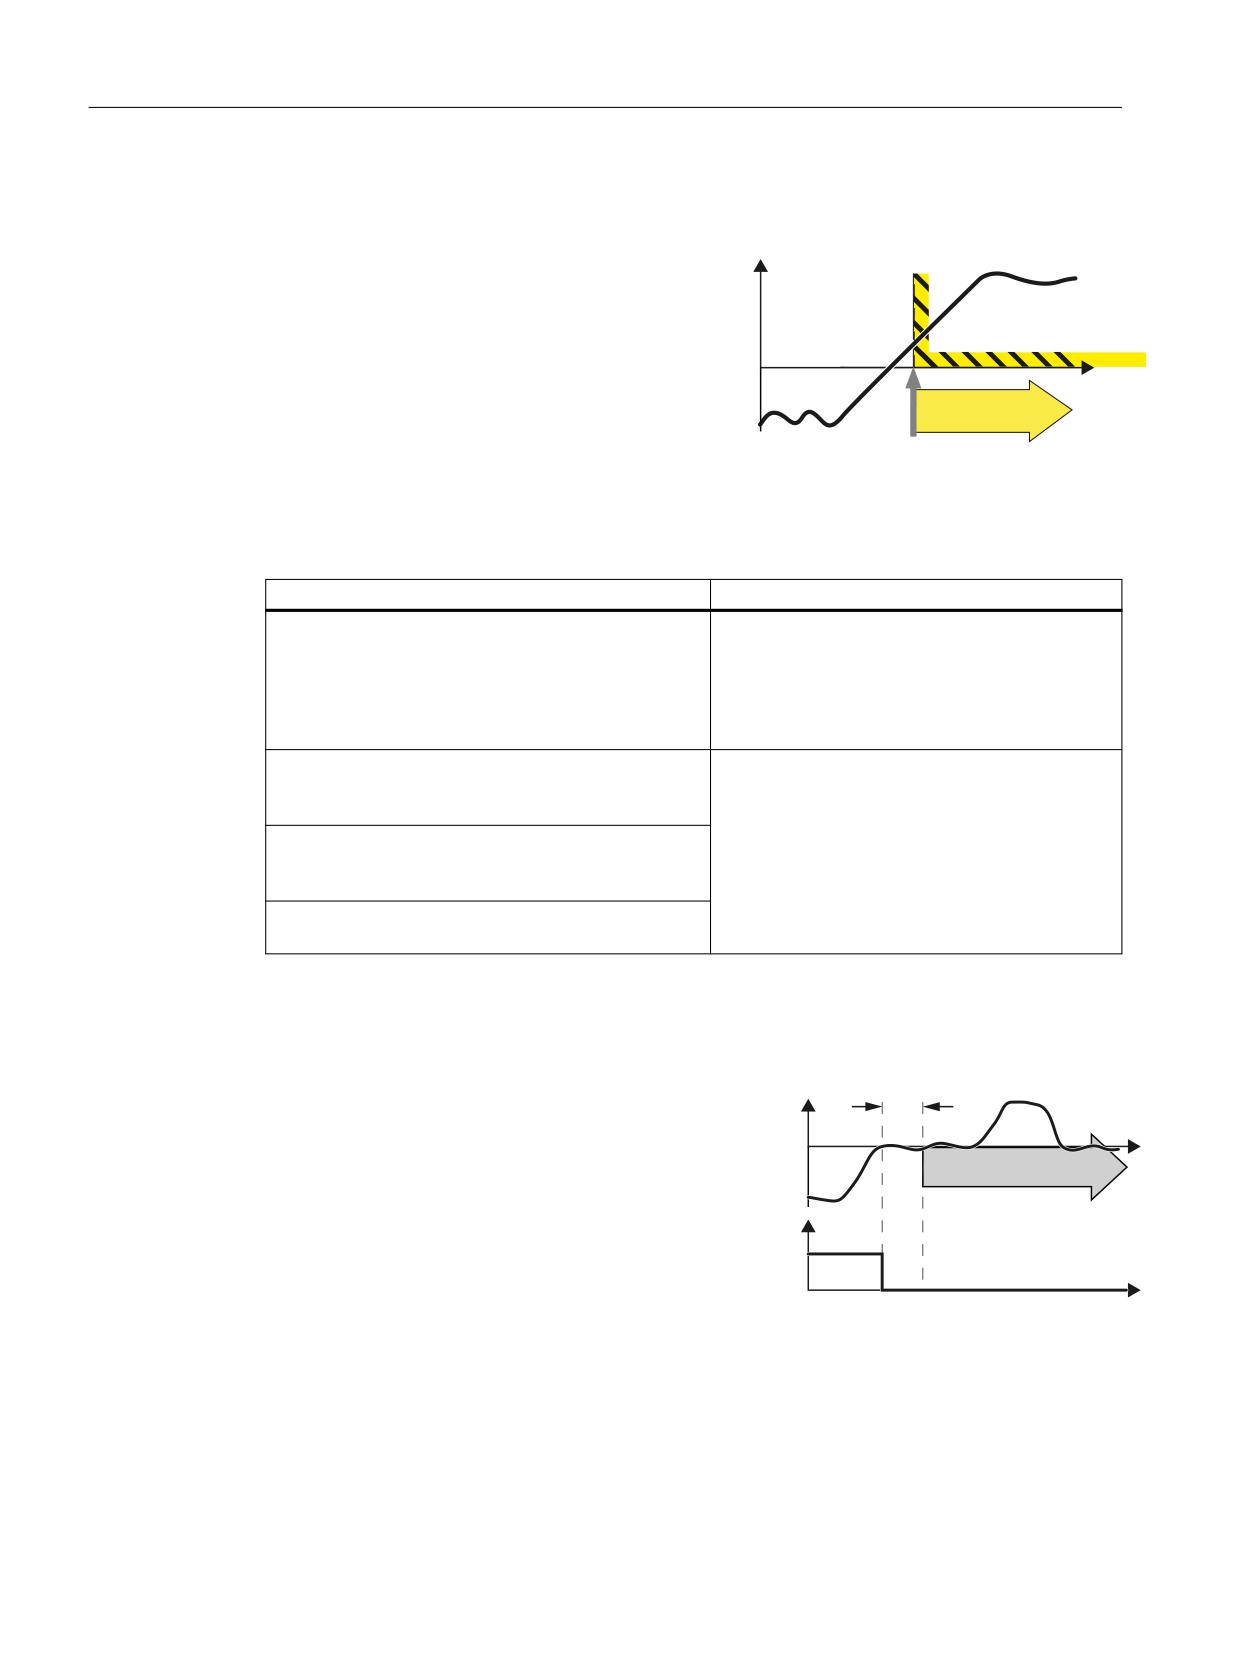
Definition according to EN 61800-5-2:
Y
"The SDI function prevents the motor shaft mov-
ing in the wrong direction."
W
SDI
Select SDI
Examples of how the function can be used
Example
Possible solution
A protective door must only be opened if a drive
● Select SDI in the converter using a fail-safe
moves in the safe direction (away from the operator).
input or PROFIsafe .
● Enable the locking mechanism of the protec-
tive doors via the PROFIsafe status bit of the
converter.
When replacing the pressure cylinders of the plates,
● Select SDI in the converter using a fail-safe
the drive must only move in the safe direction of ro-
input or PROFIsafe .
tation.
● In the converter, inhibit the direction of rota-
Once the protection against jamming has been trig-
tion that is not permitted.
gered, a roller shutter gate must only be able to start
moving in one direction.
At an operational limit switch, the trolley of a crane
must only be able to start in the opposite direction.
How does SDI function in detail?
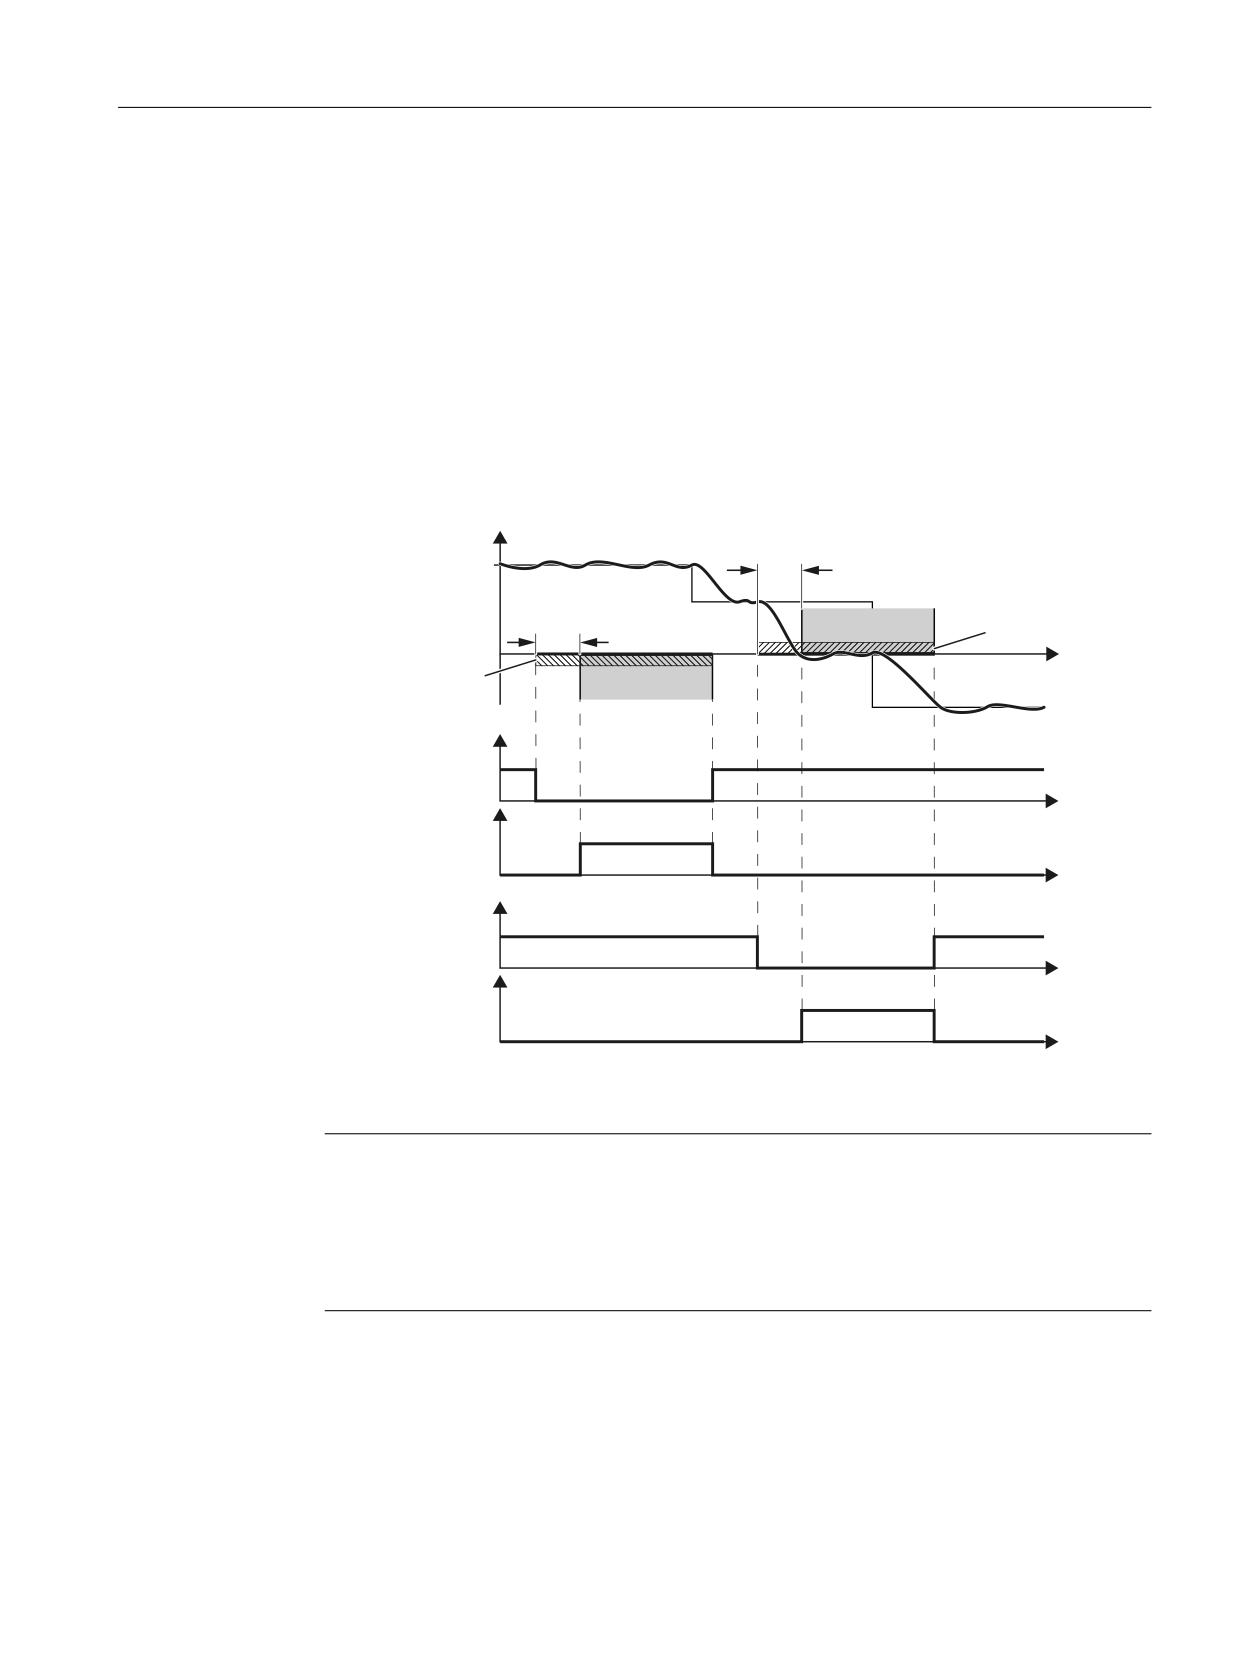
SDI (Safe Direction) monitors the actual
'HOD\ WLPH
6',
direction of rotation.
6SHHG
The SDI setpoint limit can be transmitted
to the F-PLC to enable limitation of the
6',
W
velocity setpoint.
In addition, you can configure the set-
6', GHVHOHFWLRQ
point limit provided by SDI as maximum
352),VDIH
speed in the ramp-function generator. In
FRQWURO ZRUG
this case, SDI limits the speed setpoint to
the permissible direction.
W
You can select to block either the positive or the negative direction of rotation via 2 fail-safe
signals (F-DIs or PROFIsafe).
Safety Integrated plus
142
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.11 SDI
Selecting and deselecting SDI
As soon as the converter identifies that SDIhas been selected via a failsafe input or via
PROFIsafe safe communication, the following happens:
●
You can also set a delay time, within which you can ensure that the converter moves in the
enabled (safe) direction.
●
You can also set a tolerance, within which the converter tolerates movement in the direction
that has not been enabled (unsafe). You can avoid the triggering of faults during braking
(overshoot) as well as in controlled standstill.
●
After the delay time has expired, the converter monitors the direction of rotation of the motor.
●
If the drive now moves more than the configured tolerance in the blocked direction, a
message is output and the defined stop response is initiated.
6SHHG
'HOD\
6HWSRLQW
'HOD\
/LPLWDWLRQ WR
6',
VSHHGV
W
/LPLWDWLRQ WR VSHHGV
6',
!
6', GHVHOHFWLRQ
352),VDIH FRQWURO ZRUG
6', DFWLYH
W
) '2 RU
352),VDIH VWDWXV ZRUG
W
6', GHVHOHFWLRQ
352),VDIH FRQWURO ZRUG
6', DFWLYH
W
) '2 RU
352),VDIH VWDWXV ZRUG
W
Figure 5-21
Time response of the safety function SDI (Safe Direction)
Note
SDI without selection
As an alternative to controlling via terminals and/or PROFIsafe, there is also the option of
parameterizing SDI without selection. In this case, SDI will be permanently active after
POWER ON. You can find details about this in section "Safe Direction without selection
(Page 147)".
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
143
Safety functions integrated in the drive
5.11 SDI
5.11.1
Details and parameterization
Note
Response to bus failure
If p9580 ≠ 0 and SDI is active, in the event of communication failure, the parameterized ESR
reaction is only realized if, as SDI response, a STOP with delayed pulse cancellation when the
bus fails has been parameterized (p9566[0...3] ≥ 10).
5.11.1.1
Safe Direction with encoder
The Safe Direction function (SDI) allows reliable monitoring of the direction of motion of the
drive. If this function is activated, the drive can only move in the enabled direction.
Principle of operation
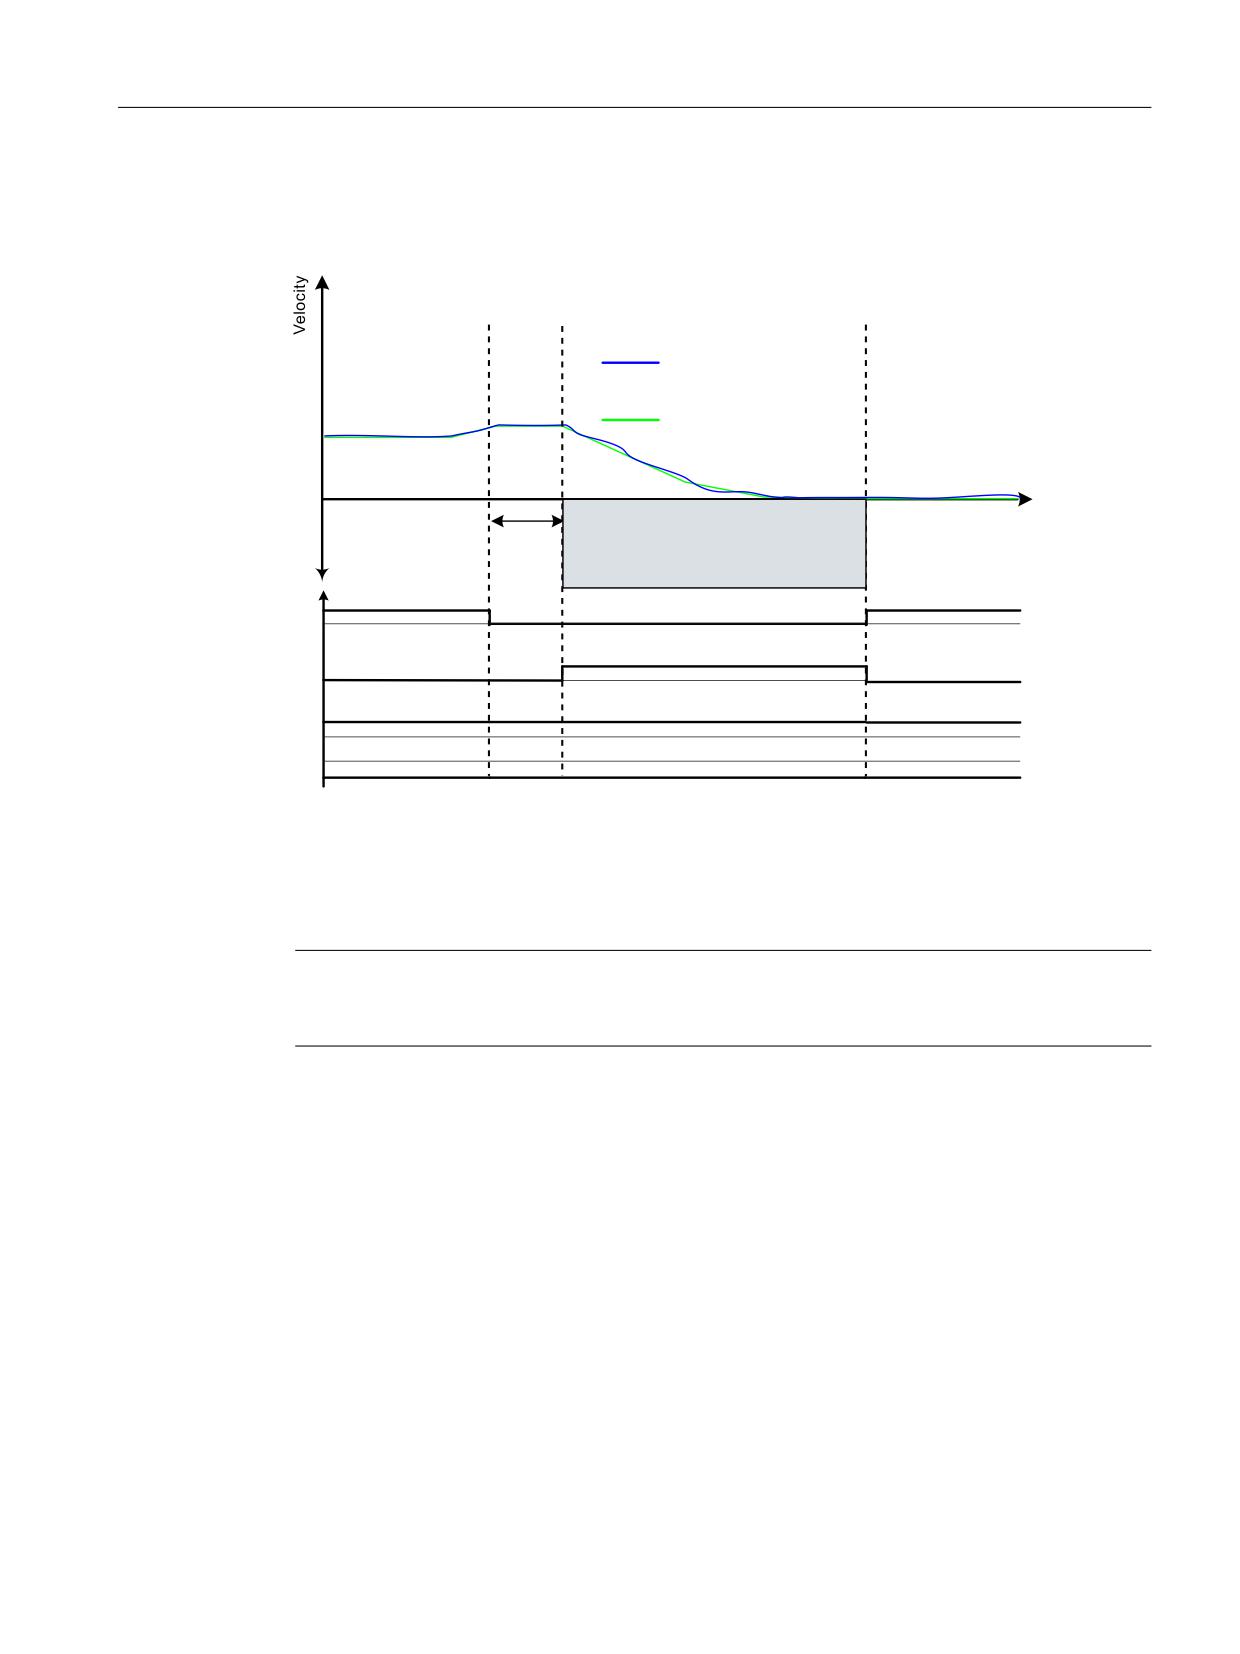
After SDI has been selected via terminals or PROFIsafe, the delay time p9565 is started. During
this time, you have the option of ensuring that the drive is moving in the enabled direction. After
this, the Safe Direction function is active and the direction of motion is monitored.
If the drive now moves more than the configured tolerance (p9564) in the blocked direction,
message C01716 is output and the stop response defined in p9566 is initiated. To acknowledge
the messages, you must first deselect SDI, correct the fault cause and then safely acknowledge
(Page 328) the messages. Only then can you reselect SDI.
Features
● Parameters r9720.12 and r9720.13 display whether the SDI function is selected.
● Parameters r9722.12 and r9722.13 display whether the SDI function is active.
● Parameter p9564 are used to set the tolerance within which a movement in a non-enabled
(non-safe) direction is tolerated.
● Parameter p9566 define the stop response in the case of a fault.
● If "SDI positive" is selected, the following value is set automatically:
- r9733[1] = 0 (setpoint limitation negative)
● If "SDI "negative" is selected, the following value is set automatically:
- r9733[0] = 0 (setpoint limitation positive)
● The absolute setpoint speed limit is available in r9733[2].
Safety Integrated plus
144
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.11 SDI
Enabling the Safe Direction function
The "Safe Direction" function is enabled with p9501.17 = 1.
6HOHFWLRQ
$FWLYDWLRQ
'HVHOHFWLRQ
6', SRVLWLYH
6', SRVLWLYH
6', SRVLWLYH
$FWXDO YHORFLW\ YDOXH
9HORFLW\ VHWSRLQW
W
6', GHOD\ WLPH
'LUHFWLRQ PRQLWRULQJ
'HVHOHFW 6',
SRVLWLYH
6', SRVLWLYH DFWLYH
'HVHOHFW 6', QHJDWLYH
6', QHJDWLYH DFWLYH
Figure 5-22
Functional principle SDI with encoder
5.11.1.2
Safe Direction without encoder
Note
You can find the parameterization for operation without encoder (p9506 = 1 or p9506 = 3) in
the commissioning screen form for the safety functional scope (Page 242).
Differences between Safe Direction with encoder and Safe Direction without encoder
● For Safe Direction without encoder, after pulse suppression the drive is unable to determine
the current speed. For this operating state, the behavior is defined using parameter p9509.8:
- p9509.8 = 1
The status signal displays "inactive".
- p9509.8 = 0
The status signal displays "active", and the drive takes on the state STO.
● Due to the less precise position recognition, "Safe Direction without encoder" requires a
larger tolerance (p9564) compared with the function with encoder.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
145
Safety functions integrated in the drive
5.11 SDI
Note
No detection of a change of direction with the aid of p1820 or p1821
If the direction of rotation is reversed via p1820 or p1821, then safe monitoring is still possible:
However, in this case, the setpoint limitation r9733 is calculated with the wrong direction of
rotation. A reversal of the rotational direction with p1820 or p1821 therefore does not make
sense.
Restart after pulse cancellation for p9509.8 = 0
If the drive has been switched off via OFF1/OFF2/STO etc., the following steps need to be
carried out before a restart can be performed:
1. Case
●
State after switching on
● SDI selected
● STO selected
● Pulse suppression active
●
Deselect STO
●
The drive enable must be issued within 5 seconds via a positive edge at OFF1, otherwise
STO is reactivated.
2. Case
●
Situation
● Traversing to standstill with SDI selected
● Initiate OFF1
● Pulses are canceled; internal selection STO becomes active
●
Select STO
●
Deselect STO
STO activated internally via pulse suppression: This activation must be undone by se-
lecting/deselecting STO.
●
The drive enable must be issued within 5 seconds via a positive edge at OFF1, otherwise
STO is reactivated.
3. Case
●
Situation
● Traversing to standstill with SDI selected
● Initiate OFF1
● Pulses are canceled; internal selection STO becomes active
●
Deselect SDI
STO activated internally via pulse suppression: This activation must be undone by de-
selecting SDI.
●
Select SDI
The drive enable must be issued within 5 seconds via a positive edge at OFF1, otherwise
STO is reactivated.
Safety Integrated plus
146
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.11 SDI
4. Case
● Situation
● All Safety Integrated functions are deselected.
● After this the drive enable must be given by a positive edge at OFF1.
● In this case, the motor is not started safely.
When acknowledging SDI with STOP C, you must maintain the following sequence:
1. Correct the incorrect setpoint input.
2. Deselect SDI.
While the safety STOP is active, this ensures that the motor cannot travel in the direction
that has not been enabled while the SDI function is deselected.
3. Select SDI again.
The SDI limits are then set again.
4. Cancel the safety STOP as a result of "safe acknowledgment".
5.11.1.3
Safe Direction without selection
Differences between Safe Direction with and without selection
● As an alternative to controlling via terminals and/or PROFIsafe, there is also the option of
parameterizing SDI without selection. In this case, SDI will be permanently active after
POWER ON (with encoder) or will be active after switch-on (without encoder).
● The "SDI without selection" function is activated as follows:
- p9512.12 = 1 (SDI positive static active)
- p9512.13 = 1 (SDI negative static active)
● The stop response is parameterized with p9566[0].
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
147
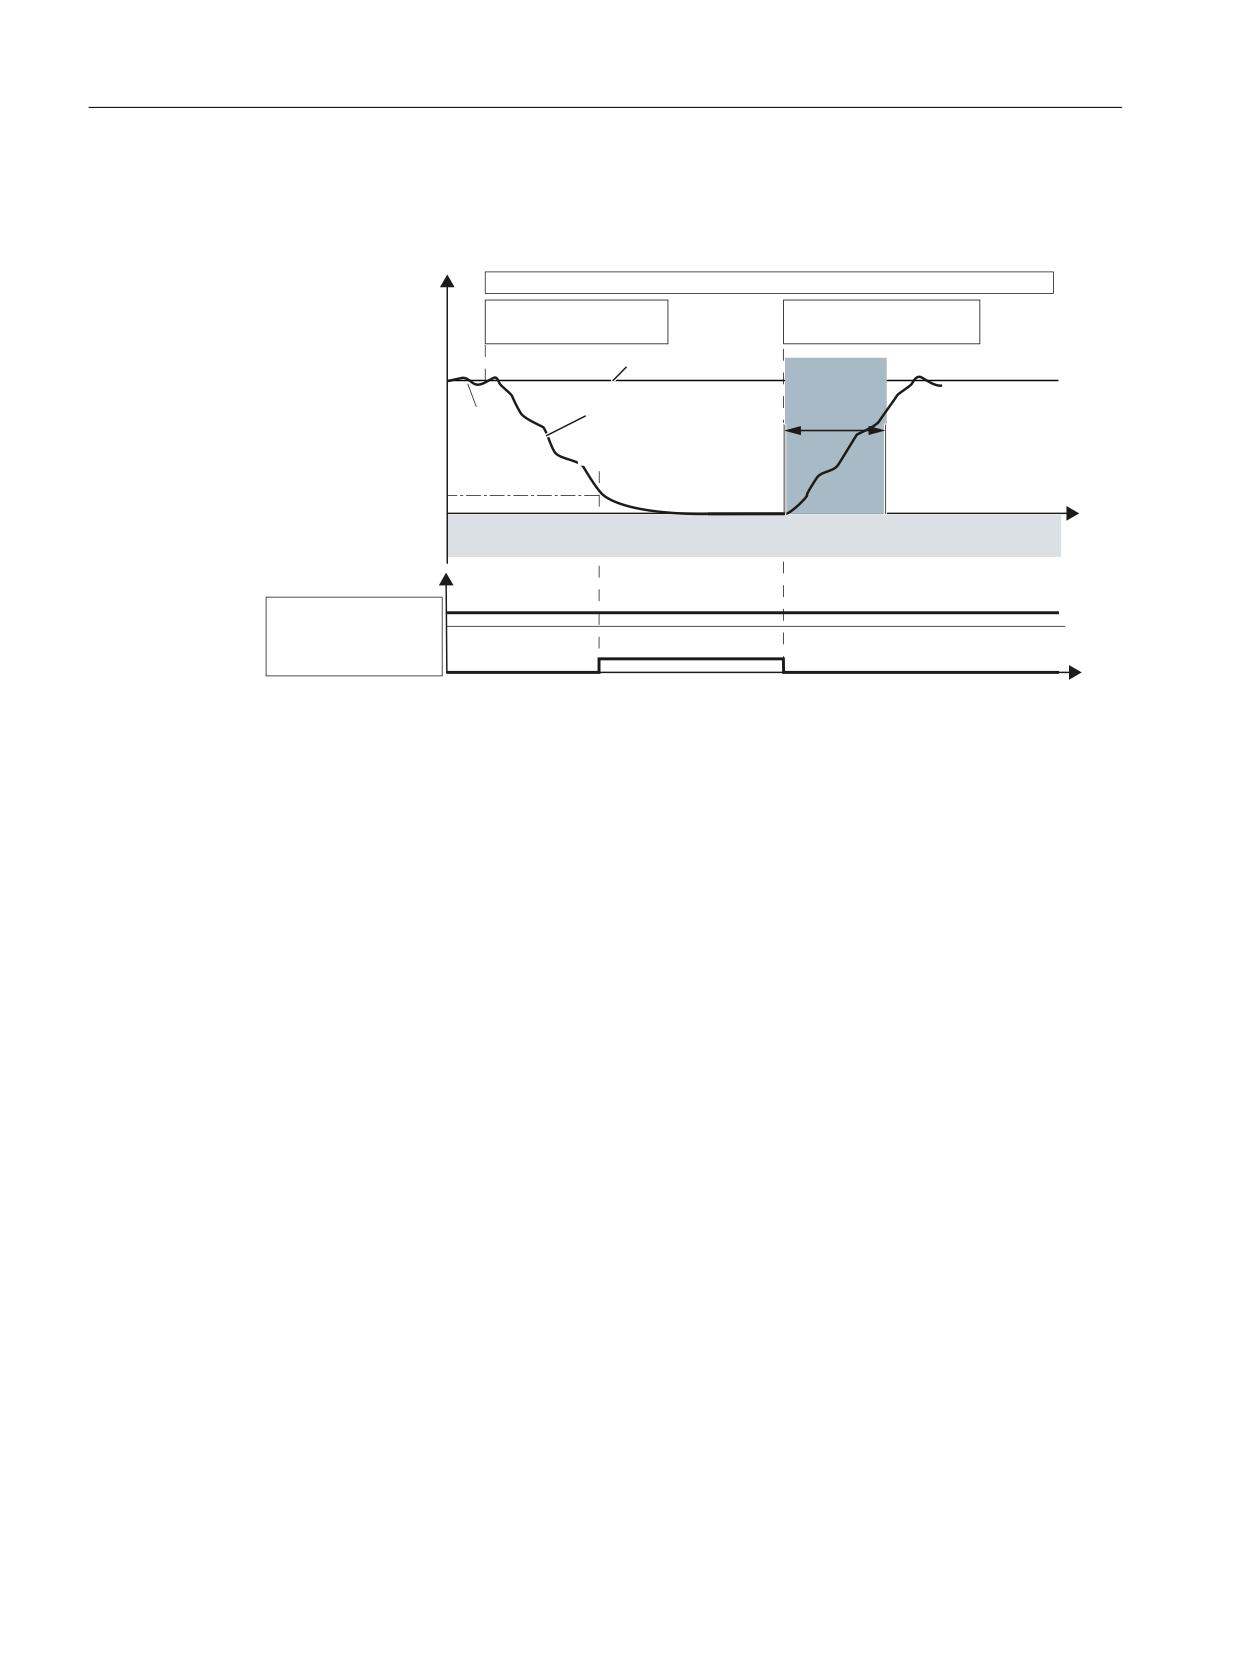
Safety functions integrated in the drive
5.11 SDI
Switching the motor on and off (without encoder)
The time response and diagnostic options are as follows in this SDI version:
/RDG VSHHG
2SHUDWRU DFWLRQV
6ZLWFK RII WKH PRWRU
6ZLWFK RQ PRWRU
2)) FRPPDQG
21 FRPPDQG
6HWSRLQW
5DPS IXQFWLRQ
$FWXDO
VHFRQGV
JHQHUDWRU UDPS GRZQ
YDOXH
WLPH
=HUR VSHHG
GHWHFWLRQ
W
6',
'LDJQRVWLFV
6', DFWLYH
6DIH SXOVH VXSSUHVVLRQ
DFWLYH
W
Figure 5-23
Time response of SDI without selection (example: Switching the motor on and off (without
encoder))
"SDI without selection" behaves as follows when switching off and switching on again:
● After switch-off, the motor behaves in accordance with the canceled signal (OFF1, OFF2 or
OFF3).
● STO (≙ safe pulse cancellation) becomes active after the standstill limit is undershot.
● After the ON command, the converter cancels the "safe pulse suppression" state and the
start procedure is initiated.
● If the minimum current has not been reached after 5 seconds, the converter returns to the
"safe pulse suppression" state and initiates the safety message C01711(1041).
5.11.1.4
Function diagrams and parameters
Function diagrams (see SINAMICS S120/S150 List Manual)
●
2824
SI Extended Functions - SDI (Safe Direction)
●
2840
SI Extended Functions - SI Motion drive-integrated control signals/status
signals
Overview of important parameters
● p1820[0...n]
Reverse the output phase sequence
● p1821[0...n]
Direction of rotation
● p9501.17
SI Motion enable safety functions (Control Unit): Enable SDI
Safety Integrated plus
148
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.11 SDI
● p9506
SI Motion function specification (Control Unit)
● p9509
SI Motion behavior during pulse suppression (Control Unit)
● p9564
SI Motion SDI tolerance (Control Unit)
● p9565
SI Motion SDI delay time (Control Unit)
● p9566
SI Motion SDI stop response (Control Unit)
● p9580
SI Motion pulse suppression delay bus failure (Control Unit)
● r9720.0...27
CO/BO: SI Motion drive-integrated control signals
● r9722.0...31
CO/BO: SI Motion drive-integrated status signals (Control Unit)
● r9733[0...2]
CO: SI Motion speed setpoint limit active
● p10017
SI Motion digital inputs debounce time (processor 1)
● p10030[0...3]
SI Motion SDI positive input terminal (processor 1)
● p10031[0...3]
SI Motion SDI negative input terminal (processor 1)
● p10039[0...3]
SI Motion safe state signal selection (processor 1)
● p10042[0...5]
SI Motion F-DO signal sources (processor 1)
● p10043[0...5]
SI F-DO 1 signal sources
● p10044[0...5]
SI F-DO 2 signal sources
● p10045[0...5]
SI F-DO 3 signal sources
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
149
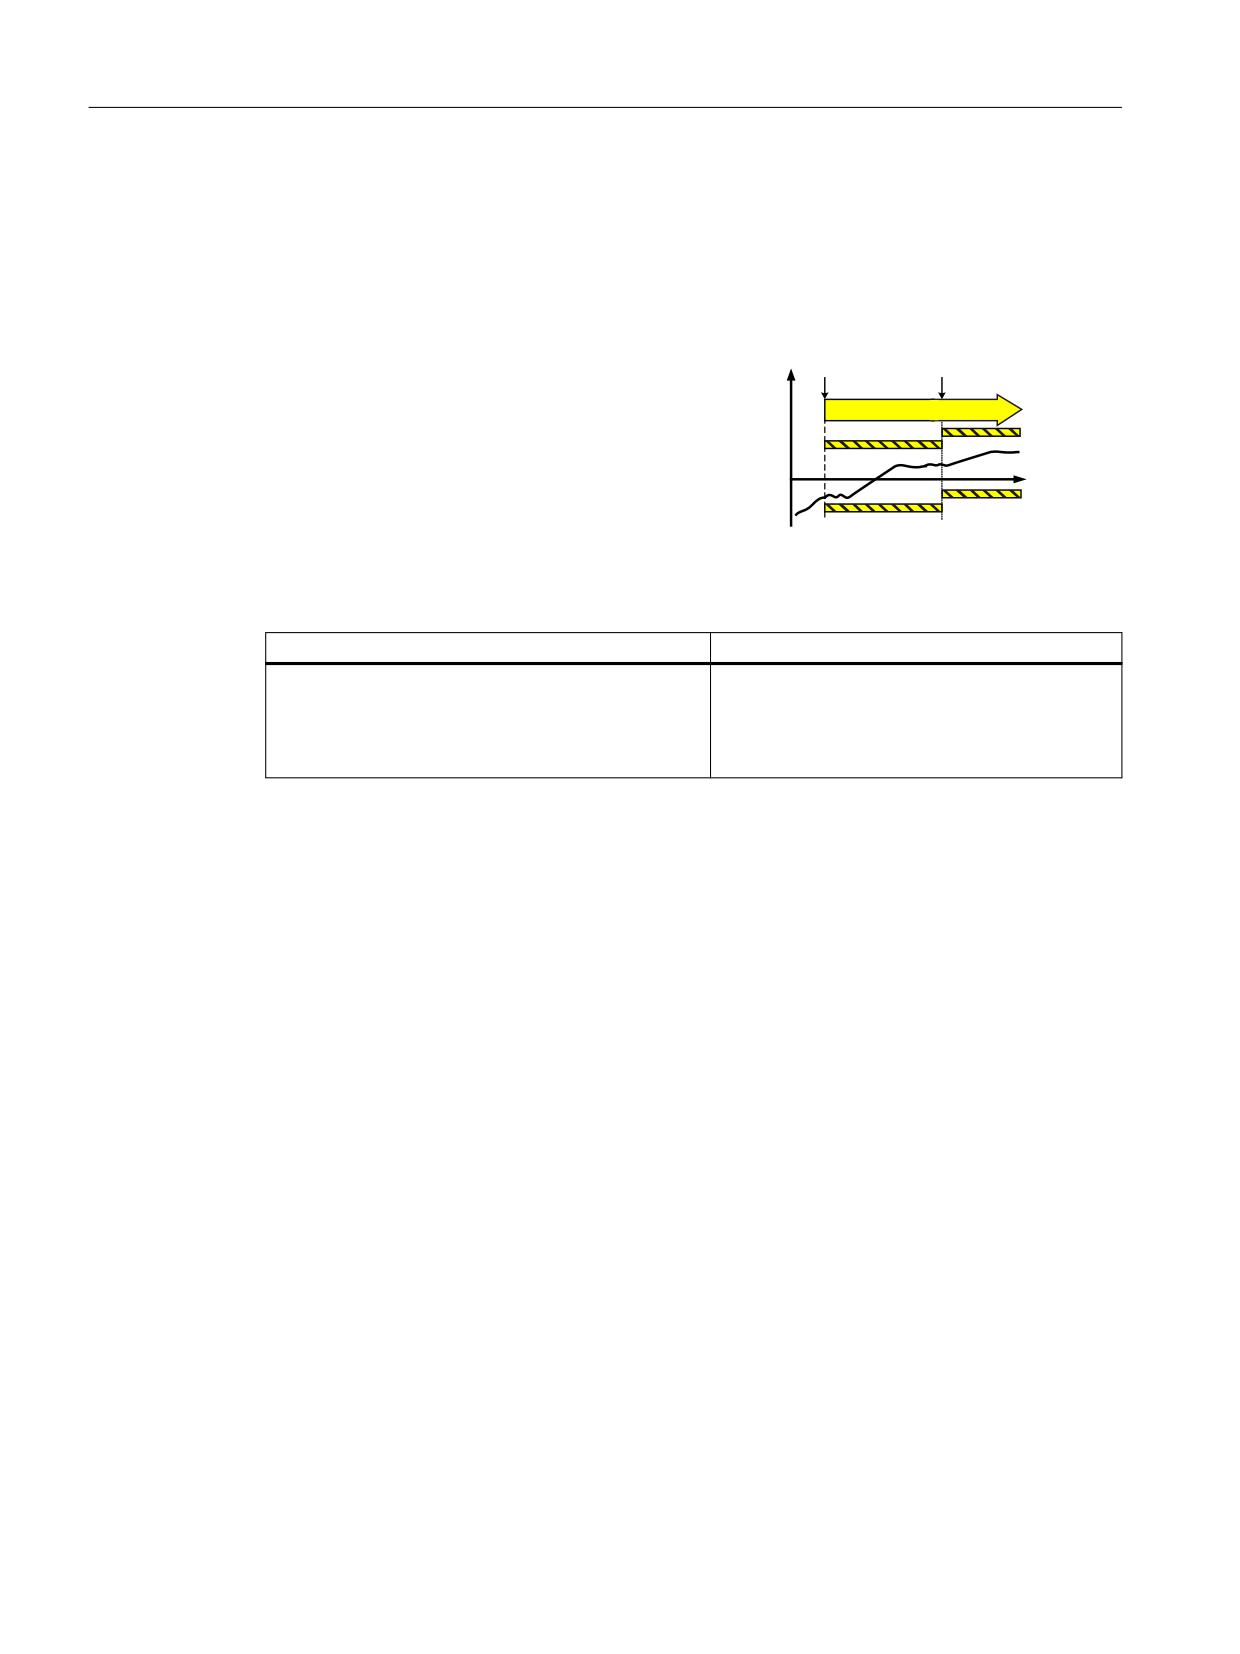
Safety functions integrated in the drive
5.12 SLP
5.12
SLP
5.12.1
Safely-Limited Position (SLP)
Definition according to EN 61800-5-2:
Y
6HOHFWLRQ
6ZLWFKRYHU
"The SLP function prevents the motor shaft from
6/3
exceeding the specified position limit(s)."
6 BR
6 BR
W
6 BX
6 BX
Examples of how the function can be used
Example
Possible solution
It is not permissible that the drive exits the specified
● Select SLP in the converter; inhibit the range
position ranges.
that is not permitted.
● After the enabled range has been exited, a
parameterizable stop response is initiated.
The Safely-Limited Position function (SLP) is used to safely monitor the limits of two traversing
and/or positioning ranges, which are toggled between using a safe signal.
Features
● Selection via terminals or PROFIsafe
●
2 position ranges, each defined by a limit switch pair
● Safe switchover between the two position ranges
● Adjustable stop response
● To move the motor out of the unauthorized range, you must execute a special sequence
(see "Retraction (Page 153)").
5.12.2
Details and parameterization
The Safely-Limited Position function (SLP) is used to safely monitor the limits of two traversing
or positioning ranges which can be switched over by a safe signal.
Requirements
For the Safely-Limited Position function, the following requirements must be met:
● The use of one or two suitable encoders for the extended safety functions with encoder (see
also Section "Safe actual value acquisition (Page 183)").
Safety Integrated plus
150
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.12 SLP
● Determining the absolute position of the drive by referencing during commissioning and
after all actions after which a safe absolute reference can no longer be guaranteed (POWER
ON, parking)
A description of safe referencing is provided in Section "AUTOHOTSPOT".
Principle of operation
As soon as SLP is active, maintaining the limits of the active positioning range is safely
monitored. With a safety signal you can switch between 2 position ranges. Each position range
is limited by its previously defined limit switch pair. When passing the position of one of the two
limit switches, a parameterizable stop response (STOP A, STOP B, STOP C, STOP D or STOP
E) is initiated and the messages C01715 are output.
To acknowledge this fault, you can either switch over to a range whose limits have not been
violated, or you can deselect the SLP function. After acknowledgment, the drive can then be
traversed again in the permissible range.
Traversing in the permissible range can be realized in a safety-relevant fashion using the
"Retract" function (see Chapter "Retraction (Page 153)").
Features
● Selection via safe terminals (onboard F-DI) or PROFIsafe
● Definition of the position range using 2 limit switch pairs (p9534 and p9535)
● Safe switchover between 2 different position ranges (not available for PROFIsafe telegram
30)
● Adjustable stop response (p9562)
Enabling the Safely-Limited Position function
● The "Safety-Limited Position" function is enabled with p9501.1 = 1.
● After the enable, POWER ON at the converter.
Note
No actual value synchronization for SLP
It is not permissible to simultaneously enable the SLP function and the actual value
synchronization (p9501.3 = 1). In this case, the drive outputs fault F01688.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
151
Safety functions integrated in the drive
5.12 SLP
Control and status signals from the SLP
Selecting SLP and switching over between the position ranges is performed via a PROFIsafe
control bit. SLP selection can be checked using parameter r9720.6. The selected position
range can be checked using parameter r9720.19. Status bit r9722.6 is set if SLP is active. The
active position range is displayed by r9722.19. Maintaining the upper or lower active SLP limit
can be checked using r9722.30 and r9722.31.
Note
Jumps in the display
There is no hysteresis available for r9722.30 and r9722.31. Small fluctuations in the area
around the range limit can result in the display jumping back and forth.
Controlling the Safely-Limited Position function
You have 2 options to select/deselect the Safely-Limited Position function and to switch over
the range limits:
● PROFIsafe
- SLP is selected/deselected using control words S_STW1.6 or S_STW2.6.
- Switchover between the two limit switch pairs using control word S_STW2.19.
- S_ZSW2.23 indicates whether the actual position is "safe"; for instance, the bit is only set
after the axis was "safely referenced".
- Whether SLP is active is indicated in bit 6 of the status words S_ZSW1.6 or S_ZSW2.6.
The bit is not set until SLP is selected and the axis is in the "safely referenced" state.
- Which SLP limit switch pair is active is indicated in status word S_ZSW2.19. This
indication is only valid if SLP is itself active.
- S_ZSW2.30 and S_ZSW2.31 indicate whether the upper or lower limit of the active
position range is maintained.
Note
Extended Functions via PROFIsafe
The status signal "SLP active" (S_ZSW1.6 or S_ZSW2.6) is not the same as the diagnostic
signal "SLP active" (r9722.6), but is the AND logic operation of "SLP active" (r9722.6) and
"safely referenced" (r9722.23).
The other SLP status signals S_ZSW2.19 "SLP active position range", S_ZSW2.30 "upper SLP
limit maintained" and S_ZSW2.31 "lower SLP limit maintained" match the corresponding bits in
r9722.
Safety Integrated plus
152
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.12 SLP
Note
Restrictions for PROFIsafe telegram 30
The use of PROFIsafe telegram 30 (with the 16-bit words S_STW1 and S_ZSW1) has the
following restrictions:
● Only position range 1 is available.
● A switchover to position range 2 is not possible.
● The status feedback signals "safely referenced", "active position range", "upper SLP limit
maintained" and "lower SLP limit maintained" are not available.
Note
Response to bus failure
If p9580 ≠ 0 and SLP is active, in the event of communication failure the parameterized ESR
reaction is only realized if, as an SLP response, a STOP with delayed pulse cancellation when
the bus fails has been parameterized (p9562[0...1] ≥ 10).
5.12.2.1
Retraction
After a limit of the active traversing range has been exceeded, the drive must be brought back
to the permissible range. A safety acknowledgment would, in this case, only retrigger the safety
messages; the drive would be prevented from moving. If a switchover to the other traversing
range doesn't come into question, then the only thing that remains is to deselect SLP. However,
this would have the disadvantage that it is not monitored as to whether the drive is moving in
the direction of the permissible traversing range.
Therefore, it is recommended that a retract function is implemented as follows:
Safety commissioning
1. Completely parameterize SLP.
2. Completely parameterize SDI.
3. Perform an acceptance test for both functions.
The next steps differ depending on the control type:
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
153
Safety functions integrated in the drive
5.12 SLP
Control via PROFIsafe
● Implement a user program in your F-CPU with the following steps to implement a retract
function:
- Select SDI positive in the case that the lower SLP limit is violated, or SDI negative if the
upper SLP limit is violated
- Wait until the selected SDI is active, then deselect SLP
- Safe acknowledgment of the limit violation
- Movement of the drive with suitable setpoint inputs in the range that has been enabled
- Select SLP
- Wait until SLP is active, then deselect SDI
Note
FAQ retraction
You will find a description of how retraction can be implemented via a failsafe control and
PROFIsafe communication in the Internet at:
5.12.2.2
Function diagrams and parameters
Function diagrams (see SINAMICS S120/S150 List Manual)
●
2822
SI Extended Functions - SLP (Safely-Limited Position)
●
2840
SI Extended Functions - SI Motion drive-integrated control signals/status
signals
Overview of important parameters (see SINAMICS S120/S150 List Manual)
● p9501
SI Motion enable safety functions (Control Unit)
● p9534[0...1]
SI Motion SLP (SE) upper limit values (Control Unit)
● p9535[0...1]
SI Motion SLP (SE) lower limit values (Control Unit)
● p9544
SI Motion actual value comparison tolerance (referencing) (CU)
● p9562[0...1]
SI Motion SLP (SE) stop response (Control Unit)
Safety Integrated plus
154
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.13 SP
5.13
SP
The "Safe Position (SP)" function enables you to
transfer safe position values to the F-CPU via
SP
PROFIsafe (telegram 901 or 902).
From the position change over a specific time,
the F-PLC can also calculate the actual velocity.
In telegram 902, the values are transferred in 32-
bit format, in telegram 901, in 16-bit format.
The position actual value is not transferred in
PROFIsafe telegram 903, which is preset for
SINUMERIK.
See also: Overview of process data telegrams
(Page 199)
After parameter assignment, release and POWER ON, the function is automatically selected
and the values transferred. Please observe the following:
● For use as the safe absolute position, the "Absolute position" must also be enabled and then
safely referenced.
● In order that the transferred position can be used, the actual position value must be valid.
Using the time stamp that is also transferred, you can also calculate the velocity from the
position values. If you only want to calculate the velocity, it is sufficient to enable the "Transfer
of safe position values" without the "Absolute position."
5.13.1
Details and parameterization
The function "Transfer safe position values (SP)" enables you to transfer a safe position (i.e.
absolute or relative position) to the F-PLC via PROFIsafe. Transfer of the safe relative position
(Safe Position SP) can be used to calculate the safe speed in the F-PLC. Its use for safe
position monitoring is only permissible if the reference to the absolute position was established
at the control level. In this case, the "safely referenced" bit of SINAMICS S120 (r9722.23)
cannot be used.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
155
Safety functions integrated in the drive
5.13 SP
Enabling the "Transfer safe position values" function
The following steps are required to enable the "Transfer safe position values" function:
● Enable the Safety Integrated Extended Functions
- p9601 = 12 = C hex (≙ Extended Functions via PROFIsafe)
or
- p9601 = 13 = D hex (≙ Extended Functions via PROFIsafe and Basic Functions via
onboard terminals)
● Enable "Transfer the safe absolute position with the possibility of calculating the velocity by
the controller"
- Select one of the PROFIsafe telegrams 901 or 902 (p60022, p9611, p9811)
- p9501.2 = 1 (≙ enable absolute position)
- p9501.25 = 1 (≙ enable transfer of safe position via PROFIsafe)
Note
No actual value synchronization when SP is enabled
If the transfer safe position value function is used, it is not permissible to enable actual value
synchronization (p9501.3 = 1): In this case, the drive outputs fault F01688.
● Enable the "Transfer safe relative position" only to calculate the speed by the controller
- Select one of the PROFIsafe telegrams 901 or 902
- p9501.25 = 1
● After the enable, POWER ON the converter.
Principle of operation
After parameter assignment, release and POWER ON, the function is automatically selected
and the values transferred. Please observe the following:
● Transfer of safe absolute position values
- If the transfer of the safe relative position has been enabled through p9501.25 = 1 and
p9501.2 = 0, the validity of the safe relative position is displayed by the set bit
S_ZSW2.22.
- If the transfer of the safe absolute position has been enabled using p9501.25 = 1 and
p9501.2 = 1, S_ZSW2.22 is only set when the drive has also been safely referenced.
● Transfer of safe relative position values (e.g. for calculating the velocity)
- Only S_ZSW2.22 (r9722.22, actual position value valid) must be set to calculate the
speed.
Safety Integrated plus
156
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.13 SP
Setting the modulo value for rotary axes
● p9505 is used to define the modulo range of a safety rotary axis (p9502 = 1) when the
transfer of a safe absolute position (p9501.2 = 1 and p9501.25 = 1) is enabled.
Parameterizing the modulo value can result in a jump in the position actual value for an
overflow of the range that can be represented. As a consequence, p9505 may only be
parameterizing steps of 2n × 360° (n = 1, 2, 3, …). In all other cases, the converter issues
alarm A01794. This alarm can be hidden in the case that the possible jump in the position
actual value can be tolerated in the particular application - or this does not present a
problem.
● The modulo function is deactivated if p9505 = 0. This parameter has no relevance for a
safety linear axis (p9502 = 0) or when the transfer of a safe relative position (p9501.2 = 0 and
p9501.25 = 1) is enabled.
● If SLP is also enabled (p9501.1 = 1), the modulo function must be deactivated (p9505 = 0).
Transfer formats and value range
●
32-bit
The values are transferred in telegram 902 as 32-bit values with the following value ranges:
Table 5-2
Value range and resolution (32 bits)
Linear axis
Rotary axis
Position values
±737280000
±737280000
Unit
1 μm
0.001 °
Comment
Monitoring ±737.280 m
≙ 2048 revolutions
with an accuracy of 1 μm
●
16-bit
To transfer the position values in telegram 901 in the 16-bit format, you must scale the
values using p9574. In this case, you must select the scaling factor so that the value of the
actual position value does not exceed the 16-bit format. If the actual position value exceeds
the range that can be displayed with 16 bits (±32767), a STOP F is initiated and message
C01711 is output with fault value 7001. Depending on the scaling factor, this means that
ranges with different sizes can be monitored with varying accuracy. Example:
- Scaling factor: 1000
- Unit: 1 μm (linear axis)
- Position value: ±32767 mm
It may therefore be precisely monitored in a range of ±32.767 m to an accuracy of 1 mm.
Note
Scaling to 16 bits
The scaling is performed by dividing the mean value of r9708[0] and r9708[1] with this
scaling factor.
Example: For a position of -29.999 mm signaled in r9708[0] and r9708[1] and a scaling
factor of p9574 = 1000, a numerical value of -29 is signaled to the controller.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
157
Safety functions integrated in the drive
5.13 SP
Value range r9708
The diagnostics information in parameter r9708 is displayed with the following properties:
Table 5-3
Value range and resolution (32 bits)
Linear axis
Rotary axis
Position values
±737280000
±737280000
Unit
1 μm
0.001 °
Comment
Monitoring ±737.280 m
≙ 2048 revolutions
with an accuracy of 1 μm
What is shown in parameter r9713 is identical to the values of r9708; however, in SINAMICS-
internal calculation units.
Speed calculation
The control must calculate the speed from the position change:
● Pos diff = Pos new - Pos old
● Cycle diff = cycle counter new - cycle counter old
● Timediff = Cyclediff × Safetycycle
(If Cyclediff = 0, the speed that was last calculated must be used.)
● v = Pos diff/time diff
● Format v
Acceptance test
An acceptance test is not required for the "Transfer safe position values" function, but the
function that was implemented with the aid of SP must be accepted in the higher-level
controller.
5.13.1.1
Function diagrams and parameters
Function diagrams (see SINAMICS S120/S150 List Manual)
●
2840
Extended Functions, control word and status word
Overview of important parameters (see SINAMICS S120/S150 List Manual)
● p9501
SI Motion enable safety functions (Control Unit)
● p9505
SI Motion SP modulo value (Control Unit)
● p9542
SI Motion actual value comparison tolerance (crosswise) (Control Unit)
● p9601
SI enable functions integrated in the drive (Control Unit)
Safety Integrated plus
158
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.13 SP
● r9708[0...5]
SI Motion diagnostics safe position
● r9713[0...5]
CO: SI Motion diagnostics actual position value load side
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
159
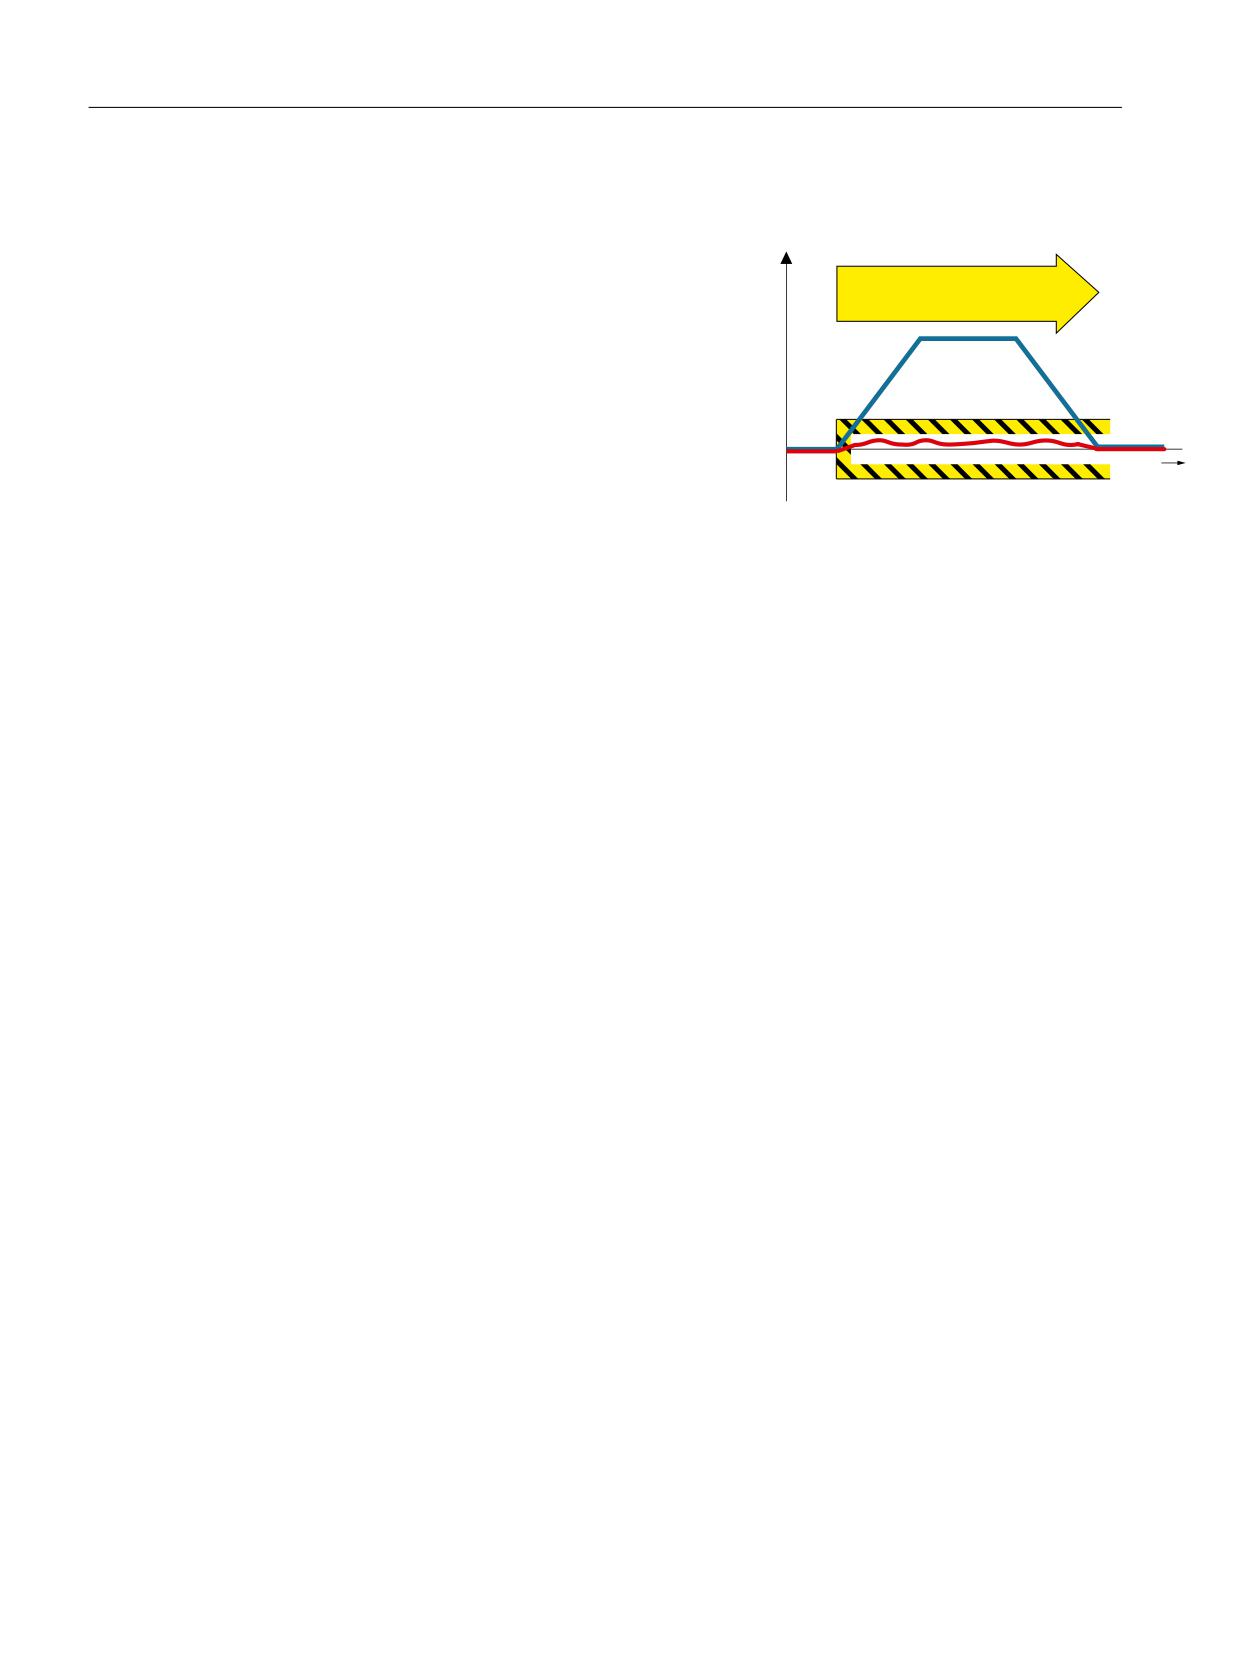
Safety functions integrated in the drive
5.14 SBT (diagnostic function)
5.14
SBT (diagnostic function)
The diagnostic function "Safe Brake Test" func-
0 V
tion (SBT) checks the required holding torque of
6%7
a brake (operating or holding brake).
You can test linear and rotary brakes. The drive
purposely generates a force/torque against the
applied brake. If the brake is operating correctly,
the axis motion remains within a parameterized
tolerance. If, however, a larger axis motion is
W
detected, it must be assumed that the braking
force/torque has deteriorated and maintenance
is required.
The "Safe Brake Test" function allows a safe test of up to two brakes:
●
1 motor holding brake and 1 external brake
●
2 external brakes
●
1 motor holding brake
●
1 external brake
The Safe Brake Test (SBT) diagnostic function is suitable for safety functions up to Category 2
according to ISO 13849-1.
5.14.1
Features
The Safe Brake Test function has the following properties:
● The parameters of the SBT function are protected by the safety password, and can only be
changed in the safety commissioning mode.
● Using this function, brakes can be tested that are directly connected to SINAMICS S120
(integrated brake control), but also externally controlled brakes (e.g. via a PLC).
● A maximum of 2 brakes can be tested:
- A motor holding brake, controlled by the integrated brake control of the SINAMICS, and
in addition, an externally controlled brake.
- Two externally controlled brakes
- A motor holding brake, controlled by the integrated brake control of the SINAMICS.
- One externally controlled brake
● The Safe Brake Test (SBT) diagnostic function is suitable for safety functions up to
Category 2 according to ISO 13849-1.
See also
Safety Info Channel and Safety Control Channel (SIC/SCC) (Page 205)
Safety Integrated plus
160
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.14 SBT (diagnostic function)
5.14.2
Connection to NC and PLC programs
The SBT function integrated in the drive does not require a setpoint from the PLC or NC - but
only an enable signal from the NC, and control via PLC user program. The relevant signals
when executing the brake test (SBT) are communicated between the PLC and drive via the
Safety Info Channel and the Safety Control Channel (SIC/SCC).
● SIC/SCC communication is realized using telegram 701 (Page 205). Telegram 701 is
automatically inserted in the TIA Portal configuration if you activate the Safety Integrated
plus mode (F-PLC).
● The SIC/SCC signals (to control SBT) are mapped in the axis DB
(axis 1 [DB31] ... axis 31 [DB61]). Bits (DBX11.0 and DBX71.0) in the relevant axis DB are
used to control SBT. As a consequence, you can execute the SBT via PLC user program.
See: Interface signals: Axis/spindle signals (Page 370).
Note
Information for those switching over from a different system: Block required for SBT (Safe
Brake Test)
The relevant axis DB is used to control SBT. The SI_BrakeTest [FB11] block - known from the
Safety Integrated mode (SPL) - is no longer used in the Safety Integrated plus (F-PLC) mode.
See also
PLC user interface (DB3x) (Page 206)
5.14.3
Details and parameterization
5.14.3.1
Requirements
NC
The following conditions must be met before the brake test is enabled by the NC:
● The axis must be at a standstill, and be in a safe axis position.
● The NC must have issued the controller enable and pulse enable.
DRV
The following requirements must be satisfied when using the "Safe Brake Test" function with
DRV:
● The Safety Integrated Extended Functions must be enabled; also available for the Safety
Integrated Extended Functions without selection.
● Safe Brake Control must be enabled when testing a brake controlled by SINAMICS (motor
holding brake).
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
161
Safety functions integrated in the drive
5.14 SBT (diagnostic function)
● Safety Integrated Extended Functions with encoder have been enabled.
You can find information about possible encoder concepts in Chapter "Safe actual value
acquisition (Page 183)".
Note
SBT only with encoder
The "Safe Brake Test" (SBT) safety function can only be used with an encoder.
● Speed control with encoder (p1300 = 21).
SBT is not possible with encoderless speed control (e.g. vector V/f control) and torque
control. In this case, alarm A01784 is output.
● The pulses must be enabled when SBT is selected. The actual speed value must not exceed
1 % of the maximum speed (p1082) when SBT is selected and over the complete time that
SBT is active.
● The brake(s) must be open
Note
SBT and HLA
The "Safe Brake Test" (SBT) function is not available for SINAMICS HLA.
5.14.3.2
Handling overview
Selecting SBT
1. In the associated axis DB, set bit "Start brake test" DBX11.0 = 1.
The NC checks that the appropriate conditions exist for the test to be performed:
- If the conditions are satisfied, then the "Brake test active" bit is set to 1 (DBX71.0 = 1).
- Alarm 27830 is output if the conditions are not satisfied.
2. Check whether the "Brake test active" bit (DBX71.0) is set to 1. It this is not the case, then
it is not permissible that you perform the SBT In this case, ensure that the requirements
(Page 161) are satisfied, and start again with step 1.
3. Select SBT via SCC by setting bit 0 "SELECTION_SBT" to 1 in STW3 (signal edge 0 => 1).
See also: Selection (Page 166)
In ZSW3, bit 1 "SETPOINT_SETTING_DRIVE" is set to 1 - which in the SIC signals that the
NC no longer enters the setpoint, but instead, DRV. The monitoring functions are
deactivated in the NC, and the setpoint is set the same as the actual value.
The brake test sequence is executed.
See also: Sequence (Page 167)
Safety Integrated plus
162
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.14 SBT (diagnostic function)
Deselecting SBT
1. Select SBT via SCC by setting bit 0 "SELECTION_SBT" to 0 in STW3 (signal edge 1 => 0).
See also: Selection (Page 166)
DRV initiates the de-selection process, and then in ZSW3 bit 1
"SETPOINT_SETTING_DRIVE" is set to 0. The setpoint chain from the NC is synchronized
to the actual values (setpoint position = actual position), the position is aligned and the
contour and standstill monitoring are reactivated again.
See also: Sequence (Page 167)
2. In the associated axis DB, set bit "Start brake test" DBX11.0 = 0.
The "Brake test active" bit is set by the NC to 0 (DBX71.0 = 0).
Canceling the brake test sequence (SBT)
If the brake test sequence (SBT) is canceled due to errors, then you can carry out the evaluation
and implement the resulting measures via the corresponding PLC interface signals.
See also: Cancellation/deselection and acknowledgment (SBT) (Page 168)
Note
Using MD36968.2 to select the parameter assignment behavior at the end of SBT
You can parameterize the positioning behavior after the brake test via the expert list using
MD36968.2 $MA_SAFE_BRAKETEST_CONTROL, bit 2:
●
0: Positioning at the actual axis position
To conclude the brake test, the actual axis position for the next path motion is used.
(MD36968 $MA_SAFE_BRAKETEST_CONTROL bit 2 = 0). This results in motion to the
last programmed axis position on the path.
●
1: Positioning to the last programmed axis position
Acceptance of the actual axis position is not carried out. After the axis has been pressed
against the brake, the closed-loop position controller withdraws the axis to the last
programmed position.
Vertical axes can thus be prevented from sagging as a result of a repeated brake test. It is
also possible to briefly exceed the software limit switch while pressing against the brake
without initiating an alarm.
See also
Enabling the function (Page 163)
5.14.3.3
Enabling the function
To enable the Safe Brake Test function, proceed as follows:
● Enable the Safe Brake Control (SBC) function when using an internal motor holding brake
(MHB): p9602 = 1.
● Select the SBT selection type:
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
163
Safety functions integrated in the drive
5.14 SBT (diagnostic function)
p10203
Selects SBT
= 0
Via SCC
= 1
Via BICO
= 2
For test stop / forced checking procedure
● Check the motor type; the following must apply: p10204 = r0108.12
For testing brake 1 [index 0] or 2 [index 1], initially, those values must be entered, which apply
to both test sequences:
●
Brake type
p10202[0,1]
SI Motion SBT brake selection
= 0
Inhibit
This must be set if one of the brakes is either not available or is not to be
tested.
= 1
Testing the motor holding brake
Here, in addition p1215 must be set to = 1
= 2
Setting an external brake
●
You define the holding torque of brakes using p10209.
●
Test torque ramp time p10208[0,1]
Within this time, before starting the test sequence, the test torque is ramped up - and at the
end of the sequence, is ramped down again.
Note
When testing an external brake, whose mechanical design exhibits backlash (e.g. if there is
a gearbox located between the motor and external brake), it can make sense to extend the
ramp time (p10208) when ramping up and ramping down the test torque.
●
The interconnection of the parameters for the telegram extension, relevant for SCC/SIC,
can be performed automatically by setting p60122 = 701. However, the telegram extension
must have been previously created. More detailed information on this can be found in
Chapter "Safety Info Channel and Safety Control Channel (SIC/SCC) (Page 205)".
●
The following parameters must also be set if you control the brake test using BICO signals
(p10203 = 1):
p10230.0
Signal for selecting the brake test
p10230.1
Signal for starting the test sequence
p10230.2
Signal for selecting the brake to be tested
(= 0: Brake 1; = 1: Brake 2)
p10230.3
Signal for selecting the sign of the test torque
(= 0: positive; = 1: negative)
p10230.4
Signal to select the test sequence (= 0: sequence 1; = 1: sequence 2)
p10230.5
Feedback signal for the state of the external brake
(= 0: external brake open; = 1: external brake closed)
Safety Integrated plus
164
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.14 SBT (diagnostic function)
You can parameterize 2 test sequences for each brake. Each test sequence is characterized
by the following setting values:
● Brake test sequence 1
p10210[0,1]
Test torque to be generated in % of the brake holding torque
p10211[0,1]
Test duration in ms
p10212[0,1]
Positional deviation to be tolerated in mm/degrees during the test
● Brake test sequence 2
p10220[0,1]
Test torque to be generated in % of the brake holding torque
p10221[0,1]
Test duration in ms
p10222[0,1]
Positional deviation to be tolerated in mm/degrees during the test
● Perform a POWER ON after commissioning
Note
SBT and EPOS
If EPOS is activated, you must activate "follow-up mode" (r2683.0) before you perform the
brake test so that the position monitoring does not react during the brake test.
Note
SBT and DSC
If SBT is used with DSC, parameter r10234 (S_ZSW3B) must be evaluated and Safety Control
Channel control word 3B (S_STW3B) must be activated. In the PLC, r10234.1 specifies that no
position monitoring may be active during the brake test (the same applies of course for
traversing).
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
165
Safety functions integrated in the drive
5.14 SBT (diagnostic function)
5.14.3.4
Selection
You have the following options for the selection of the Safe Brake Test:
● Safety Control Channel (SCC) via PROFIBUS or PROFINET (integrated drives, external
drives)
Using SCC, the SBT function can be directly controlled from a higher-level control system.
Select the brake test sequence with a 0/1 edge in S_STW3B bit 0
See also: Safety Info Channel and Safety Control Channel (SIC/SCC) (Page 205), SBT:
Communication via SIC/SCC (Page 169)
● Selection via BICO (only external drives)
BICO interconnection; here, digital signals (e.g. DIs) are used to operate the SBT function.
You cannot select SBT for integrated drives of the NCU (SINAMICS Safety Integrated, NX
modules) via BICO - but only via SCC.
Selected using 0/1 edge at DI for p10230[0]
● Selected using test stop/forced checking procedure of the Extended Functions
Automatic execution when selecting the test stop/forced checking procedure; restricted test
options; however, no additional signals are required for the control.
Selected using a 0/1 edge in the S_STW1B bit 8 (integrated drives, external drives) or at the
DI for p9705 (only external drives).
After selection, initially SBT is automatically performed, followed by the test stop/forced
checking procedure.
Note
Only brake 1 when selecting using test stop/forced checking procedure
When selecting using test stop/forced checking procedure, only the internal motor holding
brake parameterized as brake 1 is tested with test sequence 1 in the direction
parameterized in p10218.
5.14.3.5
Start of the Safe Brake Test sequence
● Make the following decisions before starting the brake test sequence:
- The brake to be tested using DI for p10230[2] or S_STW3B bit 2
- Positive or negative direction of the test torque using DI for p10230[3] or S_STW3B bit 3
- Brake test sequence 1 or 2 using DI for p10230[4] or S_STW3B bit 4.
● Start the brake test sequence using a 0/1 edge at the DI for p10230[1] or in S_STW3B bit 1.
Safety Integrated plus
166
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
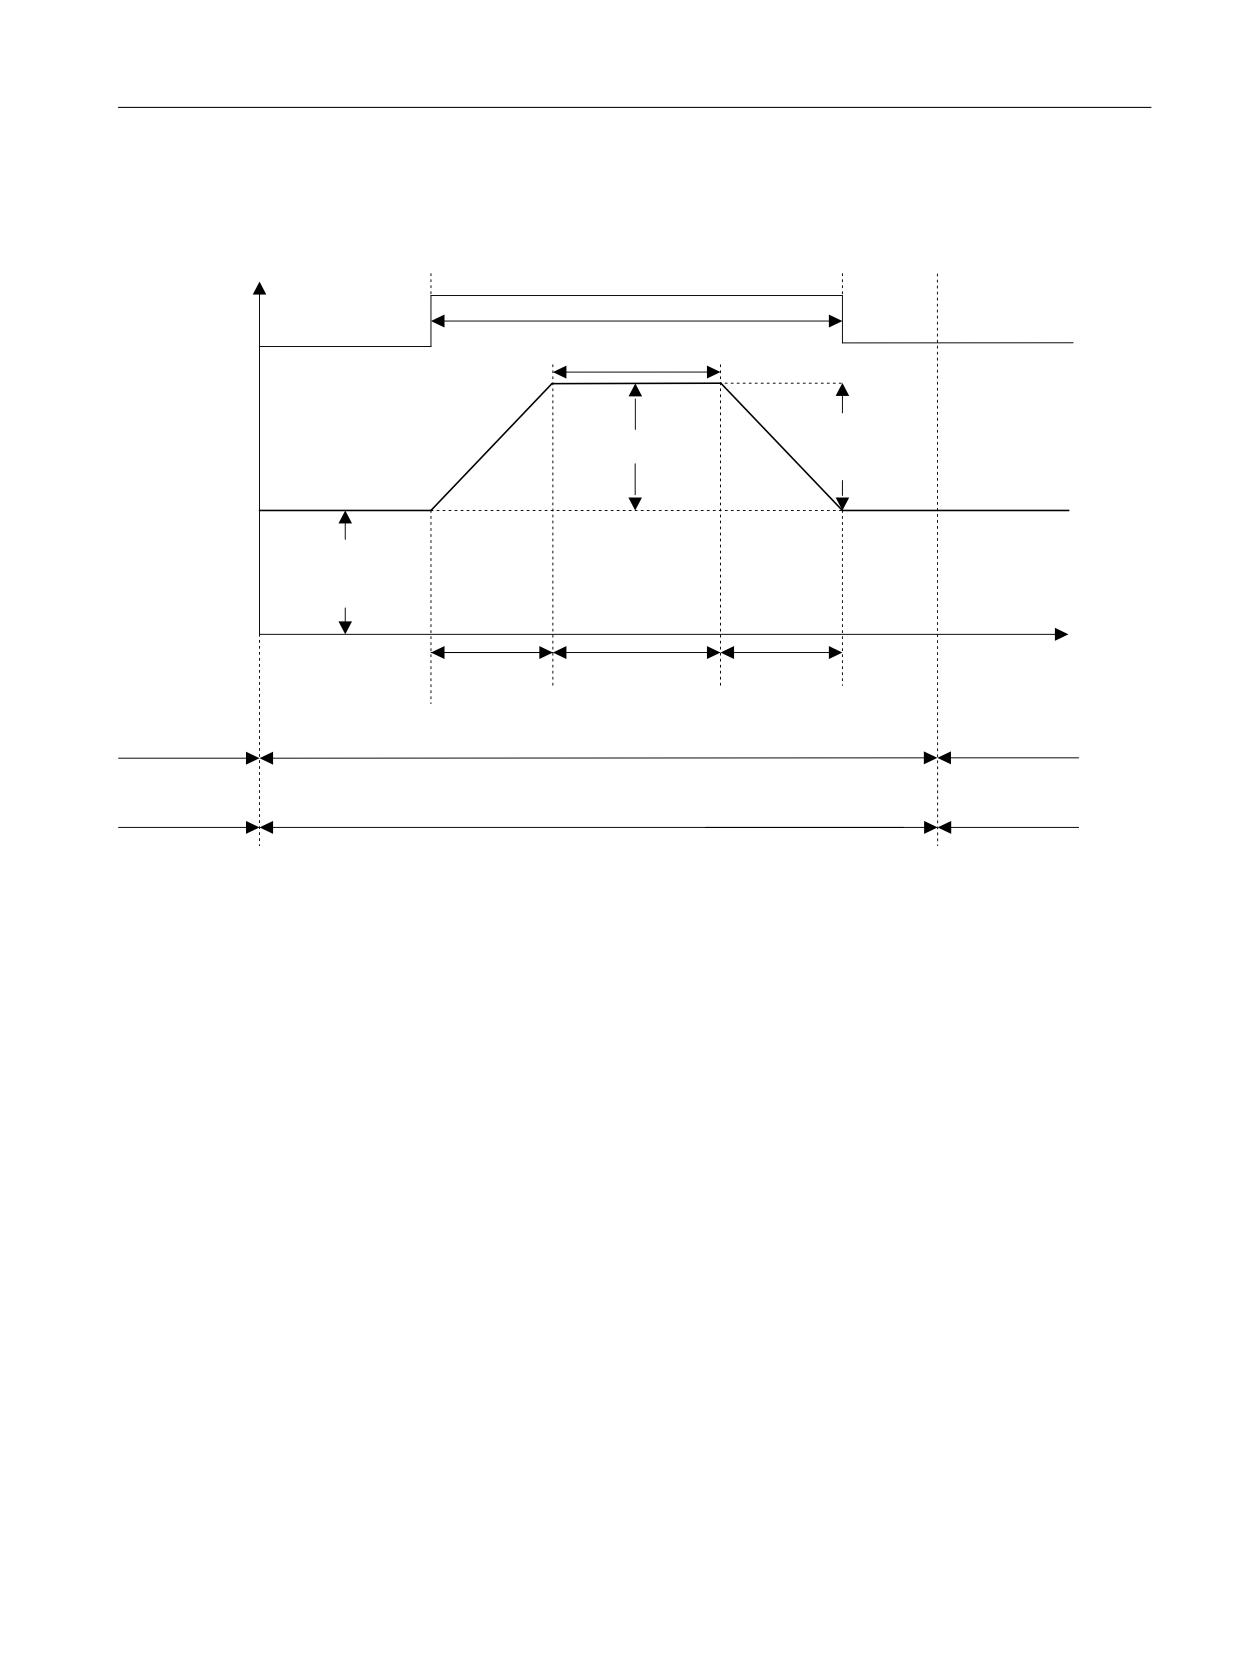
Safety functions integrated in the drive
5.14 SBT (diagnostic function)
5.14.3.6
Sequence
SBT has the following basic sequence:
0
%UDNH FORVHG
VHW
0RQLWRU SRVLWLRQ WROHUDQFH
7HVW WRUTXH
PRQLWRULQJ
'LDJQRVWLFV
%UDNH WHVW WRUTXH
PD[ WHVW
WRUTXH
0
ORDG
'LDJQRVLV
7HVW WRUTXH
6WDWLF
6LJQ
ORDG WRUTXH
VHOHFW SRVLWLYH
W
5DPS WLPH
7HVW
5DPS WLPH
GXUDWLRQ
6WDUW EUDNH WHVW
(QDEOH
(QDEOH
RSHUDWLRQ
%UDNH WHVW VHOHFWHG
RSHUDWLRQ
6HWSRLQW LQSXW
6HWSRLQW LQSXW
6HWSRLQW LQSXW GULYH
([WHUQDO
QVHW
([WHUQDO
6HOHFW EUDNH WHVW
'HVHOHFW EUDNH WHVW
Figure 5-24
SBT: Time sequence
● After the user selects the brake test (0/1 edge in r10231.0), the static hanging load is
determined. For this reason, all brakes must be open and the pulses enabled when the
brake test is selected.
- When testing a motor holding brake, which is directly controlled from SINAMICS, the
brake is automatically opened when the pulses are enabled and p1215=1.
- When testing an external brake, via p10234.6 or for SIC/SCC, via S_ZSW3B.6, a value
of 0 indicates that the external brake must be opened. This must occur within 11
seconds, otherwise the test is canceled and a fault is output.
● The brake, the test sequence and the test direction are then selected by the user.
● When the brake test is active after the start of the brake test / brake test sequence by the
user (0/1 edge in r10231.1), the holding brake (MHB) is closed or there is a prompt to close
the external brake. The request to close the brake is again indicated with p10234.6 = 1 or
S_ZSW3B.6 = 1. Also in this case, only a maximum of 11 seconds must elapse, otherwise
a fault is issued.
● The test torque (test torque ± load torque for a vertical axis) is specified during the SBT.
When n = 0 is entered, the controller builds up an appropriate test torque against the closed
brake. The test torque is built up along a ramp. The ramp is defined by the time of p10208.
● At the end of the test sequence, the brake is opened or there is a prompt to open the brake.
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
167
Safety functions integrated in the drive
5.14 SBT (diagnostic function)
● After deselection of the test sequence (test sequence is switched off), another test
sequence can be started, e.g. with a different brake in a different direction, assuming that
the brake test is still selected.
● When the test sequence is active, the brake that is not being tested must remain open.
● After deselection of the SBT, the original speed setpoint takes effect again.
5.14.3.7
Cancellation/deselection and acknowledgment (SBT)
An active brake test is cancelled through deselection of the test sequence or deselection of the
brake test. Alarm A01782 is output.
Acknowledging alarms
The alarms relevant for the brake test can only be safely acknowledged (failsafe acknowledge),
and under certain circumstances only acknowledged, when the brake test is deselected. For
"motion monitoring without selection", a POWER ON is required - or STO/SS1 must be
selected/deselected (for a configured extended alarm acknowledgment).
Safety Integrated plus
168
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
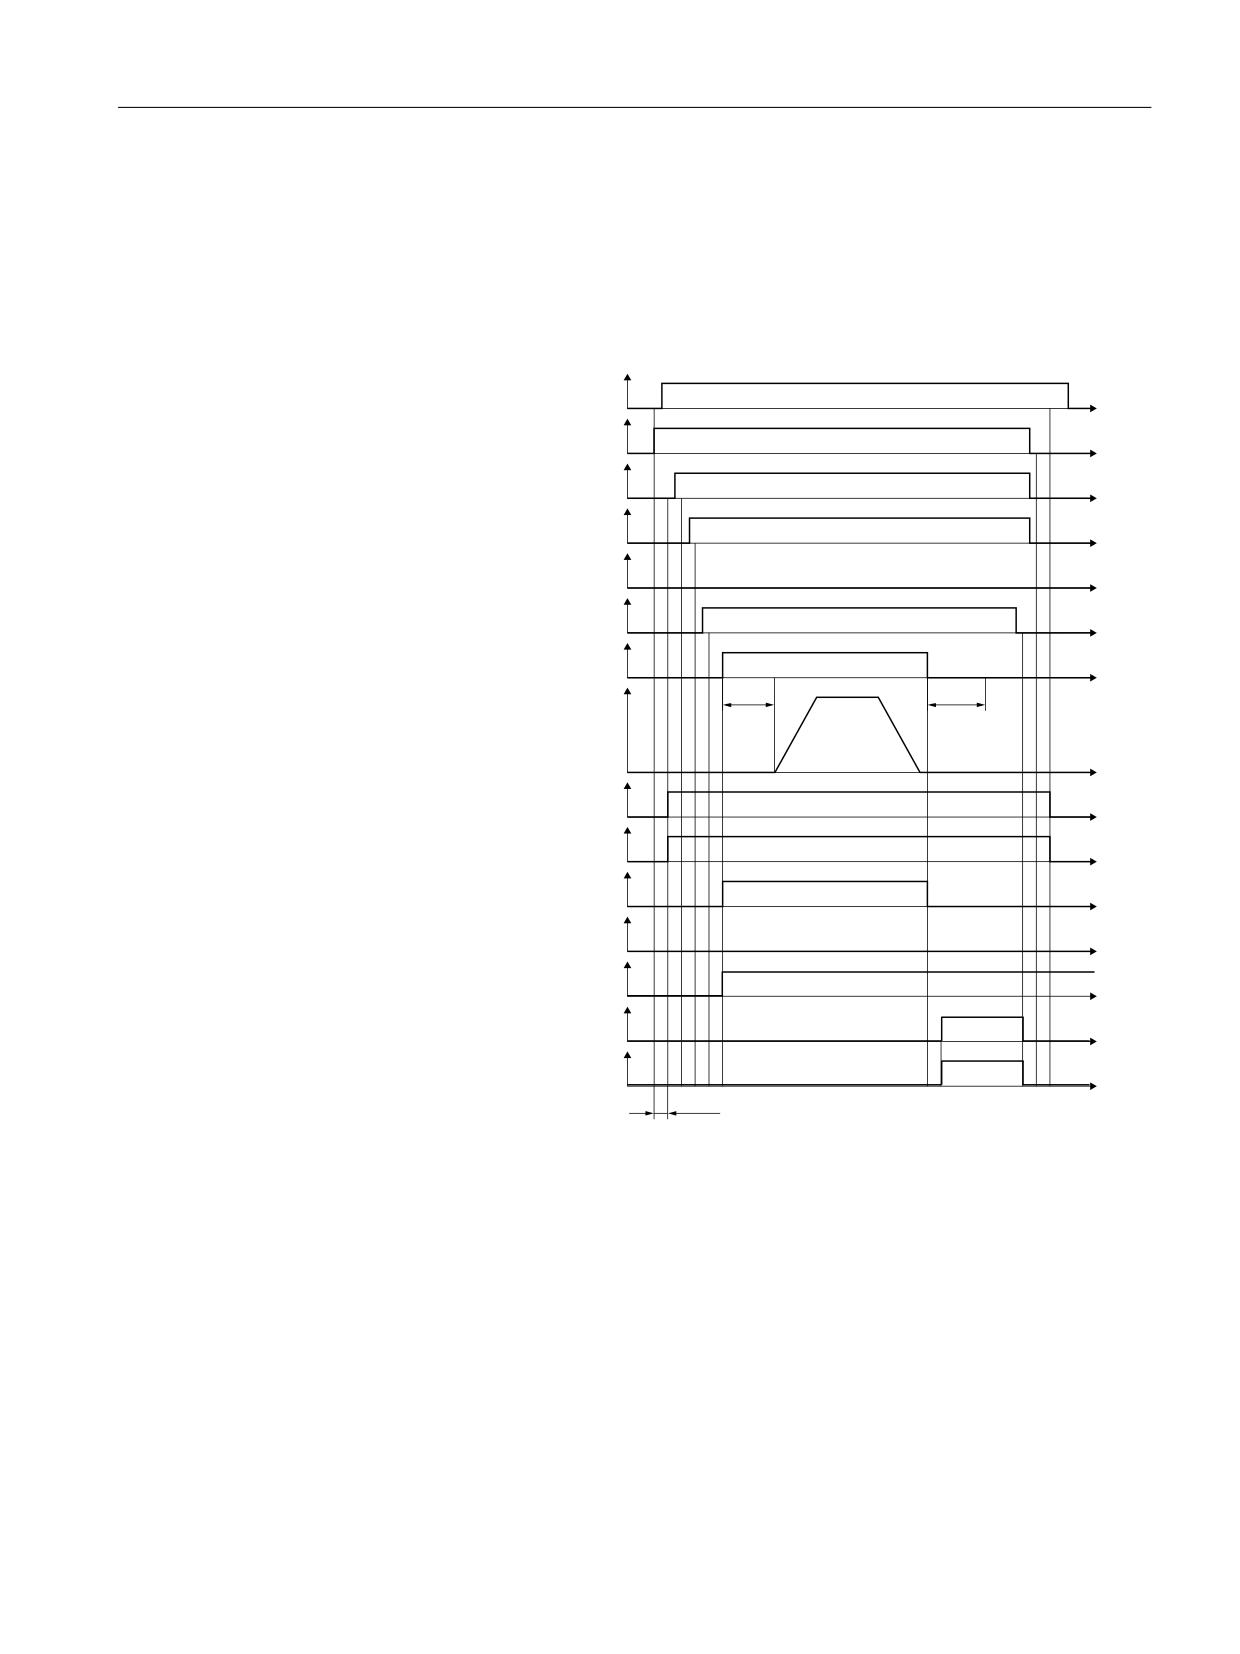
Safety functions integrated in the drive
5.14 SBT (diagnostic function)
5.14.3.8
Communication via SIC/SCC
Testing a motor holding brake
The following figure shows the communication via SIC and SCC during the test of a motor
holding brake:
21 2))
W
6HOHFW EUDNH WHVW
6B67: %
W
6HOHFW GLUHFWLRQ RI URWDWLRQ
6B67: %
W
6HOHFW WHVW VHTXHQFH
6B67: %
W
%UDNH VHOHFWLRQ
6B67: %
W
6WDUW EUDNH WHVW
6B67: %
W
&ORVH PRWRU KROGLQJ EUDNH
W
7HVW WRUTXH
S
S
W
%UDNH WHVW VHOHFWHG
6B=6: %
W
6HWSRLQW LQSXW GULYH H[WHUQDO
6B=6: %
W
%UDNH WHVW DFWLYH
6B=6: %
W
$FWLYH EUDNH
6B=6: %
W
$FWXDO ORDG VLJQ
6B=6: %
W
%UDNH WHVW UHVXOW
6B=6: %
W
%UDNH WHVW FRPSOHWHG
6B=6: %
W
S
Figure 5-25
Testing a motor holding brake
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
169
Safety functions integrated in the drive
5.14 SBT (diagnostic function)
Test of an external brake
The following figure shows the communication via SIC and SCC during the test of an external
brake:
21 2))
W
6HOHFW EUDNH WHVW
6B67: %
W
6HOHFW GLUHFWLRQ RI URWDWLRQ
6B67: %
W
6HOHFW WHVW VHTXHQFH
6B67: %
W
%UDNH VHOHFWLRQ
6B67: %
W
6WDUW EUDNH WHVW
6B67: %
W
&ORVH H[WHUQDO EUDNH
W
([WHUQDO EUDNH VWDWXV 6B67: %
W
7HVW WRUTXH
W
%UDNH WHVW VHOHFWHG
6B=6: %
W
6HWSRLQW LQSXW GULYH H[WHUQDO
6B=6: %
W
%UDNH WHVW DFWLYH
6B=6: %
W
$FWLYH EUDNH
6B=6: %
W
5HTXHVW FORVH EUDNH
6B=6: %
W
$FWXDO ORDG VLJQ
6B=6: %
W
%UDNH WHVW UHVXOW
6B=6: %
W
%UDNH WHVW FRPSOHWHG
6B=6: %
W
S
Figure 5-26
Testing an external brake
Safety Integrated plus
170
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
Safety functions integrated in the drive
5.14 SBT (diagnostic function)
5.14.3.9
Function diagrams and parameters
Function diagrams (see SINAMICS S120/S150 List Manual)
●
2836
SI Extended Functions - SBT (Safe Brake Test)
●
2837
SI Extended Functions - selection of active control word
Overview of important parameters (see SINAMICS S120/S150 List Manual)
●
p1215
Motor holding brake configuration
●
p1216
Motor holding brake opening time
●
p1217
Motor holding brake closing time
●
p9501
SI Motion enable safety functions (Control Unit)
●
p9601
SI enable functions integrated in the drive (Control Unit)
●
p9602
SI enable safe brake control (Control Unit)
●
p10201
SI Motion SBT enable
●
p10202[0...1]
SI Motion SBT brake selection
●
p10203
SI Motion SBT control selection
●
p10204
SI Motion SBT motor type
●
p10208[0...1]
SI Motion SBT test torque ramp time
●
p10209[0...1]
SI Motion SBT brake holding torque
●
p10210[0...1]
SI Motion SBT test torque factor sequence 1
●
p10211[0...1]
SI Motion SBT test duration sequence 1
●
p10212[0...1]
SI Motion SBT position tolerance sequence 1
●
p10218
SI Motion SBT test torque sign
●
p10220[0...1]
SI Motion SBT test torque factor sequence 2
●
p10221[0...1]
SI Motion SBT test duration sequence 2
●
p10222[0...1]
SI Motion SBT position tolerance sequence 2
●
p10230[0...5]
BI: SI Motion SBT control word
●
r10231
SI Motion SBT control word diagnostics
●
r10234.0...15
CO/BO: SI Safety Info Channel status word S_ZSW3B
●
p10235
CI: Safety Control Channel control word S_STW3B
●
r10240
SI Motion SBT test torque diagnostics
●
r10241
SI Motion SBT load torque diagnostics
●
p60122
IF1 PROFIdrive SIC/SCC telegram selection
Safety Integrated plus
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3
171
Safety functions integrated in the drive
5.15 SCA
5.15
SCA
Definition according to EN
s
61800-5-2:
SCA 3
The function "Safe Cam" (SCA) safe
SCA 2
supplies a safety-related output sig-
SCA 1
t
nal to indicate whether the motor
shaft position is within a defined
1
range.
0
t
The "Safe Cam" function outputs a safe signal if the drive is within a specified position range.
It facilitates the realization of safe range detection for each individual axis.
5.15.1
Details and parameterization
With the "Safe Cam" function (SCA), you implement safe electronic cams, safe zone sensing,
or a working area limitation/protection zone delimitation for a specific axis, to replace a
hardware-based solution. You parameterize up to 30 output cams for each axis. You enable
each output cam individually.
Note
The "Safe Cam" (SCA) safety function can only be used with an encoder.
Safety Integrated plus
172
Commissioning Manual, 12/2019, 6FC5397-1FP40-6BA3