SINUMERIK 840D sl. Service - Configuring Commissioning. Manual (2011-2020) - page 102
List of system variables
3.24 Axial system variables
$AA_TOFF_LIMIT [31]
Limit value for offset in TCS reached
INT
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_TOFF_PREP_DIFF [31]
Difference value of main run/preprocessing run in TCS
DOUBLE
Description:
Variable $AA_TOFF_PREP_DIFF[geo axis] determines the difference value of the overlaid movement in the corresponding tool direction be-
tween the main run and preprocessing run.
The variable is only appropriate in conjunction with an active orientation transformation or an active toolholder.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
mm
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_SOFTENDP [31]
Software limit position, positive direction
DOUBLE
Description:
$AA_SOFTENDP[X]
Current software limit position, positive direction
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_SOFTENDN [31]
Software limit position, negative direction
DOUBLE
Description:
$AA_SOFTENDN[X]
Software limit position, negative direction
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
679
List of system variables
3.24 Axial system variables
$AA_SOFTENDN [31]
Software limit position, negative direction
DOUBLE
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_DTBW [31]
Distance from block start in WCS
DOUBLE
Description:
Axial variable $AA_DTBW[ax] determines the axial distance from the start of the block in the workpiece coordinate system for positioning and
synchronized axes. The programmed position is the only factor used to calculate the distance. If the axis is a coupled axis, the position
component derived from the axis coupling is not considered.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_DTBB [31]
Distance from block start in BCS
DOUBLE
Description:
Axial variable $AA_DTBB[ax] determines the axial distance from the start of the block in the basic coordinate system for positioning and
synchronized axes. The programmed position is the only factor used to calculate the distance. If the axis is a coupled axis, the position
component derived from the axis coupling is not considered.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_DTEW [31]
Distance from block end in WCS
DOUBLE
Description:
Axial variable $AA_DTEW[ax] determines the axial distance to the end of the block in the workpiece coordinate system for positioning and
synchronized axes. The programmed position is the only factor used to calculate the distance. If the axis is a coupled axis, the position
component derived from the axis coupling is not considered.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
System variables
680
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_DTEW [31]
Distance from block end in WCS
DOUBLE
Read:
-
X
0
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_DTEB [31]
Distance from block end in BCS
DOUBLE
Description:
Axial variable $AA_DTEB[ax] determines the axial distance to the end of the block in the basic coordinate system for positioning and synchron-
ized axes.
The programmed position is the only factor used to calculate the distance. If the axis is a coupled axis, the position component derived from
the axis coupling is not considered.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_DTEPW [31]
Distance to go of a reciprocating axis in WCS
DOUBLE
Description:
Axial variable $AA_DTEPW[ax] determines the axial distance to go for the infeed reciprocation in the workpiece coordinate system.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_DTEPB [31]
Distance to go of a reciprocating axis in BCS
DOUBLE
Description:
Axial variable $AA_DTEPB[ax] determines the axial distance to go for the infeed reciprocation in the basic coordinate system.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
X
7
X
Write:
-
-
0
-
0
-
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
681
List of system variables
3.24 Axial system variables
$AA_DTEPB [31]
Distance to go of a reciprocating axis in BCS
DOUBLE
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_OSCILL_REVERSE_POS1 [31]
Reciprocation reversal position 1
DOUBLE
Description:
$AA_OSCILL_REVERSE_POS1[X]
Supplies current reversal position 1 for reciprocation.
In synchronized actions, the value of setting data $SA_OSCILL_REVERSE_POS1
is evaluated online.
The variable can be accessed only from synchronized actions.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_OSCILL_REVERSE_POS2 [31]
Reciprocation reversal position 2
DOUBLE
Description:
$AA_OSCILL_REVERSE_POS2[X]
Supplies current reversal position 2 for reciprocation.
In synchronized actions, the value of setting data $SA_OSCILL_REVERSE_POS2
is evaluated online.
The variable can be accessed only from synchronized actions.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_DELT [31]
Stored axial distance to go after deletion of distance-to-
DOUBLE
go
Description:
$AA_DELT[X]
Stored axial distance to go in workpiece coordinate system after axial delete distance to go by a motion-synchronous action.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
System variables
682
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_DELT [31]
Stored axial distance to go after deletion of distance-to-
DOUBLE
go
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$P_FA [31]
Programmed axial feedrate
DOUBLE
Description:
$P_FA[X]
Last programmed axial feedrate
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular speed
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_OVR [31]
Axial override
DOUBLE
Description:
$AA_OVR[<axis>]
Axial override for motion-synchronous actions.
Multiplicative override component, applied in addition to operator override,
programmed override and transformational override.
The value is limited to max. 200%. If a value of < 0.0 is entered,
it is assumed to be 0 and alarm 14756 is output.
$AA_OVR[<axis>] must be rewritten in every Ipo cycle or else a value of 100% is applied.
Variable $AA_OVR[<spindle>] alters the spindle override.
The variable can be accessed only from motion-synchronous actions.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
X
7
X
Write:
-
X
0
-
0
X
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
683
List of system variables
3.24 Axial system variables
$AA_PLC_OVR [31]
Axial override from PLC
DOUBLE
Description:
$AA_PLC_OVR[ax] supplies the axial override defined by the PLC.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
CHAN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_TOTAL_OVR [31]
Overall axial override
DOUBLE
Description:
$AA_TOTAL_OVR[ax] supplies the overall axial override (PLC_OVR*NC_OVR).
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
CHAN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_VC [31]
Additive axial feedrate override
DOUBLE
Description:
$AA_VC[X]
Additive axial feedrate override for motion-synchronous actions.
The override value must be rewritten in every Ipo cycle or else a value of 0 is applied.
A setting of 0 makes the override inoperative and is not applied to the override value.
The total feedrate cannot be made negative by an override value.
An upper limit is applied to ensure that the maximum axis velocities and acceleration rates cannot be exceeded.
The calculation of other feed components is not affected by $AA_VC.
The override values defined by machine data: $MN_OVR_FACTOR_LIMIT_BIN, $MN_OVR_FACTOR_FEEDRATE[30],
$MN_OVR_FACTOR_AX_SPEED[30] and $MN_OVR_FACTOR_SPIND_SPEED cannot
be exceeded. The additive feedrate override is limited such that the resultant feedrate does not exceed the maximum override
value of the programmed feedrate.
The variable can be accessed only from synchronized actions.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular speed
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
System variables
684
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_VC [31]
Additive axial feedrate override
DOUBLE
Read:
-
X
0
X
7
X
Write:
-
X
0
-
0
X
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_VACTB [31]
Axis velocity in the BCS
DOUBLE
Description:
Axial variable $AA_VACTB[ax] determines the axis velocity in the basic coordinate system.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular speed
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_VACTW [31]
Axis velocity in the WCS
DOUBLE
Description:
Axial variable $AA_VACTW[ax] determines the axis velocity in the workpiece coordinate system.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular speed
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_VACTM [31]
Axis velocity in the MCS
DOUBLE
Description:
Axial variable $AA_VACTM[ax] determines the axis velocity on the setpoint side in the machine coordinate system. The variable also returns
valid values for replacement and PLC axes.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular speed
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
685
List of system variables
3.24 Axial system variables
$VA_VACTM [31]
Axis velocity actual value in the MCS
DOUBLE
Description:
Axial variable $VA_VACTM[ax] determines the axis velocity actual value in the machine coordinate system. The variable supplies an undefined
value if the encoder limit frequency is exceeded. When a spindle/axis disable is active, this variable returns the current velocity setpoint. If it
is preferred to return the actual velocity in this situation, BIT3 in $MA_MISC_FUNCTION_MASK must be set.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular speed
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_LOAD [31]
Drive load
DOUBLE
Description:
$AA_LOAD[X]
Drive utilization in %
Only available for PROFIdrive drives.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0.0
-100
100
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Current value
Link:
Not classified
$VA_LOAD [31]
Drive load
DOUBLE
Description:
$VA_LOAD[X]
Drive utilization in %
Only available for PROFIdrive drives.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0.0
-100
100
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Current value
Link:
Not classified
System variables
686
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_TORQUE [31]
Drive torque setpoint
DOUBLE
Description:
$AA_TORQUE[X]
Drive torque setpoint in Nm
or actual force in N
Available only for PROFIdrive drives.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Current value
Link:
Not classified
$VA_TORQUE [31]
Drive torque setpoint
DOUBLE
Description:
$VA_TORQUE[X]
Drive torque setpoint in Nm
or actual force in N
Available only for PROFIdrive drives.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
-
0
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Current value
Link:
Not classified
$AA_POWER [31]
Drive active power
DOUBLE
Description:
$AA_POWER[x]
Drive active power in W
Available only for PROFIdrive drives.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
687
List of system variables
3.24 Axial system variables
$AA_POWER [31]
Drive active power
DOUBLE
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Current value
Link:
Not classified
$VA_POWER [31]
Drive active power
DOUBLE
Description:
$VA_POWER[x]
Drive active power in W
Available only for PROFIdrive drives.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Current value
Link:
Not classified
$AA_CURR [31]
Drive actual current
DOUBLE
Description:
$AA_CURR[X]
Actual current of axis or spindle in A
Available only for PROFIdrive drives.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Current value
Link:
Not classified
$VA_CURR [31]
Drive actual current
DOUBLE
Description:
$VA_CURR[X]
Actual current of axis or spindle in A
Available only for PROFIdrive drives.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
-
System variables
688
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$VA_CURR [31]
Drive actual current
DOUBLE
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Current value
Link:
Not classified
$VA_DIST_TORQUE [31]
Disturbing torque
DOUBLE
Description:
$VA_DIST_TORQUE[X]
Normalized disturbing torque (disturbing torque/max. motor torque) = output signal of disturbance monitor in the drive - only available on
PROFIdrive drives with telegram 203
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0.0
-100
100
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Current value
Link:
Not classified
$VA_VALVELIFT [31]
Hydraulic valve lift
DOUBLE
Description:
$VA_VALVELIFT[X]
Actual valve lift in mm (for hydraulic module only)
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
-
0
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Current value
Link:
Not classified
$VA_PRESSURE_A [31]
Pressure at the A end of the hydraulic cylinder
DOUBLE
Description:
$VA_PRESSURE_A[X]
Pressure at A end of cylinder in bar (for hydraulic module only)
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
689
List of system variables
3.24 Axial system variables
$VA_PRESSURE_A [31]
Pressure at the A end of the hydraulic cylinder
DOUBLE
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Current value
Link:
Not classified
$VA_PRESSURE_B [31]
Pressure at the B end of the hydraulic cylinder
DOUBLE
Description:
$VA_PRESSURE_B[X]
Pressure at B end of cylinder in bar (for hydraulic module only)
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
-
0
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Current value
Link:
Not classified
$VA_DP_ACT_TEL [20,31]
PROFIBUS/PROFINET actual telegram from drive to NC
INT
Description:
$VA_DP_ACT_TEL[b,a]
b: Word index (16-bit access) in the PROFIBUS/PROFINET telegram
a: Machine axis
Actual value telegram contents - only available for PROFIBUS/PROFINET.
For details, please see telegram configuration in PROFIdrive or drive documentation
Index 1:
b: Word index in the PROFIBUS/PROFINET actual value frame
Index 2:
Maximum axis number
Unit
Init value
Min
Max
-
0
-2147483648
65535
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
690
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_STAT [31]
Axis status
INT
Description:
The axial variable $AA_STAT[<axis>] determines the axis status. The status "Exact stop fine" is derived from the servo status. See also $AA_IN-
POS_STAT[<axis>]. The following values are possible:
0: No axis status available
1: Traversing movement pending
2: Axis has reached IPO end
3: Axis in position (exact stop coarse)
4: Axis in position (exact stop fine)
Note:
With a position default setting for an axis / spindle, the variable can still indicate the statuses 'Exact stop coarse / fine' during block change
although the axis / spindle is starting to traverse.
Remedy: Also query $AC_TIMEC.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
4
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_SNGLAX_STAT [31]
Status of single axis
INT
Description:
$AA_SNGLAX_STAT[X]
Axis status:
0: Axis is not a single axis
1: Single axis in Reset
2: Single axis has ended
3: Single axis is interrupted
4: Single axis is active
5: Single axis alarm is active
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
4
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
691
List of system variables
3.24 Axial system variables
$AA_REF [31]
Axis is homed
INT
Description:
$AA_REF[X]
Axis status:
0: Axis is not homed
1: Axis is homed
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
1
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_TYP [31]
Axis type
INT
Description:
$AA_TYP[<axis>]
Axis type:
0: Axis in another channel
1: Program axis of own channel
2: Neutral axis
3: PLC axis
4: Oscillating axis
5: Neutral axis which is currently executing a JOG or homing motion
6: Following axis coupled via master value
7: Coupled motion following axis
8: Command axis
9: CompileCycles axis
10: Coupled slave axis (master-slave function)
11: Program axis which is currently executing a JOG or homing motion
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
11
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
692
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_MASL_STAT [31]
Master-slave coupling status
INT
Description:
The current status of a master-slave coupling.
Val. 0: Axis is not a slave axis or no coupling is active.
Value> 0: Coupling is active, the relevant machine axis number of the
master axis is supplied.
$AA_MASL_STAT[X]
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
-2147483648
2147483647
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$P_SEARCH_MASLC [31]
Master-slave coupling status changed
INT
Description:
$P_SEARCH_MASLC[axis identifier]
The current status of a master-slave coupling has been changed
during a block search.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
1
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$P_SEARCH_MASLD [31]
Master-slave position offset
DOUBLE
Description:
$P_SEARCH_MASLD[axis identifier]
Positional offset between master and slave axes calculated
during block search as coupling was closed.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
693
List of system variables
3.24 Axial system variables
$P_SEARCH_MASLD [31]
Master-slave position offset
DOUBLE
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_FXS [31]
Status Desired state of "Travel to fixed stop"
INT
Description:
$AA_FXS[X]
Status desired state "Travel to fixed stop"
0: Axis not at limit stop
1: Fixed stop has been successfully approached
2: Approach to fixed stop has failed
3: Selection of travel to fixed stop active
4: Fixed stop has been detected
5: Deselection of travel to fixed stop active
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
5
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
runin stp
X
7
X
7
X
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Program sensitive
Link:
Not classified
$VA_FXS [31]
Actual status of "Travel to fixed stop"
INT
Description:
$VA_FXS[X]
Status actual state "Travel to fixed stop"
0: Axis not at limit stop
1: Fixed stop has been successfully approached
2: Approach to fixed stop has failed
3: Selection of travel to fixed stop active
4: Fixed stop has been detected
5: Deselection of travel to fixed stop active
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
5
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Current value
Link:
Not classified
System variables
694
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$VA_FXS_INFO [31]
Additional information with "Travel to fixed stop"
INT
Description:
$VA_FXS_INFO[X]
Additional information with "Travel to fixed stop" if $VA_FXS[]=2
0: No additional information available
1: No approach movement programmed
2: Programmed end position reached, motion completed
3: Abort by NC RESET (key reset)
4: Axis has exited fixed stop window
5: Torque reduction rejected by drive
6: PLC has cancelled enables
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
6
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$VA_TORQUE_AT_LIMIT [31]
Status "Torque limit reached"
INT
Description:
$VA_TORQUE_AT_LIMIT[X]
"Torque limit reached" status
0: Torque limit not yet reached
1: Torque limit reached
In digital systems, the drive returns a status signal indicating whether the programmed torque limit has been reached.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
1
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
695
List of system variables
3.24 Axial system variables
$AA_FOC [31]
Status Desired state of "ForceControl"
INT
Description:
$AA_FOC[X]
Status desired state "ForceControl"
0: ForceControl not active
1: ForceControl active modally
2: ForceControl active non-modally
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
2
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
runin stp
X
7
X
7
X
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$VA_FOC [31]
Actual status of "ForceControl"
INT
Description:
$VA_FOC[X]
Status actual state "ForceControl"
0: ForceControl not active
1: ForceControl active modally
2: ForceControl active non-modally
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
2
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
696
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_COUP_ACT [31]
Coupling type of a following axis/spindle
INT
Description:
$AA_COUP_ACT[C]
C: following axis C or S2: following spindle 2
It is possible to determine whether an axis / spindle is being used by a coupling. The coupling type is returned when the coupling is active. The
system variable must be read out for the following axis / spindle.
Values:
0: Axis / spindle is not coupled with a leading spindle / leading axis
1,2,3: Axis is tangentially tracked (TANG)
4: Synchronous spindle coupling (COUP)
8: Axis is in coupled-motion (TRAIL)
16: Following axis in master value coupling (LEAD)
32: Following axis for electronic gear (ELG)
64: Axis is active in a gantry grouping
128,256,384: Axis is tangentially tracked (TANG with optimization)
512: Following axis of the generic coupling (CP)
If the axis / spindle is a following axis / spindle in several couplings, the sum is returned as the value.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
-2147483648
2147483647
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_EG_SYNFA [31]
Synchronization of the slave axis
DOUBLE
Description:
$AA_EG_SYNFA[a]
a: Following axis
Synchronous position of following axis
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
697
List of system variables
3.24 Axial system variables
$P_EG_BC [31]
Block change criterion with active coupling
STRING
Description:
$P_EG_BC[a]
Block change criterion for EGONSYN, EGON, WAITC.
Index 1:
Maximum axis number
Index 3:
Max. string length
Unit
Init value
Min
Max
-
""
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_EG_NUM_LA [31]
Number of defined master axes
INT
Description:
$AA_EG_NUM_LA[a]
a: Following axis
Number of leading axes specified with EGDEF
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
-2147483648
2147483647
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$VA_EG_SYNCDIFF [31]
Synchronism difference
DOUBLE
Description:
$VA_EG_SYNCDIFF[a]
a: Following axis
Synchronism deviation
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
698
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$VA_EG_SYNCDIFF_S [31]
Synchronous run difference with sign
DOUBLE
Description:
$VA_EG_SYNCDIFF_S[a]
a: Following axis
Signed synchronism deviation
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_EG_AX [31,31]
Leading axis identifier
AXIS
Description:
$AA_EG_AX[n,ax]
An axis identifier of the nth active leading axis/spindle (counting starts at 0) is returned for the following axis/spindle ax.
If the leading axis is a geometry axis, the geometry axis identifier is returned, otherwise the channel axis identifier.
NO_AXIS is returned in the following cases:
- The stated coupling is not active
- n >= $AA_EG_NUM_LA[ax] (= number of active leading axes of the following axis)
Index 1:
n: Index for leading axis (nth leading axis)
Index 2:
Maximum axis number
Unit
Init value
Min
Max
-
NOAXISNUM
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_LEAD_SP [31]
Simulated lead value - position
DOUBLE
Description:
$AA_LEAD_SP[LW]
Simulated master value position
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
runin stp
X
7
-
0
X
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
699
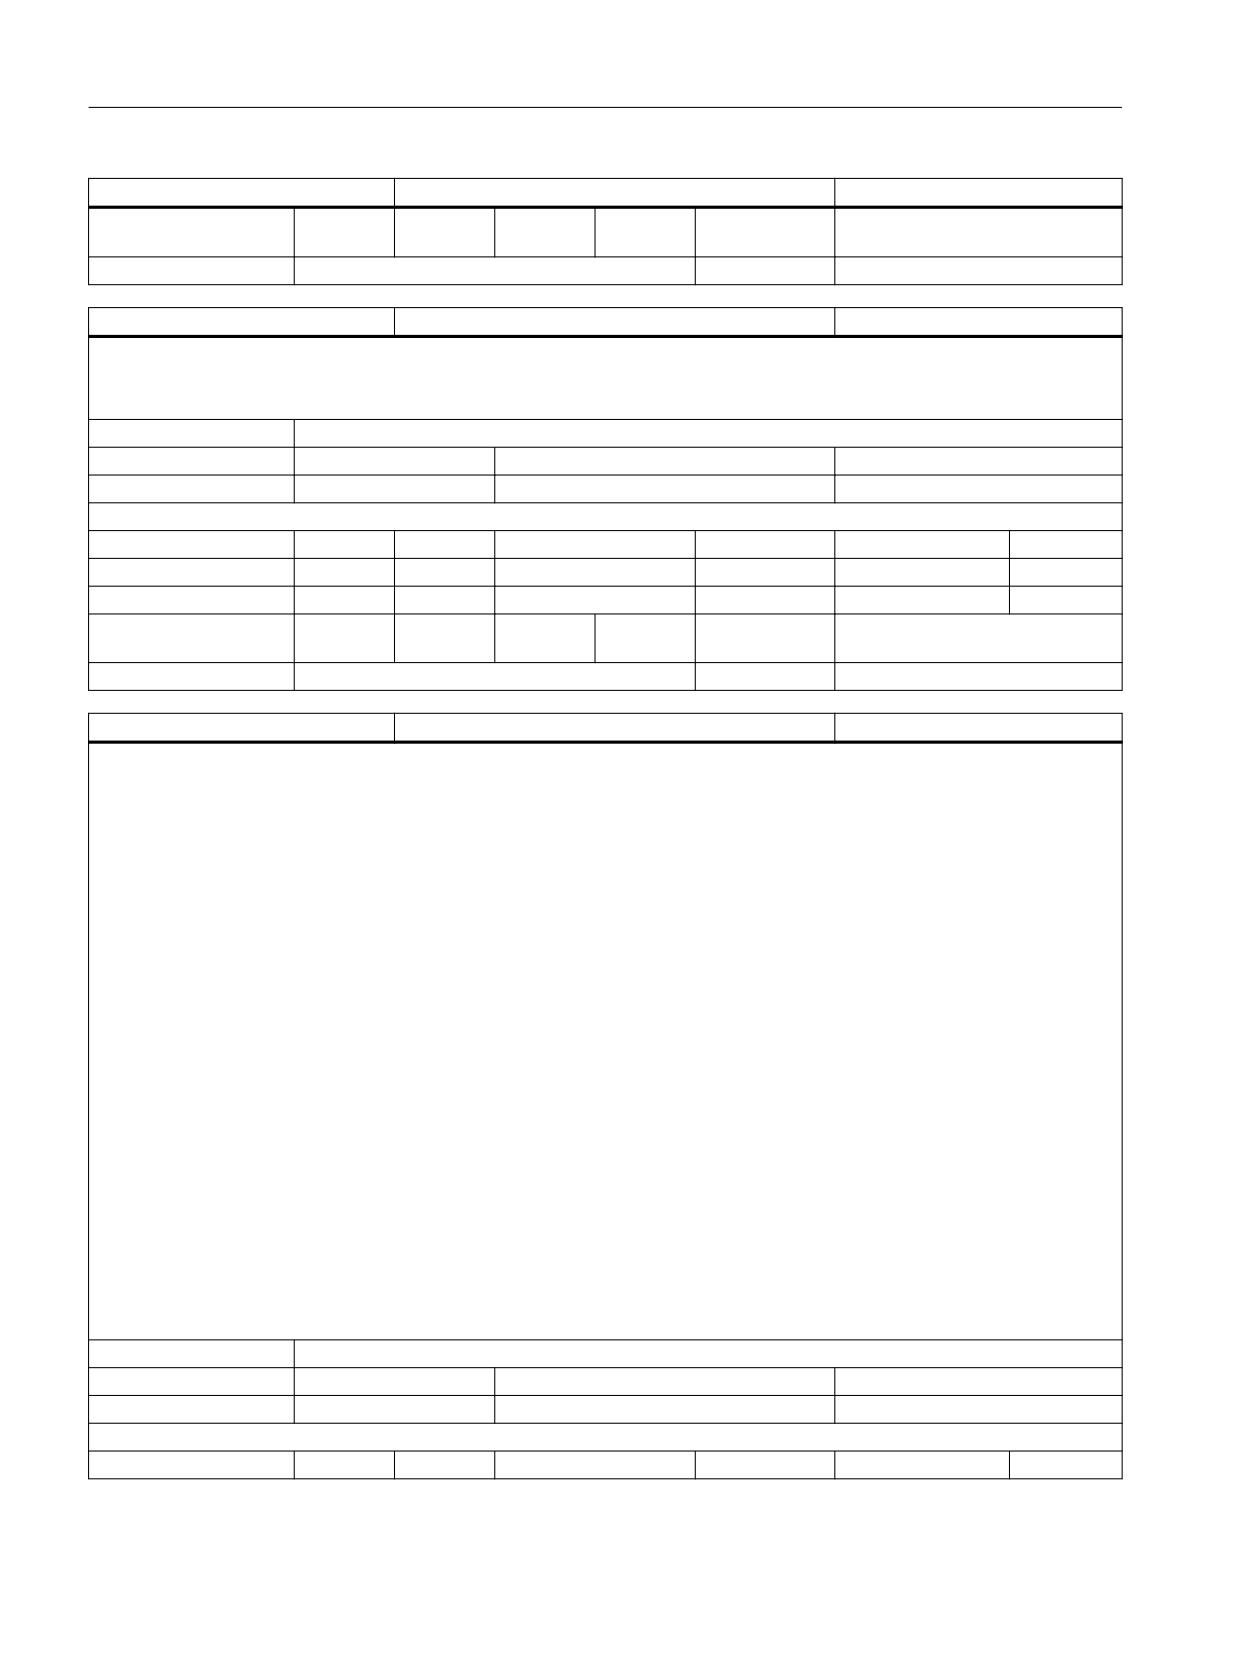
List of system variables
3.24 Axial system variables
$AA_LEAD_SP [31]
Simulated lead value - position
DOUBLE
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_LEAD_SV [31]
Simulated lead value - velocity
DOUBLE
Description:
$AA_LEAD_SV[LW]
Simulated master value velocity
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular speed
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
runin stp
X
7
-
0
X
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_LEAD_P_TURN [31]
Modulo compensation of the lead value
DOUBLE
Description:
$AA_LEAD_P_TURN[LW]
Current master value positional component
lost as a result of modulo reduction.
The actual master value position
(used internally by the control)
is $AA_LEAD_P[LW] + $AA_LEAD_P_TURN[LW]
If LW is a modulo axis, $AA_LEAD_P_TURN is an
integral multiple of $MA_MODULO_RANGE.
If LW is not a modulo axis, $AA_LEAD_P_TURN is always 0.
Example_1:
$MA_MODULO_RANGE[LW]=360
$AA_LEAD_P[LW]
=290
$AA_LEAD_P_TURN[LW] =720
The actual master value position
(used internally by the control) is 1010.
Example_2:
$MA_MODULO_RANGE[LW]=360
$AA_LEAD_P[LW]
=290
$AA_LEAD_P_TURN[LW] =-360
The actual master value position
(used internally by the control) is -70.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
System variables
700
List Manual, 10/2020, 6FC5397-6AP40-6BA4
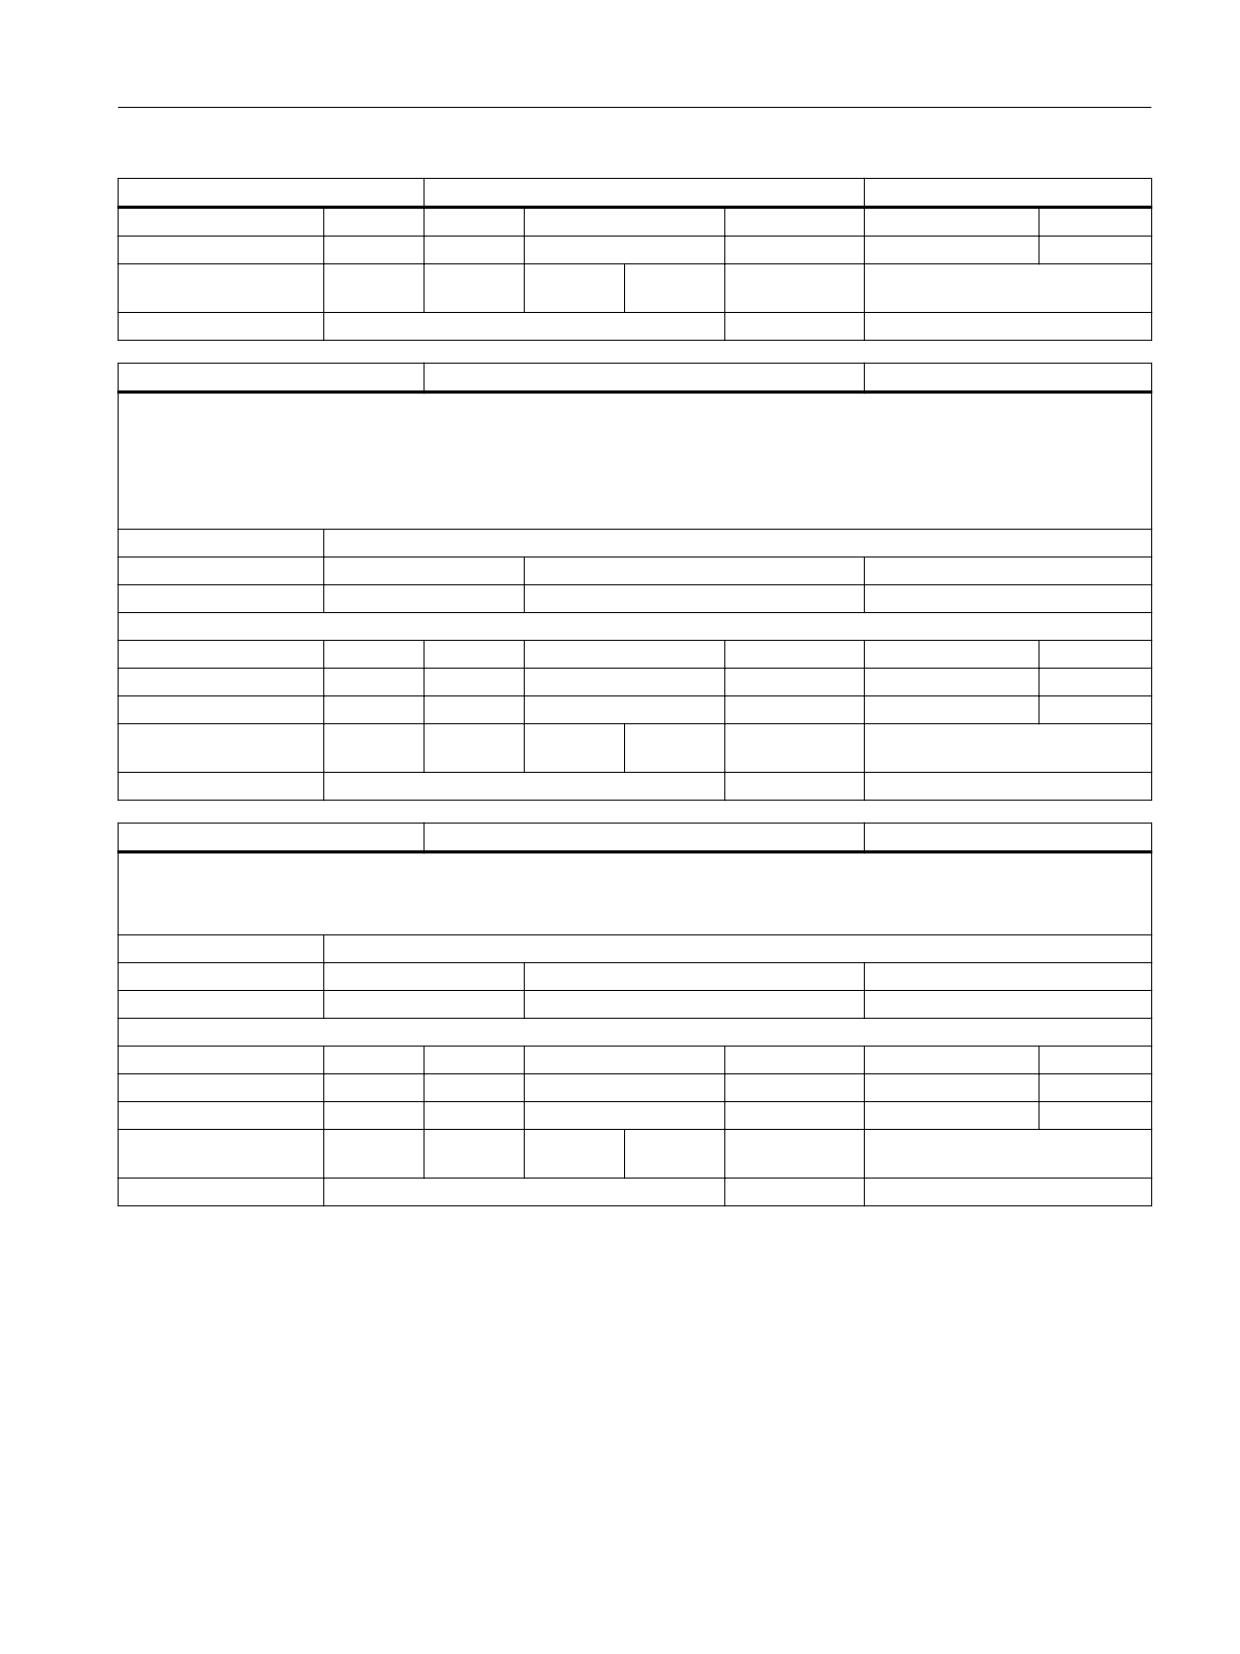
List of system variables
3.24 Axial system variables
$AA_LEAD_P_TURN [31]
Modulo compensation of the lead value
DOUBLE
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_LEAD_P [31]
Current lead value position
DOUBLE
Description:
$AA_LEAD_P[LW]
Current master value position (modulo-reduced)
If LW is a modulo axis, the following always applies:
0 <= $AA_LEAD_P[LW] <= $MA_MODULO_RANGE[LW]
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_LEAD_V [31]
Current lead value - velocity
DOUBLE
Description:
$AA_LEAD_V[LW]
Current master value velocity
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular speed
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
701
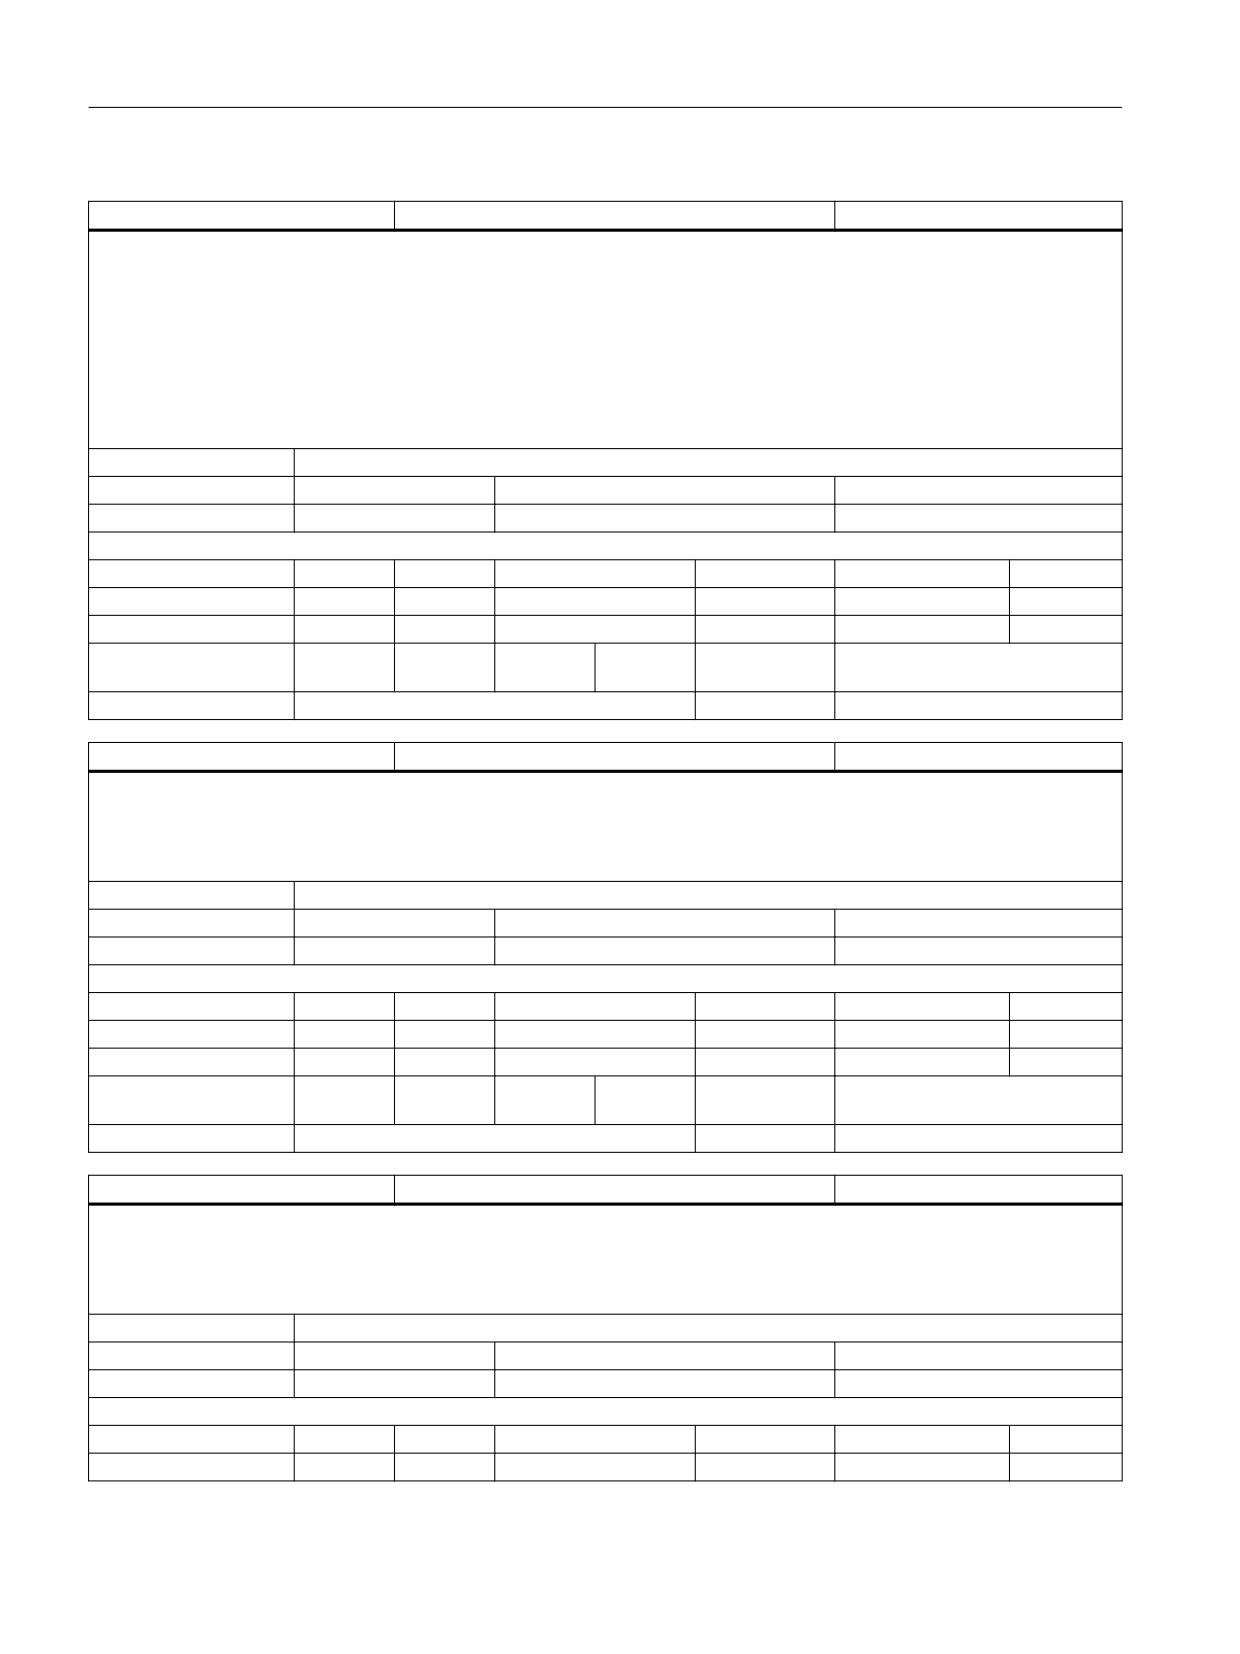
List of system variables
3.24 Axial system variables
$AA_SYNC [31]
Coupling status of the following axis
INT
Description:
$AA_SYNC[FA]
Coupling status of following axis
The actual-value synchronism difference is analyzed to determine the coupling status. See also $VA_SYNCDIFF
0 => No synchronism
1 => Coarse synchronism
2 => Fine synchronism
3 => Coarse and fine synchronism
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
3
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_IN_SYNC [31]
Synchronization status of the following axis
INT
Description:
$AA_IN_SYNC[FA]
Synchronization status of the following axis with master value coupling, ELG and generic coupling
1 => Synchronization in progress, i.e. following axis is being synchronized
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
1
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$P_COUP_OFFS [31]
Programmed position offset
DOUBLE
Description:
$P_COUP_OFFS[S2]
S2: spindle 2 or C: axis C
Programmed position offset from synchronous spindle (following spindle) to leading spindle
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
System variables
702
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$P_COUP_OFFS [31]
Programmed position offset
DOUBLE
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_COUP_OFFS [31]
Position offset on setpoint side
DOUBLE
Description:
$AA_COUP_OFFS[S2]
S2: spindle 2 or C: axis C
Position offset from synchronous spindle (following spindle) to leading spindle on setpoint side
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$VA_COUP_OFFS [31]
Position offset on actual value side
DOUBLE
Description:
$VA_COUP_OFFS[S2]
S2: spindle 2 or C: axis C
Position offset from synchronous spindle (following spindle) to leading spindle on actual value side
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$VA_DPE [31]
Power enable for machine axis
BOOL
Description:
$VA_DPE[X1]
Status of power enable for a machine axis (status of the axial pulse enable).
For PROFIdrive drives with a telegram type greater than 100: The status comes directly from the drive (message word, bit5)
For other PROFIdrive drives: The status is modeled from further drive status signals (identical to $VA_SCE, see there)
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
FALSE
FALSE
TRUE
Read/Write properties:
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
703
List of system variables
3.24 Axial system variables
$VA_DPE [31]
Power enable for machine axis
BOOL
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_ACC [31]
Current axial acceleration value
DOUBLE
Description:
$AA_ACC
Current acceleration value of axis with single-axis interpolation.
$AA_ACC = $MA_MAX_AX_ACCEL * progr. acceleration override.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular accelera-
0.0
-1.8E+308
1.8E+308
tion
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_ACC_PERCENT [31]
Current acceleration value percentage
INT
Description:
Variable $AA_ACC_PERCENT supplies the current acceleration value of the axis for single-axis interpolation in percent.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
-2147483648
2147483647
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$PA_ACCLIMA [31]
Acceleration correction in the run-in
INT
Description:
$PA_ACCLIMA
Acceleration override set with ACCLIMA in preprocessing run
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
1
200
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
System variables
704
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$PA_ACCLIMA [31]
Acceleration correction in the run-in
INT
Read:
X
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$PA_VELOLIMA [31]
Velocity correction in the run-in
INT
Description:
$PA_VELOLIMA
Velocity override set with VELOLIMA in preprocessing run
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
1
200
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$PA_JERKLIMA [31]
Jerk correction in the run-in
INT
Description:
$PA_JERKLIMA
Jerk override set with JERKLIMA in preprocessing run
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
1
200
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_ACCLIMA [31]
Acceleration compensation
INT
Description:
$AA_ACCLIMA
Acceleration override set with ACCLIMA in main run
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
1
200
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
705
List of system variables
3.24 Axial system variables
$AA_ACCLIMA [31]
Acceleration compensation
INT
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_VELOLIMA [31]
Velocity correction
INT
Description:
$AA_VELOLIMA
Velocity override set with VELOLIMA in main run
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
1
200
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_JERKLIMA [31]
Jerk override
INT
Description:
$AA_JERKLIMA
Jerk override set with JERKLIMA in main run
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
1
200
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_MOTEND [31]
Current axial end of motion criterion
INT
Description:
$AA_MOTEND
Current end of motion criterion with single-axis interpolation
1 = End of motion with exact stop FINE
2 = End of motion with exact stop COARSE
3 = End of motion at end of interpolation
4 = Block change in braking ramp of axis motion
5 = Block change in braking ramp of axis motion with tolerance window for setpoint
6 = Block change in braking ramp of axis motion with tolerance window for actual value
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
1
6
System variables
706
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_MOTEND [31]
Current axial end of motion criterion
INT
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_SCPAR [31]
Setpoint parameter set
INT
Description:
$AA_SCPAR
Current setpoint parameter set
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
-2147483648
2147483647
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_ESR_STAT [31]
ESR status of an axis
INT
Description:
$AA_ESR_STAT[X]
Status of "Extended stop and retract", bit-coded:
BIT0: Generator mode is activated
BIT1: Retraction is activated
BIT2: Extended stop is activated
BIT3: DC-link undervoltage
BIT4: Generator minimum speed
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
15
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
707
List of system variables
3.24 Axial system variables
$AA_ESR_ENABLE [31]
ESR enable
BOOL
Description:
$AA_ESR_ENABLE[X] = 1
Enabling of "Extended stop and retract"
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
FALSE
FALSE
TRUE
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
runin stp
X
7
-
0
X
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_ESR_TRIGGER [31]
Triggers a single-axis ESR
BOOL
Description:
$AA_ESR_TRIGGER[X] = 1
Activation of "NC-controlled ESR" for PLC-controlled axis (= single axis)
X: PLC-controlled axis
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
FALSE
FALSE
TRUE
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
X
7
X
Write:
-
X
0
-
0
X
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_POLFA [31]
Programmed retraction position for single axis
DOUBLE
Description:
$AA_POLFA[X]
X: PLC-controlled axis (= single axis)
Supplies the programmed retraction position of the PLC-controlled axis
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
708
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_POLFA_VALID [31]
Status of the value of $AA_POLFA
INT
Description:
$AA_POLFA_VALID[X]
Supplies the current status of $AA_POLFA[X]
X: PLC-controlled axis (= single axis)
Return values:
0: Retraction not programmed
1: Retraction programmed as position
2: Retraction programmed as distance
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
2
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_ALARM_STAT [31]
Display if alarms are present
INT
Description:
$AA_ALARM_STAT
Displays whether there are alarms present for a PLC-controlled axis.
The coded, associated alarm responses can be used as a source for the "Extended stop and retract".
The data is bit-coded so that, if necessary, individual states can also be
masked or evaluated separately (bits not listed below supply a value of 0)
Bit2 = 1: NOREADY (active rapid deceleration + cancellation of servo enable)
Bit6 = 1: STOPBYALARM (ramp stop of all channel axes)
Bit9 = 1: SETVDI (VDI interface signal alarm is set)
Bit13 = 1: FOLLOWUPBYALARM (follow-up)
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
-2147483648
2147483647
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
709
List of system variables
3.24 Axial system variables
$AN_AXCTSWA [31]
Axis container rotation
BOOL
Description:
Is axis container rotation active ?
Example: EVERY $AN_AXCTSWA[n] == TRUE DO M99
Read:
TRUE: An axis container rotation is currently being executed on the
axis container with axis container name n
FALSE: Axis container rotation is not active.
The axis container name or the axis name of an axis in the axis container can be specified as the index.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
FALSE
FALSE
TRUE
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AN_AXCTAS [31]
Axis container current position
INT
Description:
Axis container current position:
The current position of the axis container is returned for the axis container with the axis container name n.
The value ranges from 0 to the maximum number of occupied slots in the axis container -1.
In the basic position of the axis container, $AN_AXCTAS = 0
The axis container name or the axis name of an axis in the axis container can be specified as the index.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
-2147483648
2147483647
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AC_AXCTSWA [31]
Channel enable for axis container rotation
BOOL
Description:
Enables axis container rotation in the channel.
TRUE: The channel has axis container rotation enabled for the
axis container name n, and this rotation has not yet
finished.
FALSE: The axis container rotation has finished.
The axis container name or the axis name of an axis in the axis container can be specified as the index.
Index 1:
Maximum axis number
System variables
710
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AC_AXCTSWA [31]
Channel enable for axis container rotation
BOOL
Unit
Init value
Min
Max
-
FALSE
FALSE
TRUE
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$VA_POSCTRL_MODE [31]
Position controller mode
INT
Description:
$VA_POSCTRL_MODE[X]
Position controller mode:
0 = Closed-loop position control
1 = Closed-loop speed control
2 = Stop
3 = Park
4 = Follow-up
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
4
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Current value
Link:
Not classified
$VA_SCE [31]
Status of speed controller enable
BOOL
Description:
$VA_SCE[X1]
Status of speed controller enable
For SINAMICS drives with a telegram type greater than 100: The status comes directly from the drive (message word, bit11)
For other PROFIdrive drives: The status is modeled from further drive status signals (including status word1, bit2)
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
FALSE
FALSE
TRUE
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
711
List of system variables
3.24 Axial system variables
$AA_TRAVEL_DIST [31]
Total traverse path
DOUBLE
Description:
Total traversing distance of axis in MCS in mm or degrees. The total
traversing distance of the axis since the SRAM contents were last erased is added.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
0.0
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Program sensitive
Link:
Not classified
$AA_TRAVEL_TIME [31]
Total traversing time of the axis
DOUBLE
Description:
Total traversing time of axis in MCS in seconds. The total traversing time of the
axis since the SRAM contents were last erased is added.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
s
0.0
0.0
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Program sensitive
Link:
Not classified
$AA_TRAVEL_COUNT [31]
Number of traversing operations
DOUBLE
Description:
Number of traversing operations of axis in MCS. The total number of
traversing operations since the SRAM contents were last erased is stored.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0.0
0.0
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Program sensitive
Link:
Not classified
System variables
712
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_TRAVEL_DIST_HS [31]
Total traversing distance at high velocity
DOUBLE
Description:
Total traversing distance of axis in MCS in mm or degrees at high velocity, i.e.
at a velocity of >= 80% of the maximum axis velocity. This value is
stored in the SRAM.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
0.0
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Program sensitive
Link:
Not classified
$AA_TRAVEL_TIME_HS [31]
Total traversing time of the axis at high velocity
DOUBLE
Description:
Total traversing time of axis in seconds at high velocity in MCS, i.e.
at a velocity of >= 80% of the maximum axis velocity. This value
is stored in the SRAM.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
s
0.0
0.0
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Program sensitive
Link:
Not classified
$AA_TRAVEL_COUNT_HS [31]
No. of traversing operations at high velocity
DOUBLE
Description:
Number of traversing operations of axis in MCS at high velocity, i.e.
at a velocity of >= 80% of the maximum axis velocity. This value is
stored in the SRAM.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0.0
0.0
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Program sensitive
Link:
Not classified
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
713
List of system variables
3.24 Axial system variables
$AA_JERK_TOT [31]
Total axial jerk
DOUBLE
Description:
Total axial jerk in m/s^3. The total jerk applied
to the axis is added up and stored in the SRAM.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular jerk
0.0
0.0
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Program sensitive
Link:
Not classified
$AA_JERK_TIME [31]
Total traversing time of the axis with jerk
DOUBLE
Description:
Total traversing time of axis in seconds in MCS with jerk. The total time period
for which the axis traverses with jerk is added up and stored
in the SRAM.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
s
0.0
0.0
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Program sensitive
Link:
Not classified
$AA_JERK_COUNT [31]
Number of traversing operations with jerk
DOUBLE
Description:
Number of traversing operations executed by axis in MCS with jerk. This value
is stored in the SRAM.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0.0
0.0
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Program sensitive
Link:
Not classified
System variables
714
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AC_RPVALID [31]
Repos position valid
BOOL
Description:
$AC_RPVALID[X]
$AC_RPVALID[axis identifier] returns TRUE if a valid Repos position, which can be interrogated with $AC_RETPOINT[axis identifier], is available
for this axis.
Valid Repos positions are generally available while system and user ASUBs are being processed. However, this is not the case in the following
situations:
- The ASUB activates a modified radius when tool radius compensation is active. $AC_RPVALID then returns FALSE for geometry axes while the
ASUB is running. The newly calculated Repos positions only become available with the approach blocks generated by the REPOS command.
- The end position of the axis was last specified by the main run (FC18, synchronized actions, reciprocation, transfer from another channel after
axis replacement).
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
FALSE
FALSE
TRUE
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$VA_SYNCDIFF [31]
Synchronism deviation between actual values
DOUBLE
Description:
$VA_SYNCDIFF[FA]
FA: Following axis/following spindle
Deviation in synchronism between actual values for LEAD, TRAIL, ELG and COUP.
The deviation in synchronism between actual values is the deviation in distance between the servo actual position of the following axis/
following spindle and a point calculated (according to the coupling rule) from the servo actual position of the leading axis/leading spindle.
$VA_SYNCDIFF[FA] = $VA_IM[FA] - K($VA_IM[LA])
K: Coupling rule
LA: Leading axis/leading spindle
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
715
List of system variables
3.24 Axial system variables
$AA_SYNCDIFF [31]
Synchronism deviation between setpoints
DOUBLE
Description:
$AA_SYNCDIFF[FA]
FA: Following axis/following spindle
Deviation in synchronism between setpoints for LEAD, TRAIL, ELG and COUP.
The deviation in synchronism between setpoints is the deviation in distance between the setpoint position
of the following axis/following spindle and a point calculated (according to the coupling rule) from the setpoint position
of the leading axis/leading spindle.
$AA_SYNCDIFF[FA] = $AA_IM[FA] - K($AA_IM[LA])
K: Coupling rule
LA: Leading axis/leading spindle
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$VA_SYNCDIFF_STAT [31]
Status of synchronism deviation between actual values
INT
Description:
VA_SYNCDIFF_STAT[FA]
FA: Following axis/following spindle
Status of synchronism deviation between actual values:
-4: Reserved
-3: No valid value in $VA_SYNCDIFF, tangential control ( not TANG(... "P") )
-2: No valid value in $VA_SYNCDIFF, master value coupling and simulated MV
-1: No valid value in $VA_SYNCDIFF
0: No valid value in $VA_SYNCDIFF, coupling not active
1: Valid value in $VA_SYNCDIFF
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
-4
1
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
716
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_SYNCDIFF_STAT [31]
Status synchron. dev. between setpoints
INT
Description:
$AA_SYNCDIFF_STAT[FA]
FA: Following axis/following spindle
Status of synchronism deviation between setpoints:
-4: No valid value in $AA_SYNCDIFF, coupled motion from part program
-3: Reserved
-2: Reserved
-1: No valid value in $AA_SYNCDIFF
0: No valid value in $AA_SYNCDIFF, coupling not active
1: Valid value in $AA_SYNCDIFF
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
-4
1
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_OSCILL_BREAK_POS1 [31]
Reciprocation interruption position 1
DOUBLE
Description:
$AA_OSCILL_BREAK_POS1[<axis>]
The current approach to reversal position 1 is finished at
this position or the last approach to
reversal position 1 was finished at this position (reversal
position 2 currently being approached).
$AA_OSCILL_BREAK_POS1[<axis>] is not equal to
$AA_OSCILL_REVERSE_POS1[<axis>] if the
reciprocation motion was interrupted by an
external signal (PLC).
The variable can be accessed only from synchronized actions.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
717
List of system variables
3.24 Axial system variables
$AA_OSCILL_BREAK_POS2 [31]
Reciprocation interruption position 2
DOUBLE
Description:
$AA_OSCILL_BREAK_POS2[<axis>]
The current approach to reversal position 2 is finished at
this position or the last approach to
reversal position 2 was finished at this position (reversal
position 1 currently being approached).
$AA_OSCILL_BREAK_POS2[<axis>] is not equal to
$AA_OSCILL_REVERSE_POS2[<axis>] if the
reciprocation motion was interrupted by an
external signal (PLC).
The variable can be accessed only from synchronized actions.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_BCS_OFFSET [31]
Total axis offsets
DOUBLE
Description:
Axial variable $AA_BCS_OFFSET[ax] is used to determine the total axis offsets for an axis. The total consists of the handwheel (DRF) offset, the
overlaid movement ($AA_OFF[ax]) and the external work offset. This offset is included in the BCS. The MCS is displaced in relation to the BCS
according to the offset.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_CHANNO [31]
Axis in the channel
INT
Description:
This variable returns the number of the channel in which the axis is being interpolated.
If value 0 is output, the axis could not be assigned to a channel.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
10
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
System variables
718
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_CHANNO [31]
Axis in the channel
INT
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_IW_CORR [31]
Actual PCS-Position of one axis incl. overlay rates
DOUBLE
Description:
The axial variable $AA_IW_CORR[ax] determines the actual setpoint value of the workpiece coordinate system (WCS) for the respective axis.
The setpoint value corresponds to the initial value of the interpolator for the actual interpolation cycle. As opposed to $AA_IW, this value
contains the axial overlay shares (DRF, AA_OFF, external WO, retraction etc. ).
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_IEN_CORR [31]
Actual FCS-Position of one axis incl. overlay rates
DOUBLE
Description:
The axial variable $AA_IEN_CORR[ax] calculates the actual interpolator position of the adjustable coordinate system (ACS) for the specified axis.
See also $AA_IW_CORR[ax]. The ACS-Value contains any axial overlay rate (DRF, AA_OFF, external Frame, etc. ).
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_IBN_CORR [31]
Actual FCS-Position of one axis incl. overlay rates
DOUBLE
Description:
The axial variable $AA_IBN_CORR[ax] calculates the actual interpolator position of the foot coordinate system (FCS) for the specified axis. See
also $AA_IW_CORR[ax]. The FCS-Value contains any axial overlay rate (DRF, $AA_OFF, external Frame, etc. ).
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
719
List of system variables
3.24 Axial system variables
$AA_IBN_CORR [31]
Actual FCS-Position of one axis incl. overlay rates
DOUBLE
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_IB_CORR [31]
Actual BCS-Position of one axis incl. overlay rates
DOUBLE
Description:
The axial variable $AA_IB_CORR[ax] calculates the actual interpolator position of the base coordinate system (BCS) for the specified axis. See
also $AA_IW_CORR[ax]. The BCS-Value contains any axial overlay rate (DRF, $AA_OFF, external Frame, etc. ).
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_TYPE [31]
Axis type
INT
Description:
$AA_TYPE[<axis>]
Axis type:
0: Type is not ascertainable
1: NC-Program axis
2: Neutral axis
3: PLC axis
4: Oscillating axis
5: Neutral axis which is currently executing a JOG or homing motion
6: Following axis coupled via master value
7: Coupled motion following axis
8: Command axis
9: CompileCycles axis
10: Coupled slave axis (master-slave function)
11: Program axis which is currently executing a JOG or homing motion
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
11
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
-
0
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
720
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_DTSW [31]
Distance from start of motion in PCS
DOUBLE
Description:
Axial variable $AA_DTSW[ax] determines the axial distance (with algebraic sign) from the start of motion in the workpiece coordinate system
for positioning and synchronized axes. The programmed position is the only factor used to calculate the distance. If the axis is a coupled axis,
the position component derived from the axis coupling is not considered.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_DTSB [31]
Distance from start of motion in BCS
DOUBLE
Description:
Axial variable $AA_DTSB[ax] determines the axial distance (with algebraic sign) from the start of motion in the basic coordinate system for
positioning and synchronized axes. The programmed position is the only factor used to calculate the distance. If the axis is a coupled axis, the
position component derived from the axis coupling is not considered.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_COUP_CORR [31]
Generic coupling: Compensation value for 'Correct syn-
DOUBLE
chronism difference'
Description:
The variable $AA_COUP_CORR[Sn] with spindle Sn (n: spindle number), example S2: spindle 2 or C: axis C
serves to execute the "Correct synchronism error" functionality, and provides the compensation value for the position offset for generic
couplings with CPFRS="MCS" (or CPSETTYPE="COUP").
For the duration (MD 30455 MISC_FUNCTION_MASK, bit 7) of the activation of the NC/PLC interface signal <Synchronlauf_nachfuehren/>
(Correct synchronism error) for the following spindle in active coupling, the actual values of this spindle are compared with the setpoint values.
The difference is the compensation value that can be read with the system variables $AA_COUP_CORR.
If the compensation value is known, this value can also be written directly into the system variable. The NC/PLC interface signal <Synchron-
lauf_nachfuehren/> (Correct synchronism error) should not be set in this case. The variable becomes effective only if a CP coupling has been
activated for the spindle with CPSETTYPE="COUP" or CPFRS="MCS". If the axis is not a configured spindle, the writing is ignored.
In the coupling module, the variable $AA_COUP_CORR is considered, and it corrects the setpoint values.
The compensation value is automatically deleted for reference point approach and zero mark synchronization of spindles. The system variable
then returns the value 'zero'.
Depending on the application, the compensation value can also be deleted at an earlier point in time by writing the value '0' to the variables.
Index 1:
Axis/spindle identifier
Unit
Init value
Min
Max
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
721
List of system variables
3.24 Axial system variables
$AA_COUP_CORR [31]
Generic coupling: Compensation value for 'Correct syn-
DOUBLE
chronism difference'
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
runin stp
X
7
-
0
X
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
No restrictions
$AA_AXCHANGE_TYP [31]
axchange axistype
INT
Description:
$AA_AXCHANGE_TYP[<axis>]
Type of axis with regard to axis replacement
0: Axis assigned to NC program
1: Axis assigned to PLC, or active as command or reciprocating axis
2: Other channel has right to interpolate
3: Neutral axis
4: Neutral axis controlled by PLC
5: Other channel has right to interpolate, axis requested for NC program
6: Other channel has right to interpolate, axis requested as neutral axis
7: Axis is PLC axis or active as command or reciprocating axis, axis requested for NC program
8: Axis is PLC axis or active as command or reciprocating axis, axis requested as neutral axis.
9: Firmly assigned PLC axis, in neutral axis status
10: Firmly assigned PLC axis, controlled by the PLC, in neutral axis status
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
10
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_AXCHANGE_STAT [31]
axchange axis state
INT
Description:
$AA_AXCHANGE_STAT[<Axis>]
Axis status regarding axis interchange:
0: Axis can be interchanged
1: Axis is assigned to the channel, but can become the PLC, command or reciprocating axis
2: Axis cannot be interchanged
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
2
Read/Write properties:
System variables
722
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_AXCHANGE_STAT [31]
axchange axis state
INT
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
-
X
0
-
0
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_INPOS_STAT [31]
State of the programmed position
INT
Description:
The variable $AA_INPOS_STAT[<axis>] returns the status of a programmed axis position. The indexing position is used for indexing axes. In the
case of spindles, $AA_INPOS_STAT refers to the spindle position of SPOS/SPOSA/M19. In speed control mode M3/M4/M5/SPCOF and after M70
value 0 is always read.
$AA_INPOS_STAT always refers to the programmed position. The programmed position cannot be reached if end positions change during
interpolation (delete distance-to-go, NC Stop, REPOS). At zero speed, the variable then gives the value 0.
Axis positions can be programmed through the part program, synchonized actions, FC18 or as indexing positions.
The variable returns the following values:
0: No status available (axis / spindle outside the programmed position)
1: Awaiting traversing movement
2: Position reached via setpoint
3: Position reached via 'Exact stop coarse'
4: Position reached via 'Exact stop fine'
Note 1: The status referring to the programmed position is independent of the operating mode (AUTOMATIC, JOG, MDI, ...)
Note 2: If additional position components (e.g. following axis couplings, corrections, compensations etc.) are inserted, then the programmed
position is no longer identical with the machine axis position. During the period of additional traversings, exact stop signals are deleted, and
the status can fall to the value 1.
Note 3: When approaching a position with tight exact stop limits, overshooting can cause the status to drop briefly again in relation to the
dynamics of an axis / spindle.
Note 4: Function-dependent, the signals 'Spindle in position' and 'Indexing axis in position' are output on the axial VDI interface.
Note 5: When determining the status of a path axis with G643/G644/G645, the variable $AA_INPOS_STAT can remain at the value '1' on account
of smoothing behavior during the path motion. Remedy: Use variable $AA_STAT (however the variable $AA_STAT does not check whether a
programmed position has been reached).
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
4
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
723
List of system variables
3.24 Axial system variables
$VA_ENC_ZERO_MON_ERR_CNT
Zero mark monitoring error counter
INT
[n,31]
Description:
Incremental and distance-coded measuring systems:
$VA_ENC_ZERO_MON_ERR_CNT[n,ax] contains the current number of
detected zero mark errors.
Absolute measuring systems ($MA_ENC_TYPE=4):
NCK.71 and higher: $VA_ENC_ZERO_MON_ERR_CNT[n,ax] contains the current
number of detected limit violations by the comparison between the absolute and
incremental encoder tracks (limit values see MDs $MA_ENC_ABS_ZEROMON_WARNING
and $MA_ENC_ABS_ZEROMON_INITIAL)
NCK.64 and higher: $VA_ENC_ZERO_MON_ERR_CNT[n,ax] contains the current number of
deviations in 1/2 coarse increments between the absolute and incremental encoder tracks.
$VA_ENC_ZERO_MON_ERR_CNT[n,ax] is initialized to 0 during power ON.
It is not reset by RESET.
The indices mean:
n: Number of encoder
ax: Machine axis
(See also $MA_ENC_ZERO_MONITORING and alarm 25020)
Index 1:
n: Encoder number
Index 2:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
2147483647
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$VA_ABSOLUTE_ENC_ERR_CNT [n,31]
Error counter for absolute encoder
INT
Description:
Absolute measuring systems ($MA_ENC_TYPE=4), only for SIMODRIVE 611D:
This counter is incremented if any new errors have been recognized during transmission of absolute values. This can be used to observe the
transmission of absolute values.
Other systems/drives:
Variable returns 0.
$VA_ABSOLUTE_ENC_ERR_CNT[n,ax] is initialized to 0 during Power ON. RESET does not cause a reset.
The indices mean:
n: Number of encoder
ax: Machine axis
Index 1:
n: Encoder number
Index 2:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
2147483647
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
System variables
724
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$VA_ABSOLUTE_ENC_ERR_CNT [n,31]
Error counter for absolute encoder
INT
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$VA_ABSOLUTE_ENC_STATE [n,31]
Absolute encoder interface status
INT
Description:
Absolute measuring systems ($MA_ENC_TYPE=4), only for SIMODRIVE 611D:
The axial variable $VA_ABSOLUTE_ENC_STATE[n,ax] determines the last occurrence of an error state of the absolute encoder interface.
The indices mean:
n: Number of encoder
ax: Machine axis
Details:
Bit 0 Interface active
Bit 1 Error during parity check
Bit 2 Error bit Alarm
Bit 3 Error bit CRC error
Bit 4 Start bit for EnDat transmission missing
(see also Description of Functions 'Measuring System Monitoring'
Other systems/drives:
Variable returns 0.
Index 1:
n: Encoder number
Index 2:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
31
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
725
List of system variables
3.24 Axial system variables
$P_DIAM_STAT [31]
Status of the diameter programming in the preprocess-
INT
ing
Description:
The system variable $P_DIAM_STAT[AX] returns the programmed status of the diameter programming in the channel.
The programmed status of the diameter programming is bit-coded:
BIT0 = 0: Diameter programming not active
BIT0 = 1: Diameter programming active
Note : The following bits only have a meaning that can be evaluated if BIT0 = 1:
BIT1 = 0: Channel-specific diameter programming active
BIT1 = 1: Axis-specific diameter programming active
BIT2 = 0: Absolute and incremental dimensions in the diameter
BIT2 = 1: Absolute dimension in the diameter, incremental dimension in the radius
BIT3 = 0: DIAMCYCOF not active
BIT3 = 1: DIAMCYCOF active
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
15
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_DIAM_STAT [31]
Status of the diameter programming in the main run
INT
Description:
The system variable $AA_DIAM_STAT[AX] returns the active main run status of the diameter programming in the channel.
The active status of the diameter programming is bit-coded:
BIT0 = 0: Diameter programming not active
BIT0 = 1: Diameter programming active
Note : The following bits only have a meaning that can be evaluated if BIT0 = 1:
BIT1 = 0: Channel-specific diameter programming active
BIT1 = 1: Axis-specific diameter programming active
BIT2 = 0: Absolute and incremental dimensions in the diameter
BIT2 = 1: Absolute dimension in the diameter, incremental dimension in the radius
BIT3 = 0: DIAMCYCOF not active
BIT3 = 1: DIAMCYCOF active
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
15
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
-
Write:
-
-
0
-
0
-
System variables
726
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_DIAM_STAT [31]
Status of the diameter programming in the main run
INT
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$P_SCC_STAT [31]
Status of the G96/G961/G962 assignment in the prepro-
INT
cessing
Description:
The system variable $P_SCC_STAT[AX] returns the preprocessing status of the G96/G961/G962 assignment in the channel, this has been
configured or programmed by SCC[AX] .
The status of the G96/G961/G962 assignment is bit-coded:
BIT0 = 0: Axis is not assigned to G96/G961/G962
BIT0 = 1: Axis is assigned to G96/G961/G962
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
15
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_SCC_STAT [31]
Status of the G96/G961/G962 assignment in the main
INT
run
Description:
The system variable $AA_SCC_STAT[AX] returns the main run status of the G96/G961/G962 assignment in the channel, this has been config-
ured or programmed by SCC[AX].
The status of the G96/G961/G962 assignment is bit-coded:
BIT0 = 0: Axis is not assigned to G96/G961/G962
BIT0 = 1: Axis is assigned to G96/G961/G962
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
0
15
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_CPNACTFA [31]
Number of active following axes/spindles
INT
Description:
The system variable $AA_CPNACTFA[ax] returns the number of active couplings (following axes/spindles) in which the stated axis ax is active
as a leading axis/spindle
Index 1:
Axis/spindle identifier of the leading axis/spindle
Unit
Init value
Min
Max
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
727
List of system variables
3.24 Axial system variables
$AA_CPNACTFA [31]
Number of active following axes/spindles
INT
-
0
0
2147483647
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_CPFCMDPT [31]
Axis setpoint position across all coupling components
DOUBLE
Description:
The system variable $AA_CPFCMDPT[ax] returns the coupling component of the axis setpoint position. This component is the sum of all
dependent components of the axis position of all leading axes/spindles of the following axis/spindle
Index 1:
Axis/spindle identifier of the following axis/spindle
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_CPFCMDVT [31]
Axis setpoint velocity across all coupling components
DOUBLE
Description:
The system variable $AA_CPFCMDVT[ax] returns the coupling component of the axis setpoint velocity. This component is the sum of all
dependent components of the axis velocity of all leading axes/spindles of the following axis/spindle
Index 1:
Axis/spindle identifier of the following axis/spindle
Unit
Init value
Min
Max
Linear / angular speed
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_CPFREQV [31]
Required velocity of the coupling
DOUBLE
Description:
The system variable $AA_CPFREQV[ax] returns the velocity required by the leading axes/spindles.
Index 1:
Axis/spindle identifier of the following axis/spindle
Unit
Init value
Min
Max
Linear / angular speed
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
System variables
728
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_CPFREQV [31]
Required velocity of the coupling
DOUBLE
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_CPNDEFLA [31]
Number of defined master axes
INT
Description:
The system variable $AA_CPNDEFLA[ax] returns the number of leading axes/spindles defined for the following axis/spindle ax.
Index 1:
Axis/spindle identifier of the following axis/spindle
Unit
Init value
Min
Max
-
0
0
2147483647
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_CPNACTLA [31]
Number of active leading axes
INT
Description:
The system variable $AA_CPNDEFLA[ax] returns the number of leading axes/spindles active for the following axis/spindle ax.
Index 1:
Axis/spindle identifier of the following axis/spindle
Unit
Init value
Min
Max
-
0
0
2147483647
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_CPFACCT [31]
Axis setpoint acceleration across all coupling compo-
DOUBLE
nents
Description:
The system variable $AA_CPFACCT[ax] returns the coupling component of the axis setpoint acceleration. This component is the sum of all
dependent components of the axis acceleration of all leading axes/spindles of the following axis/spindle
Index 1:
Axis/spindle identifier of the following axis/spindle
Unit
Init value
Min
Max
Linear / angular accelera-
0.0
-1.8E+308
1.8E+308
tion
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
729
List of system variables
3.24 Axial system variables
$AA_CPFACCT [31]
Axis setpoint acceleration across all coupling compo-
DOUBLE
nents
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_CPFRS [31]
Reference system of the coupling
STRING
Description:
The system variable returns the reference system of the coupling for the following axis/spindle
"BCS" = basic coordinate system
"MCS" = machine coordinate system
Index 1:
Axis/spindle identifier of the following axis/spindle
Index 3:
Max. string length
Unit
Init value
Min
Max
-
""
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_CPFMSON [31]
Synchronization mode when the coupling is switched
STRING
on
Description:
The system variable $AA_CPFMSON[ax] returns the synchronization mode of the following axis/spindle ax when the coupling is switched on.
The synchronization mode determines the synchronization response when the coupling is switched on.
See the Generic Coupling documentation for further details.
Index 1:
Axis/spindle identifier of the following axis/spindle
Index 3:
Max. string length
Unit
Init value
Min
Max
-
""
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
730
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_CPFMON [31]
Response of the following axis when the coupling is
STRING
switched on
Description:
The system variable returns the response of the following axis/spindle when the coupling is switched on
"STOP" - Following axis/spindle is stopped
"CONT" - Active motion of the following axis/spindle is accepted as the starting motion
"ADD" - Active motion is retained as overlaid motion
See the Generic Coupling documentation for further details.
Index 1:
Axis/spindle identifier of the following axis/spindle
Index 3:
Max. string length
Unit
Init value
Min
Max
-
""
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_CPFMOF [31]
Response of the following axis when the coupling is
STRING
switched off
Description:
The system variable returns the response of the following axis/spindle when the coupling is switched off
"STOP" - Following axis/spindle is stopped
"CONT" - Active motion of the following axis/spindle is retained
See the Generic Coupling documentation for further details.
Index 1:
Axis/spindle identifier of the following axis/spindle
Index 3:
Max. string length
Unit
Init value
Min
Max
-
""
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_CPMRESET [31]
Status of the coupling after reset
STRING
Description:
The system variable $AA_CPMRESET[ax] returns the status of the coupling for the following axis/spindle after reset or program end
"NONE" - Current status is retained
"ON" - Coupling is activated
"OFF" - Coupling is deactivated
"DEL" - Coupling is deactivated and deleted
See the Generic Coupling documentation for further details.
Index 1:
Axis/spindle identifier of the following axis/spindle
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
731
List of system variables
3.24 Axial system variables
$AA_CPMRESET [31]
Status of the coupling after reset
STRING
Index 3:
Max. string length
Unit
Init value
Min
Max
-
""
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_CPMSTART [31]
Status of the coupling after program start
STRING
Description:
The system variable $AA_CPMSTART[ax] returns the status of the coupling for the following axis/spindle ax after program start
"NONE" - Current status is retained
"ON" - Coupling is activated
"OFF" - Coupling is deactivated
"DEL" - Coupling is deactivated and deleted
See the Generic Coupling documentation for further details.
Index 1:
Axis/spindle identifier of the following axis/spindle
Index 3:
Max. string length
Unit
Init value
Min
Max
-
""
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_CPMSTARTPRT [31]
Status of the coupling after SERUPRO start
STRING
Description:
The system variable $AA_CPMSTART[ax] returns the status of the coupling for the following axis/spindle ax after SERUPRO start
"NONE" - Current status is retained
"ON" - Coupling is activated
"OFF" - Coupling is deactivated
"DEL" - Coupling is deactivated and deleted
See the Generic Coupling documentation for further details.
Index 1:
Axis/spindle identifier of the following axis/spindle
Index 3:
Max. string length
Unit
Init value
Min
Max
-
""
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
System variables
732
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_CPMSTARTPRT [31]
Status of the coupling after SERUPRO start
STRING
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_CPSETTYPE [31]
Default coupling type
STRING
Description:
The system variable $AA_CPSETTYPE[ax] returns the default coupling type for the following axis/spindle ax .
See the Generic Coupling documentation for further details.
"NONE"
"TRAIL"
"LEAD"
"EG"
"COUP"
Index 1:
Axis/spindle identifier of the following axis/spindle
Index 3:
Max. string length
Unit
Init value
Min
Max
-
""
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_CPBC [31]
Block change criterion
STRING
Description:
The system variable $AA_CPBC[ax] returns the active block change criterion when the coupling of the following axis/spindle ax is switched on.
"NONE" = Block change takes place irrespective of the coupling state
"FINE" = Block change does not take place until synchronism "fine" is reached
"COARSE" = Block change does not take place until synchronism "coarse" is reached
"IPOSTOP" = Block change does not take place until setpoint synchronism is reached
Index 1:
Axis/spindle identifier of the following axis/spindle
Index 3:
Max. string length
Unit
Init value
Min
Max
-
""
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
733
List of system variables
3.24 Axial system variables
$AA_CPFACT [31]
Active coupling types of a following axis/spindle
INT
Description:
The active coupling types for the axis/spindle ax are returned as bit-codes
0 = No active coupling
Bit 0,1 = TANG
Bit 2 = 1 ('H04') COUP
Bit 3 = 1 ('H08') TRAIL
Bit 4 = 1 ('H10') LEAD
Bit 5 = 1 ('H20') EG
Bit 6 = 1 ('H40') GANTRY
Bit 7,8 = 1 (H180) TANG with option P
Bit 9 = 1 ('H200') CP, generic coupling
Index 1:
Axis/spindle identifier of the following axis/spindle
Unit
Init value
Min
Max
-
0
-2147483648
2147483647
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_CPDEFLA [31,n]
Specifies the nth defined leading axis/spindle
AXIS
Description:
$AA_CPDEFLA[ax,n]
An axial identifier of the nth defined leading axis/spindle (counting starts at 1) is returned for the following axis/spindle ax.
If the leading axis is a geometry axis, the geometry axis identifier is returned, otherwise the channel axis identifier.
NO_AXIS is returned in the following cases:
- The stated coupling is not defined
- The leading axis/spindle that was found is not known in the channel
- n == 0
- n > $AA_CPNDEFLA[ax] (= number of defined leading axes of the following axis)
Index 1:
Axis/spindle identifier of the following axis/spindle
Index 2:
Serial number of the leading axis/spindle n (>= 1)
Unit
Init value
Min
Max
-
NOAXISNUM
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
734
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_CPACTLA [31,n]
Specifies the nth active leading axis/spindle
AXIS
Description:
$AA_CPACTLA[ax,n]
An axis identifier of the nth active leading axis/spindle (counting starts at 1) is returned for the following axis/spindle ax.
If the leading axis is a geometry axis, the geometry axis identifier is returned, otherwise the channel axis identifier.
NO_AXIS is returned in the following cases:
- The stated coupling is not active
- The leading axis/spindle that was found is not known in the channel
- n == 0
- n > $AA_CPNACTLA[ax] (= number of active leading axes of the following axis)
Index 1:
Axis/spindle identifier of the following axis/spindle
Index 2:
Serial number of the leading axis/spindle n (>= 1)
Unit
Init value
Min
Max
-
NOAXISNUM
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_CPACTFA [31,n]
Specifies the nth active following axis/spindle
AXIS
Description:
$AA_CPACTFA[ax,n]
An axis identifier of the following axis/spindle of the nth coupling (counting starts at 1) in which the axis ax is active as a leading axis/spindle
is returned for the leading axis/spindle ax.
If the following axis is a geometry axis, the geometry axis identifier is returned, otherwise the channel axis identifier.
NO_AXIS is returned in the following cases:
- The following axis/spindle that was found is not known in the channel
- n == 0
- n > $AA_CPNACTFA[ax] (= number of active couplings of the axis as a leading axis)
Index 1:
Axis/spindle identifier of the leading axis/spindle
Index 2:
Serial number of the following axis/spindle n (>= 1)
Unit
Init value
Min
Max
-
NOAXISNUM
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
735
List of system variables
3.24 Axial system variables
$PA_CPFACT [31]
Coupling type of a following axis/spindle
INT
Description:
$PA_CPFACT[ax]
It is possible to determine whether the axis / spindle ax is being used by a coupling. The coupling type is returned when the coupling is active.
The system variable must be read out for the following axis / spindle.
Bit0, Bit1 tangential following active, TANG
Bit2 = 1 ('H04') Synchronous spindle active, COUP
Bit3 = 1 ('H08') Coupled motion active, TRAIL
Bit4 = 1 ('H10') Master value coupling active, LEAD
Bit5 = 1 ('H20') Electronic gear active, EG
Bit6 = 1 ('H40') Gantry grouping active, GANTRY
Bit7, Bit8 Tangential following active, TANG (with optimization)
Bit9 = 1 ('H200') Generic coupling active, CP
Index 1:
Axis/spindle identifier of the following axis/spindle
Unit
Init value
Min
Max
-
0
-2147483648
2147483647
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$PA_CPFPOSSTAT [31]
Validity of the synchronized position and stop position
INT
Description:
$PA_CPFPOSSTAT[ax]
The validity of the synchronized position (Bit0) and the stop position (Bit1) can be read for the axis / spindle ax if the coupling is active.
Bit0 = 1 ('H01') Synchronized position is valid
Bit1 = 1 ('H02') Stop position is valid
Index 1:
Axis/spindle identifier of the following axis/spindle
Unit
Init value
Min
Max
-
0
0
2147483647
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
736
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$PA_CPSETTYPE [31]
Default coupling type
STRING
Description:
Returns the default coupling type for the axis/spindle ax.
$PA_CPSETTYPE[ax]
"NONE"
"TRAIL"
"LEAD"
"EG"
"COUP"
Index 1:
Axis/spindle identifier of the following axis/spindle
Index 3:
Max. string length
Unit
Init value
Min
Max
-
""
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$PA_CPNACTFA [31]
Number of active following axes/spindles
INT
Description:
Returns the number of active following axes/spindles for the leading axis/spindle ax.
Index 1:
Axis/spindle identifier of the leading axis/spindle
Unit
Init value
Min
Max
-
0
0
2147483647
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$PA_CPNDEFLA [31]
Number of defined leading axes/spindles
INT
Description:
Returns the number of defined leading axes/spindles for the axis/spindle ax.
Index 1:
Axis/spindle identifier of the following axis/spindle
Unit
Init value
Min
Max
-
0
0
2147483647
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
737
List of system variables
3.24 Axial system variables
$PA_CPNDEFLA [31]
Number of defined leading axes/spindles
INT
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$PA_CPNACTLA [31]
Number of active leading axes/spindles
INT
Description:
Returns the number of active leading axes/spindles for the axis/spindle ax.
Index 1:
Axis/spindle identifier of the following axis/spindle
Unit
Init value
Min
Max
-
0
0
2147483647
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$PA_CPFRS [31]
Coordinate reference
STRING
Description:
The coordinate reference of the defined axis/spindle coupling is returned for the axis/spindle ax
"NONE" = No coupling active
"BCS" = Basic coordinate system
"MCS" = Machine (coordinate system)
Index 1:
Axis/spindle identifier of the following axis/spindle
Index 3:
Max. string length
Unit
Init value
Min
Max
-
""
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$PA_CPFMSON [31]
Synchronization response at switch on
STRING
Description:
The synchronization mode for the axis/spindle ax is returned when the coupling is switched on.
See the Generic Coupling documentation for further details.
Index 1:
Axis/spindle identifier of the following axis/spindle
Index 3:
Max. string length
Unit
Init value
Min
Max
-
""
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
System variables
738
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$PA_CPFMSON [31]
Synchronization response at switch on
STRING
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$PA_CPFMON [31]
Response of the following axis when the coupling is
STRING
switched on
Description:
The system variable returns the response of the following axis/spindle when the coupling is switched on
"STOP" - Following axis/spindle is stopped
"CONT" - Active motion of the following axis/spindle is accepted as the starting motion
"ADD" - Active motion of the following axis/spindle is retained as overlaid motion
See the Generic Coupling documentation for further details.
Index 1:
Axis/spindle identifier of the following axis/spindle
Index 3:
Max. string length
Unit
Init value
Min
Max
-
""
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$PA_CPFMOF [31]
Response of the following axis when the coupling is
STRING
switched off
Description:
The system variable returns the response of the following axis/spindle when the coupling is switched off
"STOP" - Following axis/spindle is stopped
"CONT" - Active motion of the following axis/spindle is retained
See the Generic Coupling documentation for further details.
Index 1:
Axis/spindle identifier of the following axis/spindle
Index 3:
Max. string length
Unit
Init value
Min
Max
-
""
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
739
List of system variables
3.24 Axial system variables
$PA_CPMRESET [31]
Status of the coupling after reset
STRING
Description:
The system variable $PA_CPMRESET[ax] returns the status of the coupling for the following axis/spindle after reset or program end
"NONE" - Current status is retained
"ON" - Coupling is activated
"OFF" - Coupling is deactivated
"DEL" - Coupling is deactivated and deleted
See the Generic Coupling documentation for further details.
Index 1:
Axis/spindle identifier of the following axis/spindle
Index 3:
Max. string length
Unit
Init value
Min
Max
-
""
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$PA_CPMSTART [31]
Status of the coupling after program start
STRING
Description:
The system variable $PA_CPMSTART[ax] returns the status of the coupling for the following axis/spindle ax after program start
"NONE" - Current status is retained
"ON" - Coupling is activated
"OFF" - Coupling is deactivated
"DEL" - Coupling is deactivated and deleted
See the Generic Coupling documentation for further details.
Index 1:
Axis/spindle identifier of the following axis/spindle
Index 3:
Max. string length
Unit
Init value
Min
Max
-
""
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
740
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$PA_CPBC [31]
Block change criterion
STRING
Description:
The system variable $PA_CPBC[ax] returns the active block change criterion when the coupling of the following axis/spindle ax is switched on.
"NONE" = Block change takes place irrespective of the coupling state
"FINE" = Block change does not take place until synchronism "fine" is reached
"COARSE" = Block change does not take place until synchronism "coarse" is reached
"IPOSTOP" = Block change does not take place until setpoint synchronism is reached
Index 1:
Axis/spindle identifier of the following axis/spindle
Index 3:
Max. string length
Unit
Init value
Min
Max
-
""
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$PA_CPDEFLA [31,n]
Specifies the nth defined leading axis/spindle
AXIS
Description:
$PA_CPDEFLA[ax,n]
An axis identifier of the nth defined leading axis/spindle (counting starts at 1) is returned for the axis/spindle ax.
If the leading axis is a geometry axis, the geometry axis identifier is returned, otherwise the channel axis identifier.
NO_AXIS is returned in the following cases:
- The stated coupling is not defined in the channel
- n == 0
- n > number of leading axes of the following axis
Index 1:
Axis identifier for following axis/spindle
Index 2:
Index of the leading axis/spindle
Unit
Init value
Min
Max
-
NOAXISNUM
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
741
List of system variables
3.24 Axial system variables
$PA_CPACTLA [31,n]
Specifies the nth active leading axis/spindle
AXIS
Description:
$PA_CPACTLA[ax,n]
An axis identifier of the nth active leading axis/spindle (counting starts at 1) is returned for the following axis/spindle ax
If the leading axis is a geometry axis, the geometry axis identifier is returned, otherwise the channel axis identifier.
NO_AXIS is returned in the following cases:
- The specified coupling is not active in the channel
- n == 0
- n > number of active leading axes of the following axis
Index 1:
Axis/spindle identifier of the following axis/spindle
Index 2:
Index of the leading axis/spindle
Unit
Init value
Min
Max
-
NOAXISNUM
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$PA_CPACTFA [31,n]
Specifies the nth active following axis/spindle
AXIS
Description:
$PA_CPACTFA[ax,n]
An axis identifier of the following axis/spindle of the nth coupling (counting starts at 1), in which the axis ax is active as a leading axis/spindle,
is returned for the leading axis/spindle ax.
If the following axis is a geometry axis, the geometry axis identifier is returned, otherwise the channel axis identifier.
NO_AXIS is returned in the following cases:
- n == 0
- n > number of active couplings of the axis as leading axis in the channel
Index 1:
Axis/spindle identifier of the leading axis/spindle
Index 2:
Index of the following axis/spindle
Unit
Init value
Min
Max
-
NOAXISNUM
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
X
-
7
-
0
-
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
742
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_DEPAXO [31]
Dependence on other axes
INT
Description:
The variable $AA_DEPAXO[AX] returns an axis code for the stated axis AX, which contains all machine axes with a mechanical dependence on
the stated axis.
A dependency is produced by:
Active coupling modules, the following axis is dependent on the leading axis
Active transformations, output axes of the transformation are dependent
on the input axes of the transformation
Closed gantry groupings, the slave axes are dependent
on the master axis
The given axis itself is also returned in the axis code
The axis code indicates how the machine data $MC_AXCONF_MACHAX_USED refers not directly to the machine axes but to the logical NCK
machine axis image ($MN_AXCONF_LOGIC_MACHAX_TAB).
Bit 0 = 0 There is no dependence on the logical machine axis AX1
Bit 0 = 1 There is a dependence on the logical machine axis AX1
Bit 1 = 0 There is no dependence on the logical machine axis AX2
Bit 1 = 1 There is a dependence on the logical machine axis AX2
and so on.
Index 1:
Maximum axis number
Unit
Init value
Min
Max
-
0
-2147483648
2147483647
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_FIX_POINT_SELECTED [31]
Selected fixed point
INT
Description:
$AA_FIX_POINT_SELECTED[<Axis>]
0: No fixed point selected
> 0: Number of the selected fixed point
Via the NC/PLC interface signal <Aktiviere_Festpunktfahren_inJOG/> (Activate fixed point approach in JOG) you can activate the fixed point
approach in the operating mode JOG.
Bits 0-2 indicate the number of the fixed point to be approached.
Activation is confirmed via the NC/PLC interface signal <Festpunktfahren_in_JOG_aktiv/> (Fixed point approach in JOG active). The bits indicate
the number of the fixed point being approached.
Index 1:
Axis
Unit
Init value
Min
Max
-
0
0
4
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
743
List of system variables
3.24 Axial system variables
$AA_FIX_POINT_SELECTED [31]
Selected fixed point
INT
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_ON_FIX_POINT [31]
Number of the fixed point at which the axis is currently
INT
located
Description:
$AA_ON_FIX_POINT[<Axis>]
0: Axis is not at a fixed point
> 0: Number of the fixed point at which the axis currently stands (the fixed point position is the current position).
This is independent of the way this position was reached.
Index 1:
Axis
Unit
Init value
Min
Max
-
0
0
4
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$VA_ENC1_COMP_VAL [31]
EEC compensation value encoder 1
DOUBLE
Description:
The axial variable $VA_ENC1_COMP_VAL[ax] determines the current compensation value of the measuring system error compensation (en-
coder 1) in the machine coordinate system (MCS).
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$VA_ENC2_COMP_VAL [31]
EEC compensation value encoder 2
DOUBLE
Description:
The axial variable $VA_ENC2_COMP_VAL[ax] determines the current compensation value of the measuring system error compensation (en-
coder 2) in the machine coordinate system (MCS).
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
System variables
744
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$VA_ENC2_COMP_VAL [31]
EEC compensation value encoder 2
DOUBLE
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$VA_CEC_COMP_VAL [31]
CEC compensation value
DOUBLE
Description:
The axial variable $VA_CEC_COMP_VAL[ax] determines the current compensation value of the sag compensation in the machine coordinate
system (MCS).
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$VA_TEMP_COMP_VAL [31]
TEMP compensation value
DOUBLE
Description:
The axial variable $VA_TEMP_COMP_VAL[ax] determines the current compensation value of the temperature compensation in the machine
coordinate system (MCS).
Index 1:
Maximum axis number
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
SPIN
Overlap chan-
channel-specific
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_DTBREB [31]
Total deceleration path in the BCS
DOUBLE
Description:
$AA_DTBREB[ax]
Total deceleration path of the axis ax in the BCS. The value is the estimated deceleration path of the axis to standstill
Index 1:
Axis/spindle identifier
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
745
List of system variables
3.24 Axial system variables
$AA_DTBREB_CMD [31]
Command component of the total deceleration path in
DOUBLE
the BCS
Description:
$AA_DTBREB_CMD[ax]
Command component of the total deceleration path of the axis ax in the BCS. The value is the estimated deceleration path of the axis to
standstill
Index 1:
Axis/spindle identifier
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_DTBREB_CORR [31]
Correction component of the total deceleration path in
DOUBLE
the BCS
Description:
$AA_DTBREB_CORR[ax]
Correction component of the total deceleration path of the axis ax in the BCS. The value is the estimated deceleration path of the axis to
standstill
Index 1:
Axis/spindle identifier
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_DTBREB_DEP [31]
Coupling component of the total deceleration path in
DOUBLE
the BCS
Description:
$AA_DTBREB_DEP[ax]
Coupling component of the total deceleration path of the axis ax in the BCS. The value is the estimated deceleration path of the axis to standstill
Index 1:
Axis/spindle identifier
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
System variables
746
List Manual, 10/2020, 6FC5397-6AP40-6BA4
List of system variables
3.24 Axial system variables
$AA_DTBREB_DEP [31]
Coupling component of the total deceleration path in
DOUBLE
the BCS
Axis entry:
GEO
CHAN
MACH
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_DTBREM [31]
Total deceleration path in the Machine
DOUBLE
Description:
$AA_DTBREM[ax]
Total deceleration path of the axis ax in the Machine. The value is the estimated deceleration path of the axis to standstill
Index 1:
Axis/spindle identifier
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_DTBREM_CMD [31]
Command component of the total deceleration path in
DOUBLE
the Machine
Description:
$AA_DTBREM_CMD[ax]
Command component of the total deceleration path of the axis ax in the Machine. The value is the estimated deceleration path of the axis to
standstill
Index 1:
Axis/spindle identifier
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_DTBREM_CORR [31]
Correction component of the total deceleration path in
DOUBLE
the Machine
Description:
$AA_DTBREM_CORR[ax]
Correction component of the total deceleration path of the axis ax in the Machine. The value is the estimated deceleration path of the axis to
standstill
Index 1:
Axis/spindle identifier
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
System variables
List Manual, 10/2020, 6FC5397-6AP40-6BA4
747
List of system variables
3.24 Axial system variables
$AA_DTBREM_CORR [31]
Correction component of the total deceleration path in
DOUBLE
the Machine
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_DTBREM_DEP [31]
Coupling component of the total deceleration path in
DOUBLE
the Machine
Description:
$AA_DTBREM_DEP[ax]
Coupling component of the total deceleration path of the axis ax in the Machine. The value is the estimated deceleration path of the axis to
standstill
Index 1:
Axis/spindle identifier
Unit
Init value
Min
Max
Linear / angular position
0.0
-1.8E+308
1.8E+308
Read/Write properties:
TP
SA
TP/SA safety
NC-Variable
Safety
OEM-CC
Read:
runin stp
X
7
X
7
X
Write:
-
-
0
-
0
-
Axis entry:
GEO
CHAN
MACH
Overlap chan-
Cross-channel
nel:
Scan mode:
Not classified
Link:
Not classified
$AA_BRAKE_CONDB [31]
Context-sensitive conditions for interpolator stop in the
INT
BCS
Description:
The axial variable $AA_BRAKE_CONDB[ax] indicates the braking requests (conditions) pending on the axis / spindle to the interpolator stop. A
braking request consists of a collision direction referring to a coordinate axis in the BCS, and a braking priority referring to the machining level.
If the axis / spindle receives a new braking request due to these conditions, bit 0 is set in $AA_BRAKE_STATE[X] (in the next IPO cycle).
Bits 0 to 3 show the highest braking priority in positive direction:
0x0: No pending braking request
0x1: Priority 1 includes all positioning actions (G0, POS, SPOS)
0x2: Priority 2 includes DYNNORM and all movements of priority 1
0x3: Priority 3 includes DYNPOS and all movements of priorities 1 to 2
0x4: Priority 4 includes DYNROUGH and all movements of priorities 1 to 3
0x5: Priority 5 includes DYNSEMIFIN and all movements of priorities 1 to 4
0x6: Priority 6 includes all movements (incl. DYNFINISH). The request can also be triggered by a CP SW Limit Stop.
0x7: Priority 7 includes all movements. The request was triggered by the NC/PLC interface signal <VorschubHalt-SpindelHalt/> (Feed stop /
spindle stop). Brakes are always applied independently of the movement direction.
0xD: Priority 13 includes all movements. Axial braking is executed using the Emergency Stop braking ramp.
In bits 16 to 19 the highest braking priority is shown in negative direction:
0x0 to 0xD: Same significance as with bits 0 to 3
All other bits are reserved and not set.
When displaying the value of the variables in hexadecimal format, the fifth digit from the right indicates the braking priority in negative
direction and the digit on the right the braking priority in positive direction.
Index 1:
Axis identifier
Unit
Init value
Min
Max
-
0
0
0xD000D
System variables
748
List Manual, 10/2020, 6FC5397-6AP40-6BA4